
Magnetism, an invisible fundamental force of nature, is far more than just the attraction of metal to a magnet. It is a pervasive phenomenon that shapes our planet and underpins a vast array of technologies, playing an especially critical and often overlooked role in the advanced systems that enable modern flight. From the earliest compasses guiding mariners to the sophisticated navigation and stabilization systems found in contemporary drones and aircraft, understanding and harnessing magnetism has been pivotal in humanity’s quest to conquer the skies. In the intricate world of flight technology, magnetism is not merely a scientific curiosity but a foundational element ensuring precision, stability, and autonomy.
Understanding Magnetism: The Invisible Force Guiding Flight
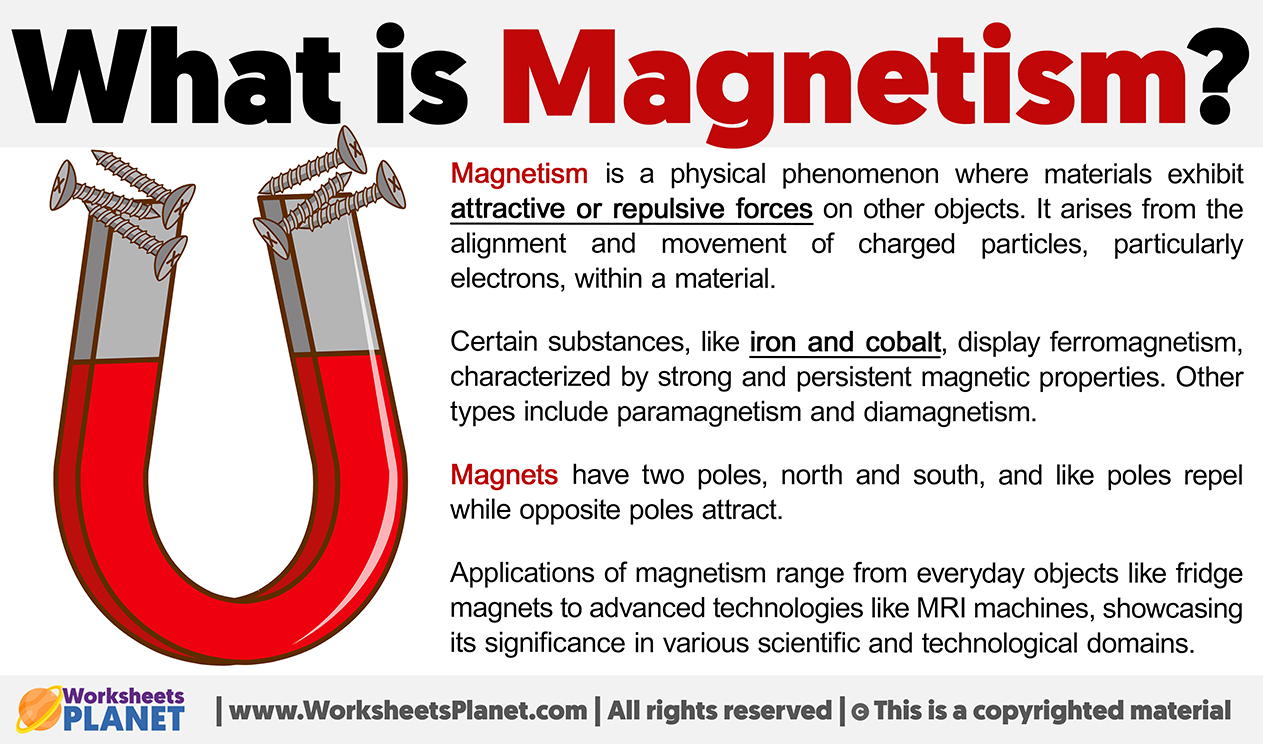
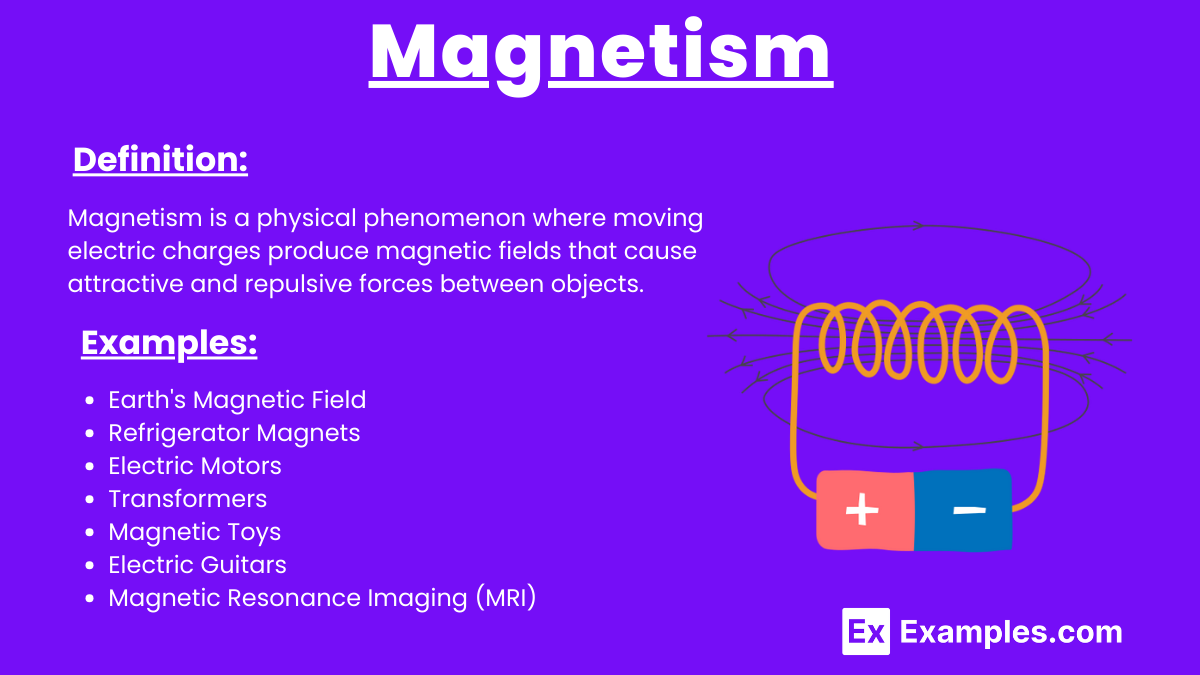
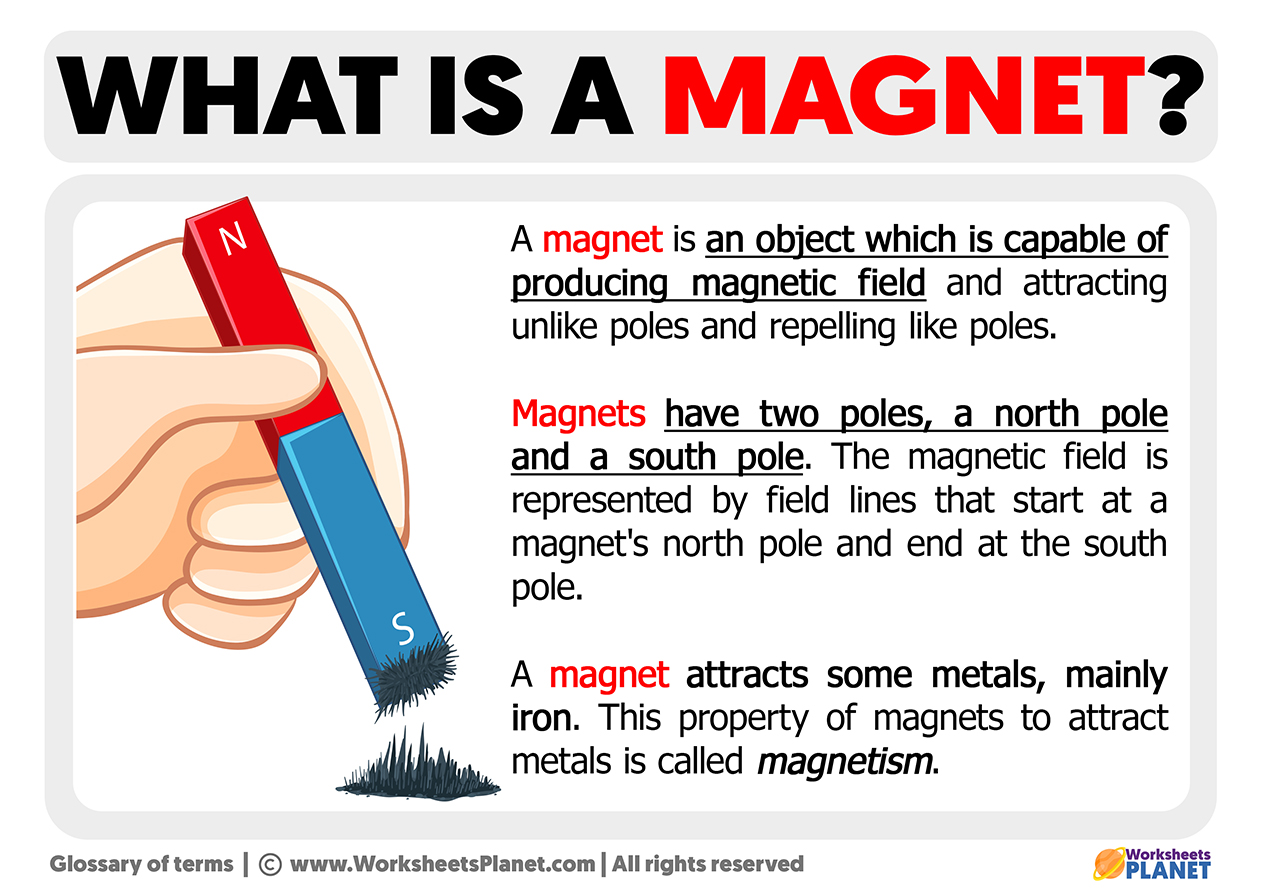
At its core, magnetism is a force mediated by magnetic fields, which are created by moving electric charges. These fields exert forces on other moving charges and magnetic materials. This fundamental interaction governs everything from the simple bar magnet to the complex electromagnetic systems powering electric motors. In the context of flight, particularly within the realm of autonomous aerial vehicles, magnetism offers a stable, ever-present frame of reference that complements and often augments other sensory data.
Permanent Magnets vs. Electromagnets
Magnetism manifests in several forms. Permanent magnets, like those found in compasses, produce their own persistent magnetic field. Their utility in flight technology is primarily in basic compass functionality and in the construction of some motor types. Electromagnets, conversely, produce magnetic fields only when an electric current flows through them. This controllable nature makes electromagnets crucial for electric motors, actuators, and various other components within flight systems where dynamic magnetic fields are required. For instance, the brushless DC motors ubiquitous in drones rely on the precise interplay between permanent magnets in the rotor and electromagnets in the stator to generate thrust. Beyond propulsion, the principles of electromagnetism are at the heart of many sophisticated sensors that help aerial vehicles perceive their environment.
Earth’s Geomagnetic Field: A Global Navigation Grid
Perhaps the most significant aspect of magnetism for flight technology is the Earth’s own geomagnetic field. Generated by the convection currents of molten iron in the planet’s outer core, this vast magnetic field envelops Earth, extending thousands of kilometers into space. It acts as a natural shield against harmful solar radiation and, crucially, provides a consistent, albeit dynamic, directional reference across the globe. For any aerial vehicle, particularly those operating autonomously or requiring precise orientation, tapping into this geomagnetic field offers an invaluable source of navigation data. Unlike satellite-based navigation systems, which can be susceptible to signal loss or jamming, the Earth’s magnetic field is always present, offering a robust fallback and augmentation mechanism for maintaining heading and orientation.
Magnetometers: The Digital Compass of Modern Aircraft
The ability to detect and measure the Earth’s magnetic field is realized through specialized sensors known as magnetometers. These devices are the digital compasses of modern flight technology, providing essential heading information that is critical for navigation, stabilization, and overall flight control. Without accurate magnetic sensing, autonomous flight would be significantly more challenging, if not impossible, for many applications.
Principles of Operation
Magnetometers come in several forms, each utilizing different physical principles to detect magnetic fields. Fluxgate magnetometers, known for their high sensitivity, measure the effect of an external magnetic field on a saturable core. Hall effect sensors measure the voltage difference across a conductor carrying current, when subjected to a magnetic field. More commonly in compact flight systems like drones, magnetoresistive magnetometers are employed. These sensors exploit the property of certain materials whose electrical resistance changes in the presence of a magnetic field. Regardless of the underlying technology, the output of a magnetometer is typically a set of values representing the magnetic field strength along three orthogonal axes (X, Y, Z). By measuring the components of the Earth’s magnetic field, these sensors can determine the vehicle’s orientation relative to magnetic north.
Integration within Inertial Measurement Units (IMUs)
While invaluable, magnetometers alone are insufficient for complete flight control. Their data must be fused with information from other sensors to provide a comprehensive understanding of the aircraft’s state. This integration typically occurs within an Inertial Measurement Unit (IMU). An IMU is a compact electronic device that measures and reports a vehicle’s specific force, angular rate, and often, the magnetic field surrounding the vehicle, using a combination of accelerometers, gyroscopes, and magnetometers.
Accelerometers measure linear acceleration, providing data on gravity and changes in velocity. Gyroscopes measure angular velocity, indicating rotational movements. The magnetometer, or e-compass, measures the Earth’s magnetic field, providing absolute heading information. When these three sensor types are combined and their data intelligently processed, the IMU can output highly accurate attitude (pitch, roll, yaw/heading) and sometimes position information. This sensor fusion is crucial because each sensor type has strengths and weaknesses; for instance, gyroscopes provide excellent short-term rotational data but suffer from drift over time, while magnetometers provide an absolute reference but can be susceptible to local magnetic interference.
Data Fusion with Accelerometers and Gyroscopes
The real power of magnetometers in flight technology emerges through data fusion algorithms. Kalman filters or complementary filters are commonly used to combine the raw data from accelerometers, gyroscopes, and magnetometers. Accelerometers help correct for gyroscope drift in pitch and roll by referencing the direction of gravity. Magnetometers provide the absolute yaw or heading reference, correcting the gyroscope’s long-term drift around the vertical axis. This synergistic approach results in a robust and accurate estimate of the aircraft’s orientation in 3D space, which is critical for stable flight, precise navigation, and executing complex maneuvers. Without the magnetic reference, cumulative errors from gyroscopes would quickly lead to significant heading inaccuracies, making autonomous flight impossible.
Enhancing Navigation and Stabilization Systems
The data provided by magnetometers, when integrated into flight control systems, dramatically improves both navigation accuracy and flight stability. These improvements are fundamental to the reliable operation of everything from consumer drones to advanced unmanned aerial vehicles (UAVs) performing critical missions.
Providing Absolute Heading Reference
One of the primary contributions of magnetometers is to provide an absolute heading reference. While GPS provides global position coordinates, it does not directly provide orientation. Gyroscopes track changes in orientation, but without an external reference, their errors accumulate, leading to “drift” in the heading estimate. Magnetometers, by detecting the Earth’s magnetic north, offer a stable, non-drifting reference point. This allows the flight controller to continuously correct the gyroscope’s yaw estimate, maintaining an accurate understanding of which direction the aircraft is facing. This precise heading information is vital for path planning, maintaining straight flight lines, executing coordinated turns, and ensuring that any cameras or sensors on board are pointed in the correct direction.
Drift Correction and Attitude Estimation
Beyond basic heading, magnetometers are indispensable for refining the overall attitude estimation. In combination with accelerometers, they help filter out the inherent noise and drift of gyroscopes, especially over longer flight durations. For instance, if a drone is holding a steady hover, the IMU combines the accelerometer’s sense of gravity with the magnetometer’s sense of magnetic north to continuously verify and correct the gyroscope’s output for pitch, roll, and yaw. This constant correction ensures that the flight controller always has an accurate picture of the aircraft’s orientation, allowing it to apply precise control inputs to counteract disturbances like wind, thereby maintaining stable flight. This robust attitude estimation is a cornerstone of modern autopilot systems.
Redundancy and GPS Augmentation
In scenarios where GPS signals are weak, jammed, or unavailable (e.g., indoors, under heavy foliage, or in contested environments), magnetometers provide a crucial layer of redundancy. While they cannot replace GPS for absolute positioning, they can maintain an accurate heading, which is vital for dead reckoning—estimating current position based on a previously determined position, and advancing that position based on known or estimated speeds and course over elapsed time. In such situations, the magnetic compass allows the aircraft to maintain a directed path, potentially returning to an area where GPS is available or completing a mission with reduced positional accuracy. Furthermore, even when GPS is fully operational, magnetometer data augments GPS by providing instantaneous heading changes that GPS, with its slower update rate, cannot always capture with sufficient fidelity for dynamic flight control. This combination creates a more resilient and precise navigation system.
Mitigating Magnetic Interference in Aerial Platforms
While incredibly useful, magnetometers are not without their challenges. The very sensitivity that makes them effective also makes them susceptible to magnetic interference, which can significantly degrade their accuracy and, consequently, the performance of the flight system. Understanding and mitigating these interferences is a critical aspect of designing and operating reliable aerial platforms.
Sources of Interference in Drones
Modern drones and other aerial vehicles are complex ecosystems of electronic components, many of which generate their own magnetic fields. The most significant sources of interference include:
- Motors and ESCs (Electronic Speed Controllers): The high currents flowing through motor windings and ESCs create strong, fluctuating magnetic fields that can overwhelm the subtle Earth’s magnetic field.
- Power Cables: Any cable carrying significant current will generate a magnetic field around it, proportional to the current’s strength.
- Batteries: While less dynamic, the static magnetic fields from battery packs can also contribute to overall interference, especially if they contain ferrous materials.
- Other Electronics: Switching power supplies, radio transmitters, and even the internal components of the flight controller itself can emit electromagnetic interference (EMI) that affects magnetometers.
- External Environment: Beyond the vehicle itself, magnetic anomalies in the operating environment (e.g., reinforced concrete structures, power lines, large metal objects, geological magnetic variations) can also corrupt magnetometer readings.
Calibration and Shielding Techniques
To counteract these interferences, several strategies are employed:
- Calibration: This is the most common and critical step. Magnetometer calibration involves rotating the aircraft through all axes in a magnetically “clean” environment. The flight controller records the magnetic field readings from various orientations, building a correction profile that accounts for fixed magnetic biases and scale factors caused by the drone’s own hardware. This calibration process allows the software to subtract the known magnetic signature of the drone from the raw sensor readings, isolating the Earth’s magnetic field components. Regular calibration is often necessary, especially after hardware changes or significant environmental shifts.
- Sensor Placement: Strategically locating the magnetometer as far as possible from known sources of interference (motors, ESCs, power lines) is crucial. Often, magnetometers are placed on external masts or at the furthest points on a drone’s frame to minimize direct exposure to internal magnetic noise.
- Shielding: In some cases, passive magnetic shielding can be used. This involves encasing sensitive components or routing magnetic fields away using materials with high magnetic permeability, such as mumetal or soft iron. However, shielding can add weight and complexity, and is not always feasible for compact aerial platforms.
- Filtering and Data Fusion Algorithms: Advanced filtering techniques in the flight controller’s software can help distinguish between legitimate geomagnetic signals and transient noise from onboard electronics. Furthermore, data fusion algorithms are designed to detect and temporarily de-weight magnetometer data when it appears corrupted, relying more heavily on gyroscope data until the magnetic readings stabilize or become reliable again.
Beyond Navigation: Evolving Roles of Magnetism in Flight Tech
The utility of magnetism in flight technology extends beyond current navigation and stabilization systems, with ongoing research exploring its potential for future advancements, pushing the boundaries of what aerial vehicles can achieve.
Magnetic Sensing for Advanced Situational Awareness
Future flight systems could leverage magnetism in more sophisticated ways for situational awareness. For instance, drones equipped with highly sensitive magnetometers could potentially detect anomalies in the Earth’s magnetic field caused by large underground metal objects, power lines, or even specific geological formations. This capability could be invaluable for infrastructure inspection, geophysical surveying, or search and rescue operations, allowing autonomous vehicles to identify hazards or targets that are not visible to optical sensors. Such applications would require even more robust interference mitigation and advanced data processing to differentiate subtle environmental magnetic signatures from internal noise.
Precision Landing and Docking Systems
Magnetism also holds promise for enhancing the precision of autonomous landing and docking. Magnetic markers embedded in landing pads or docking stations could emit specific magnetic signatures. A drone equipped with a sensitive magnetometer array could then precisely home in on these markers, providing highly accurate relative positioning data in the final crucial moments of approach, even in environments where GPS is unavailable or unreliable. This could enable fully autonomous charging, package delivery to precise locations, or the secure return of larger UAVs to their base stations with centimeter-level accuracy.
The journey of magnetism from a simple compass needle to an indispensable component of advanced flight technology underscores its profound and evolving impact. As aerial platforms become more autonomous, versatile, and integrated into our daily lives, the intricate dance between magnetic fields and electronic systems will continue to be a cornerstone of their design and operation, ensuring their precision, reliability, and ultimately, their continued success in the skies.