
Understanding Standard Deviation in Drone Technology
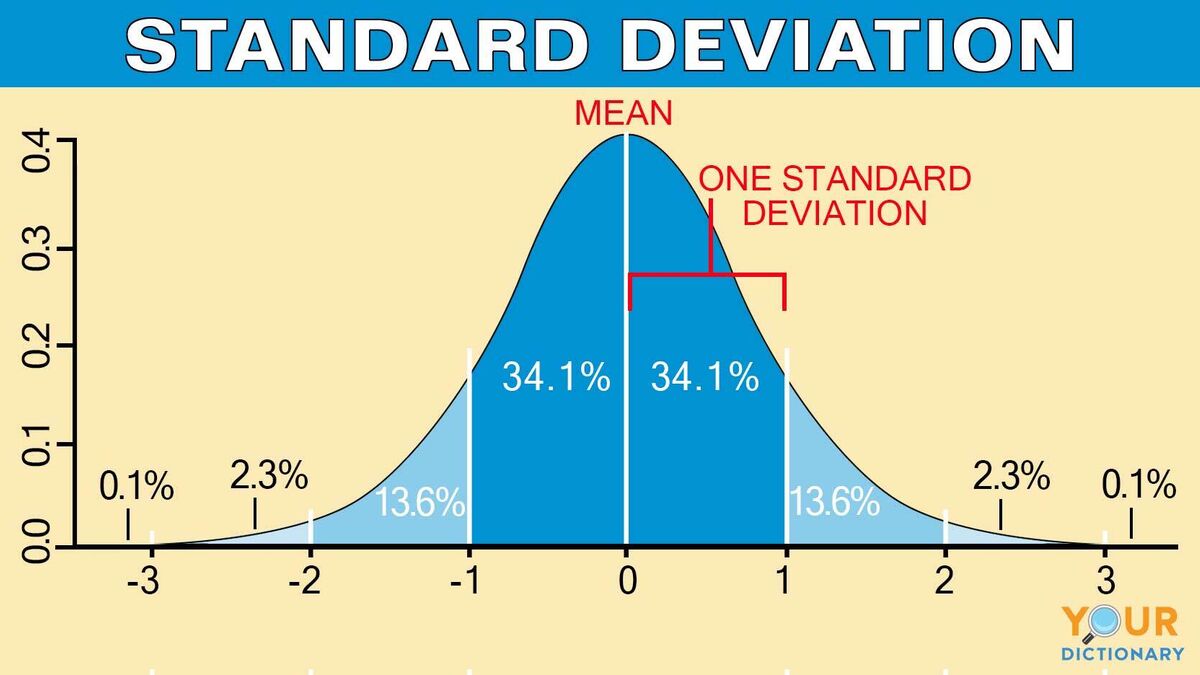
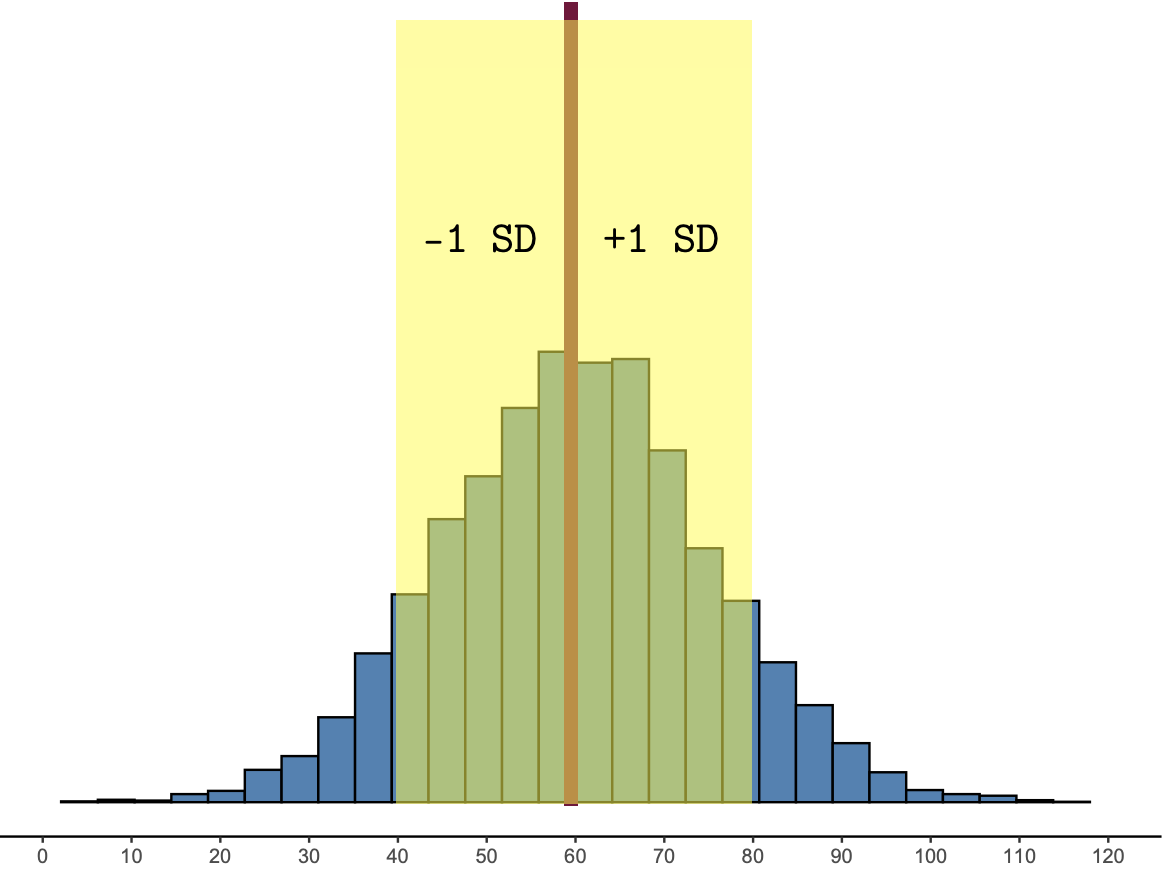
In the dynamic world of drone technology and innovation, precision, reliability, and data quality are paramount. Whether a drone is autonomously navigating complex environments, generating high-resolution maps, or collecting critical remote sensing data, the accuracy of its operations and outputs is constantly evaluated. A fundamental statistical concept that underpins much of this evaluation is the “standard deviation,” often abbreviated as “SD.” When we encounter “1 SD,” it refers to the range around the mean within which approximately 68.3% of the data points are expected to fall, assuming a normal distribution. In essence, it quantifies the typical amount of variation or dispersion from the average.
The Basics of Data Dispersion
Standard deviation serves as a powerful metric for understanding the spread of a dataset. Imagine a drone flying a precise straight line. Due to environmental factors, sensor limitations, and control system nuances, the drone’s actual path will inevitably deviate slightly from the ideal. If we plot numerous positional measurements over time, they won’t all land exactly on the target line. Some will be a little to the left, some a little to the right. The standard deviation tells us, on average, how far these individual measurements stray from the mean position. A small standard deviation indicates that data points are clustered tightly around the mean, signifying high precision. Conversely, a large standard deviation suggests that data points are widely spread, indicating lower precision and greater variability. For drone operators and developers, understanding this inherent variability is crucial for assessing system performance and the reliability of collected data.
Why Precision Matters for Drones
The applications of drones in modern industry demand an ever-increasing level of precision. From meticulously spraying crops in precision agriculture to constructing highly accurate 3D models of infrastructure, small errors can lead to significant consequences. For instance, in surveying, an error of a few centimeters in a building’s dimensions could lead to costly rework. In autonomous delivery, minor navigation discrepancies could lead to missed targets or even safety hazards. Therefore, knowing the standard deviation of a drone’s positional accuracy, sensor readings, or data outputs provides a quantifiable measure of its performance envelope. It helps set realistic expectations, define operational limits, and build more robust, reliable, and safe drone systems and applications. Without understanding and managing this variability, the advanced capabilities promised by drone technology cannot be fully realized or trusted.
Quantifying Accuracy in Geospatial Data and Mapping
One of the most significant contributions of drones to technological innovation is their ability to rapidly acquire and process geospatial data for mapping and surveying. The accuracy of these outputs is critical, and “1 SD” plays a central role in communicating and understanding this accuracy, particularly through metrics like Root Mean Square Error (RMSE).
Root Mean Square Error (RMSE) and its Relation to 1 SD
In geospatial applications, accuracy is frequently expressed using Root Mean Square Error (RMSE). RMSE is a commonly used measure of the differences between values predicted by a model or estimator and the values actually observed. For mapping, RMSE typically quantifies the average magnitude of the errors in the measured positions (X, Y, Z coordinates) relative to known ground control points or higher-accuracy reference data.
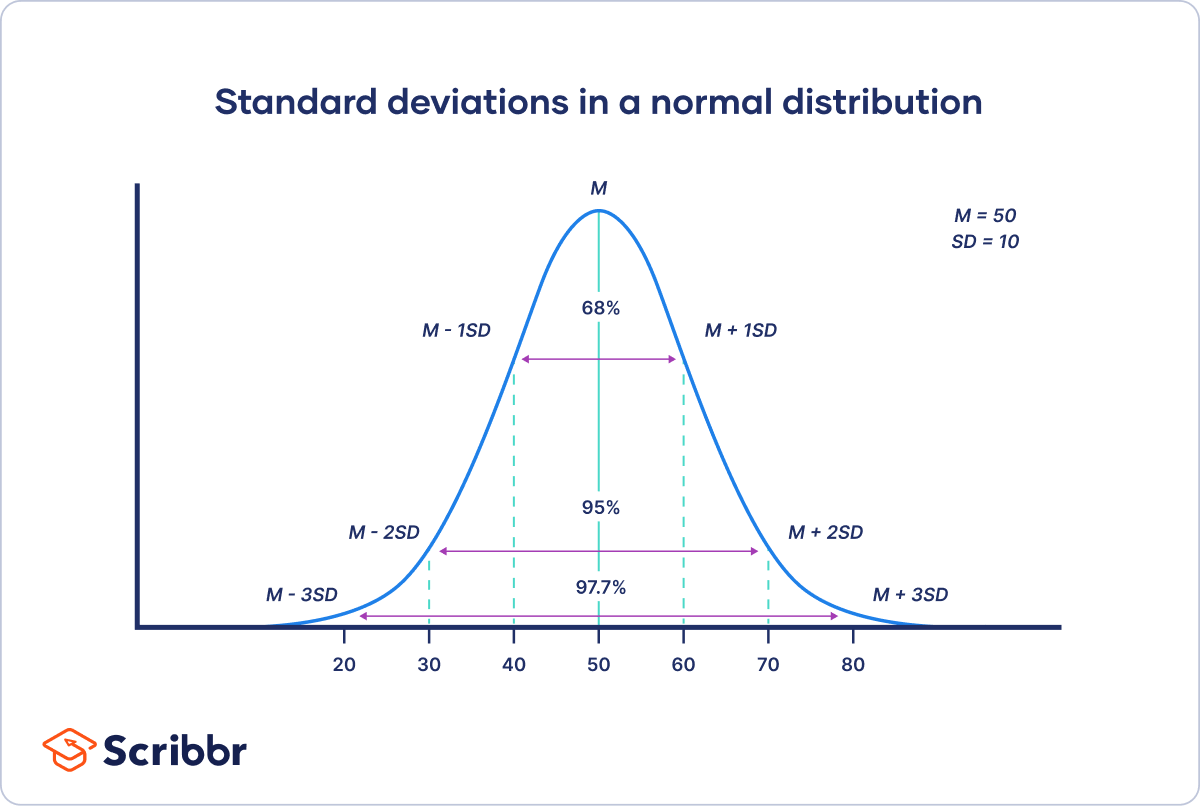
Crucially, RMSE is directly related to standard deviation. If the errors in a dataset follow a normal distribution, then the RMSE effectively represents the standard deviation of those errors. Thus, an RMSE of 10 cm in the horizontal plane means that the standard deviation of the horizontal errors is 10 cm. This implies that approximately 68.3% of the measured points in the map are expected to fall within 10 cm of their true horizontal positions. Similarly, an RMSE for vertical accuracy (Z-axis) of 5 cm means that 68.3% of the elevation points are within 5 cm of their true elevation. Understanding this link allows drone professionals to interpret accuracy specifications and product quality with statistical rigor. It moves beyond qualitative descriptions of “good” or “bad” accuracy to precise, quantifiable statements.
Ensuring Data Quality in Surveying and Photogrammetry
For professional surveying and photogrammetry, the concept of “1 SD” is fundamental to guaranteeing data quality. Before a drone map can be used for critical decision-making—whether for construction progress monitoring, land valuation, or environmental analysis—its positional accuracy must be rigorously validated. This often involves comparing a sample of points within the drone-generated map to independent, higher-accuracy ground control points (GCPs) or checkpoints.
The resulting error analysis will yield RMSE values for horizontal and vertical components. These RMSE values, representing the 1 SD of the errors, become the standard by which the map’s quality is judged. For example, a client might require a map with a horizontal RMSE of no more than 5 cm and a vertical RMSE of no more than 10 cm. Drone operators must plan their missions (flight altitude, overlap, camera settings, number and distribution of GCPs) to consistently achieve these 1 SD accuracy benchmarks. Failing to meet these standards means the data cannot be reliably used for its intended purpose, underscoring the vital importance of comprehending and controlling the standard deviation of mapping outputs.
Enhancing Reliability in Autonomous Flight and Navigation
Autonomous flight represents a pinnacle of drone innovation, enabling complex missions without constant human intervention. The reliability of these systems hinges on highly accurate and consistent navigation, where “1 SD” helps quantify and manage the inherent uncertainties.
Path Following and Positional Accuracy
For an autonomous drone to execute a predefined flight plan, it must maintain a high degree of positional accuracy and adhere closely to its intended path. Deviation from this path can be a significant concern, especially in sensitive environments or during operations requiring precise maneuvers. “1 SD” provides a statistical measure for this deviation. If an autonomous drone is designed to follow a path with a positional accuracy specified as “1 SD = 20 cm,” it means that under typical operating conditions, approximately 68.3% of its flight trajectory will remain within 20 cm of the planned path.
This metric is critical for assessing the performance of navigation algorithms, flight controllers, and GPS/GNSS systems. Developers constantly work to reduce this standard deviation through improved sensor fusion techniques, more sophisticated control algorithms, and robust error correction mechanisms. For mission planning, understanding the 1 SD of path following accuracy allows operators to assess risks, determine appropriate safety margins, and select the right drone platform for tasks demanding varying levels of precision—from broad area surveys to intricate inspection routes near structures.
Sensor Fusion and Error Margins
Modern drones rely heavily on sensor fusion—combining data from multiple sensors like GPS, Inertial Measurement Units (IMUs), barometers, and even vision systems—to achieve robust and accurate navigation. Each sensor has its own inherent noise and error characteristics, which can often be described by its standard deviation. GPS signals can be affected by atmospheric conditions or signal obstructions, leading to variations in positional readings. IMUs drift over time. Barometers can be influenced by local air pressure changes.
Effective sensor fusion algorithms are designed to intelligently weigh these different sensor inputs, leveraging their strengths and mitigating their weaknesses. The goal is to produce a combined navigational solution that has a lower standard deviation (i.e., higher accuracy and precision) than any single sensor alone. By understanding the 1 SD error margins of individual sensors and how these errors propagate through the fusion process, engineers can develop more sophisticated filters (like Kalman filters) that predict and correct for sensor drift and noise, thereby increasing the overall reliability and positional accuracy of the autonomous flight system. This iterative process of characterizing, modeling, and compensating for error is central to advancing the capabilities of autonomous drones.
The Role of 1 SD in Remote Sensing and Analytics
Beyond just mapping, drones are powerful platforms for remote sensing, collecting vast amounts of data across various spectral bands. This data is then processed for advanced analytics, where the concept of “1 SD” is crucial for interpreting variations and validating model outputs.
Interpreting Sensor Data Variation
Remote sensing involves capturing data about the Earth’s surface without physical contact, using sensors that measure reflected or emitted radiation. For example, multispectral sensors collect data in specific light bands to analyze crop health (NDVI), detect water stress, or identify land cover types. Thermal cameras measure heat signatures. In all these applications, the raw data collected by the sensor will exhibit some degree of variation.
This variation can stem from several sources: inherent sensor noise, atmospheric conditions, variations in target properties, or even slight changes in drone altitude and angle. “1 SD” helps to quantify this variation. For instance, if a drone’s multispectral sensor measures the reflectance of a specific crop field, and the NDVI readings for a seemingly uniform area show a standard deviation of 0.02, this tells analysts about the natural variability within the crop or the precision of the sensor. Understanding this 1 SD range is vital for differentiating true changes or anomalies in the environment from mere sensor noise or typical fluctuations. It allows for more accurate thresholding and classification in subsequent analytical processes.
Validating Models and Outputs
Remote sensing data is often used as input for complex analytical models—for example, predicting crop yield, assessing forest biomass, or modeling urban heat islands. The output of these models must be validated to ensure their reliability and applicability. “1 SD” provides a statistical backbone for this validation process.
When a model predicts a certain value (e.g., predicted crop yield for a specific plot), this prediction is compared against actual ground truth measurements. The differences between predicted and actual values constitute the model’s errors. The standard deviation of these errors (often expressed as RMSE) becomes a critical metric for validating the model’s performance. A model with a low RMSE (small 1 SD) for its predictions is considered highly accurate and robust. Conversely, a high RMSE indicates a model that is less reliable. This statistical validation, anchored by the concept of 1 SD, is essential for gaining confidence in the insights derived from drone-based remote sensing and for developing innovative, data-driven solutions in fields like precision agriculture, environmental monitoring, and disaster response.
Implications for Operators and Developers
The profound understanding of “1 SD” and its applications is not merely an academic exercise; it has tangible, practical implications for both drone operators in the field and the engineers developing the next generation of drone technology.
Setting Performance Benchmarks
For drone developers, “1 SD” serves as a critical benchmark for system performance. When designing new navigation systems, payloads, or autonomous flight algorithms, engineers strive to minimize the standard deviation of errors in positioning, sensor readings, and control outputs. For example, a new GPS module might be tested to ensure its horizontal positioning error (1 SD) is below a certain threshold. A more advanced stabilization system might be designed to reduce the 1 SD of altitude deviation in gusty winds. These quantitative targets drive innovation and ensure that new products meet the rigorous demands of professional applications. Without clearly defined 1 SD performance metrics, objective comparison and improvement are nearly impossible.
Making Informed Decisions
Drone operators, on the other hand, rely on “1 SD” specifications to make informed decisions about mission planning, data acquisition, and product delivery. Before embarking on a high-precision surveying project, an operator will review the drone’s and payload’s stated accuracy (often in terms of 1 SD or RMSE) to ensure it meets the client’s requirements. They will factor in environmental conditions that might increase the standard deviation of errors (e.g., flying under heavy tree cover affecting GPS signals).
Furthermore, when processing data, understanding the 1 SD of the output allows operators to set appropriate quality controls and communicate realistic accuracy expectations to clients. It helps in assessing the confidence level of a map, a 3D model, or an analytical result. Ultimately, the comprehensive understanding and application of “1 SD” enable the drone industry to push the boundaries of technological innovation, ensuring that these advanced aerial platforms deliver consistent, reliable, and trustworthy results for an ever-expanding array of applications.