
Magnetic North, a fundamental concept often taken for granted in daily life, holds profound significance in the realm of flight technology, particularly for modern Unmanned Aerial Vehicles (UAVs). Far from being a mere point on a compass, it represents a dynamic and invisible force essential for precise navigation, stable flight, and the successful execution of complex aerial missions. Understanding magnetic north is not just about knowing a direction; it is about grasping a critical input for the advanced sensor systems that power today’s sophisticated drones.
The Earth’s Geomagnetic Field and Its Significance for Flight
The Earth behaves like a giant magnet, generating a magnetic field that extends from its interior into space. This geomagnetic field is crucial for protecting our planet from solar winds, but more pertinently for flight technology, it provides a pervasive, naturally occurring reference frame for orientation. Unlike visual cues or radio signals, the magnetic field is always present, offering a continuous source of directional information.

True North vs. Magnetic North
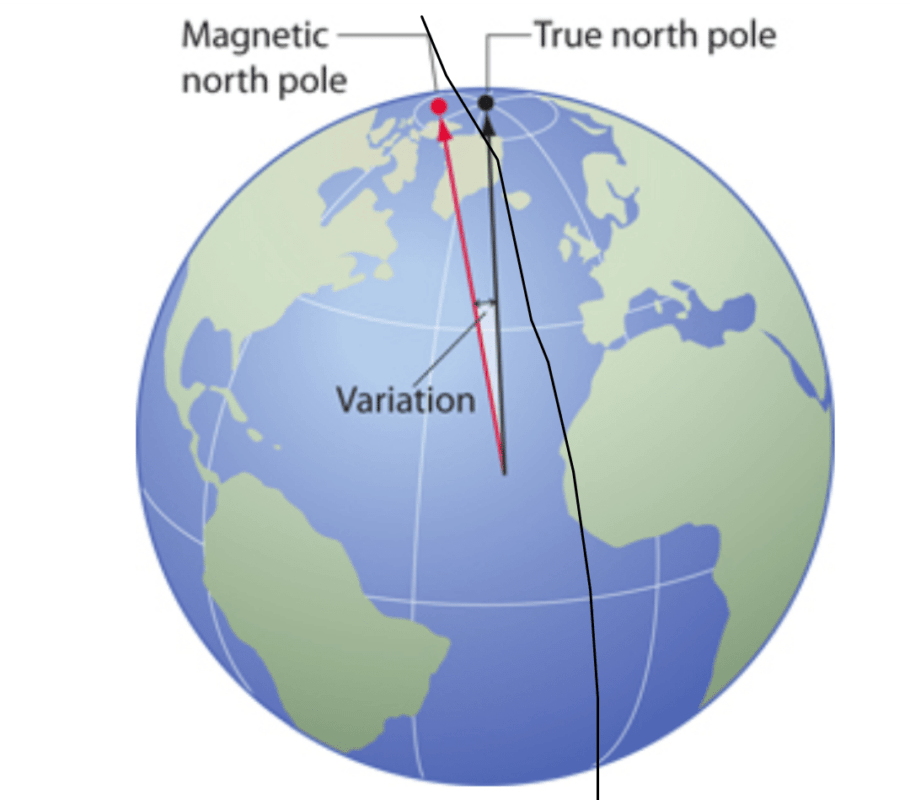
For navigators, the distinction between True North and Magnetic North is paramount. True North refers to the geographical North Pole, the fixed point around which the Earth rotates. It is a constant, unmoving reference for maps and global positioning systems (GPS). Magnetic North, conversely, is the point on the Earth’s surface where the planet’s magnetic field lines converge vertically downwards. Crucially, the Magnetic North Pole is not stationary; it drifts over time due to complex processes within the Earth’s molten outer core.
This distinction is vital for flight technology. While GPS provides global coordinates relative to True North, aircraft and drones often rely on onboard compasses—magnetometers—that detect the Earth’s magnetic field and, therefore, point towards Magnetic North. Without accounting for the difference, navigation systems would introduce significant errors, leading to incorrect headings and deviations from intended flight paths.
Magnetic Declination
The angular difference between True North and Magnetic North at any given location is known as magnetic declination. This declination varies significantly across the globe and changes over time. For example, in some regions, Magnetic North might be several degrees east or west of True North. For UAVs engaged in precision mapping, surveying, or autonomous delivery, accurately compensating for magnetic declination is non-negotiable.
Modern flight control systems integrate sophisticated algorithms that incorporate up-to-date magnetic declination data. This data, often stored in lookup tables or obtained from global geomagnetic models (like the World Magnetic Model, WMM), is used to convert the raw magnetic heading detected by the drone’s magnetometer into a True North heading. This conversion is a critical step in ensuring that the drone accurately follows pre-programmed flight plans and maintains correct orientation relative to a fixed geographic reference frame, aligning with GPS data and desired mission parameters. Without this compensation, a drone programmed to fly “north” would consistently drift off course relative to its actual geographical target.
How Drones Utilize Magnetic North for Navigation
The utilization of magnetic north in drones is a cornerstone of their sophisticated navigation and stabilization systems. It provides a reliable directional input that complements other sensors, creating a robust framework for autonomous flight.
The Role of Magnetometers (Electronic Compasses)
At the heart of a drone’s ability to sense magnetic north is the magnetometer, an electronic compass. Magnetometers are typically microelectromechanical systems (MEMS) sensors integrated into the drone’s Inertial Measurement Unit (IMU) or as a separate component. These tiny devices measure the strength and direction of the Earth’s magnetic field in three dimensions.
By detecting the orientation of the magnetic field lines, the magnetometer can determine the drone’s heading relative to Magnetic North. This real-time heading information is continuously fed into the drone’s flight controller. Unlike traditional magnetic compasses which use a physical needle, electronic magnetometers provide digital data that can be precisely integrated into complex computational models. They are crucial for tasks such as maintaining a consistent flight direction, executing turns with accurate angles, and holding specific orientations during stationary flight or hovering. Without magnetometers, a drone would struggle significantly to maintain a stable heading, particularly in situations where GPS signals might be momentarily lost or corrupted.

Enhancing Stabilization and Orientation
Beyond basic navigation, magnetic north plays a vital role in a drone’s stabilization and attitude estimation. A drone’s flight controller requires an accurate understanding of its orientation (pitch, roll, and yaw) in space to maintain stability and execute controlled movements. While accelerometers and gyroscopes provide data on angular velocity and gravitational forces (for pitch and roll), the magnetometer is indispensable for determining yaw, or the heading around the vertical axis.
In sensor fusion algorithms, the magnetometer’s heading data is combined with information from gyroscopes and accelerometers. Gyroscopes excel at detecting rapid angular changes but suffer from drift over time, meaning their reported orientation can slowly become inaccurate. Magnetometers, while susceptible to magnetic interference, provide an absolute heading reference that can correct this drift, particularly for the yaw axis. This fusion creates a more stable, accurate, and drift-free estimation of the drone’s attitude. For a drone performing aerial photography, precision mapping, or simply hovering steadily in windy conditions, this accurate attitude estimation, heavily reliant on magnetic north, is critical for smooth footage, accurate data capture, and reliable flight performance.
Challenges and Compensations in Drone Flight
Despite its fundamental importance, relying on magnetic north for drone navigation comes with inherent challenges that flight technology engineers must address.
Magnetic Interference
The primary challenge for magnetometers in drones is magnetic interference. Drones are densely packed with electronic components—motors, ESCs (Electronic Speed Controllers), power distribution boards, and batteries—all of which generate their own electromagnetic fields. These localized fields can distort the Earth’s relatively weak magnetic field, causing the magnetometer to report an erroneous heading. This is often referred to as “magnetic bias” or “hard iron interference.”
Even external factors like nearby power lines, metal structures, or certain geological formations can introduce “soft iron interference,” subtly altering the magnetic field detected by the sensor. If left uncorrected, such interference leads to unstable flight, unpredictable yaw movements, and significant errors in navigation. For this reason, magnetometers are often placed on extended masts or arms, away from the drone’s main body, to minimize interference from internal components. However, even with optimal placement, residual interference remains a factor that demands sophisticated compensation techniques.
Calibration and Sensor Fusion
To mitigate the effects of magnetic interference and ensure accurate heading data, magnetometers require regular calibration. This process typically involves rotating the drone through all axes (often a figure-eight motion) so that the flight controller can map out the drone’s internal magnetic distortions and create a compensation model. This calibration data allows the drone to subtract its own magnetic “noise” from the Earth’s magnetic field signal. Proper calibration is a critical pre-flight step for any drone pilot aiming for precise and stable flight.
Furthermore, flight technology employs advanced sensor fusion techniques to enhance the reliability of heading information. Data from the magnetometer is fused with readings from other sensors within the IMU, such as gyroscopes (for angular velocity) and accelerometers (for linear acceleration and gravity). Crucially, GPS data provides an independent velocity vector which, over time, can also be used to estimate heading. By combining these diverse sensor inputs using Kalman filters or similar algorithms, the flight controller can cross-reference data, identify inconsistencies, and derive a more robust and accurate estimate of the drone’s orientation and position. If the magnetometer experiences temporary interference, the system can temporarily rely more heavily on gyroscope and GPS data, gracefully degrading performance rather than failing outright. This multi-sensor approach ensures that even if one sensor provides faulty data, the overall navigation system remains resilient and reliable.
Future of Magnetic North in Autonomous Flight
As drone technology continues to evolve towards increasing autonomy, the role of magnetic north, and the sensors that detect it, remains as crucial as ever. While advanced techniques like visual odometry, lidar, and increasingly sophisticated GPS systems (e.g., RTK/PPK) provide highly accurate positional data, the magnetometer offers a unique, passive, and pervasive directional reference that is independent of external signals or environmental lighting conditions.
For autonomous flight, particularly in complex or GPS-denied environments, the robustness of a drone’s heading estimation is paramount. Whether a drone is navigating through urban canyons where GPS signals can be blocked, performing intricate maneuvers for industrial inspection, or undertaking long-range mapping missions, maintaining an accurate sense of direction derived from the Earth’s magnetic field is a baseline requirement. Future innovations in magnetometer technology might include more robust sensors less susceptible to internal interference, or even arrays of magnetometers providing a more comprehensive magnetic field map around the drone.
Ultimately, magnetic north serves as an enduring pillar of flight technology. It grounds sophisticated autonomous systems in a fundamental geophysical reality, ensuring that even the most advanced UAVs can reliably orient themselves and execute their missions with precision and stability. The ongoing development of sensors, calibration methodologies, and sensor fusion algorithms will continue to refine how drones harness this invisible force for the benefit of aerial navigation and performance.