
The Algorithmic Imperative: Deciphering Environmental Cues for Autonomous Operations
The question of “what whether” in advanced drone technology delves into the intricate decision-making processes that underpin truly autonomous flight and intelligent task execution. It addresses the fundamental challenge of how an unmanned aerial vehicle (UAV) perceives its dynamic environment, interprets countless data points, and then determines “what” action to take, “whether” specific conditions are met or not. At its core, this involves sophisticated sensor fusion, real-time data processing, and advanced artificial intelligence (AI) algorithms that enable drones to move beyond mere pre-programmed flight paths into realms of adaptive, intelligent behavior.

The ability for a drone to understand its surroundings is paramount. This isn’t just about avoiding static obstacles but comprehending a fluid, unpredictable world filled with changing light, moving objects, and varying atmospheric conditions. The success of autonomous missions, from intricate infrastructure inspections to complex search-and-rescue operations, hinges on the drone’s capacity to build a robust, dynamic model of its operational space. This model then serves as the foundation upon which all subsequent “what whether” decisions are made, dictating everything from trajectory adjustments to mission critical pivots.
Sensor Fusion as the Foundation of Perception
For a drone to effectively answer “what whether,” it must first gather comprehensive data about its environment. This is achieved through an array of sophisticated sensors, each providing a unique perspective. LiDAR (Light Detection and Ranging) systems offer precise 3D mapping capabilities, measuring distances by emitting pulsed laser light. Radar, particularly useful in adverse weather conditions where optical sensors struggle, detects objects by emitting radio waves. Visual cameras, ranging from high-resolution RGB to thermal and multispectral, capture detailed imagery that AI can process for object recognition, classification, and change detection.
The true power, however, lies not in individual sensors but in their harmonious integration through sensor fusion. This process combines data from multiple disparate sources to produce a more accurate, reliable, and comprehensive understanding of the environment than any single sensor could provide alone. AI algorithms play a critical role here, taking raw, often noisy, data streams from LiDAR, radar, IMUs (Inertial Measurement Units), GPS, and vision systems, then synthesizing them into a coherent, real-time environmental map. For instance, LiDAR might provide depth, while a vision system identifies object types and their semantic meaning, and an IMU tracks the drone’s own motion to compensate for movement artifacts. This fused data forms the drone’s “situational awareness,” enabling it to determine “what” is around it, and subsequently “whether” a certain flight path is clear or if an identified object requires a specific response.
Predictive Analytics and Dynamic Decision-Making
Beyond simply understanding the current state, truly intelligent drones engage in predictive analytics. This involves using current and historical data to forecast future events or conditions, allowing the drone to anticipate changes and make proactive decisions rather than merely reacting to immediate threats. AI models, often leveraging deep learning techniques, analyze patterns in sensor data to predict the movement of dynamic obstacles, the onset of environmental changes, or even the optimal time to capture specific data points for mapping or inspection tasks.
For example, a drone tasked with monitoring wildlife might use predictive analytics to anticipate animal movement patterns based on time of day, season, and terrain, optimizing its flight path to maximize observation opportunities while minimizing disturbance. In obstacle avoidance, this translates from merely swerving to prevent a collision to adjusting trajectory minutes in advance to smoothly navigate an evolving airspace. This proactive approach is central to the “what whether” paradigm, allowing drones to determine “what” actions will lead to the most successful outcome, “whether” unforeseen circumstances arise, by preparing for them beforehand. Such dynamic decision-making transforms drones from automated flying platforms into truly autonomous agents, capable of complex problem-solving in unpredictable environments.
Navigating the Elements: Integrating Weather Intelligence into Autonomous Missions
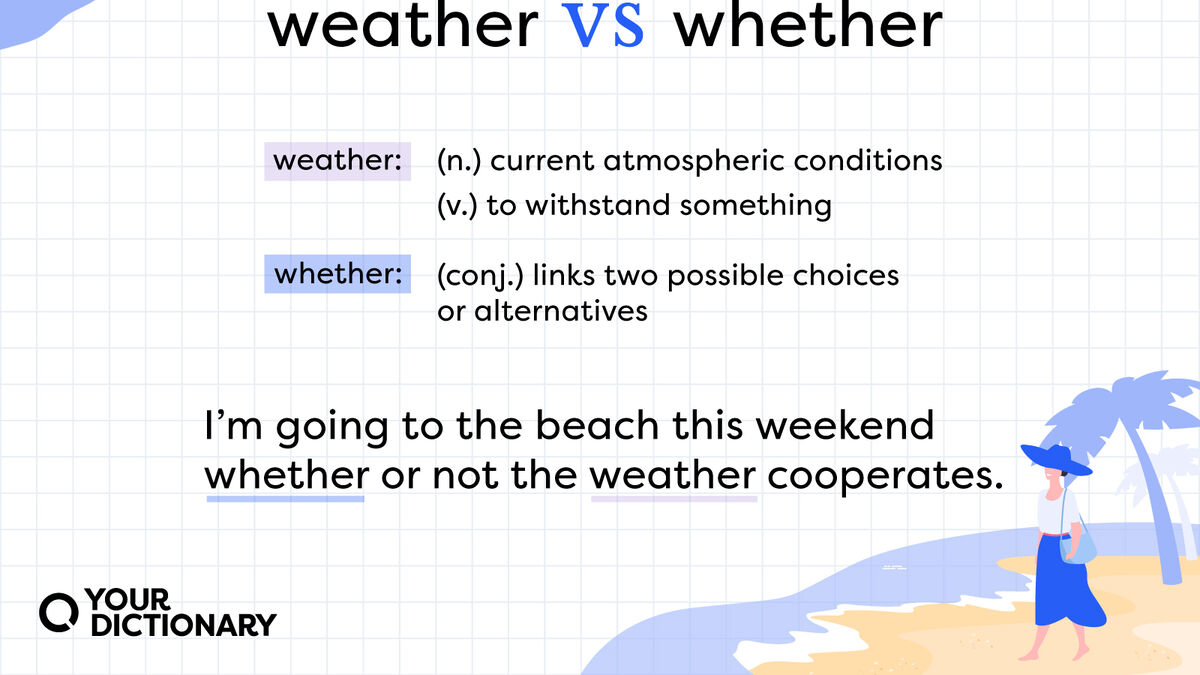
A critical facet of the “what whether” question for autonomous drones, and indeed a subtle play on words, concerns the integration of “weather” intelligence into mission planning and execution. Environmental factors, particularly meteorological conditions, significantly influence a drone’s operational capabilities, safety margins, and the quality of data collected. For autonomous systems to truly excel, they must not only perceive physical obstacles but also understand and adapt to the invisible forces of the atmosphere.
The impact of weather extends beyond mere comfort; it directly affects aerodynamics, battery performance, sensor efficacy, and communication reliability. High winds can destabilize a drone, demanding more power for stability and reducing flight time. Rain can obscure optical sensors, affect signal integrity, and potentially damage electronic components. Extreme temperatures impact battery longevity and motor efficiency. Consequently, an intelligent drone must constantly evaluate “what” the weather conditions are and “whether” they permit, compromise, or outright prohibit a given mission segment.
Real-time Weather Integration and Predictive Modeling
To address these challenges, advanced autonomous drones incorporate sophisticated weather integration systems. This often involves a multi-pronged approach: onboard atmospheric sensors (anemometers, barometers, thermometers, hygrometers) provide localized, real-time data, while external data feeds (e.g., METAR, satellite imagery, numerical weather prediction models) offer broader regional context and forecasts.
AI algorithms then fuse this disparate meteorological data. They don’t just report current conditions; they build predictive models specific to the drone’s operational micro-climate. For instance, a drone flying through a mountain valley might experience highly localized wind shear that wouldn’t be captured by regional forecasts. AI can learn to anticipate these micro-climates based on terrain, time of day, and broader weather patterns, using onboard sensor data to fine-tune its predictions. This allows the drone to understand “what” kind of wind conditions it might encounter at a specific altitude or near a particular structure, and “whether” those conditions fall within its safe operating envelope. Furthermore, AI can predict the impact of precipitation on sensor visibility, the likelihood of icing at certain altitudes, or the potential for electromagnetic interference from lightning, offering a comprehensive environmental risk assessment.
Adaptive Flight Planning and Contingency Protocols
Armed with a deep understanding of current and forecasted weather, autonomous drones engage in adaptive flight planning. This means that the flight path isn’t static but is dynamically adjusted in real-time based on evolving meteorological conditions. If strong headwind is detected, the drone might automatically select a lower altitude or an alternative, more sheltered route to conserve battery and maintain stability. If precipitation begins, it might switch to a radar-based obstacle avoidance system if available, or prioritize a faster return-to-home path.
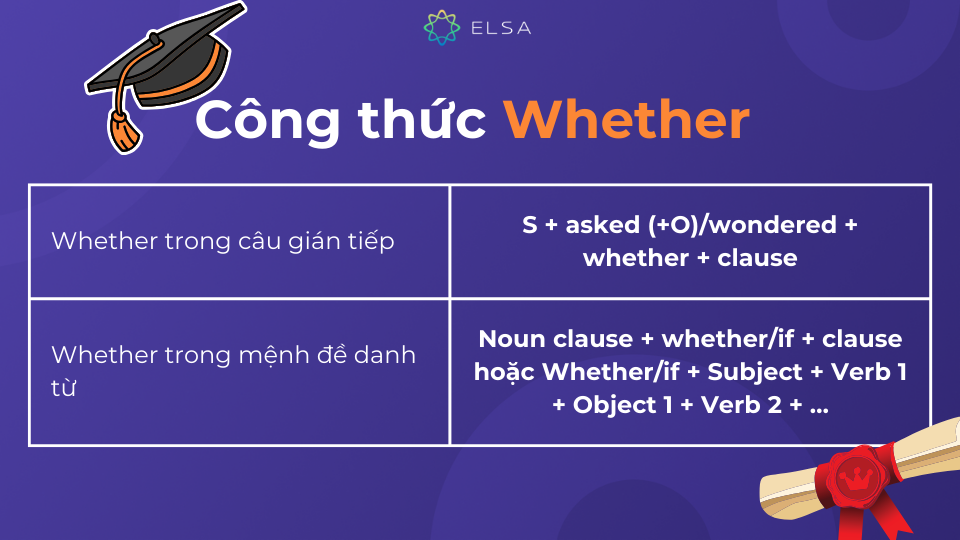
Beyond simple adjustments, autonomous systems develop robust contingency protocols based on weather thresholds. These protocols define “what” actions to take “whether” specific critical weather parameters are exceeded. For instance, if wind gusts surpass a pre-defined safety limit, the drone might initiate an immediate landing at the nearest safe zone or trigger an emergency return-to-launch sequence. If visibility drops below a certain threshold due to fog or heavy rain, an inspection mission might be automatically paused or aborted to prevent collision or ensure data quality. This level of weather-aware autonomy significantly enhances operational safety and mission reliability, moving drones further into applications that demand resilience against environmental variability.
The “What If”: AI’s Role in Counterfactual Reasoning and Mission Optimization
The pinnacle of autonomous drone intelligence lies in its capacity for “what if” scenarios and counterfactual reasoning. This is where the “what whether” paradigm truly shines, as drones move beyond merely reacting to the present to proactively evaluating potential futures and optimizing their actions based on simulated outcomes. This advanced capability, powered by sophisticated AI, allows drones to weigh multiple courses of action, predict their consequences, and select the most advantageous or safest path forward even before a situation fully develops.
This foresight is crucial for complex missions where the environment is uncertain, resources are finite, or safety margins are narrow. Instead of following a rigid set of rules, the drone’s AI evaluates hypotheses: “what if I take this route, whether the wind shifts?”; “what if I use this sensor configuration, whether the lighting changes?”; “what if this dynamic obstacle moves in an unexpected direction, whether my current speed allows avoidance?” This iterative process of simulation and evaluation is fundamental to achieving truly intelligent and resilient autonomous operations.
Scenario Planning and Risk Assessment
Autonomous drones equipped with advanced AI can perform rapid scenario planning. For any given objective, the AI can generate multiple potential strategies or flight paths, each with a different set of associated risks and rewards. Using internal models of physics, environmental dynamics, and operational constraints, the system simulates the outcome of each scenario. This allows the drone to calculate the probability of success, the estimated resource consumption (e.g., battery life), the potential for adverse events (e.g., collision, data corruption), and the expected quality of the mission output.
For example, in a mapping mission over challenging terrain, the AI might consider several flight altitudes and speeds. One path might offer higher resolution imagery but risks encountering stronger winds or obstacles. Another might be safer but yield lower data fidelity. The AI then weighs these trade-offs, making an informed decision about “what” flight plan to execute, “whether” the primary objective is maximum data quality, safety, or efficiency. This involves complex optimization algorithms that seek to maximize a defined utility function, taking into account all relevant parameters. Risk assessment is inherently integrated, as the AI assigns probabilities to different failure modes and adjusts its strategy to minimize the most critical risks, even if it means slightly compromising on a secondary objective.
Autonomous Learning and Evolving Intelligence
A key enabler of counterfactual reasoning and mission optimization is autonomous learning. Drones are no longer just executing pre-programmed tasks; they are continuously learning from their experiences. Through techniques like reinforcement learning, the AI agents within the drone can observe the outcomes of their past decisions, evaluate whether those outcomes were successful, and adjust their internal models and decision-making policies accordingly.
Every flight, every data point collected, and every encountered environmental condition becomes a learning opportunity. If a particular flight strategy consistently leads to higher battery drain in certain wind conditions, the AI will learn to avoid that strategy in similar future scenarios. If a specific sensor configuration proves more effective for identifying certain object types under particular lighting, that knowledge is integrated. This evolving intelligence allows the drone to refine its “what whether” decision logic over time, becoming more proficient, more efficient, and more robust with each successive operation. This continuous learning cycle is paramount for drones operating in dynamic, unstructured environments, as it allows them to adapt to novel situations that were not explicitly programmed or anticipated by human engineers.
Beyond Reactive: Proactive Autonomy and the Future of Drone Intelligence
The trajectory of drone innovation points towards increasingly proactive autonomy, where “what whether” decisions are made not just for single-entity operations but for entire fleets collaborating in complex environments. This future emphasizes not just individual drone intelligence but collective, distributed intelligence that can tackle challenges far beyond the scope of a single unit.
Collaborative Autonomy and Swarm Intelligence
The ultimate expression of proactive autonomy is seen in collaborative drone systems, often referred to as swarm intelligence. Here, multiple drones work in concert, sharing information, coordinating their movements, and collectively making “what whether” decisions to achieve a common goal. Instead of one drone asking “what whether” to do, an entire swarm asks “what whether we should do.”
Imagine a scenario where a large area needs to be mapped after a natural disaster. A swarm of drones can dynamically divide the area, allocate sub-tasks based on individual drone capabilities (e.g., thermal imaging drone for hotspots, LiDAR drone for structural damage), and adjust their coverage patterns in real-time as new information becomes available or as environmental conditions change. If one drone detects a severe wind gust, it communicates this to its peers, allowing the entire swarm to adjust their flight paths proactively. This collective decision-making, where each drone contributes its local “what whether” assessment to a global understanding, leads to unparalleled efficiency, redundancy, and scalability. This isn’t merely about multiple drones flying near each other; it’s about a decentralized network of intelligent agents constantly optimizing their collective behavior.
Human-AI Collaboration: Defining the Autonomy Threshold
As drone intelligence evolves, the relationship between human operators and autonomous systems is also transforming. The “what whether” question increasingly involves a collaborative decision-making process. Rather than replacing human judgment entirely, advanced AI systems are designed to augment it, providing operators with actionable insights and intelligent recommendations.
In many critical applications, human oversight remains essential. The AI might determine “what” the optimal flight path is and “whether” certain risks are acceptable, but it then presents these options and its reasoning to a human operator for final approval or intervention. This defines an autonomy threshold, where the system is capable of executing complex tasks independently but allows for human input at crucial decision points. For instance, in an emergency response scenario, an autonomous drone might identify a collapse zone and suggest the safest entry points, leaving the ultimate decision to human first responders. This symbiotic relationship ensures that the power of autonomous decision-making is leveraged for efficiency and safety, while accountability and ethical considerations remain firmly in human hands. The future of drone intelligence lies in this elegant dance between advanced AI making proactive “what whether” evaluations and human operators providing strategic guidance and ultimate authority.