
The central nervous system of any advanced aerial platform, analogous to a biological spinal cord, represents the intricate network responsible for transmitting critical data and control signals throughout the drone’s operational architecture. Unlike a biological entity with a definitive anatomical termination, the “end” of this digital spinal cord in Unmanned Aerial Vehicles (UAVs) is not a single, fixed anatomical point, but rather a series of sophisticated integration layers and functional thresholds. Understanding these “vertebral levels” is paramount for optimizing flight stability, navigation precision, and overall system reliability. Modern flight technology, driven by innovations in microprocessors, sensor fusion, and real-time operating systems, defines these crucial junctures where core flight control diverges into specialized subsystem management, impacting navigation and obstacle avoidance.
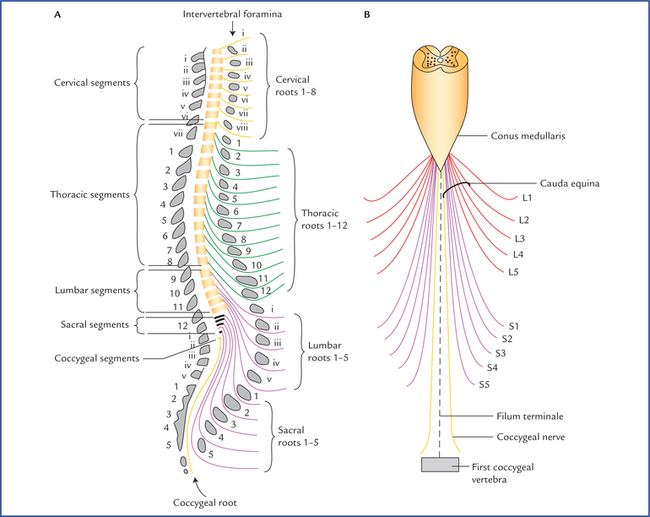
The Core Data Pathways: A Drone’s Central Nervous System
The “spinal cord” of a contemporary UAV is predominantly embodied by its flight controller (FC) and the high-speed data buses that connect it to various peripheral components. This digital backbone processes inputs from an array of sensors—including accelerometers, gyroscopes, magnetometers, barometers, and GPS modules—and translates these into precise motor commands and control surface adjustments. The integrity and latency of this data transmission are critical. A breakdown or delay at any point in this “spinal cord” can lead to catastrophic failure, highlighting the need for robust communication protocols. In advanced systems, this also encompasses control loops for stabilization, where algorithms compare desired flight parameters with sensor readings, sending immediate corrective signals to the propulsion system.
Flight Controllers: The Brain and Backbone Hub
The flight controller acts as the central processing unit, the “brain” where primary decision-making and data aggregation occur. It’s equipped with microcontrollers (MCUs) that execute the flight control firmware (e.g., ArduPilot, Betaflight, PX4). These MCUs process millions of instructions per second, managing tasks such as attitude estimation, position holding, and waypoint navigation. The physical layout of the FC board, with its numerous pins and connectors, can be considered the most centralized “vertebral level” where all major data streams converge and emanate. From a design perspective, the architecture of these controllers dictates the maximum throughput and resilience of the system, fundamentally defining the upper limits of drone performance and reliability.
Sensor Integration: The Afferent Information Streams
Sensors are the eyes, ears, and proprioceptors of a drone, feeding constant streams of environmental and self-state data into the central “spinal cord.” GPS modules provide positional awareness, while Inertial Measurement Units (IMUs) offer critical attitude and motion data. Barometers contribute altitude information, and ultrasonic or lidar sensors enable precise height holding and obstacle detection. The “vertebral levels” in this context are the physical and logical interfaces where these diverse data types are sampled, digitized, and integrated into a unified data model within the flight controller. This fusion process is a cornerstone of robust navigation and stabilization. High-frequency sampling rates and synchronized data acquisition are vital to ensure the flight controller receives the most accurate and up-to-date representation of the drone’s state, directly influencing stable flight and complex maneuvers.
Architectural Levels and Functional Divergence
The concept of “vertebral levels” within a drone’s flight technology architecture extends beyond mere physical connections to encompass logical layers of control and processing. As the core flight control “spinal cord” extends, it branches and specializes, much like the nervous system extending into peripheral nerves. These divergences mark points where generalized control signals are translated into specific actions, or where data is routed to specialized subsystems.
Hardware Layer Interconnectivity
At the hardware level, these “vertebral levels” are manifest in the various communication buses and protocols that link different components. I2C, SPI, UART, and CAN bus are common examples, each serving specific purposes in connecting sensors, ESCs (Electronic Speed Controllers), GPS modules, and other peripherals to the flight controller. The “end” of the spinal cord in a direct control sense might be considered the point where these digital signals are converted into analog or pulse-width modulation (PWM) signals, directly driving motors or servos. This conversion is a critical “vertebral level” as it represents the final command transmission before physical actuation, directly impacting the drone’s response to control inputs. The robustness of these interfaces, including signal integrity and EMI shielding, directly affects system reliability.
Software Abstraction and Control Flow

Logically, the “vertebral levels” also correspond to layers of software abstraction within the flight control firmware. The lowest “level” involves direct hardware drivers for sensors and actuators. Above this lies the attitude and position estimation algorithms, followed by the control loops for stabilization and navigation. Higher “levels” involve mission planning, intelligent autonomy features, and obstacle avoidance routines. The “spinal cord” effectively “ends” its direct, high-frequency control within the core PID (Proportional-Integral-Derivative) loops, responsible for immediate aircraft stabilization. Beyond this, control flow diverges into more strategic, slower-loop decision-making processes, operating at a higher level of abstraction and typically involving complex environmental interpretation rather than direct motor control. This hierarchical structure allows for modular development and debugging, ensuring critical flight stabilization is decoupled from higher-level cognitive tasks.
Termination Points and Actuation Integration
The ultimate “end” of the drone’s “spinal cord” in a functional sense is where its control signals translate into physical action, directly manipulating the drone’s environment or its own state. These are the effector points where the digital commands become mechanical force.
Actuator Integration: The Efferent Command Pathways
Electronic Speed Controllers (ESCs) and motors represent a crucial “terminal vertebral level.” The flight controller sends PWM or digital signals (e.g., DShot) to the ESCs, which then regulate the power delivered to the brushless motors. This is where the abstract commands of stability and navigation are converted into thrust, controlling the drone’s movement in three-dimensional space. The precision and responsiveness of this link are paramount. Any desynchronization or delay between the FC and the ESCs can lead to instability or loss of control. Therefore, seamless integration and high-speed communication at this “end” of the spinal cord are vital for agile and stable flight characteristics. Modern ESCs with integrated microcontrollers themselves contain sophisticated control loops, effectively extending the “spinal cord” to the propeller tips, constantly adjusting motor speed based on feedback and commands.
Data Telemetry and External Systems
Another “terminal vertebral level” is where the drone’s internal operational data is transmitted externally. This includes telemetry links that send flight parameters (altitude, speed, battery voltage, GPS coordinates) back to a ground control station (GCS) or remote controller. For advanced applications like mapping, remote sensing, or aerial filmmaking, the “spinal cord” also connects to payload controllers, triggering cameras, lidar units, or other specialized sensors. While these connections do not directly control flight, they represent the informational “end” of the drone’s internal processes, providing valuable operational feedback and enabling mission execution. The resilience of these external data links, often employing robust radio frequency technologies, ensures critical information can be retrieved even in challenging environments, complementing internal flight control mechanisms.
Ensuring Resilience and Adaptability at the “End”
The precise definition and robust implementation of these “vertebral levels” are fundamental to developing resilient and adaptable flight technology. As drones are increasingly deployed in complex and demanding environments, the ability to withstand failures and maintain operational integrity becomes paramount.
System Redundancy and Integrity
At various “vertebral levels,” redundancy can be implemented to enhance reliability. This might involve dual GPS modules, multiple IMUs, or redundant flight controllers that can take over in case of primary system failure. Understanding where the “spinal cord” effectively “ends” allows engineers to identify critical single points of failure and design around them. For instance, the transition from digital control signals to analog motor actuation is a crucial juncture where electrical interference or component failure could be catastrophic, necessitating careful shielding and robust power management. Ensuring signal integrity across all “vertebral levels” is a continuous engineering challenge, involving sophisticated electrical design and rigorous testing.
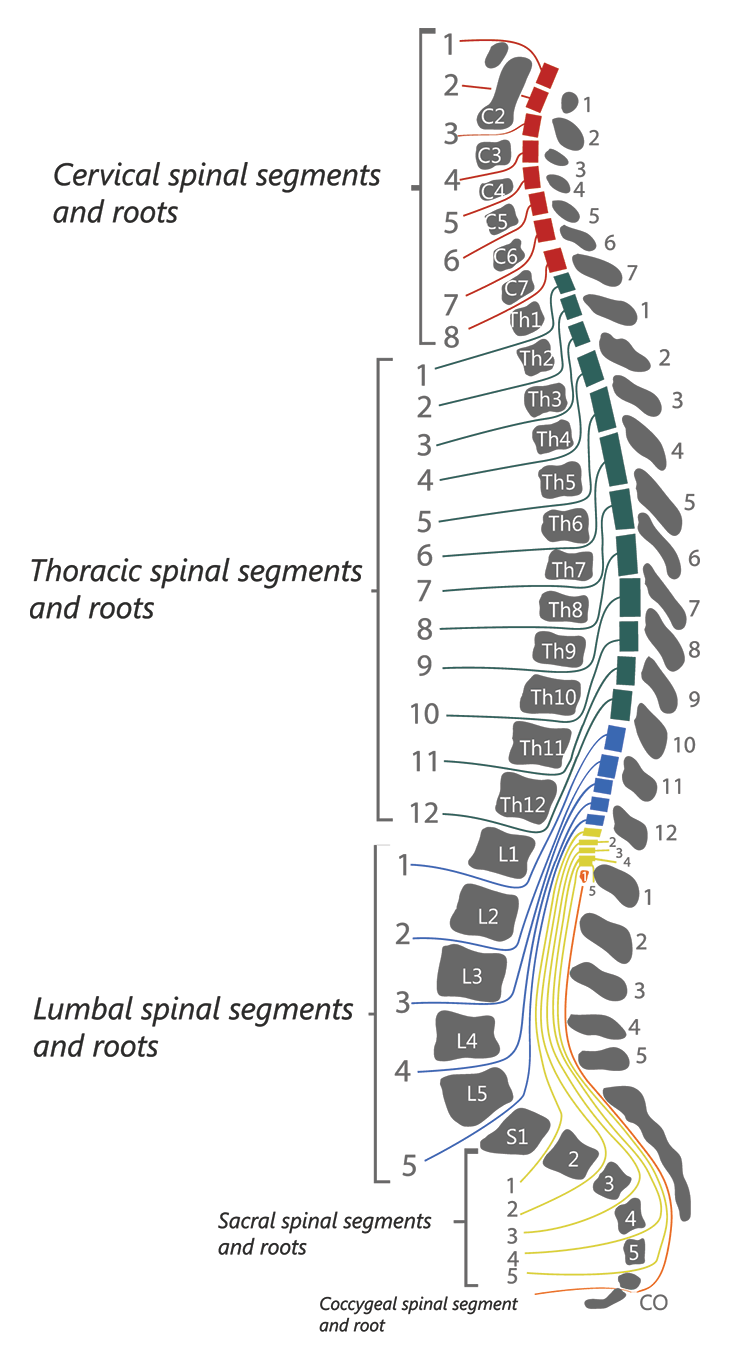
Future Architectures and Distributed Intelligence
As flight technology evolves, the concept of a singular “spinal cord” may transition towards a more distributed intelligence model. Future drone architectures might feature multiple, semi-autonomous processing units closer to the sensors and actuators, reducing the need for a single, long central data bus. This decentralization would mean the “spinal cord” effectively “ends” at many points, with local intelligence handling micro-tasks, and a higher-level network coordinating overall behavior. This paradigm shift holds promise for increased resilience, faster response times, and greater adaptability, especially in swarms or highly autonomous missions where decisions are made at the edge. Continuous innovation in processing power, miniaturization, and communication protocols is pushing the boundaries of what these “vertebral levels” can achieve, promising more sophisticated and reliable aerial platforms.