
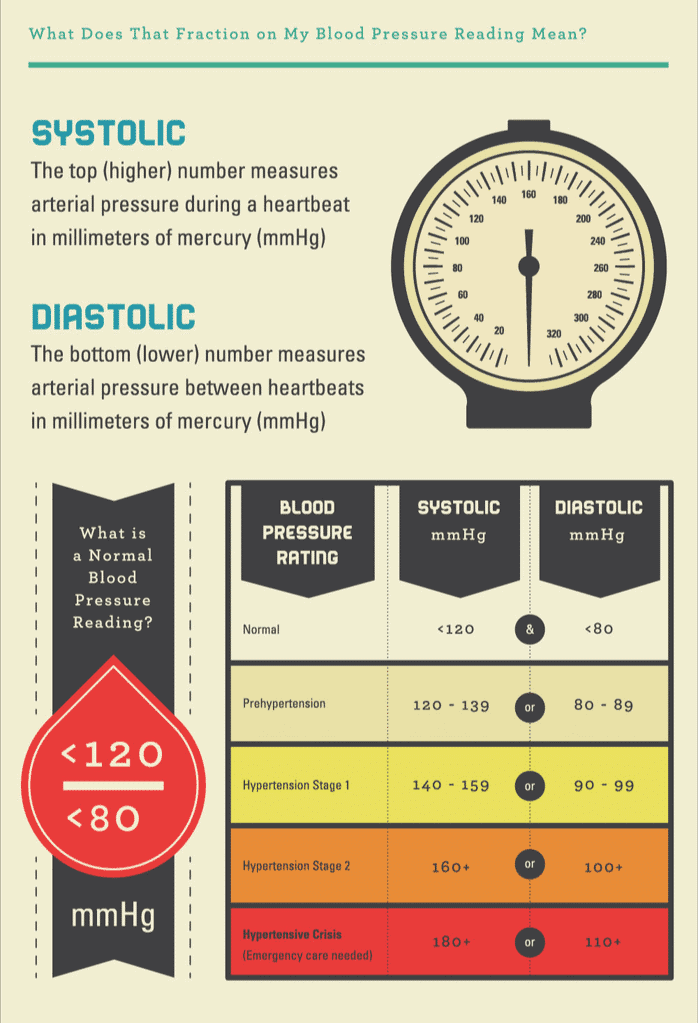
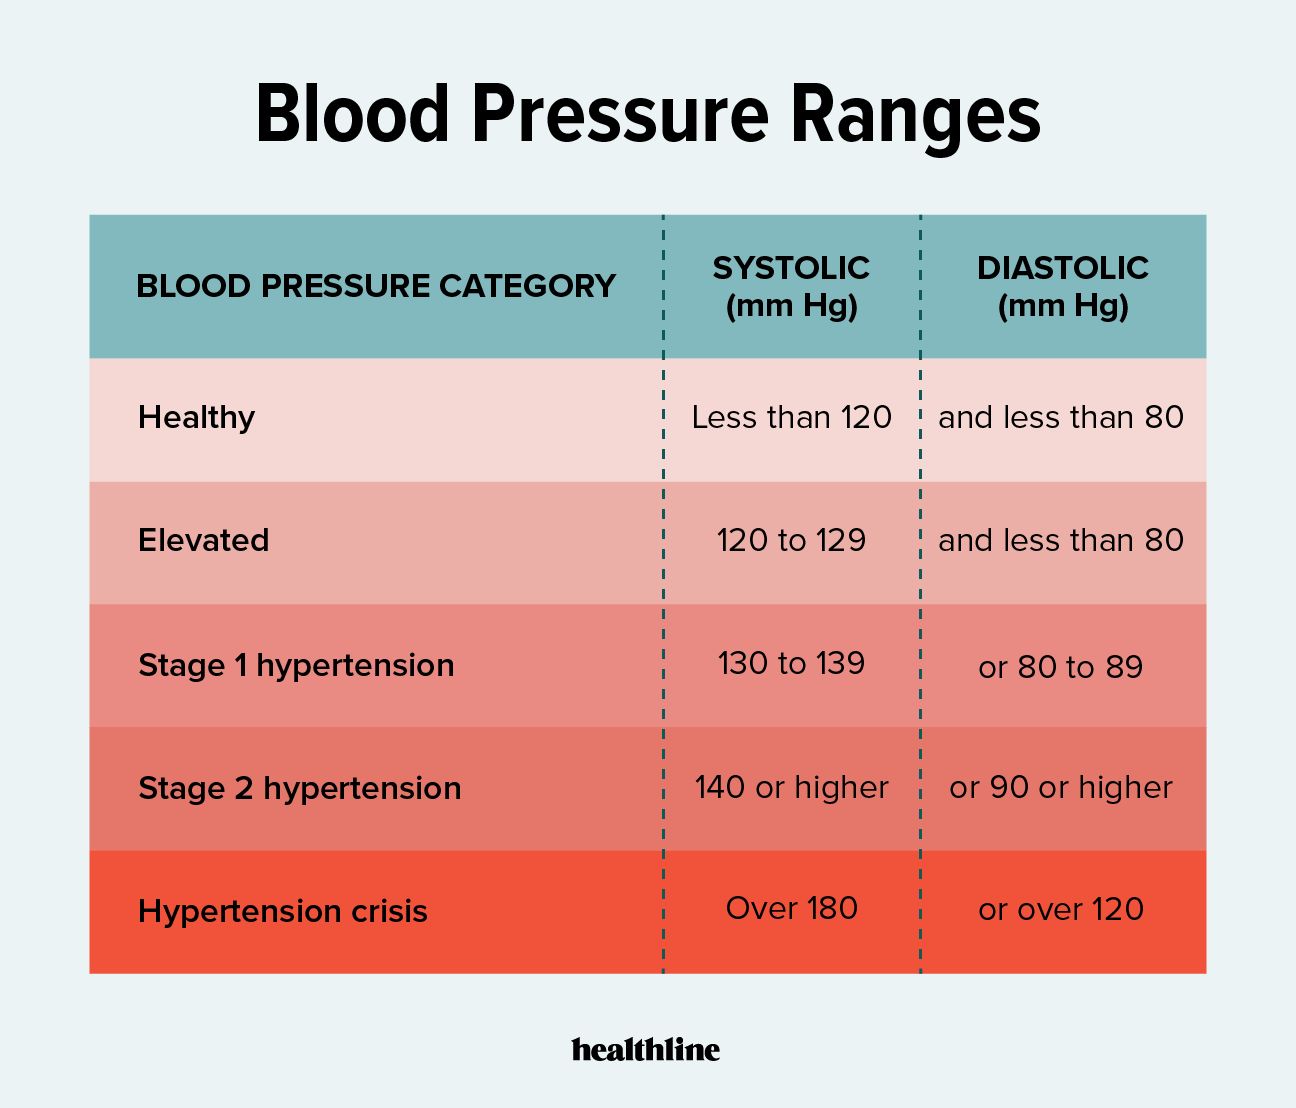
The intricate dance of autonomous flight, from the simplest hover to complex waypoint navigation, is orchestrated by a constant deluge of numerical data. Much like how medical professionals interpret blood pressure readings to gauge human physiological health, drone operators and flight systems analyze a multitude of digital “vital signs” to understand the operational status, stability, and safety of an unmanned aerial vehicle (UAV). These numbers, streaming from an array of sophisticated sensors and internal systems, are the bedrock of reliable flight technology, ensuring everything from precise navigation to robust obstacle avoidance. Understanding these critical figures is not just for expert diagnosticians; it’s fundamental to leveraging the full potential and ensuring the safe operation of modern flight systems.
The Vital Signs of Autonomous Flight: Telemetry as a Diagnostic Tool
In the realm of flight technology, telemetry serves as the UAV’s digital pulse, a continuous stream of numerical data that paints a real-time picture of its operational health. This data is the equivalent of a comprehensive medical chart, providing insights into every aspect of the drone’s system. When we refer to “blood pressure” in this context, we’re talking about the critical thresholds and deviations within these telemetry numbers that signal either a healthy, stable flight or an impending issue.
Key telemetry parameters include the drone’s attitude (roll, pitch, and yaw angles), its absolute and relative altitude, ground speed, vertical speed, and critical GPS information such as satellite count and positional accuracy (HDOP/VDOP). Battery voltage, current draw, motor RPMs, and signal strength are also integral components of this diagnostic mosaic. A flight system continuously processes these numbers, comparing them against expected values and operational limits. For instance, a sudden, unexplained spike in current draw might indicate a motor issue or prop obstruction, while persistent high HDOP numbers could signal unreliable GPS positioning.
Monitoring these numbers is paramount during all phases of flight. Pre-flight checks often involve reviewing initial sensor calibrations and GPS lock status. In-flight, pilots or autonomous systems monitor for deviations that could necessitate immediate action, such as a low battery voltage trigger initiating an automated return-to-home. Post-flight analysis of logged telemetry data is crucial for troubleshooting performance issues, identifying potential component wear, and refining flight parameters for future missions. The ability to interpret these numerical outputs is what differentiates a well-managed flight from a precarious one, transforming raw data into actionable intelligence for maintaining optimal flight system health.
Decoding Sensor Outputs: GPS, IMU, and Environmental Data
The backbone of stable and autonomous flight technology lies in the precise and continuous input from a suite of highly calibrated sensors. Each sensor contributes a unique set of numbers, which are then fused and interpreted by the flight controller to guide the UAV accurately and safely.
Global Positioning System (GPS) Metrics
GPS is arguably the most critical external sensor for navigation, providing precise positional data. The numbers derived from GPS include latitude, longitude, and altitude, which define the drone’s absolute position on Earth. Beyond raw coordinates, key performance indicators like Horizontal Dilution of Precision (HDOP) and Vertical Dilution of Precision (VDOP) are crucial. These numbers quantify the accuracy of the GPS fix; lower HDOP/VDOP values indicate a more reliable positional reading. The number of satellites acquired is another vital metric: more satellites generally equate to better accuracy and a stronger lock. Deviations in these numbers, such as a sudden increase in HDOP or a drop in satellite count, immediately signal a potential degradation in navigation precision, which can critically impact waypoint following, position hold, and return-to-home functions.
Inertial Measurement Unit (IMU) Readings
The IMU is the core of a drone’s stabilization system, providing vital numbers related to its orientation and movement. It comprises accelerometers and gyroscopes, and often magnetometers. Accelerometers measure linear acceleration along the X, Y, and Z axes, yielding numbers that indicate the drone’s translational motion and the force of gravity. Gyroscopes measure angular velocity, or the rate of rotation, around these same axes. These numbers are critical for determining the drone’s roll, pitch, and yaw angles, which are essential for maintaining a level flight and executing controlled turns.
Raw IMU data is prone to noise and drift, so sophisticated algorithms fuse these numbers, often incorporating magnetometer readings (which provide directional heading relative to magnetic north), to produce a highly accurate estimate of the drone’s orientation. The stability and precision of flight directly depend on the integrity of these IMU numbers; any uncalibrated offsets, vibrations, or sensor noise can lead to instability, control issues, and even catastrophic failures.
Barometric and Obstacle Avoidance Data
Barometric altimeters provide numbers related to atmospheric pressure, which can be translated into relative altitude. While GPS offers absolute altitude, the barometer provides very fine-grained vertical position changes, crucial for accurate altitude hold in varying terrain. The numbers from a barometer are particularly useful for maintaining a consistent height above ground level (if paired with a terrain model) or for precise vertical ascent/descent rates.
For obstacle avoidance, various sensors provide critical numerical inputs:
- Lidar/Sonar: These sensors emit pulses and measure the time it takes for them to return, yielding precise distance measurements to objects. These numbers form a real-time map of the drone’s immediate surroundings.
- Vision Systems: Stereo cameras or monocular vision systems process pixels to create depth maps and identify objects. The “numbers” here are often represented as distances, object classifications, and velocity vectors, all used by the flight controller to adjust flight paths, maintain safe separation, and prevent collisions in complex environments. The accuracy and refresh rate of these numbers directly dictate the effectiveness of the drone’s ability to navigate safely through congested airspace.
Powering Performance: Interpreting Battery and Motor Metrics
Beyond position and attitude, the performance and endurance of a UAV are fundamentally governed by the health of its propulsion and power systems. The numbers derived from these components offer direct insight into their operational efficiency and potential for failure, acting as critical indicators of the drone’s “physical” condition.
Battery Management System (BMS) Data
The battery is the lifeline of any electric drone, and its “blood pressure” is measured through several key numerical outputs. The most critical include total voltage, individual cell voltages, current draw, and remaining capacity (typically expressed in milliamp-hours, mAh, or as a percentage). A drop in total voltage below a safe threshold, especially under load (high current draw), indicates a weakening battery or an excessive power demand. Discrepancies between individual cell voltages can signal an unbalanced pack, which impacts overall capacity and safety. High current draw numbers, especially when sustained, can lead to overheating and premature battery degradation. Monitoring battery temperature is also vital, as excessive heat can compromise battery chemistry and lead to thermal runaway. These numbers collectively inform flight planning, dictating maximum flight times and triggering automated low-power failsafes, such as an emergency landing or return-to-home, long before a critical power loss occurs.
Motor and ESC (Electronic Speed Controller) Data
The motors and their accompanying ESCs are responsible for generating thrust and controlling the drone’s movement. Their numerical outputs provide a window into the health and efficiency of the propulsion system. Key metrics include individual motor RPM (revolutions per minute), ESC temperature, and the current being drawn by each motor. Consistent RPMs across all motors, commensurate with the desired thrust, indicate balanced power distribution. Deviations, such as one motor spinning slower than others for the same ESC input, could signify a damaged propeller, a failing motor bearing, or an issue with the ESC itself. Elevated ESC temperatures or unusually high current draws for a given RPM might suggest increased resistance, a short circuit, or a motor working harder than necessary due to an imbalanced prop or payload. Interpreting these numbers allows for early detection of mechanical issues, preventing unexpected motor failures that could destabilize or crash the UAV. Understanding these power-related numbers is crucial for optimizing payload capacity, flight duration, and overall system longevity.
From Data to Decision: Stabilization and Navigation Algorithms
The true intelligence of flight technology lies not just in collecting vast amounts of numerical data, but in the sophisticated algorithms that interpret and act upon it. The flight controller, often referred to as the drone’s “brain,” continuously ingests the “blood pressure” readings from all sensors and internal systems, converting these raw numbers into precise, real-time control commands.
At the heart of a drone’s stability are Proportional-Integral-Derivative (PID) controllers. These algorithms process numerical error signals—the difference between the desired flight attitude (e.g., level flight) and the actual attitude reported by the IMU sensors. The “P” component reacts to the current error (how far off the numbers are), the “I” component accounts for accumulated past errors (to eliminate steady-state offset), and the “D” component anticipates future errors based on the rate of change in the error numbers (to dampen oscillations). By continuously calculating and outputting corrective motor commands based on these numerical discrepancies, PID controllers ensure the drone remains stable, counteracting disturbances like wind gusts or subtle imbalances. The tuning of these PID numbers is critical; incorrect values can lead to unstable oscillations or sluggish responses.
Navigation algorithms leverage the numbers from GPS, IMU, and barometers to execute complex flight plans. For waypoint navigation, the system constantly compares the drone’s current numerical position (latitude, longitude, altitude) with the next target waypoint coordinates. It then calculates the required heading, speed, and ascent/descent rates to reach that point, translating these into precise motor control adjustments. During “position hold” or “altitude hold” modes, the algorithms actively work to keep the positional and altitudinal numbers within a very tight tolerance, counteracting external forces to maintain a steady hover.
The integration of redundant sensors and sensor fusion techniques further enhances the reliability of data-driven decisions. If one sensor’s numbers become erratic or are deemed unreliable, fusion algorithms can intelligently weigh inputs from other sensors, providing a more robust and accurate estimate of the drone’s state. For example, if GPS numbers briefly become unreliable in a challenging environment, the flight controller can temporarily rely more heavily on IMU data and visual odometry (from camera systems) to maintain stability and navigation. This continuous feedback loop of numerical input, algorithmic processing, and corrective action is what empowers modern flight systems to perform complex autonomous tasks with remarkable precision and resilience.
Predictive Maintenance and Anomaly Detection: Proactive Flight Health
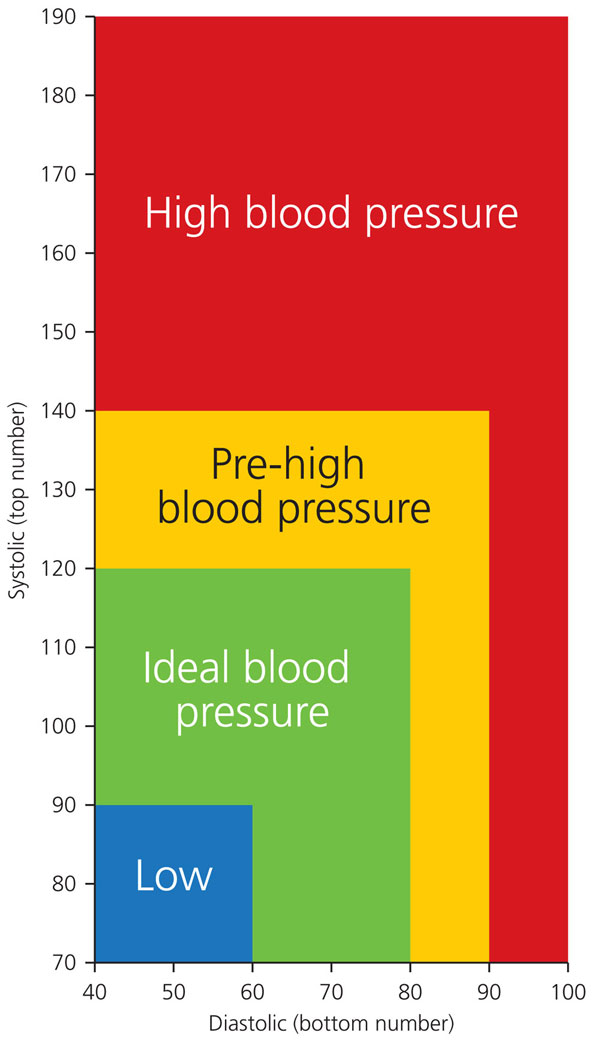
The constant stream of numerical data from a drone’s flight systems offers an unprecedented opportunity for proactive maintenance and enhanced safety. By diligently analyzing these “blood pressure” readings, flight technology is moving beyond reactive repairs towards predictive models that anticipate potential failures before they manifest.
Leveraging Historical Data for Predictive Maintenance: Every flight generates a rich dataset of numerical values: motor temperatures, battery cycle counts, individual cell voltages over time, sensor noise levels, and controller output ranges. By establishing baselines of “normal” operating numbers for various components under different conditions, deviations can be identified. For instance, a gradual but consistent increase in a motor’s operating temperature over several flights, even within acceptable limits, might predict an impending bearing failure. Similarly, a faster-than-expected degradation of battery capacity or an increase in the voltage differential between cells could signal the end of its reliable service life. These trends in numerical data allow operators to schedule component replacements or maintenance proactively, preventing in-flight failures and optimizing the operational lifespan of the UAV.
Anomaly Detection through Data Analytics: Advanced flight systems are increasingly employing sophisticated data analytics, including machine learning algorithms, to monitor real-time telemetry numbers. These algorithms learn the typical patterns and correlations within the drone’s operational data. When a numerical value or a combination of values deviates significantly from these learned patterns—for example, an unexpected oscillation in roll angle combined with a slight drop in a specific motor’s RPM—it triggers an alert. This anomaly detection allows for immediate investigation or automated corrective action, such as a controlled landing or activating a redundant system. This capability goes beyond simple threshold alerts; it can identify subtle, interconnected issues that might otherwise go unnoticed until they escalate into a critical problem.
The future of flight technology will heavily rely on these sophisticated analyses of numerical “blood pressure” readings. AI and machine learning will enable UAVs to not only self-diagnose but also to dynamically adjust their flight parameters, predict optimal maintenance schedules, and even learn from past operational data to enhance future mission safety and efficiency. This continuous learning and adaptation, driven by the meticulous interpretation of countless numbers, represents the ultimate evolution in ensuring robust and reliable autonomous flight operations.