
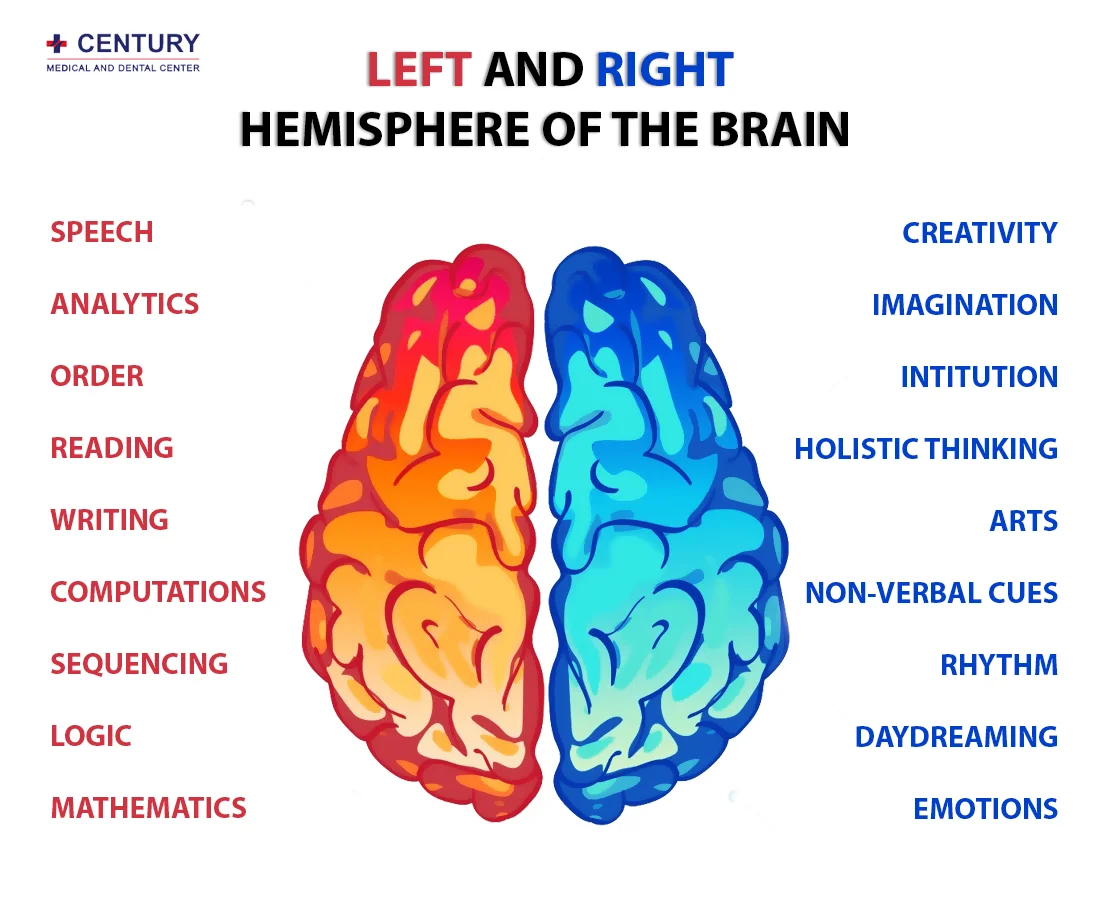
In the complex architecture of advanced drone technology, one can draw a compelling analogy to the human brain. While the right side might represent intuitive understanding, spatial awareness, and creative interpretation, the “left side of the brain” in autonomous flight systems embodies the logical, analytical, sequential processing core. This computational engine is responsible for the precision, reliability, and intelligence that defines modern aerial innovation, from meticulously planned missions to dynamic, real-time decision-making. It is the powerhouse behind data interpretation, strategic execution, and the unwavering consistency required for sophisticated operations.
The Logical Core of Autonomous Navigation
The essence of autonomous navigation lies in its ability to process vast amounts of data and execute complex decisions with machine-like precision. This is the domain of the system’s “left brain,” where logical algorithms and computational power converge to ensure drones traverse airspace efficiently and safely. Every flight path, every adjustment, and every predictive maneuver is the result of intricate logical operations.
Path Planning and Trajectory Optimization
At the heart of autonomous navigation is the meticulous task of path planning. This involves calculating the most efficient, safest, and legally compliant route from a starting point to a destination. The “left brain” processes geographical data, airspace restrictions, weather patterns, and mission objectives to generate a precise trajectory. This isn’t merely drawing a straight line; it involves optimizing for factors like energy consumption, flight time, payload stability, and avoidance of no-fly zones. Algorithms analyze elevation changes, wind currents, and potential interference, constructing a multi-dimensional flight path that is both pragmatic and robust. When faced with multiple viable routes, the system employs sophisticated optimization techniques to select the best one based on pre-defined parameters, ensuring mission success with minimal resource expenditure.
Data Fusion and Environmental Mapping
To navigate effectively, autonomous systems must understand their environment comprehensively. This necessitates data fusion—the process of integrating information from multiple sensors to create a coherent and accurate representation of the surroundings. GPS data provides global positioning, while inertial measurement units (IMUs) track orientation and movement. Lidar and radar systems map obstacles and terrain, and optical cameras capture visual details. The “left brain” meticulously synthesizes these disparate data streams, correlating them in real-time to build a dynamic, high-resolution environmental map. This fused data allows the drone to pinpoint its exact location, perceive its orientation relative to the ground and other objects, and understand the dynamic changes within its operational sphere. Without this analytical processing and fusion, the drone would be blind and disoriented, unable to perform any meaningful autonomous function.
Precision Control and Sensor Data Interpretation
The execution of any flight maneuver, from subtle adjustments to aggressive evasions, relies entirely on the autonomous system’s capacity for precision control and acute interpretation of sensor feedback. This aspect is quintessential to the “left brain” functionality, demanding instantaneous data analysis and deterministic output.
Real-time Feedback Loops
Autonomous drones operate within a constant cycle of observation, analysis, and action—a robust real-time feedback loop. Sensors continuously gather data on the drone’s position, velocity, altitude, and attitude. This raw data is immediately fed into the “left brain,” where it undergoes rapid processing. Algorithms compare the current state with the desired state (as dictated by the flight plan) and calculate the necessary control inputs to correct any deviations. Whether it’s a minor drift caused by a gust of wind or a significant course correction, these feedback loops operate at millisecond speeds, adjusting motor speeds, propeller angles, and control surface deflections with exacting precision. The analytical core ensures that the drone maintains its intended path and stability, even in challenging conditions, by constantly evaluating and responding to environmental variables. This sequential, logical comparison and adjustment process mirrors the analytical functions of the human left brain.
Obstacle Avoidance Algorithms

One of the most critical safety features of autonomous flight is sophisticated obstacle avoidance. The “left brain” is constantly engaged in processing data from various sensors—ultrasonic, infrared, stereo cameras, lidar, and radar—to detect potential collisions. Once an obstacle is identified, the system doesn’t merely stop; it immediately assesses its trajectory, speed, and the size and nature of the impediment. Advanced algorithms then calculate an alternative path, either by re-routing around the obstacle or by adjusting altitude to fly over or under it, all while adhering to the primary mission objectives as much as possible. This requires rapid sequential analysis of spatial relationships, predictive modeling of both the drone’s and the obstacle’s movements, and the logical selection of the safest avoidance maneuver. The robustness of these algorithms directly impacts the drone’s ability to operate safely in dynamic and unpredictable environments, representing a pinnacle of computational intelligence.
Sequential Processing for Mission Execution
Beyond navigation and immediate obstacle avoidance, the “left brain” of an autonomous system orchestrates the entire mission sequence, ensuring tasks are performed in a logical order and resources are managed efficiently. This involves managing complex workflows and adapting to unfolding scenarios.
Task Scheduling and Resource Management
Complex missions often involve a series of discrete tasks, such as specific data collection points, payload deployment, or inspection routines. The “left brain” is responsible for scheduling these tasks in an optimal sequence, minimizing travel time between points, maximizing data collection efficiency, and adhering to predefined timelines. It logically prioritizes tasks based on urgency, importance, and available resources (e.g., battery life, remaining storage). Furthermore, it manages the drone’s internal resources, monitoring power consumption, propulsion system health, and communication link integrity. If a critical resource begins to deplete, the system’s analytical core determines the most appropriate course of action, which could range from altering the mission plan to initiating an emergency return-to-home procedure, all based on a pre-programmed set of logical rules and contingencies.
Adaptive Learning in AI Follow Mode
AI Follow Mode, a key innovation in autonomous drone technology, exemplifies the “left brain’s” capacity for adaptive learning and real-time execution. When a drone is tasked to follow a moving subject, its analytical core continuously processes visual and spatial data to identify and track the target. It predicts the subject’s movement patterns, adjusts its own speed and trajectory accordingly, and maintains optimal distance and angle for filming or surveillance. This isn’t merely reacting to current positions; it involves building a dynamic model of the subject’s behavior over time and making predictive adjustments. The “left brain” learns from observed movements, refining its tracking algorithms to become more precise and fluid with each operation. This continuous learning and adaptation, driven by logical interpretation of sensory input, allows for increasingly sophisticated and human-like tracking capabilities.
The Future: Enhanced Analytical Intelligence
The trajectory of drone technology points towards even more advanced “left-brain” functionalities, pushing the boundaries of autonomous operation through heightened analytical intelligence and proactive decision-making.
Predictive Analytics for Proactive Operations
The next generation of autonomous flight systems will heavily rely on predictive analytics. Moving beyond real-time reactions, the “left brain” will analyze historical data, environmental forecasts, and current operational parameters to anticipate potential issues before they arise. For instance, based on current battery drain rates and predicted wind conditions, it could proactively suggest an altered flight path to conserve power or identify potential equipment failures before they become critical. This proactive approach, rooted in complex statistical analysis and pattern recognition, will enable drones to operate with unprecedented levels of foresight, minimizing risks and maximizing operational efficiency in fields like infrastructure inspection, agriculture, and logistics.
Towards Self-Correction and Advanced Problem Solving
Ultimately, the goal is to imbue autonomous systems with the capacity for true self-correction and advanced problem-solving. This involves not just following pre-programmed rules but dynamically re-evaluating mission parameters and generating novel solutions in unforeseen circumstances. If an unexpected obstacle arises that cannot be circumvented by existing avoidance algorithms, the “left brain” might analyze the situation, access a broader knowledge base of environmental physics and operational constraints, and formulate a completely new, safe strategy. This level of cognitive automation requires sophisticated symbolic reasoning, probabilistic inference, and machine learning models that can infer causality and experiment with solutions, propelling autonomous flight into an era where drones can truly think, adapt, and innovate on their own.