
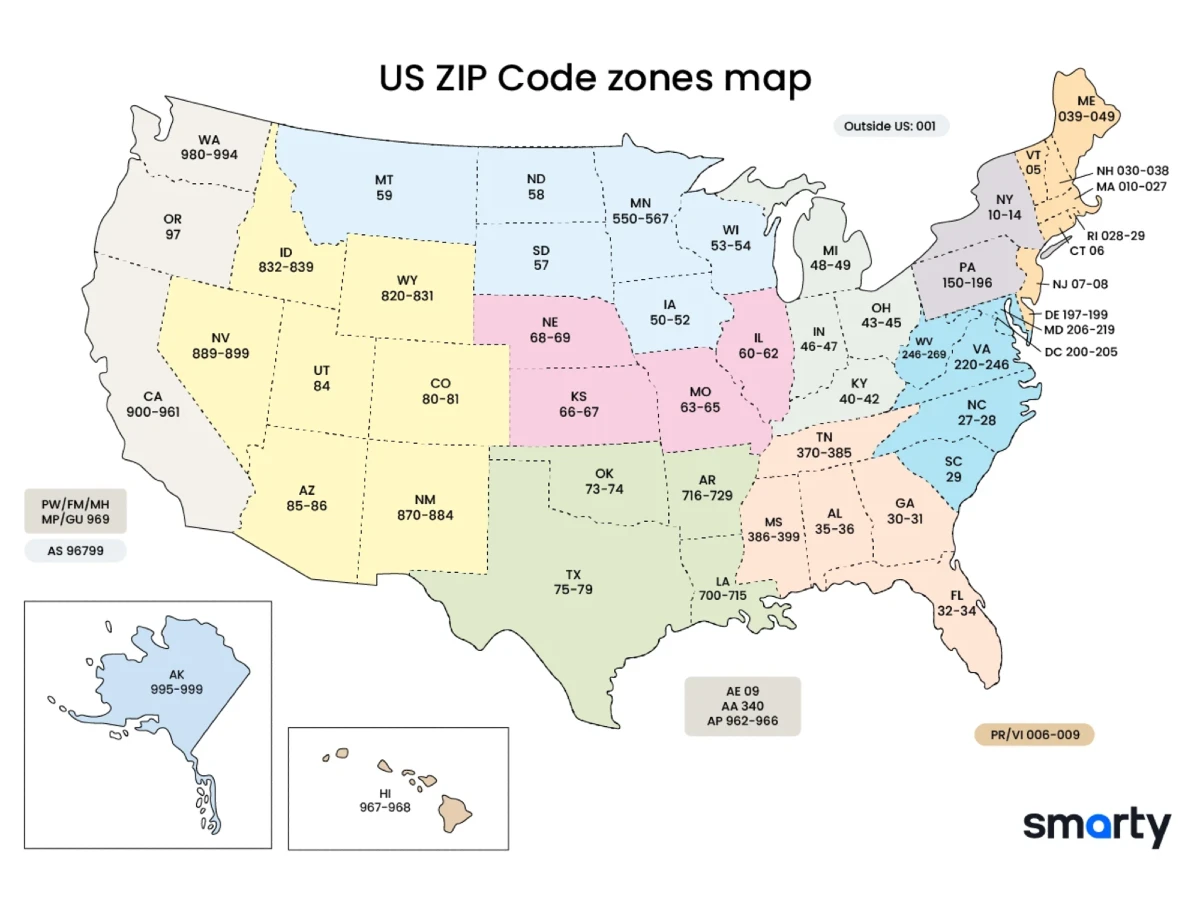
The question of “what my zip code of my location” might seem simple on the surface, but when applied to the realm of drone operations, it unlocks a profound discussion about precision navigation, spatial awareness, and the intricate technologies that enable unmanned aerial vehicles (UAVs) to understand and interact with their environment. For drones, knowing “where” they are is not just a matter of coordinates; it’s fundamental to safe operation, regulatory compliance, mission success, and the very stability of flight. This intricate understanding of location, from broad geographical zones akin to a zip code down to centimeter-level accuracy, is powered by advanced flight technology, with Global Positioning Systems (GPS) serving as the bedrock.
The Foundation of Location: Global Positioning Systems in Drones
At the core of a drone’s ability to determine its “zip code” or precise location is the Global Positioning System (GPS), or more broadly, Global Navigation Satellite Systems (GNSS), which encompass other constellations like GLONASS, Galileo, and BeiDou. These systems provide the foundational data that allows a drone to pinpoint its position on Earth.
GPS Fundamentals for UAVs
GPS operates by receiving signals from a network of satellites orbiting Earth. Each satellite transmits a unique signal containing its orbital position and the precise time the signal was sent. A drone’s GPS receiver calculates its distance from multiple satellites by measuring the time delay between sending and receiving these signals. Through a process called trilateration, by receiving signals from at least four satellites, the receiver can accurately determine its three-dimensional position (latitude, longitude, and altitude).
For UAVs, GPS is indispensable. It enables autonomous flight modes, helps maintain stable hovering, and facilitates waypoint navigation. Without reliable GPS data, advanced drone functions like automated return-to-home or precision agricultural spraying would be impossible. However, standard consumer-grade GPS receivers typically offer accuracy within a few meters. While sufficient for general recreational flight, this level of precision falls short for many professional applications that demand centimeter-level positioning. Factors such as atmospheric conditions, satellite signal availability, and signal reflections (multipath errors) in urban canyons or near large structures can further degrade standard GPS accuracy.
Enhancing Accuracy: RTK and PPK Technologies
To overcome the inherent limitations of standard GPS, particularly the need for pinpoint accuracy in commercial and industrial drone applications, advanced positioning technologies like Real-Time Kinematic (RTK) and Post-Processed Kinematic (PPK) have become crucial. These systems dramatically enhance the precision of GPS data, providing centimeter-level accuracy.
Both RTK and PPK leverage a network of ground-based reference stations with precisely known locations. These stations continuously receive satellite signals and compare them with their known positions to calculate error corrections.
- RTK (Real-Time Kinematic) systems transmit these correction data in real-time to the drone’s onboard GPS receiver. This real-time correction allows the drone to adjust its position calculations instantly, achieving highly accurate positioning during flight. RTK is particularly beneficial for applications requiring immediate precision, such as real-time surveying, construction progress monitoring, or precise agricultural spraying where mission-critical decisions are made on the fly. The primary challenge with RTK is maintaining a continuous, stable data link between the ground station and the drone throughout the flight. Signal interruptions can temporarily reduce accuracy.
- PPK (Post-Processed Kinematic) systems, on the other hand, log the raw satellite observation data on both the drone and the ground reference station during the flight. After the flight is completed, this data is combined and processed using specialized software. This post-processing approach offers several advantages, including greater robustness against temporary signal losses during flight, as all corrections are applied retrospectively. PPK often yields slightly more accurate results than RTK because the processing can involve more sophisticated algorithms and wider datasets. It is ideal for applications where real-time accuracy is less critical than ultimate precision, such as high-accuracy mapping, photogrammetry, and 3D modeling where the final product’s quality depends heavily on precise spatial data.
The integration of RTK and PPK technologies has revolutionized the capabilities of drones, transforming them from aerial cameras into sophisticated precision instruments capable of collecting highly accurate georeferenced data. This level of precision is essential for understanding geographical context down to granular details, allowing drones to operate within specific zones and boundaries with unparalleled accuracy.
Beyond Raw Coordinates: Understanding Geographic Context
While precise coordinates tell a drone exactly where it is, understanding the “zip code of its location” requires interpreting those coordinates within a broader geographic and regulatory framework. This is where geofencing and the integration of location data for regulatory compliance become paramount.
Geofencing and Airspace Management
Geofencing is a virtual boundary that can be programmed into a drone’s flight controller, using the drone’s GPS coordinates to define specific operational areas. These digital fences can restrict a drone from flying into certain zones, limit its altitude, or even prevent takeoff in designated no-fly zones. This technology is critical for ensuring public safety and maintaining controlled airspace.
Regulatory bodies worldwide, such as the Federal Aviation Administration (FAA) in the United States or the European Union Aviation Safety Agency (EASA), define various airspace classifications and restrictions. These often correlate to specific geographical areas around airports, military installations, national parks, or sensitive infrastructure. A drone’s flight technology integrates these “no-fly zones” into its navigation system. Before or during a flight, the drone’s software checks its current GPS location against these geofences. If the drone approaches or attempts to enter a restricted area, the system can automatically slow it down, hover, or initiate a return-to-home sequence. This proactive approach prevents accidental incursions, safeguarding both the drone and other airspace users. In essence, geofencing translates the abstract concept of a regulatory “zip code” into actionable flight parameters.
Integrating Location Data for Regulatory Compliance
The ability to accurately determine and understand its location allows drones to comply with complex and evolving aviation regulations. Beyond simple no-fly zones, many regulations dictate specific operating procedures based on geographic location. For instance, rules regarding flying over people, beyond visual line of sight (BVLOS), or night operations often depend on the drone’s location relative to populated areas, specific types of terrain, or designated flight corridors.
Drone flight planning software increasingly integrates comprehensive databases of airspace information, topographical maps, and local regulations. Pilots can input their intended flight path, and the software will analyze the route against all relevant geographic and regulatory data. This can include:
- Airspace classifications: Identifying whether the flight falls within controlled, uncontrolled, or special-use airspace.
- Temporary Flight Restrictions (TFRs): Real-time updates on dynamic restrictions due to events like sporting events, wildfires, or VIP movements, which can be highly localized.
- Environmental protections: Avoiding sensitive ecological areas or wildlife habitats.
- Proximity to critical infrastructure: Ensuring safe distances from power plants, prisons, or government buildings.
By accurately knowing its location through GPS/GNSS and interpreting this data within a georeferenced regulatory framework, a drone’s flight technology can guide the operator through the permitting process, flag potential violations, or even prevent unauthorized flights. This integration of location intelligence into flight planning is vital for promoting responsible and legal drone operations, transforming raw coordinates into meaningful operational context.
The Role of Inertial Navigation and Sensor Fusion
While GPS provides the primary means for a drone to establish its absolute global position, it is not the only piece of the navigation puzzle. Inertial Measurement Units (IMUs) and sophisticated sensor fusion techniques play a critical role in providing robust and continuous positional awareness, especially when GPS signals are weak or unavailable.

IMUs and Stabilization
An Inertial Measurement Unit (IMU) is a microelectronic device that contains a combination of accelerometers, gyroscopes, and often magnetometers.
- Accelerometers measure the drone’s linear acceleration along its three axes (X, Y, Z).
- Gyroscopes detect and measure the angular velocity or rate of rotation around the same three axes.
- Magnetometers (electronic compasses) provide heading information by measuring the strength and direction of the Earth’s magnetic field.
Together, these sensors provide real-time data on the drone’s orientation, angular velocity, and linear acceleration. This information is crucial for the flight controller to maintain stability, execute precise movements, and counteract external forces like wind. While an IMU can track movement relative to a starting point (dead reckoning), it is prone to accumulating errors over time due to drift. Therefore, it is typically used in conjunction with GPS. For instance, if a drone briefly loses GPS signal, the IMU can continue to estimate its position and attitude for a short period, preventing immediate instability or uncontrolled drift.
Sensor Fusion for Robust Positioning
Sensor fusion is the process of combining data from multiple dissimilar sensors to achieve a more accurate, reliable, and comprehensive understanding of a drone’s state (position, velocity, orientation) than any single sensor could provide alone. For drone navigation, this often means merging GPS data with IMU readings, barometer data, and sometimes optical flow sensors or vision systems.
- GPS + IMU: The IMU provides high-frequency, short-term motion data, while GPS provides slower-frequency, long-term absolute position data. By fusing these, the system can correct the IMU’s drift with GPS updates, resulting in a stable and accurate position estimate even during dynamic maneuvers.
- Barometer: A barometer measures atmospheric pressure, which can be used to determine relative altitude. Fusing this with GPS altitude (which can be less accurate vertically) provides a more precise and stable height estimate.
- Optical Flow Sensors: These downward-facing cameras analyze movement patterns on the ground to estimate horizontal velocity and relative position, particularly useful for hovering indoors or at low altitudes without GPS.
- Vision Systems (SLAM): For complex environments or where GPS is entirely absent, Visual Inertial Odometry (VIO) or Simultaneous Localization and Mapping (SLAM) algorithms use camera data in conjunction with IMU readings to build a map of the environment while simultaneously tracking the drone’s position within that map.
This sophisticated fusion of data streams ensures that the drone continuously knows its “zip code” or precise location, even when individual sensors face challenges. It provides the robust redundancy necessary for safe and autonomous flight, allowing drones to maintain stability and execute complex missions with high reliability.
Advanced Navigation for Complex Missions
The ability to accurately and reliably determine its location empowers drones to undertake increasingly complex and autonomous missions, pushing the boundaries of what UAVs can achieve. From pre-programmed flight paths to navigating challenging environments, advanced navigation systems are at the forefront of drone innovation.
Waypoint Navigation and Autonomous Flight Paths
Waypoint navigation is a cornerstone of advanced drone operations, enabling fully autonomous flights based on a predefined series of geographic coordinates. Pilots can program a sequence of waypoints, specifying parameters such as altitude, speed, camera angle, and actions to perform at each point. The drone’s flight technology, relying on its precise GPS/GNSS and IMU data, then executes this flight plan with remarkable accuracy.
This capability is invaluable for a wide range of applications:
- Automated Inspections: Drones can repeatedly fly the exact same path to inspect infrastructure like power lines, bridges, or wind turbines, ensuring consistent data collection over time.
- Photogrammetry and Mapping: For creating high-resolution orthomosaic maps, 3D models, or digital elevation models, drones follow a meticulously planned grid pattern to capture overlapping images from precise locations, ensuring comprehensive coverage and accurate georeferencing of the output.
- Precision Agriculture: Drones can follow pre-programmed routes to spray crops, monitor field health, or conduct livestock management, optimizing resource use and improving efficiency.
- Search and Rescue: Automated flight patterns can systematically cover large areas, reducing human effort and speeding up response times.
The accuracy provided by RTK/PPK systems is particularly critical for these missions, as even small deviations from the planned path can impact the quality and consistency of the collected data. The drone’s ability to precisely navigate to and between “zip codes” (or specific points within them) is what transforms it from a manual flying machine into an intelligent, autonomous data collection platform.
Overcoming GPS Challenges in Urban and Indoor Environments
While GPS is phenomenal for open-sky navigation, its effectiveness can diminish significantly in urban areas (due to signal blockage and multipath reflections from tall buildings) or become entirely non-existent indoors. To maintain positional awareness in these challenging environments, drones employ a suite of alternative and complementary navigation technologies.
- Visual Odometry (VO) and Visual Inertial Odometry (VIO): These systems use cameras to track features in the environment and estimate the drone’s movement relative to those features. By combining visual data with IMU readings, drones can accurately estimate their position and orientation without GPS. VIO is particularly effective for indoor navigation, tight spaces, and environments with rich visual textures.
- Lidar (Light Detection and Ranging): Lidar sensors emit laser pulses and measure the time it takes for them to return, creating a highly detailed 3D map of the surroundings. By comparing successive scans, a drone can track its movement and build a real-time understanding of its position within the mapped environment. This is invaluable for complex indoor inspections or autonomous navigation in cluttered spaces.
- Ultra-Wideband (UWB) Positioning Systems: UWB technology uses radio signals for precise short-range distance measurement. By deploying several UWB anchors (transmitters) in a known indoor layout, a drone equipped with a UWB receiver can triangulate its position with centimeter-level accuracy, much like an indoor GPS.
- Sonar and Barometric Sensors: Sonar sensors use sound waves to measure distance to the ground or obstacles, while barometers provide relative altitude, supplementing other sensors for safe flight at low altitudes or indoors.
The continuous development of these advanced navigation technologies ensures that drones can reliably determine their “zip code” and move through their environment safely and effectively, regardless of external conditions or GPS availability. This adaptability unlocks new possibilities for drone deployment in a broader range of industries and scenarios.
The Future of Precision Location in Drone Flight
The relentless pursuit of precision and reliability in drone navigation continues to drive innovation in flight technology. The future promises even more sophisticated ways for drones to understand their location, from global coordinates to highly localized spatial relationships.
One significant trend is the expansion and improvement of Global Navigation Satellite Systems. New constellations like Europe’s Galileo and China’s BeiDou, alongside modernizations of GPS and GLONASS, are increasing satellite availability and signal robustness. Drones equipped with multi-constellation receivers can access more satellite signals simultaneously, leading to better accuracy and reliability, especially in challenging urban environments where line-of-sight to individual satellites might be obstructed.
Furthermore, the integration of Artificial Intelligence (AI) and machine learning will play an increasingly vital role. AI can process vast amounts of sensor data (GPS, IMU, vision, LiDAR) to predict optimal flight paths, detect anomalies in positioning data, and adapt navigation strategies in real-time. This includes predictive path planning that anticipates signal degradation or dynamic obstacle avoidance based on an evolving understanding of the drone’s environment and its relation to its ‘zip code’ or operational zone.
The concept of “my zip code of my location” will also evolve to encompass more granular and dynamic spatial awareness. Drones will increasingly integrate with national airspace management systems, facilitating seamless and safe integration into complex air traffic flows. This will involve real-time data sharing about a drone’s precise location and intended movements, enabling collaborative decision-making and preventing conflicts with other air users. Urban Air Mobility (UAM) and drone delivery services critically depend on this level of precision and integration, requiring drones to navigate specific, often temporary, corridors with unparalleled accuracy and real-time contextual awareness of their geographical surroundings.
Ultimately, the drive in flight technology is towards making drone navigation not just accurate, but also intelligent, adaptable, and context-aware. This means empowering drones to not only know their exact coordinates but also understand the broader implications of those coordinates—from regulatory restrictions and environmental sensitivities to dynamic traffic conditions and mission-specific requirements—ensuring safe, efficient, and transformative aerial operations for years to come.