
The landscape of unmanned aerial vehicles (UAVs) is in a perpetual state of flux, driven by relentless innovation in artificial intelligence, sensor technology, and miniaturization. Within this dynamic environment, the concept of a ‘Weedle’ drone represents a hypothetical yet highly pertinent model for understanding the evolutionary trajectory of autonomous micro-UAVs. Far from a biological entity, ‘Weedle’ serves as a codename for a class of advanced, AI-enhanced autonomous micro-drone platforms, meticulously engineered for agile data acquisition, complex environmental monitoring, and intricate mapping missions. The question, “what level does ‘Weedle’ evolve,” thus becomes a compelling inquiry into the escalating sophistication of these systems, charting their progression through distinct stages of autonomy, intelligence, and operational capability. It underscores the continuous development cycle that pushes the boundaries of what small, intelligent drones can achieve, particularly within the domain of Tech & Innovation, encompassing AI follow mode, autonomous flight, mapping, and remote sensing.
Defining ‘Weedle’: A New Paradigm in AI-Enhanced Autonomous Systems
The ‘Weedle’ platform represents a new frontier in micro-UAV design, prioritizing agility, intelligence, and self-sufficiency. Its genesis lies in the demand for drones capable of operating in highly dynamic, complex, and often inaccessible environments where human intervention is either impractical or unsafe. These systems are not merely drones with automation features; they are conceived as truly autonomous agents, capable of learning, adapting, and making informed decisions in real-time. Their lightweight construction belies a formidable technological core, integrating advanced computational power with sophisticated sensor arrays to perform tasks with unprecedented precision. The overarching mission of the ‘Weedle’ project is to push the boundaries of remote sensing and dynamic data collection, minimizing the need for constant human oversight and maximizing operational efficiency and data fidelity.
Initial Prototypes and Fundamental Algorithms
The early developmental stages of any ‘Weedle’-class system are critical, laying the groundwork for its future autonomous capabilities. Initial prototypes focus heavily on establishing a robust foundational AI architecture. This involves implementing basic machine learning models for fundamental tasks such as stable navigation, power management, and rudimentary object detection. Challenges at this stage are manifold, primarily revolving around miniaturization – how to integrate powerful processors, communication modules, and essential sensors into a package small enough for agile flight, yet robust enough to withstand varied operational conditions. Fundamental algorithms at this level are designed for basic environmental mapping, establishing a preliminary understanding of the operational area, and ensuring the drone can maintain its position and orientation reliably. These initial steps are crucial for validating the core concepts of autonomous operation and setting the stage for more complex behaviors.
Sensory Integration and Edge Computing Capabilities
A defining characteristic of ‘Weedle’ systems is their reliance on advanced sensory integration combined with powerful edge computing. This combination is pivotal for enabling true autonomy. Micro-UAVs are equipped with a diverse suite of miniaturized sensors, which can include high-resolution optical cameras, thermal imagers, LiDAR for precise ranging, and even specialized environmental sensors for atmospheric analysis. The ability to process the vast amounts of data generated by these sensors in real-time, directly on the drone itself – rather than relying on constant communication with a ground station – is where edge computing becomes indispensable. This on-board processing capability allows ‘Weedle’ systems to perceive their environment, understand context, and make immediate, informed decisions, such as identifying a target, adjusting flight paths to avoid unexpected obstacles, or optimizing sensor parameters for better data capture. This level of integrated intelligence is what separates truly autonomous ‘Weedle’ systems from traditional remotely piloted drones.
Leveling Up: Stages of Autonomous Evolution in ‘Weedle’ Systems
The “evolution” of a ‘Weedle’ system can be understood as a progression through distinct levels of autonomy and capability, much like biological evolution but in a technological context. Each level represents a significant leap in operational intelligence, independence from human control, and the complexity of tasks it can undertake. This layered approach ensures that as ‘Weedle’ systems evolve, they become increasingly adept at navigating, understanding, and interacting with their environment.
Foundational Autonomy: Level 1 – Waypoint Navigation and Basic Obstacle Avoidance
At its most fundamental, Level 1 of ‘Weedle’s’ evolution embodies foundational autonomy. Here, the system is primarily characterized by its ability to execute pre-programmed flight paths, often defined by a series of waypoints. While autonomous in executing these routes, its decision-making capabilities are relatively limited. Basic obstacle avoidance is typically reactive, relying on immediate sensor inputs to detect and swerve around obstructions without complex predictive analysis. This level of ‘Weedle’ is akin to a highly sophisticated automated vehicle, capable of following instructions but lacking the capacity for dynamic adaptation to unforeseen circumstances. It still relies heavily on pre-surveyed maps and significant human oversight for mission planning and intervention in non-standard situations. Its applications are generally confined to repetitive tasks in controlled environments where the probability of unexpected events is low.
Adaptive Intelligence: Level 2 – Dynamic Path Planning and Environmental Adaptation
Ascending to Level 2, the ‘Weedle’ system demonstrates adaptive intelligence, marking a significant shift towards proactive decision-making. This stage introduces advanced AI algorithms that enable dynamic route optimization. Instead of rigidly adhering to pre-set waypoints, the drone can now analyze real-time data – such as changing weather patterns, the movement of a target, or newly identified environmental anomalies – and recalculate its optimal flight path on the fly. This adaptive capability allows ‘Weedle’ to adjust mission parameters in real-time, perhaps altering its altitude to achieve a better photographic angle or rerouting to avoid an area of high wind. Features like “AI Follow Mode” begin to manifest at this level, allowing the drone to autonomously track moving subjects or phenomena while maintaining optimal distance and viewing angles. The system starts to build an internal model of its environment, improving its predictions and responses, making it far more versatile for diverse remote sensing and mapping tasks.
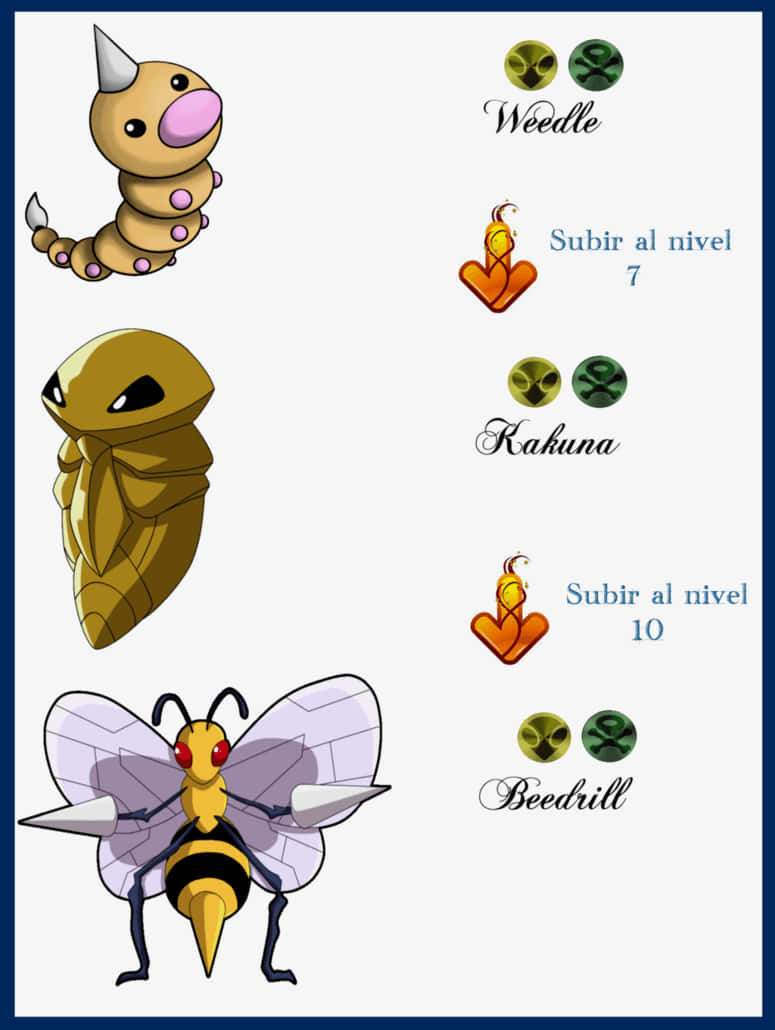
Collaborative Learning: Level 3 – Swarm Coordination and AI-Driven Decision Making
The pinnacle of current ‘Weedle’ evolution resides at Level 3, characterized by collaborative learning and sophisticated swarm coordination. At this advanced stage, multiple ‘Weedle’ units operate as a cohesive team, communicating and sharing data in real-time to achieve complex, overarching objectives that a single drone could not. This distributed AI enables collective decision-making, where the swarm can autonomously divide tasks, optimize resource allocation (e.g., battery life, sensor coverage), and achieve comprehensive mapping or remote sensing over vast areas with unprecedented efficiency. For instance, in a large-scale agricultural mapping project, a ‘Weedle’ swarm could dynamically reassign roles to cover detected anomalies, or one drone could take over another’s route if it encounters a technical issue. This level signifies a move beyond individual drone intelligence to a collective, emergent intelligence, offering enhanced resilience, redundancy, and efficiency for the most demanding applications.
The Evolutionary Drivers: AI, Machine Learning, and Real-time Data Fusion
The engine behind ‘Weedle’s’ progressive evolution across these levels is the relentless advancement in artificial intelligence, machine learning, and the ability to fuse vast quantities of real-time data. AI is not merely a feature within these systems; it is the core operating principle that enables them to transcend simple automation and achieve true autonomy. The continuous development in neural networks, deep learning algorithms, and reinforcement learning paradigms is what propels ‘Weedle’ from reactive machines to predictive, adaptive, and collaborative agents.
Predictive Analytics for Route Optimization
One of the most impactful applications of AI in ‘Weedle’ systems is in predictive analytics for route optimization. Leveraging historical data, environmental models, and real-time sensor inputs, AI algorithms can predict factors like wind changes, shifting light conditions, or the movement of a subject. This predictive capability allows the drone to pre-emptively adjust its flight path, minimizing energy consumption by avoiding headwinds, optimizing data collection by ensuring ideal lighting, or ensuring continuous tracking of dynamic elements. This proactive approach significantly enhances mission efficiency, extends operational endurance, and improves the overall quality and relevance of the collected data, directly supporting highly efficient autonomous flight and mapping initiatives.
Real-time Object Recognition and Classification for Enhanced Remote Sensing
Another critical evolutionary driver is the ability of ‘Weedle’s’ AI to perform real-time object recognition and classification. Using sophisticated convolutional neural networks, these drones can instantly identify and categorize objects of interest within their visual or thermal feeds. This is crucial for diverse remote sensing applications, from identifying specific crop diseases in precision agriculture to locating endangered wildlife for conservation, or even detecting structural anomalies in infrastructure inspections. This immediate processing capability transforms raw visual data into actionable intelligence directly at the source, allowing the drone to react accordingly – perhaps by performing a closer inspection, triggering an alarm, or tagging the data with specific metadata. This capability not only enhances the accuracy and speed of mapping but also provides immediate, critical insights without the delay of post-mission analysis.
Beyond the Current ‘Level’: Future Trajectories for ‘Weedle’ Technology
The journey of ‘Weedle’s’ evolution is far from complete. As technology continues its exponential growth, future ‘levels’ promise even more profound capabilities, pushing the boundaries of what autonomous micro-UAVs can achieve. The trajectory is toward even greater integration, self-sufficiency, and symbiotic interaction with human operators.
Seamless Human-AI Teaming and Intuitive Control
The next significant leap will likely be in seamless human-AI teaming. Future ‘Weedle’ systems are envisioned to move beyond simple teleoperation or autonomous task execution. Instead, human operators will define high-level strategic goals, while the ‘Weedle’ swarm autonomously devises and executes the intricate tactical details. This will involve highly intuitive control interfaces, possibly leveraging augmented reality (AR) or virtual reality (VR), allowing operators to visualize the drone’s understanding of its environment and intentions. The focus will be on natural language processing for command input and advanced predictive displays, making the interaction as intuitive as working with a highly intelligent, proactive assistant.
Energy Harvesting and Extended Endurance for Persistent Missions
A key limitation for all drones remains battery life. Future ‘Weedle’ evolution will heavily feature advancements in energy harvesting and extended endurance. Imagine drones capable of recharging mid-mission using miniature solar panels, exploiting thermal gradients, or even through kinetic energy harvesting from their flight dynamics. This would enable truly persistent missions, allowing ‘Weedle’ systems to monitor vast areas continuously for days or even weeks without human intervention for battery swaps. Such capabilities would revolutionize long-term environmental monitoring, infrastructure surveillance, and disaster response, providing unparalleled data continuity for mapping and remote sensing applications.