
The Foundation of Statistical Certainty in Drone Tech
In the rapidly evolving landscape of drone technology and innovation, precision, reliability, and accuracy are paramount. From autonomous flight systems navigating complex environments to high-resolution mapping and remote sensing applications, the underlying data must be rigorously evaluated. This is where statistical tools like the Z-score and the 95% confidence interval become indispensable. They provide a quantitative framework for understanding the certainty and variability inherent in the vast amounts of data generated by modern UAVs, ensuring that technological advancements are not only impressive but also dependable.
Understanding Z-Scores: Quantifying Deviation
A Z-score, also known as a standard score, is a statistical measurement that describes a value’s relationship to the mean of a group of values. It measures how many standard deviations an element is from the mean. A positive Z-score indicates the data point is above the mean, while a negative Z-score indicates it’s below the mean. A Z-score of 0 means the data point is identical to the mean.
The formula for calculating a Z-score is:
$Z = (X – mu) / sigma$
Where:
- $X$ is the individual data point (e.g., a single GPS coordinate reading, a sensor temperature reading).
- $mu$ (mu) is the mean (average) of the data set (e.g., the average recorded altitude over multiple measurements).
- $sigma$ (sigma) is the standard deviation of the data set (e.g., the spread of GPS error measurements).
In drone technology, Z-scores are particularly useful for anomaly detection and quality control. For instance, when a drone’s Inertial Measurement Unit (IMU) logs thousands of acceleration values, a sudden Z-score significantly outside the typical range (e.g., >3 or <-3) might flag a sensor malfunction, an unexpected environmental disturbance, or an unusual flight dynamic that requires further investigation. Similarly, in remote sensing, Z-scores can help identify outlier pixel values in multispectral imagery, potentially indicating sensor noise or a unique feature on the ground that warrants closer analysis. By standardizing diverse data points, the Z-score provides a universal metric for understanding their significance relative to the typical performance or expected baseline.
The 95% Confidence Interval: A Window of Reliability
While a Z-score tells us about an individual data point, a confidence interval provides a range of values within which we are confident the true population parameter lies. A 95% confidence interval, specifically, means that if we were to take many samples and construct a confidence interval from each, approximately 95% of these intervals would contain the true population parameter. This doesn’t mean there’s a 95% probability that the true mean falls within a specific interval, but rather it reflects the reliability of the estimation process itself.
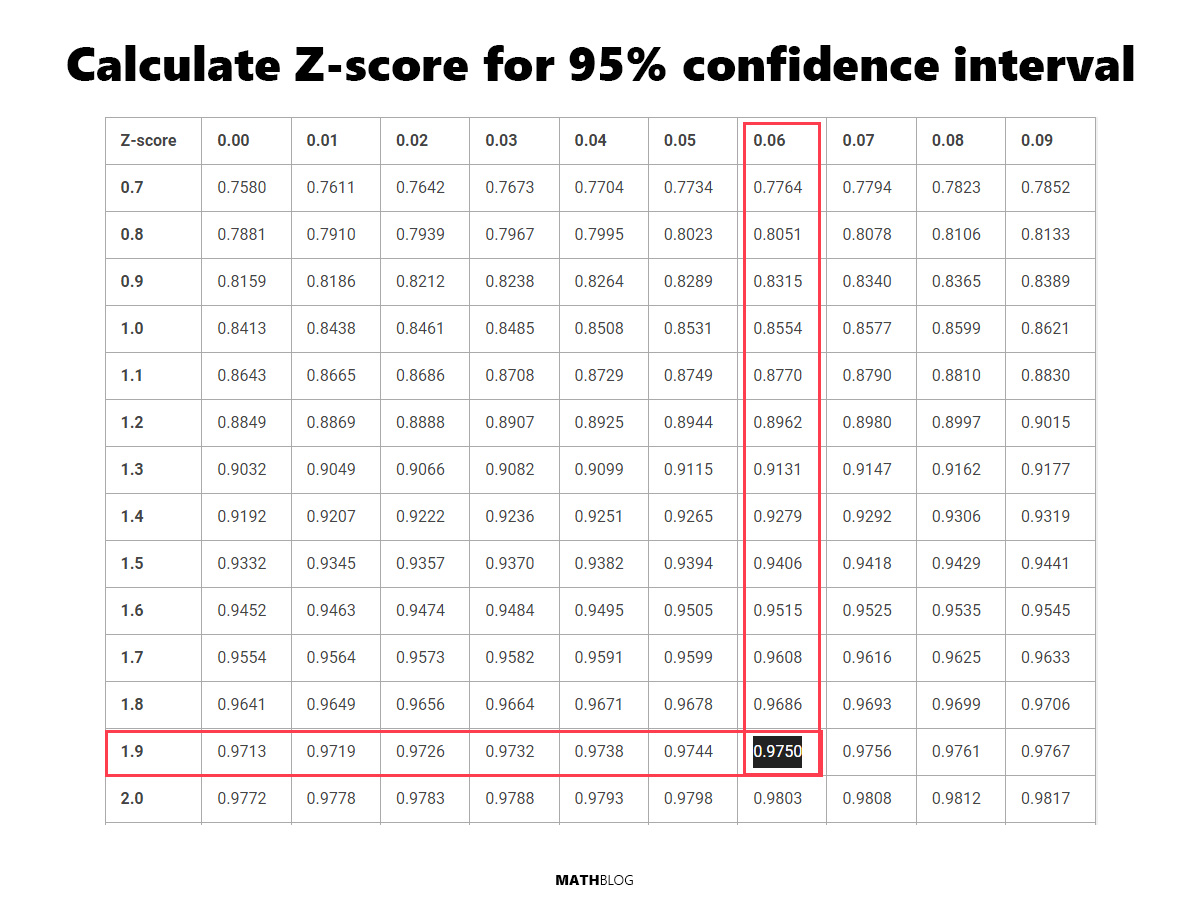
For a 95% confidence interval, the critical Z-score value is approximately 1.96. This value corresponds to the point in a standard normal distribution where 95% of the data falls between -1.96 and +1.96 standard deviations from the mean.
The formula for a confidence interval (for a large sample size, where the population standard deviation is known or approximated by sample standard deviation) is:
$CI = bar{X} pm Z* (sigma / sqrt{n})$
Where:
- $CI$ is the confidence interval.
- $bar{X}$ (X-bar) is the sample mean (e.g., average accuracy of a drone’s RTK GPS system over a test flight).
- $Z*$ is the critical Z-score for the desired confidence level (1.96 for 95%).
- $sigma$ is the population standard deviation (or sample standard deviation for larger samples).
- $n$ is the sample size (number of measurements).
The 95% confidence interval is crucial for validating the performance claims of drone systems and their underlying algorithms. For example, if an AI-powered autonomous drone claims to detect obstacles with a certain accuracy, a 95% confidence interval around that accuracy metric would give a practical range for its true performance, acknowledging the inherent variability in real-world conditions. This allows developers and operators to understand the statistical boundaries of their technology’s capabilities.
Ensuring Precision in Drone Sensor Data
The foundation of any advanced drone operation—be it autonomous navigation, precise mapping, or intelligent decision-making—rests squarely on the accuracy and reliability of its sensor data. Z-scores and 95% confidence intervals are critical tools for quantifying and validating this sensory input, moving beyond anecdotal performance observations to statistically robust assessments.
Calibrating GPS Accuracy for Autonomous Navigation
Global Positioning Systems (GPS) are central to a drone’s ability to navigate autonomously, maintain stable flight paths, and execute predefined missions. However, raw GPS data is subject to various errors, including atmospheric interference, multipath signals, and satellite clock inaccuracies. Technologies like Real-Time Kinematic (RTK) or Post-Processed Kinematic (PPK) significantly enhance GPS precision, but even these sophisticated systems have inherent variability.
When calibrating a drone’s GPS module or evaluating the performance of an RTK system, engineers collect numerous position measurements at a known fixed point. The mean of these measurements represents the average observed position, while the standard deviation reflects the spread of these readings. A Z-score can then be used to flag individual outlier readings that deviate significantly from the mean, potentially indicating a temporary signal loss or interference event.
More importantly, a 95% confidence interval can be constructed around the mean of these positional errors (e.g., horizontal or vertical error). If, for instance, a series of 100 measurements yields an average horizontal error of 2 cm with a standard deviation of 1 cm, the 95% confidence interval might suggest that the true average horizontal error lies between 1.8 cm and 2.2 cm. This interval is invaluable: it provides a statistically sound range for the system’s actual performance, rather than just a single point estimate, which is critical for safety-of-flight assessments and mission planning for high-precision tasks like surveying or infrastructure inspection. Without this statistical certainty, claims of “centimeter-level accuracy” remain unsubstantiated and potentially misleading.
Validating IMU and Vision System Performance

Beyond GPS, Inertial Measurement Units (IMUs) and vision systems are vital for a drone’s attitude estimation, stabilization, and obstacle avoidance. IMUs, comprising accelerometers and gyroscopes, provide crucial data on rotation and linear acceleration, while vision systems (cameras) contribute to visual odometry, SLAM (Simultaneous Localization and Mapping), and object detection.
For IMU performance validation, individual sensor readings (e.g., gyroscope drift rates or accelerometer biases) can be assessed using Z-scores to identify faulty sensors or transient anomalies that could compromise flight stability. For a batch of IMUs, collecting calibration data allows for the calculation of average error and standard deviation. A 95% confidence interval around these error metrics provides manufacturers with a reliable estimate of the typical performance range of their IMU units. This helps in setting realistic performance expectations and in performing quality control during manufacturing.
Vision systems, especially those employing AI for object detection or classification, rely heavily on statistical validation. When testing an AI-powered obstacle avoidance system, repeated trials will yield varying detection accuracies or false positive rates. A 95% confidence interval around the observed average detection rate allows developers to state with statistical confidence the true performance range of their algorithm. For example, if a system detects wires with 90% accuracy in a test, but the 95% confidence interval is [85%, 95%], it indicates that in 95% of similar real-world scenarios, the true accuracy would likely fall within this range. This statistical rigor is essential for building trust and ensuring the robust deployment of autonomous capabilities.
Quantifying Reliability in Mapping and Autonomous Systems
The utility of drones extends significantly into data acquisition for mapping, surveying, and the implementation of advanced autonomous functionalities. In these domains, quantifying the reliability and precision of the generated outputs is paramount, and Z-scores alongside 95% confidence intervals serve as critical validation tools.
Assessing Georeferencing Accuracy in Photogrammetry
Drone-based photogrammetry and remote sensing are revolutionary for creating high-resolution 2D maps (orthomosaics) and 3D models (digital elevation models, point clouds). The accuracy of these products hinges on precise georeferencing—the process of aligning imagery with real-world geographic coordinates. Ground Control Points (GCPs) are often used to improve and validate this accuracy.
When assessing the georeferencing accuracy of a generated map, survey points (either GCPs or independent checkpoints) are measured against their known true coordinates. The differences (errors) in X, Y, and Z directions are then analyzed. A Z-score can be employed to identify individual checkpoints where the deviation from the true position is unusually large, potentially indicating a measurement error in the field or a localized distortion in the photogrammetric model.
More broadly, a 95% confidence interval is indispensable for providing a statistically sound statement of the overall mapping product’s accuracy. For instance, after processing hundreds of checkpoints, if the average horizontal RMSE (Root Mean Square Error) is 3 cm, a 95% confidence interval might be calculated as [2.8 cm, 3.2 cm]. This interval signifies that with 95% confidence, the true average horizontal error of the entire map product lies within this range. Surveyors and engineers rely on such confidence intervals to understand the fitness-for-purpose of the map data for specific applications, whether it’s land surveying, construction monitoring, or environmental assessment, where even small inaccuracies can have significant implications.
Performance Metrics for AI-Powered Obstacle Avoidance
Autonomous flight, particularly in complex or dynamic environments, necessitates robust obstacle avoidance systems. Many modern drones employ AI and machine learning algorithms to process sensor data (from cameras, lidar, ultrasonic sensors) and identify potential collisions. Evaluating the performance of these AI models requires statistical rigor.
During the development and testing phases, an autonomous drone might undergo thousands of simulated or real-world encounters with various obstacles. Key performance metrics include the detection rate, false positive rate, and reaction time. For example, if an AI system is designed to detect power lines, its performance across numerous trials will vary.
A Z-score could identify an abnormally long reaction time in a specific test scenario, potentially highlighting an edge case where the AI struggles. However, a 95% confidence interval offers a more comprehensive understanding of the system’s overall reliability. If testing reveals an average detection rate of 97% for power lines, and the 95% confidence interval for this rate is calculated as [95.5%, 98.5%], it provides critical insight. This interval communicates that while 97% is the observed average, the system’s true performance under similar operational conditions is expected to fall within 95.5% to 98.5% with high confidence. Such intervals are crucial for regulatory bodies, drone manufacturers, and end-users in assessing the safety and operational limits of AI-driven autonomous features, moving beyond single-point estimates to a more realistic and statistically validated performance profile.
Practical Implications for Drone Innovation
The application of Z-scores and 95% confidence intervals transcends theoretical statistical exercises, directly impacting the practical development, deployment, and operational decision-making within drone innovation. These tools transform raw data into actionable insights, fostering a culture of evidence-based design and reliable performance.
Enhancing Decision-Making in Critical Missions
For critical drone missions, such as search and rescue, industrial inspection of high-value assets, or autonomous delivery, the margin for error is often extremely thin. The ability to quantify the reliability of drone systems and their data outputs using Z-scores and confidence intervals directly enhances operational decision-making.
Consider a drone conducting a structural integrity inspection of a bridge using thermal imaging. If the thermal camera’s calibration shows that temperature readings have a 95% confidence interval of $pm$1.5$^circ$C around the true value, this information is vital for engineers interpreting the thermal data to identify potential structural anomalies. They know the precision limits of their data, preventing misinterpretation due to sensor variability.
In autonomous search and rescue, a drone equipped with AI for object recognition might be tasked with identifying survivors. If the AI’s detection probability has a 95% confidence interval, mission planners can understand the likelihood of missing a target and factor this into search patterns or decide when to deploy secondary verification methods. This statistical understanding allows for more informed risk assessments and the development of robust contingency plans, ultimately increasing the success rate and safety of high-stakes operations.
Driving Robustness in Next-Generation UAV Development
The journey from prototype to production for advanced UAVs is iterative, characterized by continuous testing, data collection, and refinement. Z-scores and confidence intervals are integral to this developmental process, driving the creation of more robust and dependable next-generation drone technologies.
During the development of new flight control algorithms for enhanced stability or novel autonomous navigation capabilities, engineers collect vast datasets from flight tests. By applying Z-scores, they can quickly identify specific instances of unexpected behavior or performance deviations that might indicate flaws in the algorithm or hardware. This allows for targeted debugging and optimization.
Furthermore, the 95% confidence interval provides a powerful benchmark for validating improvements. If a new algorithm is designed to reduce GPS drift, test flights will generate new drift data. Comparing the 95% confidence interval of the drift from the old algorithm to that of the new one offers a statistically sound way to demonstrate the improvement. A narrower confidence interval, for example, would concretely prove the enhanced precision. This quantitative feedback loop is essential for engineering teams to systematically refine their designs, make data-driven decisions about hardware selections, and ultimately build drones that consistently meet or exceed performance specifications. By embedding these statistical validation methods into the development lifecycle, drone manufacturers can deliver technologies that are not only innovative but also reliably perform in the complex and demanding environments they are designed to operate within.