
Vibrations are ubiquitous oscillatory motions that resonate through mechanical systems, and nowhere are their effects more critically felt than in the intricate world of flight technology. For unmanned aerial vehicles (UAVs), commonly known as drones, understanding and mitigating vibrations is not merely an engineering preference; it is fundamental to stable flight, accurate navigation, and reliable sensor operation. These seemingly innocuous tremors can profoundly degrade performance, undermine control systems, and compromise the integrity of critical data, directly impacting everything from a drone’s ability to maintain a steady hover to its precise execution of complex flight paths.
At its core, a vibration is a mechanical phenomenon where oscillations occur about an equilibrium point. In the context of a drone, these oscillations are rarely benign. They are an inherent byproduct of a system designed to generate thrust and maneuver through the air, creating a constant interplay of forces that, if unchecked, can lead to a cascade of technical issues.

The Ubiquitous Challenge of Vibrations in Aerial Platforms
The drone environment is a hotbed for vibration generation. Every component that contributes to lift and movement is a potential source, and these vibrations propagate throughout the airframe, affecting sensitive electronics and mechanical parts alike. Identifying the primary sources is the first step in understanding their impact on flight technology.
Primary Sources of Vibrational Energy
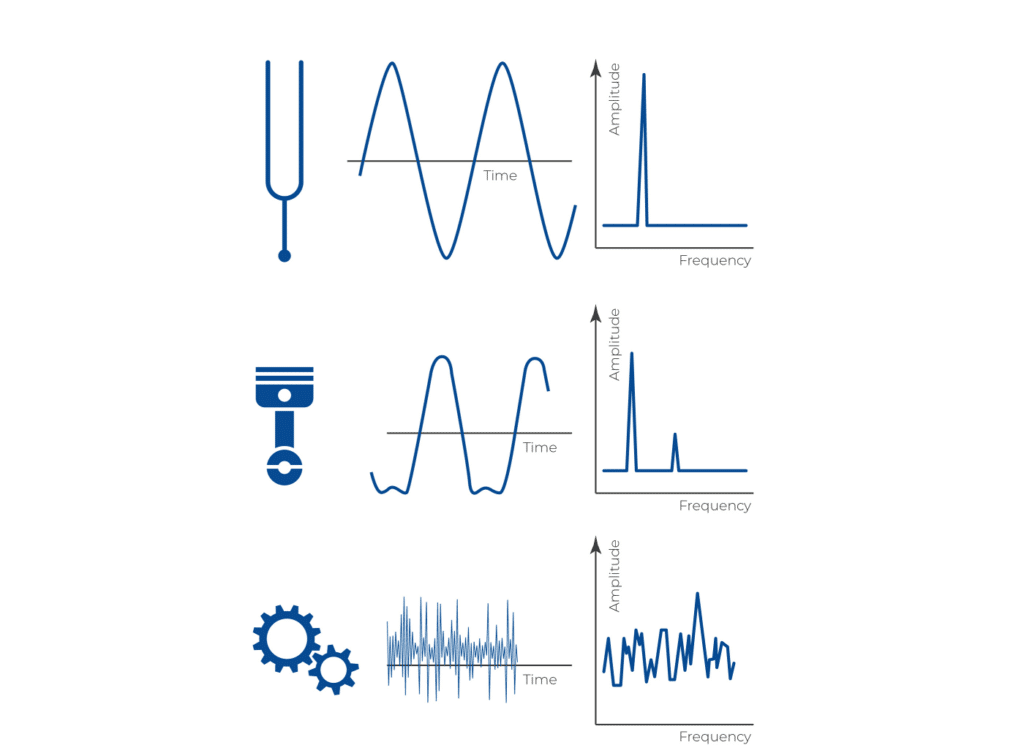
- Motors: Electric motors, while incredibly efficient, are rarely perfectly balanced. Minor imperfections in their manufacturing, uneven wear on bearings, or slight misalignments can lead to rotational imbalances. As these motors spin at thousands of revolutions per minute, these imbalances translate into rapid, high-frequency vibrations that transfer directly into the drone’s frame.
- Propellers: Propellers are perhaps the most significant single source of vibration. Any slight damage, such as a nick or bend, or even minor manufacturing inconsistencies, can throw them out of balance. Aerodynamic forces acting on the blades can also induce flutter and vibration, especially at higher speeds or during aggressive maneuvers. An unbalanced propeller creates asymmetrical thrust, leading to oscillations that must be actively countered by the flight controller.
- Structural Resonance: Every physical structure has natural resonant frequencies. If the vibrations generated by motors or propellers happen to coincide with the drone’s structural resonance frequency, the amplitude of the vibrations can amplify dramatically, leading to severe instability and potential component damage.
- Aerodynamic Turbulence: As a drone moves through the air, it interacts with air currents and creates its own turbulent wake. These aerodynamic forces can induce vibrations in the frame, especially on control surfaces or flexible parts, further contributing to the overall vibrational noise signature.
These mechanical oscillations are not isolated; they travel through the drone’s structure, reaching the very heart of its flight technology: the sensors and control systems.
Direct Impact on Flight Stability and Control Systems
The most immediate and critical impact of vibrations is on a drone’s ability to maintain stable flight and respond accurately to control inputs. The core components responsible for flight stabilization are incredibly sensitive to these physical disturbances.
Distorting the Flight Controller’s Perception
At the heart of every modern drone’s flight technology is the Inertial Measurement Unit (IMU), typically comprising accelerometers and gyroscopes. These sensors are tasked with precisely measuring the drone’s linear acceleration and angular velocity, respectively. They provide the flight controller with real-time data about the drone’s orientation, movement, and attitude.
- Accelerometers: Designed to detect gravitational forces and linear acceleration, accelerometers become “deafened” by vibrations. High-frequency oscillations can be misinterpreted as actual changes in the drone’s position or attitude, leading to noisy data. The flight controller then receives a distorted picture of what the drone is actually doing, confusing true movement with vibrational noise.
- Gyroscopes: Similarly, gyroscopes, which measure rotational velocity, are highly susceptible to vibrational interference. Rapid, small-amplitude oscillations can be registered as significant angular movements, even when the drone is perfectly stable. This “jitter” in gyroscope readings can cause the flight controller to overcompensate or misinterpret the drone’s true rotational state.
When the IMU’s data is compromised by vibrations, the flight controller loses its accurate sense of the drone’s reality. This often manifests as erratic flight behavior, a phenomenon sometimes colloquially referred to as “toilet-bowling,” where the drone drifts or wobbles erratically instead of maintaining a stable position. In severe cases, it can lead to a complete loss of control.
Affecting PID Loops and Control Algorithms
Modern flight controllers utilize sophisticated Proportional-Integral-Derivative (PID) control loops and other advanced algorithms to maintain stability. These algorithms constantly compare the drone’s current state (as reported by the IMU) with its desired state and calculate appropriate adjustments to motor speeds to correct any discrepancies.
- Noisy Data and Overcompensation: When the IMU feeds noisy, vibration-corrupted data into the PID loops, the algorithms struggle to differentiate between genuine movement and vibrational artifacts. The controller may attempt to “correct” for phantom movements, leading to rapid, unnecessary changes in motor thrust. This overcompensation can exacerbate oscillations, consume more power, and make the drone feel sluggish or unpredictable to control.
- Destabilization: In extreme scenarios, the feedback loop can become unstable. The controller might enter a positive feedback cycle, where its attempts to correct for perceived vibrations actually induce more severe vibrations, leading to an uncontrollable oscillation known as “fly-aways” or crashes.
Compromising Navigation and Sensor Accuracy

Beyond immediate flight stability, vibrations cast a long shadow over the accuracy and reliability of other crucial flight technology systems, particularly those related to navigation and advanced sensing.
GPS Signal Degradation and Positional Drift
While GPS receivers themselves are not direct vibration sensors, vibrations can indirectly impact their performance and the precision of positional data.
- Antenna Interference: Physical vibrations can cause slight movements or stress on the GPS antenna, potentially leading to intermittent signal reception or increased signal noise.
- Data Fusion Errors: More significantly, GPS data is often fused with IMU data (via techniques like Kalman filtering) to provide a more robust and accurate estimate of the drone’s position and velocity. If the IMU data is corrupted by vibrations, the combined positional estimate will also suffer, leading to increased positional drift, less accurate waypoint navigation, and difficulty in maintaining precise hover positions.
- Barometer Fluctuations: Barometric pressure sensors, critical for accurate altitude hold, can be affected by vibrations. These oscillations can create localized air pressure fluctuations around the sensor, leading to erroneous altitude readings and a “bouncy” altitude hold.
Advanced Sensor Interference
Vibrations can also impede the performance of other specialized sensors increasingly found in advanced drone flight technology:
- Magnetometers: These sensors detect the Earth’s magnetic field to determine the drone’s heading. Vibrations can induce magnetic noise through mechanical stress on the drone’s structure or by causing subtle movements in nearby electronic components, leading to inaccurate compass readings and compromised heading stability.
- Lidar and Ultrasonic Sensors: Sensors used for obstacle avoidance, precision landing, or terrain following (e.g., LiDAR, ultrasonic) rely on accurate distance measurements. Vibrations can cause these sensors to shake or move rapidly, introducing noise into their readings and reducing their effective range or accuracy. This can lead to missed obstacles or unreliable landing procedures.
Engineering Solutions and Mitigation Strategies
Addressing vibrations requires a multi-faceted approach, combining intelligent design, physical isolation, and sophisticated software processing. The goal is to minimize vibration at its source, prevent its transmission to sensitive components, and filter out any remaining noise from sensor data.
Passive Vibration Damping
Passive damping involves physical isolation techniques designed to absorb or dissipate vibrational energy before it reaches critical components.
- Anti-Vibration Mounts: This is the most common and effective passive strategy. Flight controllers, GPS modules, and other sensitive electronics are mounted on soft rubber grommets, gel pads, or specialized damping platforms. These materials convert the mechanical energy of vibrations into heat, effectively isolating the component from the oscillating airframe.
- Material Selection and Frame Design: Drone frames can be designed with materials that have inherent vibration-damping properties or with structural geometries that absorb and dissipate vibrational energy more effectively. Flexible mounting points for motors can also help reduce the transmission of motor-induced vibrations into the main frame.
- Component Balancing: Ensuring that propellers are perfectly balanced (dynamically and statically) is crucial. Similarly, high-quality motors with precise manufacturing tolerances and well-maintained bearings will produce significantly fewer vibrations. Regular inspection and replacement of worn or damaged propellers and motors are essential.
Software-Based Compensation
Even with effective passive damping, some residual vibration noise will always reach the sensors. This is where sophisticated software algorithms within the flight controller play a critical role.
- Digital Filtering: Low-pass filters are universally applied to IMU sensor data. These digital filters effectively remove high-frequency noise signatures associated with vibrations, allowing the flight controller to process a cleaner signal that more accurately represents the drone’s true motion. Advanced adaptive filtering techniques can even adjust their parameters in real-time to cope with varying vibration profiles.
- Kalman Filters and Sensor Fusion: Kalman filters and similar sensor fusion algorithms are designed to combine data from multiple, noisy sensors (e.g., accelerometers, gyroscopes, GPS, barometer) to produce a single, statistically optimal estimate of the drone’s state. While not directly removing vibrations, these algorithms are highly robust to noise and can significantly improve the accuracy of state estimation even in the presence of moderate vibration. They weight sensor inputs based on their perceived accuracy, effectively reducing the influence of noisy IMU data when other sensors (like GPS) are more reliable.
- Vibration Compensation Algorithms: Some advanced flight controllers incorporate specific algorithms that attempt to model and actively compensate for known vibration patterns, using sophisticated mathematical models to subtract the estimated vibration component from the raw sensor data.
Design and Maintenance Best Practices
Preventing vibrations starts with careful design and continues with diligent maintenance.
- Quality Components: Investing in high-quality motors, propellers, and frame materials can significantly reduce baseline vibration levels.
- Proper Assembly: Ensuring all screws are tightened to spec, components are securely mounted, and cables are properly managed (not taut or rubbing against vibrating parts) prevents new vibration sources from emerging.
- Regular Inspection: Routine checks for propeller damage, motor bearing wear, loose connections, and structural integrity are crucial for maintaining a vibration-free drone.
In essence, “what is vibrations” in the context of flight technology is a fundamental question whose answer underpins the very possibility of stable, precise, and reliable aerial operations. From the subtle hum of an unbalanced motor to the sophisticated algorithms filtering sensor data, vibrations are a constant antagonist, yet through careful engineering and advanced technological solutions, they are a challenge that has been increasingly met and overcome.