
The Fundamental Concept of Vectors in Flight
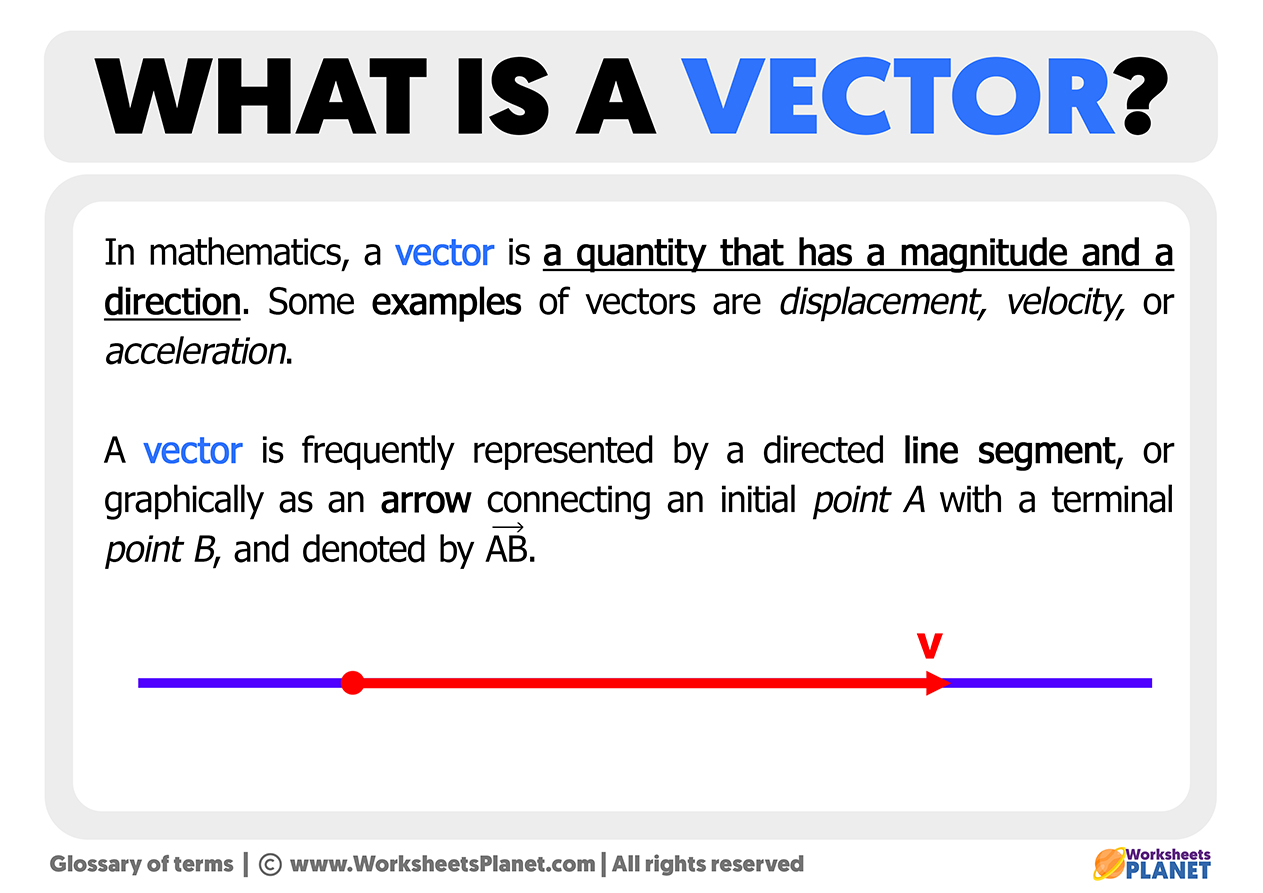
In the intricate world of flight technology, particularly concerning the precision and agility of modern drones, understanding vectors is not merely advantageous—it’s absolutely indispensable. At its core, a vector is a mathematical entity that possesses both magnitude (size or quantity) and direction. This dual characteristic makes vectors the perfect language for describing physical phenomena in three-dimensional space, which is precisely where drones operate. Unlike simple numerical values, vectors provide a complete picture of motion, force, position, and orientation, enabling the sophisticated control systems that define advanced flight.
Defining Vectors: Magnitude and Direction
Imagine a drone lifting off. Its vertical ascent isn’t just a speed; it’s a speed in a specific direction—upwards. This combination is a vector quantity: velocity. The “magnitude” part of this velocity vector would be the drone’s speed (e.g., 5 meters per second), while the “direction” specifies that it’s moving straight up along the Z-axis. Similarly, if a gust of wind pushes the drone, that force also has a strength (magnitude) and a specific direction. Without knowing both, accurately predicting the drone’s response or correcting its course would be impossible. Vectors are typically represented geometrically as arrows, where the length of the arrow signifies the magnitude and the way the arrow points indicates the direction.
Scalars vs. Vectors: Why Direction Matters
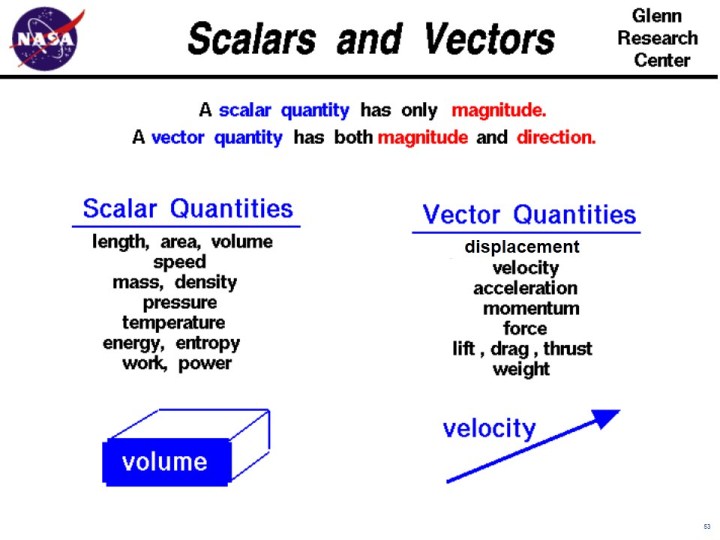
To fully appreciate vectors, it’s helpful to contrast them with scalars. A scalar quantity has only magnitude. Examples include temperature, mass, time, or the speed of a drone without specifying its heading. For instance, saying a drone is traveling at “10 meters per second” is a scalar statement. While useful, it doesn’t tell us where the drone is going. Is it moving north, east, up, or in a complex diagonal path? This crucial piece of information is provided by direction, transforming the scalar speed into a vector velocity. In flight technology, almost every critical parameter—from the forces generated by propellers to the drone’s precise location relative to a target—requires the directional insight that only vectors can provide. Ignoring direction would lead to uncontrolled, unpredictable flight, making any form of autonomous or stable operation impossible.
Representing Vectors: From Math to Reality
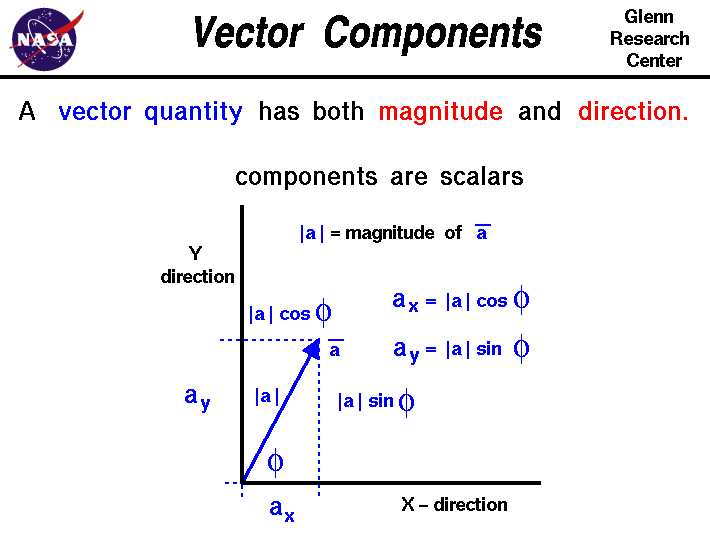
Mathematically, vectors can be represented in several ways. In a two-dimensional plane, a vector might be represented by its components along the x and y axes, such as (x, y). In the 3D space relevant to drones, this extends to (x, y, z). These components describe how much of the vector’s magnitude lies along each axis. For instance, a drone’s velocity vector (Vx, Vy, Vz) tells its speed in the forward/backward, left/right, and up/down directions, respectively. These numerical representations are critical for onboard flight controllers, allowing them to perform vector addition (e.g., combining drone velocity with wind velocity), subtraction (e.g., calculating relative velocity), and multiplication (e.g., scaling a force vector) at lightning speed. These computations form the backbone of a drone’s ability to interpret sensor data, execute commands, and maintain stable flight.
Vectors in Drone Navigation and Positioning
The ability of drones to navigate autonomously or precisely follow flight paths is almost entirely dependent on the continuous processing and manipulation of various vector quantities. From knowing its exact location in the world to understanding its current movement and orientation, vectors provide the foundational data structures for a drone’s spatial awareness.
GPS and Positional Vectors
Global Positioning System (GPS) is perhaps the most obvious application of vectors in drone navigation. A GPS receiver on a drone calculates its position in 3D space by triangulating signals from multiple satellites. This position is effectively a position vector originating from a global reference point (like the center of the Earth) to the drone’s current coordinates (latitude, longitude, altitude). When a pilot sets a waypoint or plans a flight path, these are essentially sequences of target position vectors. The drone’s flight controller then calculates the necessary movement vectors (direction and magnitude of travel) required to transition from its current position vector to the next target position vector, ensuring precise execution of the mission.
Velocity and Acceleration Vectors
Beyond static position, drones must constantly understand their dynamic state. Velocity, as previously discussed, is a vector representing both speed and direction. The drone’s onboard sensors (like accelerometers) measure acceleration, which is also a vector, indicating the rate of change of velocity. If a drone is accelerating upwards, its acceleration vector points up. If it’s turning, the acceleration vector will point towards the center of the turn. By integrating acceleration vectors over time, the flight controller can estimate the drone’s current velocity. By integrating velocity vectors, it can estimate its current position. This constant feedback loop of positional, velocity, and acceleration vectors is vital for stable flight, enabling the drone to maintain a desired speed, stop precisely, or follow complex trajectories with accuracy.
Orientation and Attitude Vectors (Roll, Pitch, Yaw)
For a drone, knowing its absolute position is one thing, but knowing how it’s oriented in space is equally critical. This is described by attitude or orientation vectors. The three primary rotational degrees of freedom for an aircraft are roll (rotation around the front-to-back axis), pitch (rotation around the side-to-side axis), and yaw (rotation around the vertical axis). Each of these can be represented as a vector indicating the axis of rotation and the angle of rotation around it. Gyroscopes and magnetometers provide data that, when combined and processed, yield the drone’s current attitude vectors. These are compared to desired attitude vectors (e.g., level flight, or a specific angle for a cinematic shot). The difference between the actual and desired attitude vectors drives the control system to adjust motor speeds and propeller thrust, correcting the drone’s orientation to maintain stability and execute maneuvers.
Stabilizing Flight: Vectors in Control Systems
The inherent instability of multirotor drones necessitates sophisticated control systems that continuously analyze and respond to flight dynamics. Vectors are the cornerstone of these systems, enabling the drone to interpret forces, correct deviations, and maintain a stable, predictable flight.
Forces and Torques as Vectors
Every physical interaction affecting a drone can be described using vectors. The thrust generated by each propeller is a force vector, pushing the drone in a specific direction. Gravity is a force vector pulling it downwards. Wind is a force vector pushing it laterally. When these force vectors are summed, they yield a net force vector on the drone, determining its overall acceleration. Similarly, torques (rotational forces) are also vector quantities. An imbalance in propeller thrusts creates torque vectors that cause the drone to roll, pitch, or yaw. The flight controller’s primary job is to constantly calculate these force and torque vectors, both desired and actual, and make adjustments to maintain equilibrium or execute a maneuver. Understanding these vector interactions allows the drone to counteract external disturbances and achieve precise control.
PID Control and Vector Feedback
Proportional-Integral-Derivative (PID) controllers are widely used in drone flight systems for stabilization. A PID controller works by calculating an “error” value, which is the difference between a desired state and the current measured state. For a drone, these states are often vector quantities: a desired attitude vector versus the current attitude vector, or a desired velocity vector versus the current velocity vector. The PID controller then uses this error vector to calculate an appropriate control output vector (e.g., motor speed adjustments) that will reduce the error. The “proportional” term acts on the current error, the “integral” term accounts for past errors (reducing steady-state errors), and the “derivative” term anticipates future errors based on the rate of change of the current error. This vector-based feedback loop is executed thousands of times per second, allowing the drone to maintain stability even in turbulent conditions.
Counteracting Disturbances with Vector Adjustments
Wind gusts, sudden changes in payload, or even minor manufacturing inconsistencies can act as disturbances, pushing a drone off its intended course or orientation. The flight controller, using its array of sensors (IMUs, gyroscopes, accelerometers), constantly measures the drone’s actual attitude, velocity, and position vectors. When these deviate from the desired reference vectors, the control system calculates the necessary counteracting force and torque vectors. For example, if a drone begins to drift sideways due to wind (an unwanted velocity vector), the flight controller will adjust the thrust of specific motors to generate an opposing force vector, bringing the drone back to its intended path. This continuous, real-time vector analysis and adjustment is what gives drones their remarkable stability and precision.
Advanced Vector Applications in Flight Technology
Beyond fundamental stabilization, vectors play a crucial role in enabling more sophisticated drone capabilities, pushing the boundaries of what these aerial platforms can achieve.
Obstacle Avoidance and Trajectory Planning
For autonomous flight, drones must not only navigate to a destination but also avoid collisions. This involves complex vector computations. LiDAR, ultrasonic, or stereo vision sensors detect obstacles, providing their distance and direction relative to the drone—essentially, obstacle position vectors. The drone’s flight controller then calculates a collision risk based on the drone’s current velocity vector and the obstacle’s position vector. If a collision is imminent, the system must generate a new, safe trajectory. This re-planning involves calculating a series of intermediate waypoint vectors that guide the drone around the obstacle while still aiming towards the ultimate destination. The algorithms leverage vector mathematics to find optimal, smooth paths that respect the drone’s dynamic constraints (maximum acceleration, turning radius, etc.).
Sensor Fusion and State Estimation
Modern drones are equipped with a multitude of sensors, each providing a piece of the puzzle regarding the drone’s state. GPS provides absolute position vectors, IMUs (Inertial Measurement Units) provide acceleration and angular velocity vectors, magnetometers provide heading vectors, and barometers provide altitude scalars. No single sensor is perfect; each has its own noise and inaccuracies. Sensor fusion algorithms, such as Kalman filters or Extended Kalman Filters, use vector mathematics to combine these disparate sensor readings into a more accurate and reliable estimate of the drone’s overall state (position, velocity, attitude, and biases). By weighting each sensor’s contribution based on its known accuracy and cross-referencing information, these algorithms produce a more robust set of state vectors that are essential for precise navigation and control, especially when GPS signals are weak or unavailable.
Pathfinding and Waypoint Navigation
Advanced pathfinding for drone delivery, mapping missions, or surveillance often involves navigating complex environments with multiple waypoints and dynamic obstacles. Algorithms like A* (A-star) or RRT (Rapidly-exploring Random Tree) utilize vector representations of the environment (e.g., occupancy grids where each cell has a vector indicating its traversability) and the drone’s capabilities. A sequence of target position vectors (waypoints) defines the mission. The drone’s control system, in turn, calculates the necessary velocity and acceleration vectors to smoothly transition between these waypoints, optimizing for factors like speed, energy efficiency, or obstacle avoidance. These planning algorithms continuously update their vector-based path in real-time, adapting to new information or changing environmental conditions.
The Future of Vector-Driven Flight
As flight technology continues to evolve, the reliance on vectors will only deepen. Future innovations in drone autonomy, swarm intelligence, and human-drone interaction will demand even more sophisticated vector processing. Real-time path optimization in highly dynamic environments, precise formation flying for drone light shows, and complex manipulation tasks will require advanced algorithms capable of rapidly processing and generating multi-dimensional vector fields. The development of AI-driven flight systems, predictive control, and digital twin technology will increasingly use vectors to model, simulate, and control every aspect of a drone’s interaction with its environment. Ultimately, a thorough understanding and masterful application of vectors will remain at the forefront of pushing the boundaries of what aerial platforms can achieve, driving safer, more efficient, and more intelligent flight operations.