
Vector projection, at its essence, is a fundamental mathematical operation that reveals how much one vector “points in the direction of” another. It decomposes a given vector into two components: one that is parallel to a reference vector, and another that is perpendicular to it. The parallel component is the vector projection. While an abstract concept on its own, its practical applications form the bedrock of many sophisticated technologies, particularly within the realm of drone innovation, enabling the advanced capabilities we see in autonomous flight, AI-driven features, and precise environmental mapping. In the complex world of drones, where every movement, every sensor reading, and every decision is a calculation based on spatial relationships, understanding vector projection is key to unlocking the true intelligence of these flying robots.
The Fundamental Concept Behind Smart Drone Operations
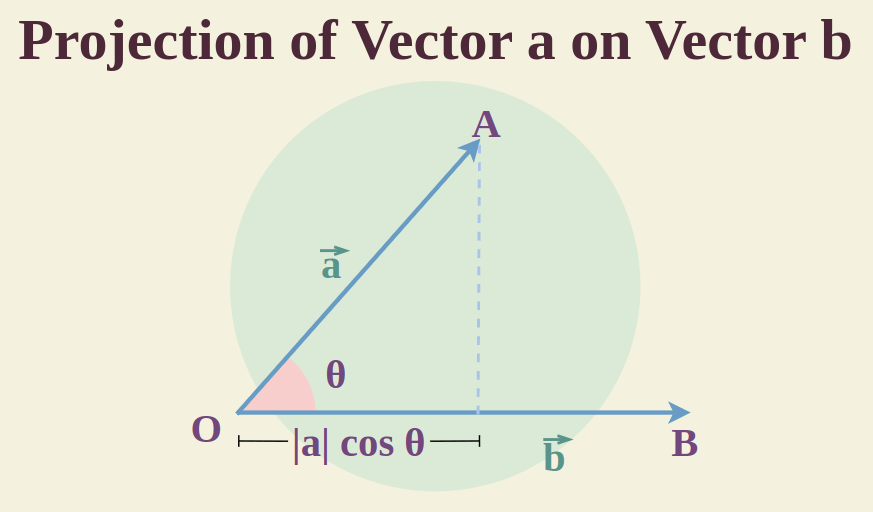
To grasp the profound impact of vector projection on drone technology, it’s crucial to first internalize its core definition. Imagine a light source directly above a vector, casting its “shadow” onto another vector or a line. That shadow is, in essence, the vector projection. It quantifies the extent to which one vector influences or aligns with another, providing a scalar value (the magnitude of the projection) and a directional component. This seemingly simple operation becomes an indispensable tool for algorithms that govern everything from a drone’s stable hover to its ability to autonomously navigate a dynamic environment.
Visualizing Directional Influence
Consider a drone moving through the air. Its velocity can be represented as a vector. If we want to understand how much of that velocity is contributing to its forward motion relative to a specific wind direction, or how much is contributing to its ascent, vector projection provides the answer. It allows us to isolate the component of a vector that acts along a particular direction. For instance, if a drone’s main camera is pointed forward, and the drone is crabbing sideways due to wind, vector projection can help determine the actual “forward” component of its movement relative to the camera’s perspective, essential for stable video capture or accurate object tracking. Similarly, when a drone needs to maintain a certain altitude, its vertical velocity vector can be projected onto the upward direction, allowing the flight controller to determine if it’s gaining or losing height and by how much. This directional decomposition is not just theoretical; it translates directly into actionable data for the drone’s onboard systems.
Quantifying Alignment: The Mathematical Basis
Mathematically, the projection of vector A onto vector B is given by the formula: proj_B A = ((A ⋅ B) / ||B||²) * B, where A ⋅ B is the dot product of A and B, and ||B|| is the magnitude of B. The dot product A ⋅ B itself is a scalar value that indicates the extent to which two vectors point in the same direction. A large positive dot product means they are largely aligned, a negative one means they are in opposite directions, and zero means they are orthogonal (perpendicular).
The projection operation essentially scales the reference vector B by a factor derived from the dot product, effectively giving us a new vector that points in the same direction as B but has a magnitude that reflects A‘s alignment with B. This scalar component, (A ⋅ B) / ||B||, is particularly useful as it represents the signed length of the projection. This mathematical precision is critical for drones. Every sensor reading — be it from an accelerometer, gyroscope, or GPS — generates data in vector form. To make sense of these diverse inputs and integrate them into a unified understanding of the drone’s state and environment, algorithms constantly employ vector projection to align and interpret these data streams within a common reference frame. Without this mathematical tool, the drone’s perception of its own motion and the world around it would be chaotic and unusable for intelligent decision-making.
Precision Navigation and Control in Autonomous Systems
In the realm of autonomous drones, precision is paramount. Whether executing a pre-programmed flight path, navigating through a complex urban canyon, or performing intricate aerial maneuvers, the drone’s ability to accurately perceive its position, orientation, and velocity relative to its environment is entirely dependent on sophisticated mathematical operations. Vector projection plays a pivotal role in enabling this precision, forming the backbone of advanced navigation and control algorithms.
Decomposing Sensor Inputs for Real-time Awareness
Drones are equipped with an array of sensors, each providing a piece of the puzzle regarding its current state. Inertial Measurement Units (IMUs) deliver raw acceleration and angular velocity data, while GPS provides global position. Barometers measure altitude, and optical flow sensors track ground movement. Each of these sensors inherently provides data in its own coordinate system or frame of reference. For the drone’s flight controller to process and fuse this disparate information, it must first be transformed into a common, consistent framework, typically the drone’s body frame or a global navigation frame.
Vector projection is indispensable here. For example, an accelerometer measures acceleration along its own internal axes. To determine the component of acceleration due to gravity, or the component contributing to forward thrust relative to the drone’s current orientation, the raw accelerometer vector is projected onto the estimated global “down” vector or the drone’s “forward” vector. Similarly, when GPS provides a velocity vector in global North-East-Down (NED) coordinates, this vector needs to be projected onto the drone’s body axes (forward-right-down) to inform the control loops responsible for motor commands. By continually projecting and decomposing these sensor inputs, the drone builds an accurate, real-time understanding of its own attitude, velocity, and position, which is critical for maintaining stability and executing precise maneuvers.
Predictive Pathing and Obstacle Avoidance Algorithms
Autonomous flight relies heavily on predictive capabilities. Drones must not only know where they are but also anticipate where they will be and where obstacles might be. Vector projection is integral to these predictive models and obstacle avoidance strategies. When a drone plans a path, it projects its current velocity vector and anticipated future velocity vectors onto the direction of its desired trajectory. This allows the flight controller to calculate exactly how much thrust is needed in specific directions to achieve the target path, minimizing deviations and ensuring smooth, efficient movement.
For obstacle avoidance, LiDAR or stereo vision systems generate point clouds or depth maps of the surrounding environment. An algorithm might identify a potential collision vector — a vector pointing from the drone towards an obstacle. The drone’s current velocity vector can then be projected onto this collision vector to determine if its current trajectory will lead to an impact and, if so, the magnitude of the impending collision. This information enables the system to calculate an avoidance maneuver, projecting a new desired velocity vector that steers clear of the obstacle while minimizing disruption to the overall flight plan. By continuously performing these projections, drones can dynamically adjust their paths in real-time, making autonomous navigation in complex environments a reality.

Enabling Advanced AI and Robotic Capabilities
The cutting-edge functionalities in drones, such as AI-driven object tracking, sophisticated mapping, and autonomous decision-making, are not merely products of powerful processors but are deeply rooted in advanced mathematical principles. Vector projection stands out as a critical tool that empowers these intelligent capabilities, allowing drones to interpret complex spatial relationships and react dynamically to their surroundings.
Dynamic Target Tracking and AI Follow Modes
AI Follow Mode, a popular feature in many consumer and professional drones, exemplifies the practical application of vector projection. When a drone is tasked with following a moving subject (a person, a car, or even another drone), it needs to constantly calculate the subject’s relative position and velocity, and then predict its future trajectory. Cameras and onboard sensors track the target, providing its observed position and movement vector. The drone then projects its own current position and velocity onto the target’s estimated movement vector. This allows the drone to:
- Determine Relative Position: Projecting the vector from the drone to the target onto various axes helps establish the target’s exact location relative to the drone (e.g., how far forward, to the side, or above).
- Predict Future Movement: By projecting the target’s velocity onto different directions, the drone can estimate where the target will be in the next few milliseconds or seconds.
- Plan Evasive/Following Maneuvers: The drone can then project its desired velocity vector to maintain a safe distance or a specific angle relative to the target, adjusting its own flight path to continuously align with the target’s movement.
This constant loop of observation, projection, and re-projection allows the drone to anticipate the target’s actions, ensuring smooth, stable tracking even when the subject performs unpredictable movements. Without vector projection, AI follow mode would struggle to maintain precise relative positioning and predictive capability, resulting in jerky movements or lost targets.
Environmental Mapping and 3D Reconstruction
For applications like surveying, agriculture, construction, and disaster response, drones equipped with LiDAR, photogrammetry cameras, and other remote sensing technologies are invaluable. These systems capture vast amounts of data about the environment, often from multiple angles and positions. To create accurate 2D maps or detailed 3D models, these disparate data points must be stitched together and accurately placed in a common spatial framework. This is where vector projection is fundamental.
When a drone takes an image, each pixel corresponds to a specific point in the real world. The camera’s position and orientation (pose) are known, and the optical ray from the camera through that pixel extends into 3D space. To project this 3D point onto a 2D map or into a unified 3D model, the camera’s pose vector (its position and orientation) is used in conjunction with vector projection. For instance, in photogrammetry, image points from multiple overlapping photos are matched. The 3D position of a feature is determined by triangulating the intersecting rays from different camera positions. Each ray is a vector, and their intersection is found through complex vector calculations that inherently involve principles of projection to minimize error and find the most probable 3D coordinate.
Similarly, in LiDAR scanning, millions of laser points are collected. Each point represents a vector from the LiDAR sensor to a surface in the environment. To combine these points from various drone positions and construct a coherent 3D point cloud or mesh, these individual vectors must be projected into a global coordinate system. This ensures that features scanned from different angles and altitudes are accurately aligned, producing a seamless and precise digital representation of the real world. Without the mathematical rigor of vector projection, generating accurate, georeferenced maps and 3D models would be an insurmountable challenge.
Optimizing Performance and Stability in Complex Scenarios
Beyond fundamental navigation and advanced AI, vector projection contributes significantly to the optimization of a drone’s overall performance, particularly in maintaining stability and achieving precision under challenging flight conditions or when executing demanding tasks. This is crucial for both robust industrial applications and high-quality aerial cinematography.
Adaptive Flight Control and Stabilization
Modern drones are incredibly stable, even in gusty winds or during aggressive maneuvers. This stability is largely due to sophisticated flight control algorithms that continuously adjust motor thrusts based on real-time sensor feedback. Vector projection is a core component of these control loops. For example, a drone’s Inertial Measurement Unit (IMU) detects its current angular velocity (rotation) and linear acceleration. The flight controller then calculates a desired state, perhaps a perfectly level hover. The vector representing the drone’s actual orientation is compared with the desired orientation vector. Any deviation is quantified by projecting the error vector onto the axes of rotation, telling the controller exactly how much to correct for pitch, roll, and yaw.
In turbulent conditions, wind gusts impose external force vectors on the drone. The flight controller uses data from airspeed sensors or estimates wind velocity, then projects the drone’s current velocity vector onto the estimated wind direction. This allows the system to determine the precise component of its motion being affected by the wind and compensate accordingly, either by increasing thrust in a specific direction or by adjusting its attitude to counter the aerodynamic forces. This adaptive response, enabled by continuous vector projections, ensures the drone maintains its desired flight path and stability despite external disturbances, leading to smoother video footage and more reliable mission execution.

Multimodal Data Fusion for Enhanced Perception
Drones often integrate data from multiple types of sensors—GPS, IMU, barometer, magnetometers, vision cameras, LiDAR, and more—to build a comprehensive and robust understanding of their environment and state. This process, known as sensor fusion, is critical for enhancing perception, especially when individual sensors might be noisy, unreliable, or temporarily unavailable (e.g., GPS signal loss). Vector projection plays a vital role in fusing these diverse data streams.
Each sensor provides information in a different format and often in a different coordinate frame. To merge these inputs, algorithms use vector projection to translate and align them into a common framework. For instance, visual odometry algorithms process camera images to estimate the drone’s movement by tracking features. The displacement vectors derived from vision are then projected onto the IMU’s estimated position and velocity vectors. This process essentially weights and combines the information, allowing the system to leverage the strengths of each sensor while mitigating their weaknesses. If GPS signal is lost, the drone can rely more heavily on IMU and visual odometry data, projecting their outputs onto a short-term estimated trajectory to maintain accurate positioning. This multimodal fusion, underpinned by the precise mathematical alignment offered by vector projection, leads to more robust navigation, more accurate mapping, and overall enhanced perception, pushing the boundaries of what autonomous drones can achieve in increasingly complex and dynamic environments.