In the realm of advanced technology and innovation, particularly concerning autonomous systems like drones, understanding fundamental statistical concepts is paramount. One such concept, the uniform probability distribution, describes situations where all outcomes within a given range or set are equally likely. Far from being a mere theoretical exercise, this distribution provides a foundational model for analyzing system behavior, predicting sensor accuracy, and designing robust algorithms for autonomous flight, mapping, and remote sensing. Its simplicity belies its profound impact on how engineers and data scientists approach the complexities of real-world drone operations and data interpretation.
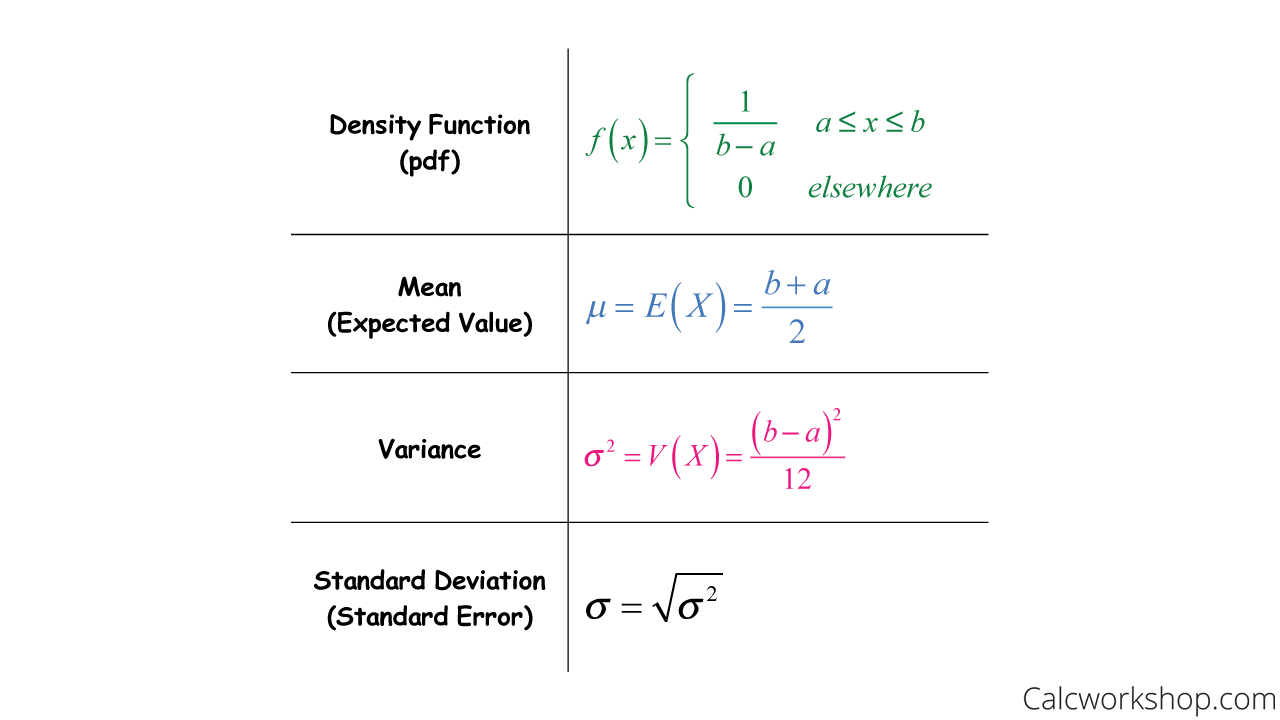
Defining Uniform Probability: The Basics
At its core, a uniform probability distribution signifies a scenario where every possible outcome across a defined interval or set has an identical chance of occurring. This stands in contrast to more common distributions like the normal (Gaussian) distribution, where outcomes cluster around a mean. The uniform distribution essentially represents a state of perfect impartiality or randomness within its boundaries, making it an invaluable tool for establishing baseline expectations or modeling noise in intricate systems.
Discrete Uniform Distribution Explained
When dealing with a finite set of distinct outcomes, we refer to a discrete uniform distribution. In this scenario, each individual outcome holds the exact same probability. Imagine a standard six-sided die: each face (1, 2, 3, 4, 5, 6) has an equal 1/6 chance of being rolled. There are no biases; the probability is spread evenly across all possibilities. In technological applications, this might model a system selecting one option from a limited, equally weighted set of actions, or a random identifier being assigned from a predefined pool. For instance, if an autonomous drone system needs to choose one of three pre-programmed emergency landing sites with no preference, a discrete uniform distribution could model this selection process. Each site has a 1/3 probability of being chosen, assuming all other factors are equal.
Continuous Uniform Distribution Explained
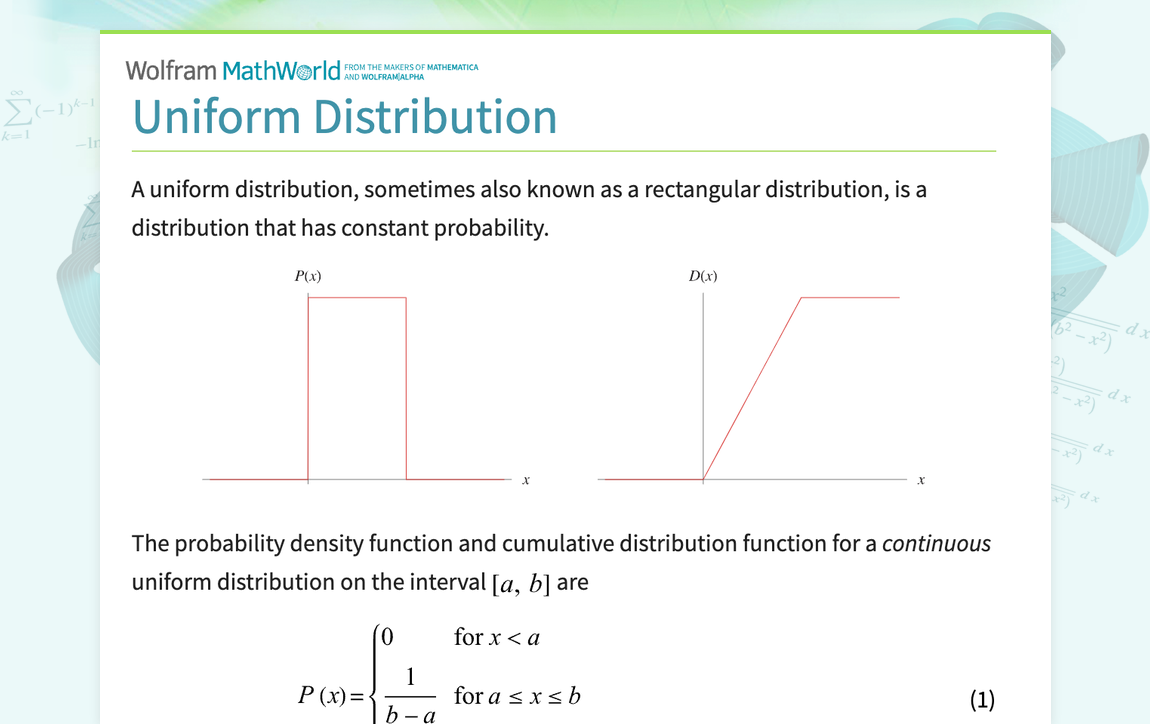
The continuous uniform distribution extends this concept to an infinite number of possible outcomes within a continuous interval. Here, instead of assigning probability to discrete points, it assigns probability density across an interval. While the probability of any single exact point occurring is infinitesimally small (approaching zero), the probability of an outcome falling within any sub-interval of a given length is constant across the entire distribution. Consider a drone’s GPS receiver: if its accuracy is stated as being within ±5 meters, and there’s no known bias, the actual error in any direction within that 10-meter range (e.g., -5m to +5m) might be modeled as continuously uniformly distributed. This implies that the chance of the actual position being off by 1 meter to the east is the same as being off by 1 meter to the west, or any other point within that symmetrical error bound. This characteristic is particularly useful for modeling uncertainties and errors where no specific value is more likely than another within the defined limits.
The Role of Uniformity in Tech & Innovation Paradigms
For technologies that push the boundaries of autonomy, precision, and data acquisition, such as advanced drones, understanding uniform probability is more than an academic exercise. It underpins the design of algorithms, the interpretation of sensor data, and the robustness of decision-making processes. In situations where inherent randomness is desired, or where the behavior of a component is assumed to be unbiased within certain limits, the uniform distribution provides a powerful initial model.
Connecting uniformity to system randomness and unpredictability is crucial. While engineers strive for deterministic and predictable systems, real-world environments introduce elements of randomness—from sensor noise to atmospheric turbulence to unforeseen obstacles. By modeling these unpredictable elements as uniformly distributed within certain boundaries, developers can create algorithms that are resilient and adaptive. For instance, in an AI follow mode, if the target’s unpredictable movements within a certain radius are assumed to be uniformly random, the drone’s predictive algorithms can establish a robust strategy that covers all likely positions with equal consideration, rather than betting on a statistically favored (but potentially non-existent) mean. This principle guides the development of fault-tolerant systems and simulations, allowing for a comprehensive evaluation of performance under diverse, yet bounded, random conditions.
Practical Applications in Drone Technology
The theoretical elegance of uniform probability distribution finds numerous practical applications within drone technology and innovation, influencing everything from sensor calibration to the intelligence of autonomous flight.
Sensor Noise and Error Bounds
One of the most critical areas where uniform probability distribution is applied is in characterizing sensor data. Drones rely on an array of sensors—GPS, IMU (Inertial Measurement Unit), barometers, magnetometers—each subject to inherent noise and potential inaccuracies. While some sensor errors might follow a normal distribution, others, particularly systematic errors or quantization errors within a defined range, can often be effectively modeled by a uniform distribution. For example, if a digital altimeter has a resolution of 0.1 meters, the actual error between the true altitude and the reported altitude might be uniformly distributed between -0.05 meters and +0.05 meters. Recognizing this allows flight control systems to account for these bounded errors, ensuring more stable navigation and precise altitude hold. Moreover, in advanced obstacle avoidance systems, if the detection range of a sensor is uniformly reliable within a specific distance but then drops off sharply, understanding this uniform operating characteristic is vital for defining safe flight parameters and triggering avoidance maneuvers effectively.
Optimized Sampling for Mapping and Remote Sensing
In applications like mapping, photogrammetry, and remote sensing, drones collect vast amounts of spatial data. To ensure comprehensive coverage and reduce biases in data acquisition, uniform sampling strategies are often employed. For instance, when planning a flight path for aerial mapping, ensuring that sample points for image capture are uniformly distributed across the target area helps guarantee that no section is over- or under-represented. This isn’t just about covering the area, but about collecting data that is statistically representative, avoiding “hot spots” of data collection that could skew analysis. In advanced remote sensing, algorithms might randomly (uniformly) select points within a detected anomaly zone for further high-resolution analysis, ensuring an unbiased investigation of the area of interest rather than focusing on a potentially misleading central point.
Autonomous Decision-Making and Path Generation
Autonomous flight systems, including those powering AI follow mode or advanced search and rescue drones, frequently encounter situations demanding robust decision-making under uncertainty. Uniform probability can be used in algorithms that generate potential flight paths or action sequences. For instance, when a drone needs to explore an unknown environment, it might generate a set of uniformly distributed waypoints within its immediate operational area to ensure systematic exploration rather than predictable, potentially inefficient, patterns. Furthermore, in collision avoidance scenarios where an immediate evasive action is required, an algorithm might uniformly sample potential escape vectors within safe parameters to find an optimal path, ensuring that all viable options are considered equally, rather than being biased towards a suboptimal ‘favorite’. This equal consideration of possibilities contributes to more resilient and adaptable autonomous behavior.
Robust Simulation and Testing Environments
Before a drone takes flight, its navigation, stabilization, and mission systems undergo rigorous testing in simulated environments. Uniform probability distribution is a cornerstone of creating realistic and comprehensive simulations. Engineers can inject uniformly distributed noise into sensor readings, simulate uniformly random wind gusts within predefined speeds, or model the unpredictable movement of targets or obstacles with uniform spatial distribution within a given area. This ensures that the drone’s algorithms are tested against a wide, unbiased spectrum of possible real-world conditions, rather than just a narrow set of expected scenarios. By validating system performance across a uniform spread of inputs, developers can build confidence in the drone’s ability to operate reliably and safely in dynamic and unpredictable operational environments.

Implications and Future Directions
The uniform probability distribution, while conceptually simple, serves as a powerful foundational tool in the evolving landscape of drone technology. Its applications extend from the microscopic analysis of sensor errors to the macroscopic design of intelligent autonomous systems. As drones become more sophisticated, capable of operating in increasingly complex and unpredictable environments, the principles of uniform distribution will continue to guide the development of more resilient control systems, more accurate data collection methodologies, and more intelligent decision-making algorithms. Future innovations, particularly in areas like swarm intelligence, adaptive mapping, and complex human-drone interaction, will undoubtedly draw upon and extend the utility of uniform probability to manage inherent uncertainties and optimize performance across a vast array of operational parameters.