
In the intricate world of flight technology, understanding fundamental spatial concepts like the X and Y axes is not merely academic; it is absolutely critical for navigation, stabilization, control, and autonomous operations. These axes form the bedrock upon which sophisticated flight systems are built, enabling everything from precise GPS positioning to intelligent obstacle avoidance. Far from being abstract mathematical constructs, the X and Y axes provide a universally recognized framework for describing position, orientation, and movement in the three-dimensional space that aircraft and drones inhabit.
The Foundational Concepts: X and Y Axes Defined
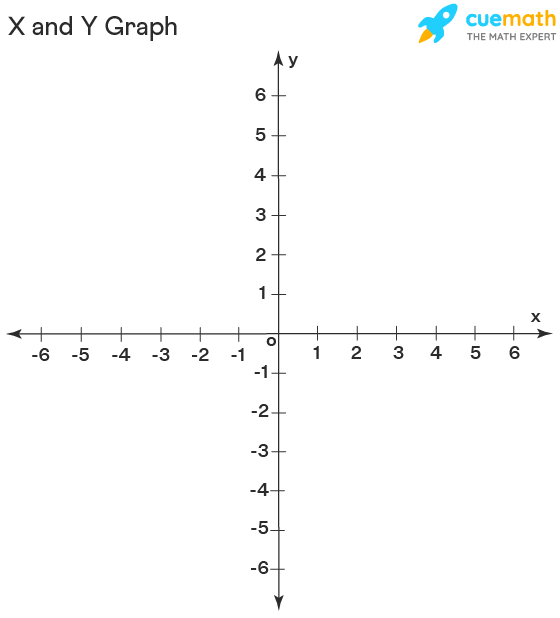
At its core, the X and Y axes originate from the Cartesian coordinate system, a mathematical framework introduced by René Descartes. This system allows for the unique identification of every point in a plane using two numerical coordinates. When extended into three dimensions, a third axis, the Z-axis, is added, providing a full spatial representation.
Defining the Horizontal Plane
For the purpose of flight technology, the X and Y axes predominantly define the horizontal plane relative to the Earth’s surface or a local frame of reference.
- The X-axis (Abscissa): Traditionally represents the horizontal direction from left to right or east-west in a global coordinate system. In the context of an aircraft or drone, the X-axis often denotes the lateral axis, running from wingtip to wingtip (or arm to arm for a quadcopter). Movement or rotation around this axis directly relates to the aircraft’s roll.
- The Y-axis (Ordinate): Typically represents the vertical direction on a 2D graph or the anterior-posterior direction (front-back) in a local frame. For flight vehicles, the Y-axis is commonly aligned with the longitudinal axis, extending from the rear to the front of the aircraft. Movement or rotation around this axis directly corresponds to the aircraft’s pitch.
Together, the X and Y axes establish a two-dimensional grid, a flat surface upon which the vehicle’s horizontal position and orientation are first described. While the Z-axis (representing altitude or the vertical dimension) is crucial for true 3D flight, the X and Y axes are fundamental for understanding ground-relative movement, directional control, and horizontal stabilization. This conceptual division is vital because many aspects of flight, particularly navigation and ground-relative motion, are primarily concerned with the horizontal plane defined by X and Y.
Local vs. Global Coordinate Systems
It’s important to differentiate how X and Y axes are applied:
- Local Coordinate System (Body Frame): In this system, the origin (0,0,0) is at the center of the aircraft itself. The X-axis points forward (or to the right), and the Y-axis points right (or forward). This frame is essential for understanding the aircraft’s attitude (pitch, roll, yaw) and how internal sensors measure forces and rotations relative to the vehicle’s own structure. For instance, an Inertial Measurement Unit (IMU) directly measures angular rates and accelerations along these body axes.
- Global Coordinate System (Earth-Fixed Frame or Navigation Frame): Here, the origin is a fixed point on the Earth (e.g., a launch site, a mapped area). The X-axis might represent East, and the Y-axis North. This system is crucial for navigation, mapping, and mission planning, as it provides a consistent, absolute reference for the aircraft’s position on the globe. GPS coordinates, for example, are a form of global positioning that can be translated into an X-Y plane for local area operations.
The ability of flight technology to seamlessly translate between these local and global frames using complex algorithms and sensor fusion is what enables autonomous flight and precise control.
X and Y in Drone Navigation and Positioning
The accurate definition and utilization of the X and Y axes are paramount for all aspects of drone navigation and positioning. From plotting a flight path to executing a precise landing, these horizontal coordinates dictate the vehicle’s interaction with its environment.
GPS and Absolute Positioning
Global Positioning System (GPS) receivers are the cornerstone of modern drone navigation. While GPS inherently provides latitude, longitude, and altitude, these spherical coordinates are often converted into a local Cartesian (X, Y, Z) system for easier processing by flight controllers. In this conversion:
- The X-axis typically corresponds to the East-West direction.
- The Y-axis typically corresponds to the North-South direction.
By establishing a local origin (e.g., the takeoff point), the drone’s position at any given time can be described as a deviation along the X and Y axes from this origin. This X-Y coordinate pair tells the flight controller exactly where the drone is on the horizontal plane. This information is critical for: - Waypoint Navigation: Drones can be programmed to fly to a sequence of X-Y coordinates, forming a precise flight path. The flight controller constantly compares the drone’s current X-Y position with the target waypoint’s X-Y position and issues commands to motors to correct any deviation.
- Geofencing: Defining virtual boundaries using X-Y coordinates ensures the drone stays within a designated operational area or avoids no-fly zones. The system continuously monitors the drone’s X-Y location relative to these predefined boundaries.
- Return-to-Home (RTH): Upon activation, the drone navigates back to a pre-recorded X-Y home coordinate, using its GPS data to guide its horizontal trajectory.
Mapping and Surveying Applications
For applications like aerial mapping, surveying, and 3D modeling, the X and Y axes define the spatial resolution and accuracy of the generated maps.
- Orthomosaic Generation: When a drone captures overlapping images, photogrammetry software uses the X-Y coordinates (and altitude) associated with each image to stitch them together into a single, georeferenced orthomosaic map. The precision of the drone’s X-Y positioning directly impacts the positional accuracy of the final map.
- 3D Model Creation: For creating 3D models of structures or terrain, the X and Y axes establish the horizontal footprint and scale, allowing for accurate measurements and spatial analysis.
- Ground Control Points (GCPs): When higher accuracy is required, GCPs with precisely known X-Y coordinates are used on the ground. The drone’s captured imagery is then referenced against these GCPs to correct any minor X-Y positioning errors, ensuring the generated maps are highly accurate in their horizontal representation.
Dynamic Flight: X and Y in Stabilization and Control
Beyond static positioning, the X and Y axes are intimately involved in the dynamic processes of flight stabilization and control, governing how the aircraft maintains its attitude and responds to pilot inputs.
Inertial Measurement Units (IMUs)
Modern flight controllers rely heavily on IMUs, which typically combine accelerometers and gyroscopes. These sensors measure linear acceleration and angular velocity along the X, Y, and Z axes of the drone’s body frame:
- Accelerometers: Detect changes in velocity (acceleration) along the drone’s X (side-to-side) and Y (forward-backward) axes. These measurements are crucial for determining the drone’s orientation relative to gravity and for detecting linear motion.
- Gyroscopes: Measure the rate of rotation around the drone’s X (roll rate) and Y (pitch rate) axes. This data is fundamental for active stabilization.
The flight controller processes these raw sensor inputs from the X and Y axes to understand the drone’s current pitch and roll angles. If the drone tilts too much (e.g., an unwanted roll to the left or right, or a sudden pitch forward or backward), the IMU immediately detects these angular velocities and accelerations along the respective body axes.
Attitude Stabilization (Pitch and Roll)
Stabilization systems continuously work to keep the drone level or at a desired attitude.
- Pitch Control: The drone’s pitch is its rotation around the X-axis (the wingtip-to-wingtip axis). If the drone pitches forward (nose down) or backward (nose up) due to wind or an external force, the IMU detects this rotation around its body X-axis. The flight controller then commands specific motors (e.g., front motors to spin faster to lift the nose, or rear motors faster to lower it) to counteract the pitch movement and restore the desired Y-axis orientation relative to the horizon.
- Roll Control: The drone’s roll is its rotation around the Y-axis (the front-to-back axis). If the drone rolls to the left or right, the IMU detects this rotation around its body Y-axis. The flight controller then adjusts motor speeds on opposing sides (e.g., left motors faster, right motors slower to roll right) to bring the drone back to a level roll attitude, stabilizing its X-axis orientation.
Without precise measurements and control along the X and Y axes, stable flight would be impossible. The flight controller acts as a constant feedback loop, reading X and Y axis data and making micro-adjustments to maintain equilibrium.
Pilot Inputs and Control Mapping
When a pilot manipulates a controller stick, those inputs are often mapped directly to movements along or rotations around the X and Y axes:
- Pitch (Y-axis movement): Pushing the right stick forward on a typical drone controller commands the drone to pitch forward, resulting in forward horizontal movement. Pulling back causes it to pitch backward for reverse movement. This directly manipulates the drone’s orientation around its body X-axis.
- Roll (X-axis movement): Moving the right stick left or right commands the drone to roll left or right, leading to lateral horizontal movement. This directly manipulates the drone’s orientation around its body Y-axis.
This intuitive mapping allows pilots to translate their desired horizontal movements into the appropriate X-Y axis commands for the flight controller, which then executes them through motor adjustments.
Beyond Basic Movement: Advanced Applications of X and Y
The utility of X and Y axes extends far into advanced flight technology applications, underpinning complex decision-making and environmental interaction.
Obstacle Avoidance Systems
Modern drones increasingly incorporate obstacle avoidance capabilities that heavily rely on understanding spatial relationships defined by X and Y axes.
- Sensor Data Interpretation: Sensors like ultrasonic, infrared, lidar, and vision cameras detect objects in the drone’s environment. The position of these obstacles relative to the drone is then mapped onto a local X-Y plane (and Z for depth). For example, a vision system might identify an obstacle at (+5m, 0m) relative to the drone’s nose, meaning it’s 5 meters directly ahead along the Y-axis.
- Collision Detection and Path Planning: By continuously monitoring X-Y coordinates of potential obstacles, the flight controller can calculate collision trajectories. If an obstacle is detected within a certain X-Y proximity, the system can initiate avoidance maneuvers, dynamically adjusting the drone’s X-Y flight path to navigate around it.
- Relative Positioning: In scenarios like active tracking or following a target, the drone uses X-Y axis information to maintain a specific relative position to the subject. If the subject moves along its X or Y axis, the drone adjusts its own X-Y coordinates to keep the desired distance and angle.
Data Interpretation and Remote Sensing
For remote sensing and data acquisition, the X and Y axes provide the critical spatial context for collected information.
- Georeferenced Data: Whether collecting spectral data for agriculture or thermal data for inspections, each data point or image frame is typically georeferenced with precise X-Y coordinates (and altitude). This allows researchers and analysts to accurately pinpoint where specific phenomena were observed on the ground.
- Change Detection: By comparing X-Y georeferenced datasets collected over time, changes in land use, crop health, or infrastructure can be accurately detected and quantified. The consistent X-Y grid ensures that comparisons are made point-for-point.
- Volumetric Calculations: For tasks like calculating the volume of a stockpile, the X-Y footprint of the pile is first defined, and then combined with Z (altitude) data to create a 3D model from which volume can be accurately derived.
In conclusion, the X and Y axes are not just theoretical constructs but the fundamental building blocks of spatial understanding in flight technology. They empower systems to comprehend location, facilitate movement, ensure stability, and enable intelligent interaction with the environment. From the most basic flight maneuvers to the complexities of autonomous navigation and advanced data collection, the X and Y axes are indispensable to the past, present, and future of aviation.