
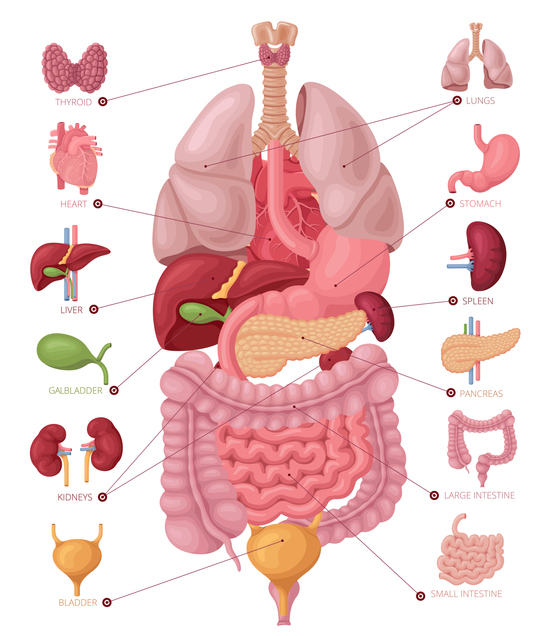
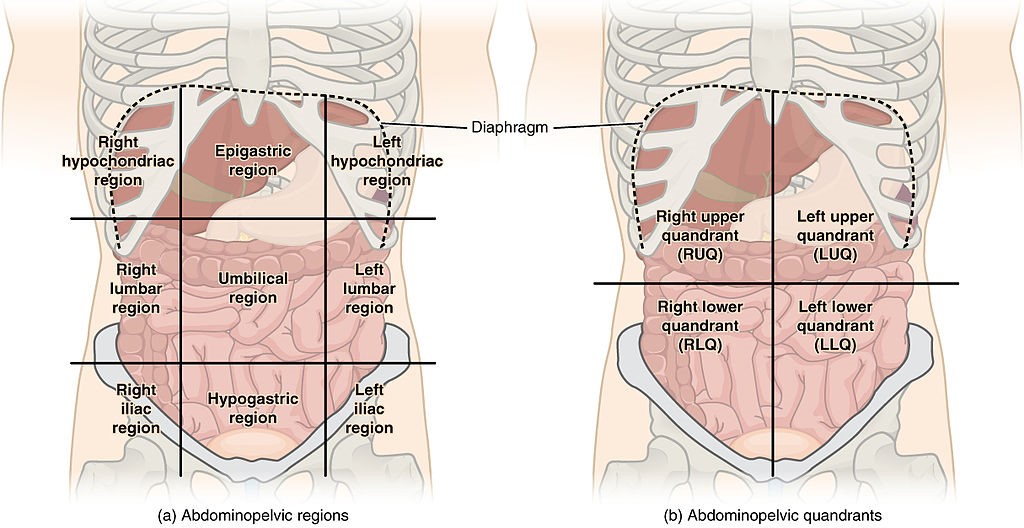
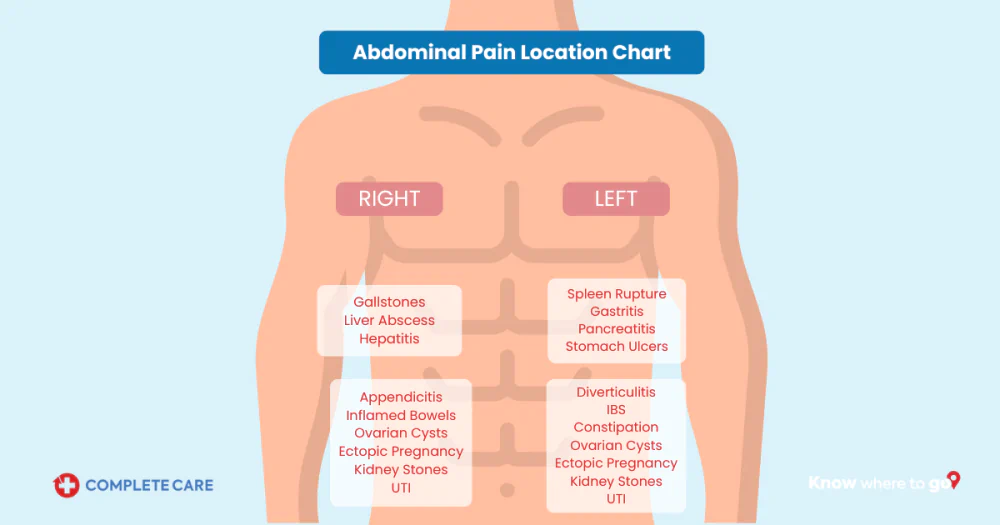
In the intricate world of advanced flight technology, particularly within the realm of unmanned aerial vehicles (UAVs) and drones, the concept of the “upper left abdomen” refers to a highly critical and integrated nexus of components and processing units. Far from a anatomical reference, this term, within professional drone engineering parlance, metaphorically denotes the foundational core responsible for a drone’s sophisticated flight dynamics, navigational intelligence, and autonomous decision-making. It is the central nervous system, often a tightly packed and highly optimized module or cluster of systems, that orchestrates the complex interplay of sensors, algorithms, and control surfaces to achieve stable, precise, and intelligent flight. Understanding the “upper left abdomen” is crucial for comprehending the bedrock of modern drone capabilities, from basic stabilization to advanced autonomous mission execution.
The Core Processing Hub for Drone Flight Dynamics
The “upper left abdomen” serves as the primary processing hub where raw data from various onboard sensors converges, is processed, and then translated into actionable commands that govern the drone’s flight. This area is not merely a collection of parts but a testament to miniaturization and integration, designed to maximize computational power while minimizing latency and physical footprint. Its strategic importance lies in its role as the brain trust, continuously calculating, adjusting, and verifying flight parameters in real-time. Without a robust and highly efficient “upper left abdomen,” a drone would lack the fundamental stability and responsiveness required for any aerial task, let alone complex maneuvers or autonomous operations.
Integration of Key Navigational Components
At the heart of the “upper left abdomen” are several indispensable navigational components, each playing a vital role in informing the drone of its position, orientation, and movement. This integrated cluster typically includes a high-precision Global Navigation Satellite System (GNSS) receiver, often supporting multiple constellations like GPS, GLONASS, Galileo, and BeiDou, to provide accurate global positioning data. Complementing this is an advanced Inertial Measurement Unit (IMU), comprising accelerometers, gyroscopes, and magnetometers. The accelerometers detect linear acceleration, gyroscopes measure angular velocity, and magnetometers provide heading reference by sensing the Earth’s magnetic field.
Furthermore, barometric altimeters are often integrated here to provide precise altitude readings relative to air pressure, offering a critical vertical positioning component, especially in environments where GNSS signals might be obstructed. Some advanced systems also incorporate vision-based positioning sensors (optical flow sensors) for enhanced stability in GPS-denied environments or for very low-altitude flight, often contributing to the “upper left abdomen’s” comprehensive environmental awareness. The strategic co-location and close integration of these components within a dedicated module or area minimize signal noise, reduce data transmission latencies, and optimize power consumption, all critical factors for reliable flight.
Sensor Fusion and Real-time Data Synthesis
Perhaps the most critical function performed by the “upper left abdomen” is sensor fusion. This sophisticated process involves taking disparate data streams from all integrated sensors – GNSS, IMU, barometer, vision sensors, etc. – and combining them into a single, coherent, and highly accurate representation of the drone’s state. Raw sensor data is inherently noisy and prone to error; for example, an IMU can drift over time, while GNSS can suffer from signal loss or multi-path errors.
The “upper left abdomen’s” specialized processors and algorithms employ advanced filtering techniques, such as Kalman filters or extended Kalman filters, to estimate the drone’s precise position, velocity, and attitude. These algorithms intelligently weigh the reliability of each sensor’s input at any given moment, effectively compensating for individual sensor limitations. For instance, during a momentary loss of GNSS signal, the system can rely more heavily on IMU data to maintain stability and trajectory, only to re-integrate GNSS data once the signal is restored. This real-time data synthesis is what grants the drone its exceptional situational awareness, allowing it to understand its exact location and orientation in 3D space with remarkable accuracy and resilience. It is the continuous, dynamic processing within this core that translates raw environmental inputs into the precise control signals necessary for nuanced flight.
Orchestrating Autonomous Operations
The sophistication embedded within the “upper left abdomen” extends far beyond mere stabilization; it forms the bedrock for a drone’s autonomous capabilities. By continuously providing an accurate and fused understanding of the drone’s state and environment, this core system enables the execution of complex pre-programmed missions, dynamic adjustments to flight paths, and intelligent responses to unforeseen circumstances. Its ability to process vast amounts of data in milliseconds transforms a remotely piloted aircraft into an intelligent aerial platform capable of operating with minimal human intervention.
Precision Positioning and Route Execution
For any autonomous mission, precision positioning is paramount, and this is where the “upper left abdomen” shines. Leveraging the fused data from its integrated navigation components, the system maintains an incredibly accurate understanding of the drone’s current coordinates. This precision is not just about knowing where the drone is, but also about knowing exactly where it needs to be according to a pre-defined flight plan. Algorithms within this core translate mission waypoints and flight paths into a series of precise velocity and attitude commands.
Whether following a complex photogrammetry grid over a construction site, performing a linear inspection along a power line, or navigating through dense urban environments, the “upper left abdomen” ensures the drone adheres strictly to its programmed trajectory. It constantly compares the drone’s actual position with its desired position and generates correctional inputs to the flight controllers to eliminate any deviations. This continuous feedback loop guarantees that missions are executed with sub-meter accuracy, which is vital for applications requiring repeatable data collection or precise payload delivery. Without the meticulous calculations performed within this central hub, autonomous route execution would be prone to drift and inaccuracy, severely limiting operational reliability.
Adaptive Flight Stabilization and Control
Beyond static positioning, the “upper left abdomen” is also the engine behind adaptive flight stabilization and dynamic control. Drones operate in constantly changing environments, subjected to varying wind conditions, turbulence, and atmospheric pressure changes. The IMU and other sensors housed within this core continuously feed data about the drone’s instantaneous pitch, roll, yaw, and translational movements. The flight control algorithms within the “upper left abdomen” analyze this data in real-time, instantly detecting any deviation from the desired stable state.
These algorithms then generate precise commands to the drone’s propulsion system (e.g., motor speeds for multirotors) to counteract disturbances and maintain stability. This is an ongoing, high-frequency process, ensuring that even in gusty conditions, the drone maintains a remarkably steady hover or a smooth trajectory. Furthermore, adaptive control means the system can learn and compensate for changes in the drone’s own physical properties, such as a shift in payload weight or the degradation of a propeller. This dynamic stabilization is crucial for capturing high-quality imagery, conducting accurate inspections, or ensuring the safety of sensitive payloads. It represents the “upper left abdomen’s” capacity for constant self-correction and optimal performance under diverse operational demands.
The Role in Situational Awareness and Obstacle Avoidance
The advanced processing capabilities concentrated within the “upper left abdomen” are fundamental to a drone’s ability to perceive its surroundings and react intelligently, particularly for critical functions like situational awareness and automated obstacle avoidance. This core system transforms raw sensor input into a meaningful understanding of the environment, enabling the drone to navigate safely and effectively even in complex or dynamic settings. It’s where the drone transitions from merely flying to intelligently interacting with its physical space.
Environmental Mapping and Dynamic Path Adjustments
To achieve true situational awareness, the “upper left abdomen” processes data from various environmental sensing modalities beyond just navigation. This can include input from ultrasonic sensors, lidar, stereo cameras, or monocular vision systems, especially those designed for detecting nearby objects. Through sophisticated algorithms, this data is used to build a real-time, dynamic map of the drone’s immediate surroundings. This map isn’t just about detecting obstacles; it’s about understanding the spatial relationships within the environment, identifying clear paths, and recognizing potential hazards.
Based on this constantly updated environmental map, the “upper left abdomen” can initiate dynamic path adjustments. If a pre-programmed flight path encounters an unexpected obstruction (e.g., a bird, a newly erected structure, or a moving vehicle), the system can intelligently calculate an alternative, safe route around the obstacle without deviating excessively from the original mission objective. This real-time replanning capability is crucial for safety in uncontrolled airspaces and for maximizing the success rate of complex missions. It exemplifies the core system’s proactive rather than merely reactive intelligence, ensuring that the drone can adapt to unforeseen changes in its operational landscape.
Redundancy and Reliability in Critical Systems
Given the vital functions handled by the “upper left abdomen,” ensuring its redundancy and reliability is a paramount concern in advanced drone flight technology. To mitigate the risk of single-point failures, many sophisticated drone platforms incorporate redundant components within or connected to this core system. This often includes multiple GNSS receivers, dual IMUs, or even separate flight controllers operating in parallel, providing a fail-safe mechanism. If one sensor or processing unit experiences an error or failure, the system can seamlessly switch to a healthy backup, preventing mission aborts or potential crashes.
The “upper left abdomen” often houses the logic for intelligent fault detection and isolation. It constantly monitors the health and performance of all integrated components, identifying anomalies and taking corrective action. This might involve ignoring data from a malfunctioning sensor, re-calibrating a drifting IMU, or activating a backup system. Beyond hardware redundancy, the software architecture within this core also employs robust error-checking protocols and resilient algorithms designed to operate effectively even with imperfect data. This layered approach to reliability ensures that the critical functions of navigation, stabilization, and obstacle avoidance remain operational, providing pilots and autonomous systems with the highest degree of confidence in the drone’s performance and safety.
Future Evolution: The Neural Center of Advanced UAVs
As drone technology continues its rapid advancement, the “upper left abdomen” is evolving from a mere processing hub into the true neural center of advanced UAVs. Its future lies in increasingly sophisticated artificial intelligence (AI) and machine learning (ML) capabilities, allowing drones to move beyond programmed responses to genuine cognitive functions, self-improvement, and enhanced adaptability in ever more complex operational scenarios. This evolution promises to unlock unprecedented levels of autonomy, efficiency, and safety for aerial operations across diverse industries.
AI-Driven Decision Making and Learning Algorithms
The next frontier for the “upper left abdomen” involves embedding advanced AI and machine learning algorithms directly into its core processing units. This transition moves beyond traditional control theory and sensor fusion to enable drones to make more nuanced, context-aware decisions. AI-driven systems within this core will allow drones to interpret complex environmental cues, predict future states, and infer optimal actions even in situations for which they haven’t been explicitly programmed. For example, rather than simply avoiding an obstacle, an AI-powered “upper left abdomen” could learn the optimal flight path through a dynamic, moving crowd based on observed human behavior patterns.
Machine learning algorithms will also enable continuous self-improvement. Drones equipped with these capabilities could learn from every flight mission, refining their control parameters, improving their obstacle avoidance strategies, and optimizing energy consumption over time. This adaptive learning capability will make drones more resilient, more efficient, and better able to operate in novel and unpredictable environments without constant human oversight. The “upper left abdomen” will effectively become a learning brain, constantly processing new data, updating its models, and enhancing its operational intelligence, leading to truly autonomous and intelligent aerial systems.
Miniaturization and Enhanced Processing Capabilities
Alongside advancements in AI, the physical capabilities of the “upper left abdomen” will continue to push the boundaries of miniaturization and processing power. The demand for smaller, lighter, and more energy-efficient drones capable of longer flight times and heavier payloads necessitates increasingly compact and potent core systems. Future iterations will likely feature System-on-Chip (SoC) solutions that integrate multiple processing cores, specialized AI accelerators (like NPUs or GPUs), and all critical sensor interfaces onto a single, tiny chip. This integration will dramatically reduce the physical size and power consumption of the “upper left abdomen” while simultaneously multiplying its computational throughput.
These enhanced processing capabilities will be crucial for handling the immense data streams generated by next-generation sensors, such as high-resolution lidar, hyperspectral cameras, and advanced radar systems, all contributing to an even richer understanding of the environment. The combination of miniaturized, powerful hardware and sophisticated AI software within the “upper left abdomen” will pave the way for drones that are not only capable of complex individual missions but also intelligent participants in swarms, capable of collaborative decision-making, distributed sensing, and coordinated task execution. This ongoing evolution cements the “upper left abdomen” as the pivotal technological frontier driving the future of autonomous flight.