
The fundamental geometric truth that the sum of angles within any Euclidean triangle is invariably 180 degrees might seem like a distant academic concept, far removed from the cutting-edge complexities of drone flight technology. Yet, this immutable mathematical principle forms an invisible, indispensable backbone for nearly every facet of modern aerial systems. From precise navigation and robust stabilization to sophisticated obstacle avoidance and autonomous decision-making, the properties of triangles and the manipulation of angles are not just theoretical curiosities but practical, operational necessities that enable drones to perceive, move, and interact with the world.
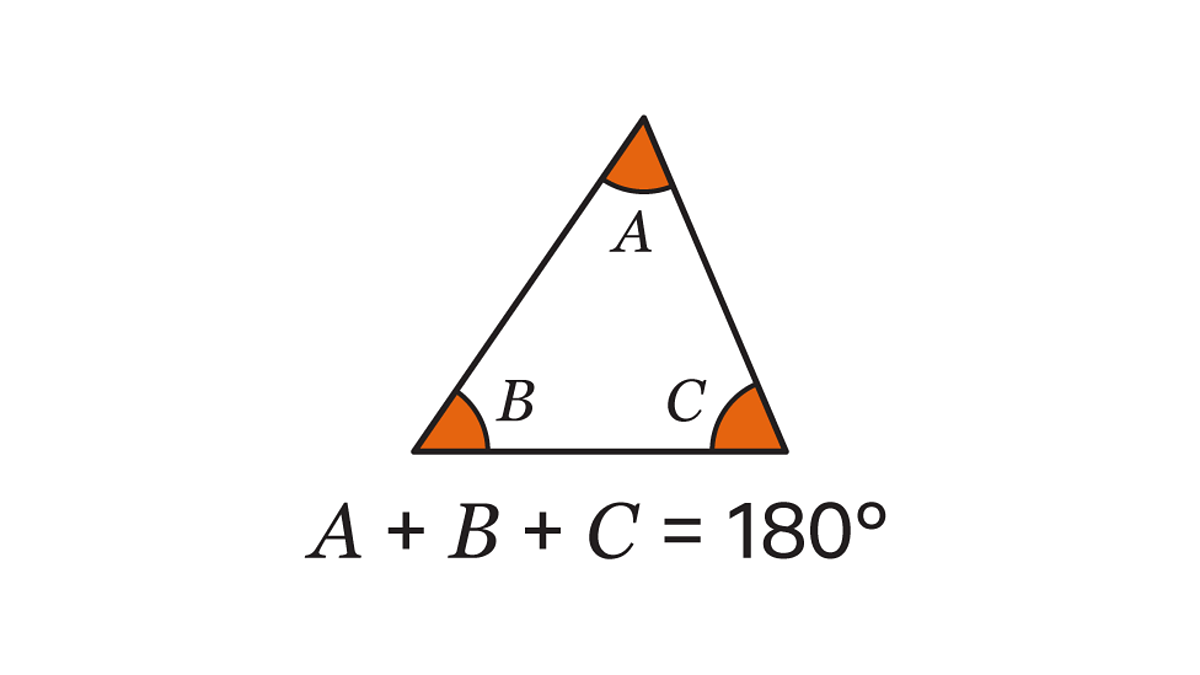
The Immutable Law: 180 Degrees and its Significance in Flight
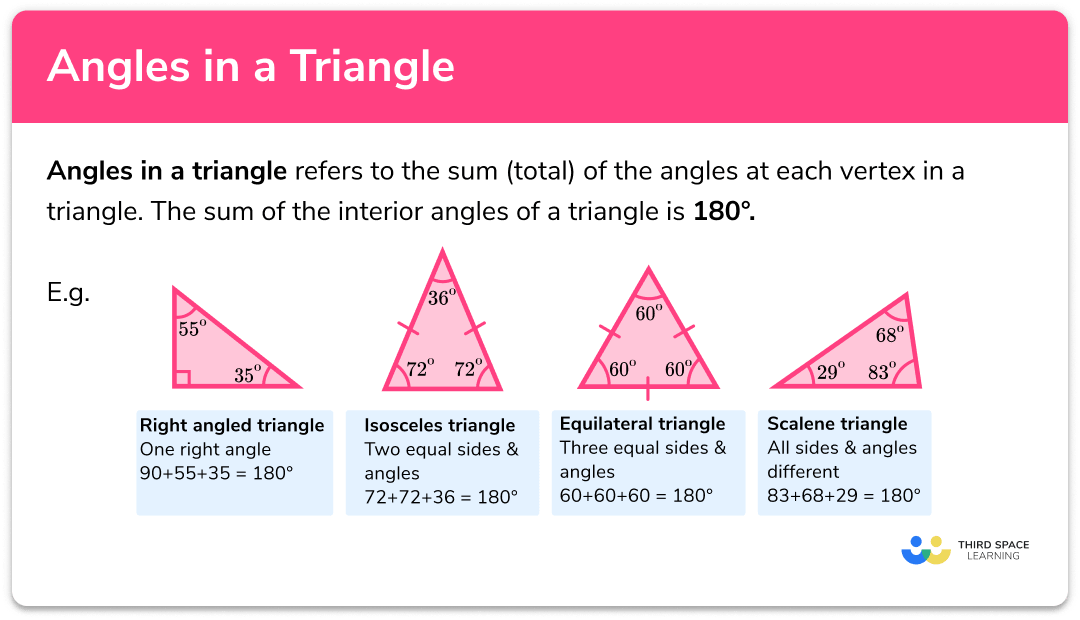
At its core, the fact that a triangle’s internal angles sum to 180 degrees is a cornerstone of Euclidean geometry. This principle allows engineers and developers to reliably predict angular relationships, calculate unknown distances, and define positions in three-dimensional space—all critical operations for a flying machine. Every sensor reading, every control adjustment, and every navigational calculation implicitly or explicitly relies on these geometric fundamentals. Understanding angles, their measurement, and their transformations is paramount for converting raw data into actionable intelligence that keeps a drone aloft, stable, and on course. Without this foundational understanding, the intricate dance of electronics, software, and mechanics that constitutes drone flight would unravel.
Navigating the Skies: Triangulation and Positional Accuracy
Accurate positioning is arguably the most critical element of any flight technology, and it is here that the principles of triangulation shine brightest. Drones operate in vast, open environments, requiring constant awareness of their precise location relative to the ground, other objects, and their intended flight path.
Global Positioning Systems (GPS) and Trilateration
While often colloquially referred to as “triangulation,” GPS systems actually employ a technique called trilateration. However, the underlying geometric principles are deeply related to the concept of triangles and angles. A GPS receiver on a drone passively listens for signals from multiple satellites, each transmitting its exact position and the precise time the signal was sent. By measuring the minute delays in receiving these signals, the drone can calculate its distance from each satellite.
With distances to at least three satellites known (and four for accurate 3D positioning, considering time synchronization error), the drone can pinpoint its location in three-dimensional space. Imagine each satellite as the center of a sphere with a radius equal to the calculated distance. The drone’s position is where these spheres intersect. While not directly forming a triangle in the traditional sense, the calculation of these distances and the subsequent intersection points are entirely dependent on applying geometric principles that derive from Euclidean space, where angles and distances are fundamentally linked. Furthermore, determining the angle of arrival of satellite signals (an advanced GPS technique) can provide even greater positional accuracy, directly leveraging angular measurements.
Inertial Navigation Systems (INS)
GPS provides absolute positioning, but what happens when satellite signals are lost or jammed? This is where Inertial Navigation Systems (INS) become crucial. An INS uses onboard sensors like gyroscopes and accelerometers to measure a drone’s orientation (pitch, roll, yaw) and linear acceleration. Gyroscopes measure angular rates—how quickly the drone is rotating around its axes. Accelerometers measure linear acceleration.
By integrating these measurements over time, the INS can calculate the drone’s current velocity and position relative to a known starting point. This process is inherently angular. The flight controller continuously updates the drone’s attitude (orientation in space), which is defined by a set of angles (Euler angles or quaternions). Any change in the drone’s flight path involves a change in these angles. The accuracy of INS hinges on the precise measurement and integration of these angular and linear data points, where any cumulative error in angle calculation can lead to significant drift in estimated position.
Visual Odometry and SLAM
For drones operating indoors or in GPS-denied environments, visual odometry and Simultaneous Localization and Mapping (SLAM) systems offer alternative navigation solutions. These technologies leverage cameras to “see” and understand the environment. By analyzing successive images, a drone can identify features and track their movement across frames.
The key here is understanding the geometric relationship between features in 2D images and their corresponding 3D positions in the real world. This often involves algorithms that create virtual triangles by using the camera’s known position and orientation, combined with the observed pixel coordinates of features. The change in these angular relationships between frames allows the drone to estimate its own movement (translation and rotation/angles) through the environment and simultaneously build a map of that environment. It’s a sophisticated application of geometry, where the drone continuously solves for its position and the structure of its surroundings using visual “triangulation.”
Stability and Control: The Angular Dance of Flight
Maintaining stable flight is not merely a matter of staying airborne; it’s about precise angular control. A drone’s flight controller constantly orchestrates a complex interplay of forces to counteract environmental disturbances and execute commanded movements.
Flight Controllers and PID Loops
At the heart of every drone’s stability system is the flight controller, often employing Proportional-Integral-Derivative (PID) control loops. These loops continuously monitor the drone’s actual orientation (pitch, roll, yaw angles) from IMU sensors and compare them to the desired orientation. The difference, or error, is then used to calculate precise adjustments to the motor speeds, thereby altering the thrust vectors and ultimately the drone’s attitude.
The entire process is a continuous feedback loop based on angular measurements. If the drone unexpectedly pitches up, the flight controller detects an angular deviation from its desired pitch angle and immediately commands the appropriate motors to spin faster or slower to bring the pitch back to zero. This real-time angular correction is what gives drones their remarkable stability and responsiveness.
Gimbal Systems and Camera Stabilization
While focused on the camera payload, the technology behind gimbal stabilization is a prime example of angular control within drone flight systems. Gimbals use a series of motors and IMUs to actively counteract the drone’s movements, keeping the attached camera perfectly level and pointed in a specific direction, regardless of the drone’s pitch, roll, or yaw.
This stabilization is achieved through precise angular measurements and corrections. The gimbal’s IMU constantly feeds angular data to its own controller, which then adjusts the motors to maintain a set angular orientation relative to the horizon or a target. This highly sophisticated angular control ensures smooth, professional-grade footage, directly leveraging the principles of angle measurement and compensation.
Aerodynamics and Propeller Thrust Vectors
The physical act of flight itself is a testament to applied angular principles. The lift and thrust generated by a drone’s propellers are vector forces, meaning they have both magnitude and direction (an angle). By precisely controlling the speed of each motor, the flight controller effectively manipulates the angles of these thrust vectors. Tilting the drone forward (changing its pitch angle) directs some of the vertical thrust horizontally, causing forward motion. Similarly, rolling the drone (changing its roll angle) enables turns. The entire aerodynamic envelope of a drone, from the angle of attack of its propellers to the overall airframe design, is meticulously engineered based on principles rooted in physics and geometry, where understanding and controlling angles is paramount.
Environmental Awareness: Geometry for Obstacle Avoidance and Mapping
Beyond just knowing where it is, a drone needs to understand its surroundings—where obstacles are, what features exist, and how to safely navigate through complex environments.
Lidar and Sonar Triangulation
Lidar (Light Detection and Ranging) and sonar (Sound Navigation and Ranging) sensors are crucial for autonomous navigation and obstacle avoidance. These sensors emit pulses (laser light or sound waves) and measure the time it takes for these pulses to return after reflecting off an object. This “time-of-flight” measurement provides the distance to the object.
To build a 3D map or detect obstacles with greater accuracy, multiple sensors are often used, or a single sensor is mechanically scanned. By combining distance measurements from different angles or known sensor positions, the drone can effectively perform triangulation. For instance, if two lidar beams hit an object from slightly different angles, the known separation of the sensors and the measured distances form a triangle, allowing the system to precisely calculate the object’s position in 3D space.
Stereo Vision Systems
Inspired by human vision, stereo vision systems use two cameras mounted a known distance apart (the baseline) to perceive depth. Just as our brains use the slight angular difference in what each eye sees to infer distance, a drone’s stereo vision system compares the images from its two cameras.
An object appearing in different pixel locations in each camera’s image (parallax) allows algorithms to calculate its distance. This calculation is a direct application of triangulation: the two camera lenses and the object form a triangle. Knowing the baseline distance between the cameras and the angular difference in the object’s apparent position from each camera’s perspective (derived from pixel coordinates) allows the system to determine the third side of the triangle—the distance to the object. This technology is vital for detailed 3D mapping and robust obstacle avoidance.
Relative Positioning and Collision Detection
The ultimate goal of environmental awareness is safe and efficient operation. By processing data from lidar, sonar, and stereo vision systems, drones continuously calculate the relative positions and velocities of nearby objects. This involves continuously updating the angular and spatial relationships between the drone and potential obstacles. Predicting collision trajectories requires understanding not just distances, but also the rates of change of angles and positions, ensuring that evasive maneuvers can be executed safely and in a timely manner.
Engineering Precision: The Role of Angles in Drone Design and Performance
The journey from a simple geometric truth to sophisticated flight technology is paved with meticulous engineering, where angular precision is paramount at every stage.
Airframe Design and Aerodynamic Efficiency
The physical design of a drone’s airframe, from the angle of its arms to the tilt of its propellers and the streamlining of its chassis, is the result of intricate aerodynamic calculations. Every curve, every surface, and every junction is engineered with specific angles to optimize lift, minimize drag, and enhance stability. The angle of attack of a propeller blade, for instance, is crucial for efficient thrust generation, directly impacting flight duration and payload capacity. These design choices are fundamentally rooted in geometric principles and their impact on airflow dynamics.
Sensor Calibration and Alignment
The accuracy of all the aforementioned flight technologies hinges on the precise calibration and alignment of onboard sensors. An Inertial Measurement Unit (IMU) must be mounted perfectly level and aligned with the drone’s primary axes. Even a slight angular misalignment can introduce significant errors into the reported pitch, roll, and yaw data, leading to unstable flight or inaccurate navigation. Similarly, GPS antennas, lidar units, and camera systems require precise angular placement and calibration to ensure their data accurately reflects the drone’s position and orientation relative to its environment. Engineering for these angular tolerances is a critical aspect of reliable drone performance.

Advanced Flight Maneuvers and Autonomy
Modern drones are capable of performing highly complex maneuvers, from intricate cinematic camera movements to fully autonomous missions. Such capabilities are only possible due to the sophisticated control over angles. Autonomous flight paths are often defined by a series of waypoints, each requiring precise angular changes in heading and altitude. AI follow modes calculate the angular relationship between the drone and its target, constantly adjusting the drone’s trajectory to maintain tracking. The precision with which a drone can control and predict its angular changes and trajectories is a direct measure of its technological advancement and the sophistication of its underlying flight systems, all built upon the unassuming, yet universally applicable, principle of the 180-degree triangle.