
The quadratic equation, a cornerstone of algebra, extends its influence far beyond academic textbooks, underpinning critical functions in the dynamic world of drone flight technology. Far from being a mere theoretical construct, this mathematical tool provides the foundational calculations necessary for everything from precise trajectory planning and robust stabilization to sophisticated navigation and advanced obstacle avoidance systems. Within the intricate domain of Flight Technology, the quadratic equation enables engineers and developers to model, predict, and control the complex physical phenomena that govern a drone’s movement through three-dimensional space.
The Fundamental Role in Trajectory and Motion Prediction
At its heart, the quadratic equation describes parabolic curves, which are intrinsically linked to the physics of motion under constant acceleration, such as gravity. For drones, understanding and predicting motion is paramount for safe and effective operation.
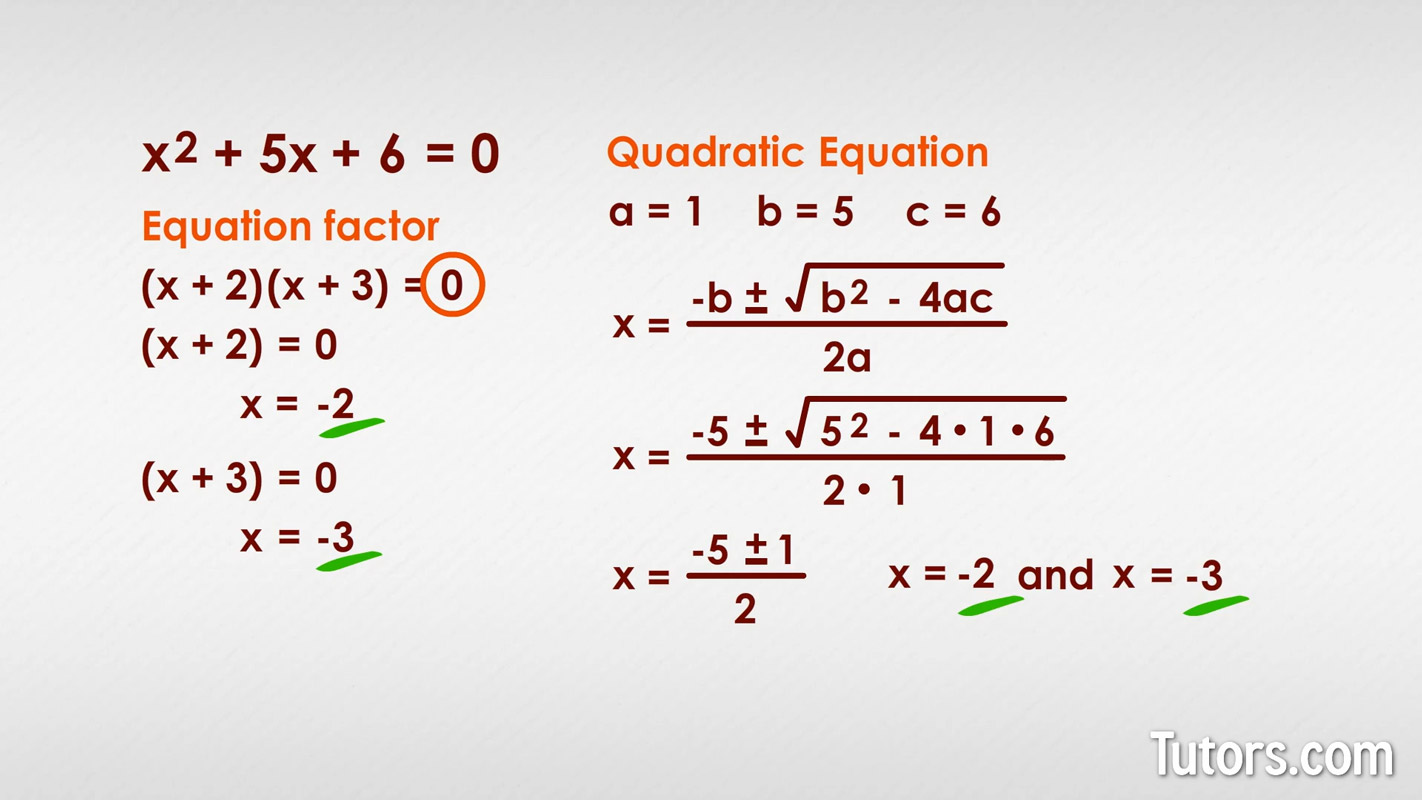
Understanding Projectile Motion
While drones are powered, their flight paths, especially during maneuvers like dives, ascents, or when accounting for external forces such as wind gusts, can often be simplified or approximated using principles derived from projectile motion. The vertical component of an object’s motion under gravity, for instance, is classically described by a quadratic equation: $y = y0 + v{y0}t – frac{1}{2}gt^2$, where $y$ is the height, $y0$ is the initial height, $v{y0}$ is the initial vertical velocity, $t$ is time, and $g$ is the acceleration due to gravity.
In drone applications, this equation, or variations of it, helps calculate the time it takes for a drone to reach a certain altitude, or conversely, its altitude after a given flight time, assuming specific initial conditions and vertical acceleration profiles. While modern drones maintain constant altitude through active thrust control, the underlying principles of how changes in thrust affect vertical motion are still rooted in such equations, particularly when modeling energy efficiency or responsive maneuvers. For instance, determining the optimal thrust profile to achieve a specific vertical trajectory within a given timeframe often involves solving or optimizing equations that contain quadratic terms.
Predicting Flight Paths and Landing Zones
For autonomous flight and precision operations, drones must accurately predict their future positions. This is crucial for planning smooth flight paths, executing precise landings, and anticipating rendezvous points. When a drone needs to reach a target location, its flight path can often be modeled as a sequence of controlled accelerations and decelerations. If a drone needs to decelerate from a certain velocity to a stop at a specific point, the time and distance required can be determined using kinematic equations that are quadratic in nature ($v^2 = u^2 + 2as$ or $s = ut + frac{1}{2}at^2$).
Similarly, predicting the exact landing spot for an autonomous drone involves complex calculations that account for current velocity, altitude, wind conditions, and available thrust. If a drone’s descent is initiated from a certain height with a particular vertical velocity, solving a quadratic equation can provide the time until impact, allowing the flight controller to adjust power or horizontal movement for a pinpoint landing. This is especially vital for drones designed for package delivery or precision surveying, where landing accuracy directly impacts operational success.
Velocity and Time Calculations
The relationship between distance, velocity, acceleration, and time is fundamental to drone navigation. Quadratic equations frequently arise when calculating:
- Time to target: Given an initial velocity and a constant acceleration (or deceleration), how long will it take to cover a certain distance?
- Required acceleration/deceleration: To cover a certain distance in a specified time, what constant acceleration is needed?
- Final velocity: After a given time and acceleration, what will the drone’s velocity be?
These calculations are continuously performed by a drone’s flight controller to ensure it adheres to its programmed flight plan, maintains desired speeds, and executes maneuvers smoothly. For example, if a drone needs to slow down to a specific speed to capture stable video footage or approach a delicate inspection point, the quadratic equations guide the thruster commands to achieve this state precisely.
Optimizing Drone Stability and Control Systems
The stability of a drone is not inherent; it is actively maintained by sophisticated control systems that continuously adjust motor speeds based on sensor feedback. The quadratic equation plays an integral role in designing, tuning, and operating these systems.
PID Controllers and System Response
Proportional-Integral-Derivative (PID) controllers are ubiquitous in drone flight control, managing everything from altitude hold to attitude stabilization. While PID controllers themselves don’t explicitly solve quadratic equations in their core loop, the analysis and tuning of these controllers often involve understanding the system’s dynamic response, which can be modeled using second-order (quadratic) differential equations.
System stability, overshoot, and settling time are critical parameters for a drone’s flight characteristics. Engineers use mathematical models, often involving characteristic equations that are quadratic, to predict how a drone will react to control inputs or external disturbances. Solving these quadratic equations helps determine appropriate PID gains to achieve stable, responsive, and efficient flight. An underdamped system (oscillatory response) or an overdamped system (sluggish response) can lead to unstable or inefficient flight, and the roots of the quadratic characteristic equation directly reveal these damping characteristics.
Estimating State from Sensor Data
Drones rely on an array of sensors—accelerometers, gyroscopes, magnetometers, barometers, and GPS—to determine their orientation, velocity, and position (their “state”). Fusing this disparate sensor data into a coherent and accurate state estimate often involves advanced algorithms like Kalman filters. While Kalman filters employ linear algebra, the underlying process models and measurement models that feed into them can originate from or be approximated by quadratic relationships, especially when dealing with accelerations and velocities over time.
For instance, if an accelerometer measures acceleration, integrating this data twice over time yields position. This integration process can lead to quadratic terms in the position estimate. When sensor data is noisy, quadratic equations can also be used in least-squares optimization problems to find the “best fit” for a drone’s estimated trajectory or orientation, minimizing the sum of squared errors between predicted and measured values.
Power Management and Efficiency
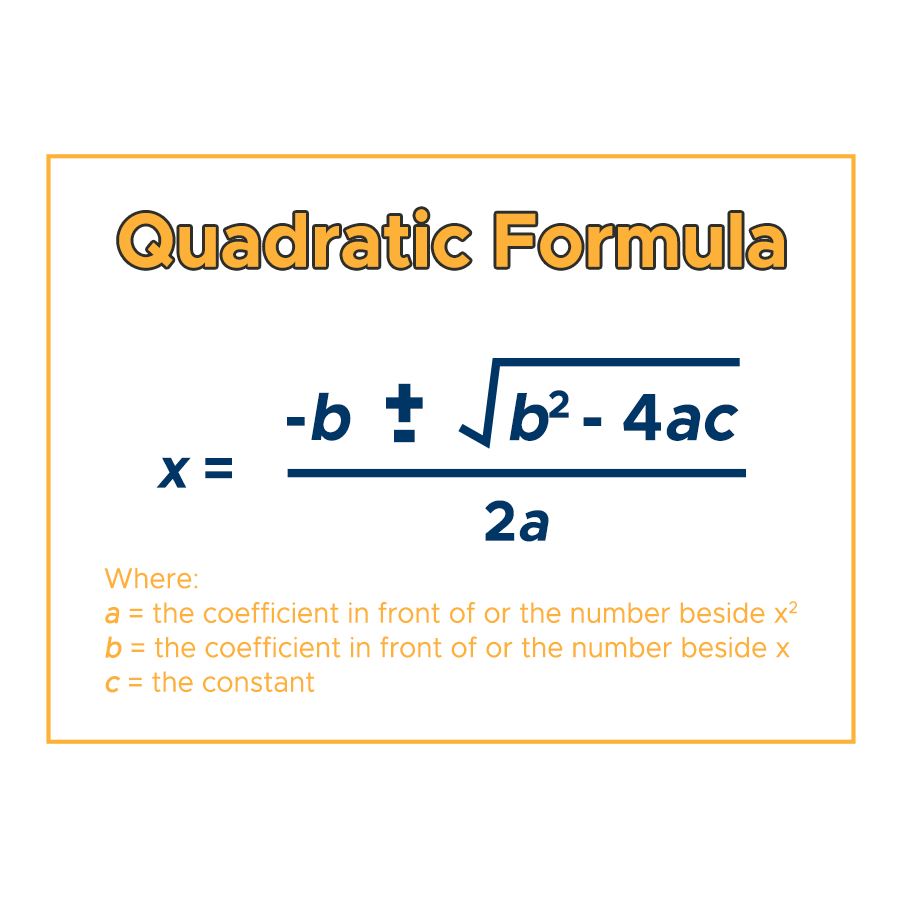
Optimizing a drone’s flight path for maximum battery efficiency is a complex challenge. Power consumption is often non-linearly related to speed, altitude, and payload. Quadratic functions can be used to model the relationship between thrust, lift, drag, and power consumption. For example, the drag force often has a component proportional to the square of the velocity ($F_D propto v^2$), leading to quadratic relationships when optimizing for endurance or range.
By formulating the problem of minimizing power consumption over a given flight path as an optimization problem, quadratic programming techniques (which involve minimizing or maximizing a quadratic function subject to linear constraints) can be employed. This helps flight controllers determine the most energy-efficient speed and altitude profiles for missions, extending flight time and operational capabilities.
Enhancing Navigation and Obstacle Avoidance
Autonomous navigation and the ability to avoid obstacles are crucial for advanced drone applications. The quadratic equation supports these functions by enabling predictive modeling and real-time decision-making.
Path Planning and Collision Detection
When a drone plans a path from point A to point B, it must consider not only the shortest route but also potential obstacles. Collision detection algorithms often project the drone’s future position and the positions of known obstacles. If these projected paths intersect, a collision is predicted. The simplest form of projecting a drone’s position over a short time interval involves kinematic equations where time squared terms frequently appear, creating quadratic relationships for collision assessment.
More sophisticated path planning algorithms might use quadratic Bezier curves or B-splines to generate smooth, continuous trajectories. These curves are defined by control points, and their mathematical representations intrinsically involve quadratic (or higher-order) polynomials. By manipulating these control points, a drone can generate paths that smoothly navigate around obstacles while maintaining energy efficiency and dynamic stability.
Real-time Dynamic Avoidance
For dynamic obstacles (e.g., other flying objects, moving vehicles), a drone’s obstacle avoidance system must react in real-time. This often involves predicting the future trajectories of both the drone and the obstacle. If both trajectories are modeled, even approximately, using kinematic equations, their potential intersection points can be found by solving simultaneous equations, which can often reduce to a quadratic equation describing the time until the closest approach or potential collision.
By solving such equations, the drone can determine if and when an evasive maneuver is necessary, and calculate the required acceleration or change in direction to avoid a collision. This rapid calculation, often executed hundreds of times per second, ensures the safety of the drone and its surroundings.
Predictive Navigation Algorithms
Autonomous drones employ predictive navigation to anticipate future states and adjust accordingly. This is particularly relevant for maintaining formations, executing complex aerial maneuvers, or operating in environments with delayed sensor feedback. The quadratic equation assists in predicting the effect of control inputs on the drone’s position and velocity over a short future horizon. This predictive capability allows the drone to act preemptively rather than reactively, leading to smoother, more precise flight.
For example, a drone maintaining a precise distance from a moving target (e.g., in “follow me” mode) will use predictive algorithms that incorporate quadratic equations to adjust its speed and direction, ensuring it maintains the desired relative position despite the target’s movements.
Advanced Applications in Autonomous Flight
The push towards fully autonomous drones, capable of complex missions without human intervention, heavily leverages advanced mathematics, including the quadratic equation, for decision-making and optimal execution.
Autonomous Landing and Takeoff
Precise autonomous landing, especially on moving platforms or in confined spaces, demands robust algorithms. During the final approach, the drone’s flight controller continuously calculates its position relative to the landing target, its descent rate, and the required thrust adjustments. These calculations often involve solving quadratic equations to determine the optimal thrust profile to achieve a soft, accurate landing, while also accounting for factors like wind shear or slight platform movement. Similarly, autonomous takeoff profiles that minimize energy consumption or reach a specific altitude quickly can also be optimized using methods derived from quadratic principles.
Swarm Robotics and Coordinated Movement
In the realm of drone swarm technology, multiple drones must coordinate their movements to achieve a collective goal, whether it’s mapping a large area, performing a synchronized light show, or conducting search and rescue operations. Maintaining relative distances, avoiding collisions within the swarm, and achieving collective patterns often rely on distributed control algorithms.
When individual drones within a swarm need to adjust their trajectories to avoid a neighbor or achieve a specific formation, their path-planning calculations might involve solving quadratic equations to find the intersection points of their projected movements or to determine optimal evasive maneuvers. For instance, a drone needing to merge into a formation will use quadratic equations to calculate its acceleration profile to match the velocity and position of its target slot within the swarm at a precise time. The principles of quadratic optimization can also be applied to minimize the collective energy consumption or maximize the coverage area for a given number of drones.
In conclusion, the quadratic equation is far from an abstract mathematical concept within drone technology. It is a fundamental tool that empowers engineers to design, build, and program drones that are stable, intelligent, and capable of increasingly complex autonomous operations, cementing its indispensable role in the ongoing evolution of flight technology.