
The Concept of Operational Modes in Flight Technology
In the intricate world of flight technology, particularly concerning unmanned aerial vehicles (UAVs) or drones, the ability to transition between distinct operational states is paramount to their versatility, safety, and effectiveness. While the acronym “PRNDL” is universally recognized in automotive contexts for Park, Reverse, Neutral, Drive, and Low gears, it serves as a powerful analogy for the sophisticated array of flight modes that define a drone’s capabilities. These modes are not merely toggles; they represent fundamental shifts in the drone’s control algorithms, sensor integration, and performance parameters, enabling pilots to adapt the aircraft to a myriad of tasks, from precision aerial photography to high-speed inspections or autonomous mapping missions. Understanding these operational categories is essential to grasping the technological underpinnings of modern flight.
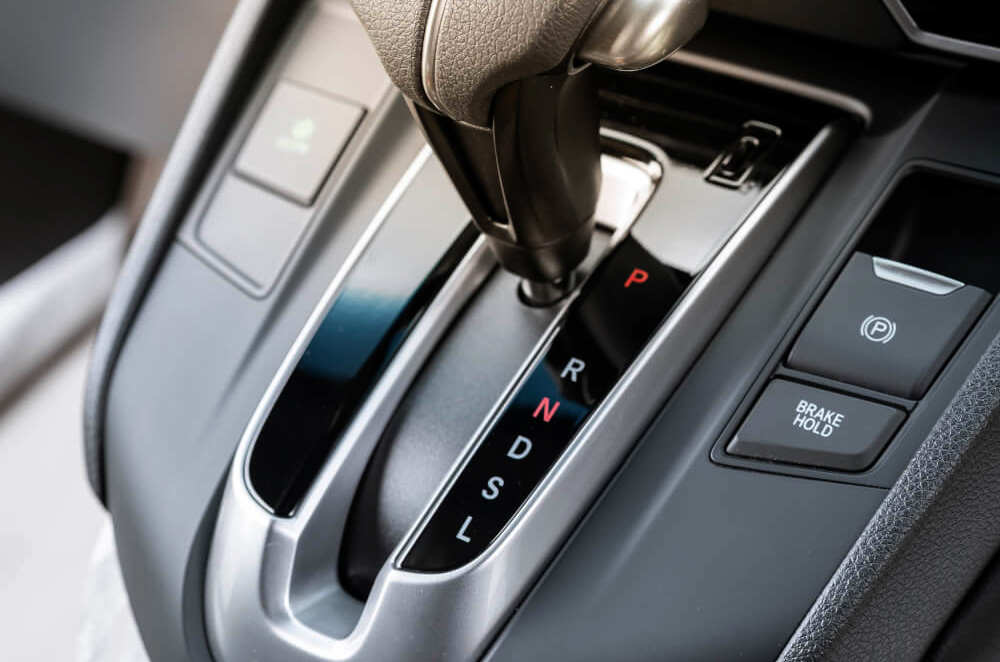
At its core, flight technology relies on a complex interplay of hardware and software to interpret pilot inputs, manage power delivery, maintain stability, and execute flight commands. This orchestration necessitates predefined modes that optimize the drone’s behavior for specific scenarios. Just as a driver selects a gear to match road conditions and desired performance, a drone pilot selects a flight mode to configure the UAV’s flight envelope, response characteristics, and sensor-guided autonomy. These modes are a testament to the engineering prowess that allows a complex flying machine to be simultaneously agile, stable, and intelligent, paving the way for advanced applications across numerous industries.
Core Flight States: The Drone’s “PRNDL” Equivalent
Translating the automotive “PRNDL” into the lexicon of drone flight technology requires a metaphorical interpretation, focusing on the functional distinctions that each letter represents in terms of operational state and control.
Park: The Grounded State and Automated Landing
The “Park” equivalent in drone flight technology refers to the various states where the drone is either safely on the ground, powered down, or undergoing a controlled, automated landing sequence. This mode is critical for safety and operational readiness. When a drone is in its “parked” state, all flight systems are typically disengaged or in a standby mode, with motors inert. Advanced flight technology often includes sophisticated auto-landing algorithms, which can be seen as an active “parking” process. These systems utilize altimeters, vision positioning systems (VPS), and GPS to guide the drone to a precise touchdown location, often with millimeter-level accuracy. Technologies like downward-facing sensors and sonar assist in determining proximity to the ground, ensuring a soft and controlled descent, minimizing impact and preventing damage to the aircraft or its payload. The “park” state, therefore, is not merely passive but can involve intricate technology ensuring a safe conclusion to a flight.
Neutral: The Hover and Position Hold
“Neutral” in the drone world is best characterized by the hover state and advanced position hold capabilities. This mode represents a stable, controlled equilibrium where the drone maintains a stationary position and altitude without significant horizontal drift. Modern flight technology achieves this through a sophisticated combination of sensors: GPS for outdoor positioning, barometric altimeters for altitude, and often Vision Positioning Systems (VPS) for precise indoor or low-altitude outdoor stability where GPS signals might be weak or unavailable. The flight controller constantly makes micro-adjustments to motor speeds to counteract wind, air currents, and other environmental disturbances, ensuring the drone remains “neutral” in its spatial coordinates. This mode is fundamental for many applications, from stable aerial photography to detailed inspection tasks where a steady platform is essential.
Drive: Navigating the Skies
The “Drive” equivalent encompasses the standard forward, backward, and sideways flight modes that allow the drone to actively navigate through three-dimensional space. This is where the drone’s primary mission often takes place, be it surveillance, delivery, or data collection. In “Drive” mode, the flight controller processes pilot inputs (or autonomous commands) to translate desired velocities and trajectories into differential motor thrusts. This involves dynamic adjustments to the drone’s pitch, roll, and yaw angles, all while maintaining stability. Technologies like inertial measurement units (IMUs) – comprising accelerometers and gyroscopes – are continuously providing data to the flight controller, which then calculates and applies the necessary corrections to maintain controlled movement. Obstacle avoidance systems, utilizing optical, ultrasonic, or radar sensors, become critical during “Drive” to detect and navigate around potential collisions, ensuring safe passage through complex environments.
Low: Precision and Slow-Speed Maneuvers
The “Low” gear in an automotive context signifies reduced speed and increased torque for challenging terrain. In drone flight technology, the “Low” equivalent translates to modes designed for precision, slow-speed maneuvers, and enhanced control, often at the expense of maximum speed. This includes “Cinematic Mode” or “Tripod Mode,” where the drone’s response to stick inputs is softened, and acceleration/deceleration ramps are smoothed out. The goal is to facilitate extremely stable and fluid movements ideal for high-quality video recording or intricate close-up inspections. This mode leverages advanced filtering in the flight controller’s software, dampening rapid movements and ensuring that even subtle pilot inputs result in graceful, controlled motion. For specialized applications like mapping or photogrammetry, a consistent, slow speed and precise altitude are paramount, relying on highly accurate GPS and altimeter data for repeatable flight paths.
Reverse: Retrospective Flight and Emergency Protocols
While a drone doesn’t typically have a literal “reverse gear” in the automotive sense, the concept of moving backward or reversing a trajectory is certainly present in flight technology. This can manifest in several ways. Programmed backward flight is common in follow-me modes or cinematic shots. More significantly, “Reverse” can be metaphorically applied to emergency protocols and automated return functions. “Return-to-Home” (RTH) is a prime example, where the drone autonomously reverses its flight path or follows a pre-defined safe route back to its take-off point or another designated safe landing zone. This mode relies heavily on precise GPS coordinates and robust pathfinding algorithms to navigate obstacles and land safely, often utilizing a “home point” recorded at the start of the flight. Failsafe mechanisms, triggered by low battery or loss of signal, also fall under this umbrella, initiating a safe return or emergency landing sequence, effectively “reversing” the operational state to a secure outcome.
Advanced Flight Modes and Their Technological Underpinnings
Beyond the core “PRNDL” equivalents, modern flight technology offers an increasingly sophisticated array of specialized flight modes, each enabled by cutting-edge sensors, processing power, and intelligent algorithms.
Autonomous Navigation and Waypoint Flight
This advanced mode represents a significant leap in drone autonomy. Pilots can pre-program complex flight paths consisting of multiple waypoints, altitudes, and even specific actions (like taking a photo or hovering for a duration) via ground control station software. The drone then executes this entire mission autonomously, relying on highly accurate GPS, inertial navigation systems, and potentially real-time kinematic (RTK) or post-processed kinematic (PPK) GPS for centimeter-level accuracy. Obstacle avoidance systems are particularly crucial here, enabling the drone to dynamically reroute if an unexpected obstruction is detected, making the flight safer and more reliable for tasks like large-area mapping, infrastructure inspection, or agricultural surveying.
Sport Mode and Performance Dynamics
For applications demanding high agility and speed, “Sport Mode” unleashes the full performance potential of the drone. In this mode, the flight controller relaxes some of the stability assistance systems, allowing for greater tilt angles, faster acceleration, and higher top speeds. While still maintaining inherent stability, the drone becomes much more responsive to pilot inputs, enabling aggressive maneuvers. This mode is popular in drone racing and for experienced pilots who require dynamic camera movements. The technology behind it involves fine-tuned PID (Proportional-Integral-Derivative) control loops that adjust motor outputs with extreme precision and speed, allowing the drone to react almost instantaneously to commands while pushing its physical limits.
Cinematic Mode and Smooth Control
As discussed under the “Low” equivalent, Cinematic Mode (sometimes called Tripod Mode or Smooth Mode) is designed for producing professional-grade video footage. The drone’s movement speed and responsiveness are significantly reduced, and acceleration/deceleration curves are smoothed. This is achieved through sophisticated motion filtering in the flight controller’s software, ensuring that even abrupt stick movements result in slow, graceful transitions. Coupled with advanced gimbal stabilization technology, which isolates the camera from the drone’s movements, Cinematic Mode allows videographers to capture incredibly fluid and stable shots, often without the need for extensive post-production stabilization.

The Evolution of Flight Control Interfaces
The selection and management of these diverse flight modes are integral to the user experience and operational safety. Early drones had relatively simple controls, often limited to manual flight and perhaps a basic altitude hold. Today, modern flight controllers provide intuitive interfaces, often incorporating physical switches on the remote controller, touch-screen options on connected smart devices, or even voice commands. The underlying technology translates these user selections into commands for the flight control system, reconfiguring sensor processing, control algorithms, and motor responses on the fly. This evolution reflects a broader trend in flight technology: making complex aerial systems accessible and efficient for an ever-expanding range of professional and recreational applications, ensuring that operators can seamlessly transition between the drone’s “PRNDL” of flight states to achieve their mission objectives.