
In the realm of drone technology, particularly within the specialized field of Cameras & Imaging, the concept of “cross-eyed” serves as a compelling metaphor for misalignment, distortion, or an undesirable convergence in visual data capture. To understand its opposite is to delve into the principles of precise optical alignment, calibrated imaging, and rectified perspectives that are crucial for high-quality aerial photography, videography, mapping, and 3D modeling. The “opposite of cross-eyed” in this context embodies clarity, accuracy, parallelism, and an uncompromised, true-to-life visual representation.
Precision in Drone Optics: Beyond Misalignment and Distortion
The phrase “cross-eyed” immediately conjures an image of misaligned eyes, where the visual axes converge improperly, leading to confused or strained perception. In drone imaging, this translates to optical imperfections that can severely compromise the utility and quality of captured data. The opposite, therefore, signifies an ideal state of optical precision, where every component of the imaging system—from the lens elements to the sensor—works in perfect harmony to deliver an unblemished view.
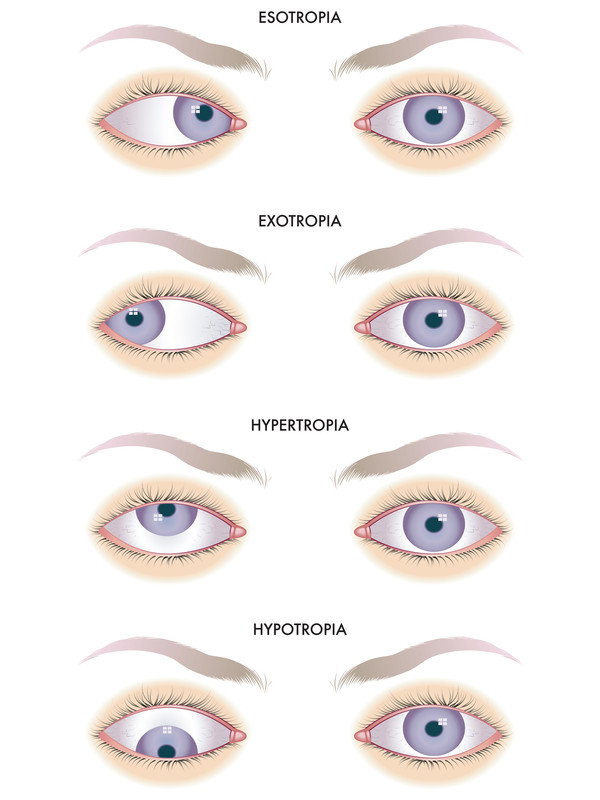
This pursuit of optical perfection begins at the lens design stage. High-quality drone cameras utilize sophisticated multi-element lenses designed to minimize aberrations such as chromatic aberration (color fringing), spherical aberration (blur at the edges), and geometric distortions like barrel or pincushion effects. A “cross-eyed” image might exhibit severe barrel distortion, where straight lines appear to bulge outwards from the center, or pincushion distortion, where they pinch inwards. The “opposite” lens corrects these, ensuring that what appears as a straight line in the real world is rendered as a straight line in the image, preserving true geometric relationships vital for applications like photogrammetry and inspection.
Furthermore, the physical alignment of the lens within its housing and its precise distance from the camera sensor (flange focal distance) are critical. Even microscopic deviations can introduce tilt, blur, or uneven focus across the image plane, creating a sense of a “skewed” or “cross-eyed” perspective. Manufacturers of professional drone cameras employ rigorous quality control and calibration procedures to ensure that each optical assembly achieves optimal alignment, guaranteeing that the image projected onto the sensor is as undistorted and uniformly focused as possible. This meticulous attention to detail is the bedrock of achieving the “opposite” of a cross-eyed view – an image of pristine clarity and geometric fidelity.
The Art of Alignment: Stereoscopy and Multi-Camera Arrays
The “opposite of cross-eyed” finds a profound expression in the design and operation of stereoscopic and multi-camera drone systems. In human vision, our two eyes provide stereopsis, allowing us to perceive depth by slightly converging on objects. However, an exaggerated “cross-eyed” convergence for distant objects can be uncomfortable and distort perception. Similarly, in multi-camera drone setups, particularly for 3D mapping or specialized FPV (First Person View) systems, the relative alignment of the cameras is paramount.
For stereoscopic 3D FPV, two cameras are often mounted with a specific interaxial distance (the distance between their optical centers), mimicking human eyes. The goal is to create a compelling sense of depth without inducing eye strain, which can occur if the cameras are “cross-eyed” (converged too much) or “wall-eyed” (diverged too much). The “opposite of cross-eyed” here implies perfectly parallel camera axes or precisely controlled convergence for specific applications, ensuring that the 3D effect is natural, immersive, and comfortable for the pilot. This precise alignment is typically achieved through robust mechanical mounts and often fine-tuned electronically, allowing for adjustments in convergence or divergence depending on the desired visual outcome and viewing distance.
Beyond stereoscopic FPV, multi-camera arrays are increasingly common on drones for applications like 360-degree photography, wide-area mapping, and cinematic virtual reality capture. In these systems, multiple cameras are fixed in a precise geometric configuration – often in a sphere or a specific angular arrangement. If these cameras are “cross-eyed” relative to each other, meaning their optical axes are not perfectly parallel or angled as designed, the resulting stitched panoramic or 3D model will suffer from parallax errors, seams, and geometric distortions that are impossible to fully correct in post-processing. The “opposite of cross-eyed” in this context demands absolute angular precision between cameras, ensuring their fields of view seamlessly overlap or align as intended. This requires sophisticated calibration processes to determine the exact relative pose (position and orientation) of each camera, allowing for accurate image stitching and photogrammetric reconstruction without visual artifacts that would betray any inherent “cross-eyed” misalignment.
Rectification and Calibration: Straightening the Drone’s Gaze

Even with high-quality lenses and careful physical alignment, raw images captured by drone cameras often exhibit subtle distortions and inconsistencies. This is where rectification and calibration become critical processes, serving as the digital means to achieve the “opposite of cross-eyed” – a perfectly straight and true visual representation.
Lens Calibration: This process involves characterizing the intrinsic parameters of a camera and lens system. These parameters include focal length, principal point (the exact center of the image relative to the lens’s optical axis), and various distortion coefficients (radial and tangential). A camera might be perfectly aligned mechanically, but the lens itself could introduce slight distortions that make the image appear marginally “cross-eyed” or skewed. Calibration typically involves capturing images of a precisely patterned target (like a checkerboard) from various angles. Sophisticated algorithms then analyze how the known pattern is distorted in the images to calculate the lens’s specific distortion profile. Once these parameters are known, software can mathematically “un-distort” every pixel in subsequent images, effectively rectifying the perspective and eliminating the subtle “cross-eyed” effects caused by the lens. This is particularly crucial for mapping and 3D modeling, where geometric accuracy is paramount. An uncalibrated camera can lead to significant errors in distance measurements, object dimensions, and overall spatial accuracy in derived products.
Image Rectification for Mapping: In photogrammetry, where drones capture hundreds or thousands of images to create orthomosaic maps and 3D models, individual images are often captured from oblique angles. These images inherently contain perspective distortion, making objects appear to converge or diverge depending on their position relative to the camera. The “opposite of cross-eyed” here means transforming these perspective images into a geometrically accurate, orthographic projection, where all ground features are depicted as if viewed directly from above, without any perspective distortion. This process involves complex geometric transformations using the camera’s calibrated intrinsic parameters, the drone’s precise GPS and IMU data (exterior orientation parameters), and ground control points (GCPs). The result is an orthomosaic map where every pixel accurately represents a specific geographic location, free from the “cross-eyed” visual compression or expansion that oblique views would create.
Gimbals and Stabilization: Maintaining Visual Equilibrium
While intrinsic camera and lens characteristics address the static “cross-eyed” issues, the dynamic nature of drone flight introduces further challenges to maintaining a stable, aligned view. This is where gimbals and advanced stabilization systems become indispensable, working to achieve the “opposite of cross-eyed” by neutralizing the drone’s motion and ensuring the camera maintains a steady, intended orientation.
A drone in flight is subject to constant vibrations, wind gusts, and pilot inputs, all of which can cause pitch, roll, and yaw movements. Without stabilization, the camera would capture a chaotic, jittery, and often blurred “cross-eyed” view, making professional aerial filmmaking or precise data acquisition impossible. Three-axis gimbals are sophisticated electro-mechanical devices that use high-speed motors and IMU sensors to counteract these movements in real-time. The gimbal continuously senses the drone’s orientation and adjusts the camera’s position to keep it perfectly level or pointed at a specific target, regardless of the drone’s motion. This allows for smooth, fluid video footage and sharp, consistently oriented still images.
The effectiveness of a gimbal is directly tied to its precision and responsiveness. A poorly tuned or low-quality gimbal might introduce its own “cross-eyed” effect, subtly tilting the horizon, exhibiting micro-jitters, or failing to maintain a perfectly perpendicular or parallel alignment to the ground. Achieving the “opposite of cross-eyed” in this context means a gimbal system that delivers buttery-smooth footage, an impeccably level horizon, and absolute consistency in camera orientation, ensuring that the visual data is free from any unwanted rotational or translational artifacts. This level of stabilization is fundamental not just for cinematic quality but also for the integrity of photogrammetric data, where even minor camera attitude variations can introduce errors into 3D models and maps.
Achieving the “Straight Ahead” Perspective in Aerial Imaging
Ultimately, the “opposite of cross-eyed” in Cameras & Imaging for drones is about achieving a “straight ahead” perspective – a view that is not only optically correct and geometrically accurate but also aligned with the intended purpose of the capture. Whether it’s a perfectly level horizon for a cinematic shot, an absolutely nadir (downward-looking) view for mapping, or precisely converged lenses for comfortable 3D FPV, this ideal state is the culmination of various technologies working in concert.
This holistic approach involves:
- Superior Optics: Lenses designed for minimal distortion and high resolution.
- Robust Mechanical Integration: Precision mounting of cameras and sensors.
- Advanced Calibration: Characterizing and correcting intrinsic camera parameters.
- Dynamic Stabilization: Gimbals and flight controllers working together to isolate the camera from drone motion.
- Sophisticated Post-Processing: Applying rectification algorithms to correct for remaining geometric distortions and perspective effects.
For aerial filmmaking, the “straight ahead” perspective allows for compelling storytelling without visual distractions or artifacts. For industrial inspections, it ensures that defects are clearly visible and precisely located. For mapping and surveying, it guarantees the geometric fidelity required for accurate measurements and reliable digital twins. In essence, the “opposite of cross-eyed” represents the pinnacle of drone imaging capability: delivering a clear, undistorted, stable, and functionally accurate visual perception of the world from above, opening up new possibilities across countless applications. It’s the assurance that what the drone sees, and what we subsequently interpret, is as close to objective reality as current technology allows.