
The Model-View-Controller (MVC) is an architectural pattern widely used in software engineering for organizing code, particularly in applications with graphical user interfaces. It promotes the separation of concerns, dividing an application into three interconnected components. This separation enhances modularity, maintainability, and scalability, making it a powerful pattern for developing complex and evolving systems, including those at the forefront of drone technology and innovation. In the context of sophisticated drone applications, from intricate flight management systems to advanced data processing platforms, understanding MVC is crucial for building robust and adaptable software solutions.
Deconstructing the MVC Pattern
At its core, MVC establishes a clear division of responsibilities, allowing different aspects of an application to be developed and managed independently. Each component plays a distinct role in processing information and interacting with the user or other system parts.
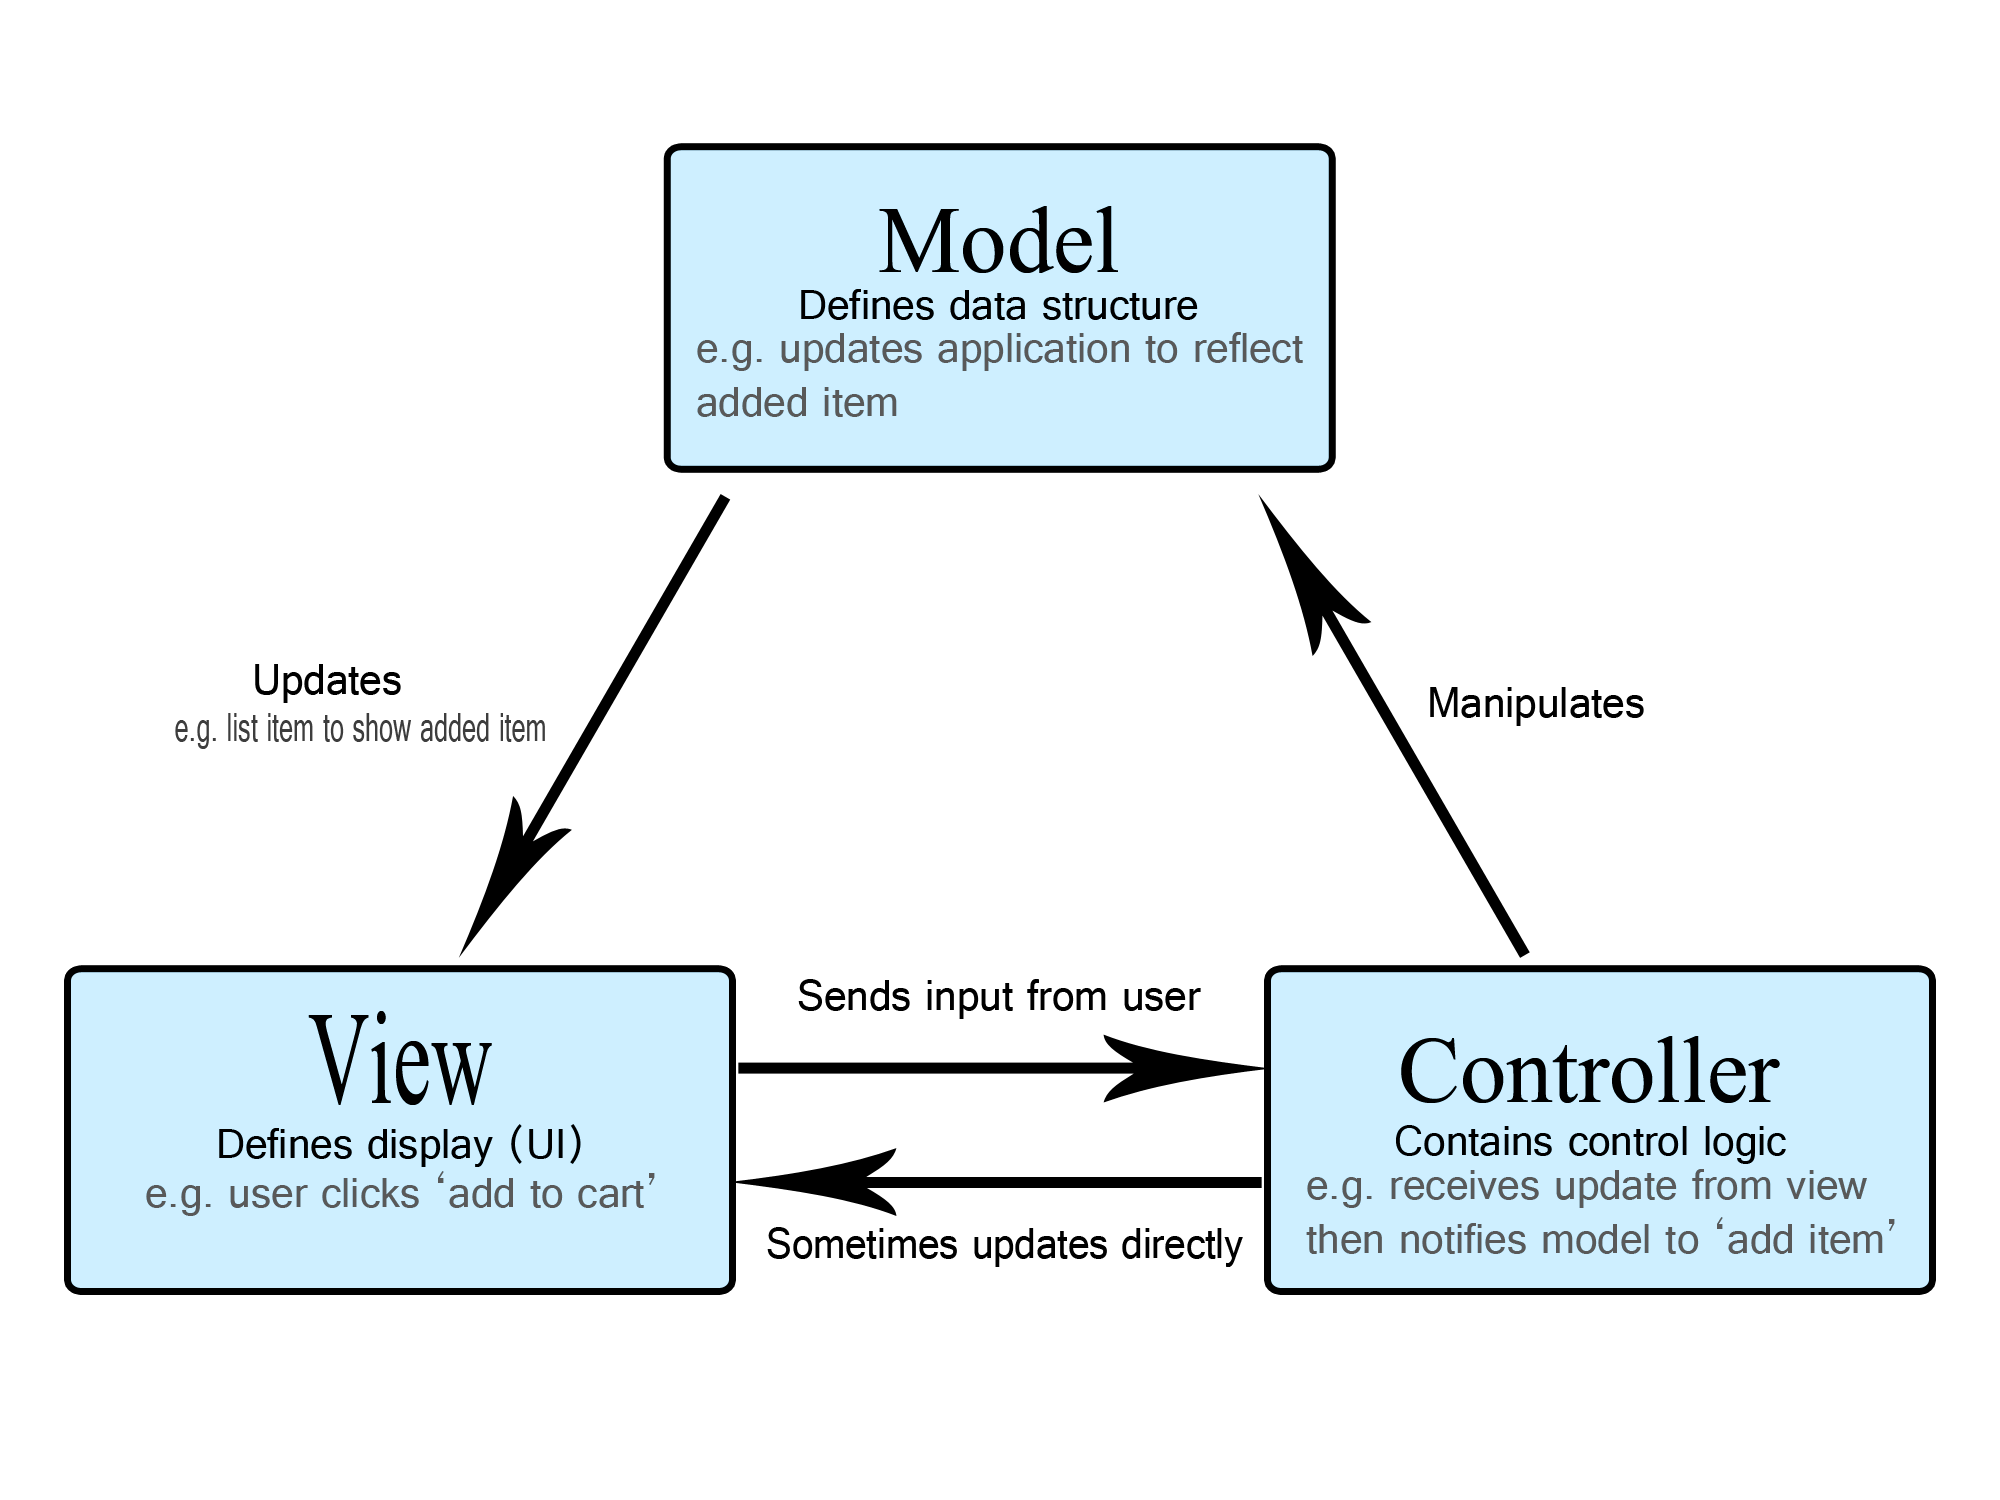
The Model: The Heart of Data and Logic
The Model is the central component of the MVC pattern. It encapsulates the application’s data, business logic, rules, and state. In essence, the Model represents the “what” of the application – the actual data and the operations that can be performed on it. It is entirely independent of any user interface, meaning it doesn’t know how its data will be displayed or manipulated by a user.
For drone-related applications, the Model could represent various critical elements:
- Drone State Data: This includes real-time telemetry such as GPS coordinates, altitude, speed, battery level, orientation (pitch, roll, yaw), and sensor readings (e.g., LiDAR, thermal camera data).
- Flight Plan Logic: Algorithms for path planning, waypoint management, obstacle avoidance rules, and mission parameters.
- Mapping Data: Geographic information system (GIS) data, terrain models, processed aerial imagery, and annotations.
- System Configuration: Settings for flight modes, safety protocols, communication parameters, and payload configurations.
- AI/ML Models: The underlying logic for AI follow modes, object recognition, anomaly detection, or predictive maintenance.
When data within the Model changes, it typically notifies its observers (often the View or Controller) that a change has occurred, allowing them to react accordingly. This notification mechanism is key to keeping the application’s various parts synchronized.
The View: Presenting Information to the User
The View is responsible for rendering the Model’s data to the user. It is the “how” of the application’s presentation – how the data is visualized and interacted with. The View typically doesn’t contain any business logic; its primary role is to display information and provide controls for user input.
In drone innovation, the View manifests in numerous ways:
- Ground Control Station (GCS) Interfaces: Displays showing flight telemetry, a real-time map with the drone’s position and flight path, battery indicators, and command buttons.
- Live FPV Feeds: The video output from a drone’s camera, potentially overlaid with telemetry data or augmented reality elements.
- Data Analysis Dashboards: Interactive charts and graphs presenting processed sensor data, thermal maps, 3D models of surveyed areas, or anomaly reports.
- Mobile Applications: User interfaces on smartphones or tablets for quick drone control, mission planning, or status monitoring.
- Heads-Up Displays (HUDs): Information projected onto goggles or screens for pilots, showing critical flight parameters and warnings.
Views are designed to be updated whenever the underlying Model changes, ensuring the user always sees the most current information. They are highly adaptable, allowing different representations of the same data (e.g., a map view versus a textual log view of flight data).
The Controller: Bridging Model and View
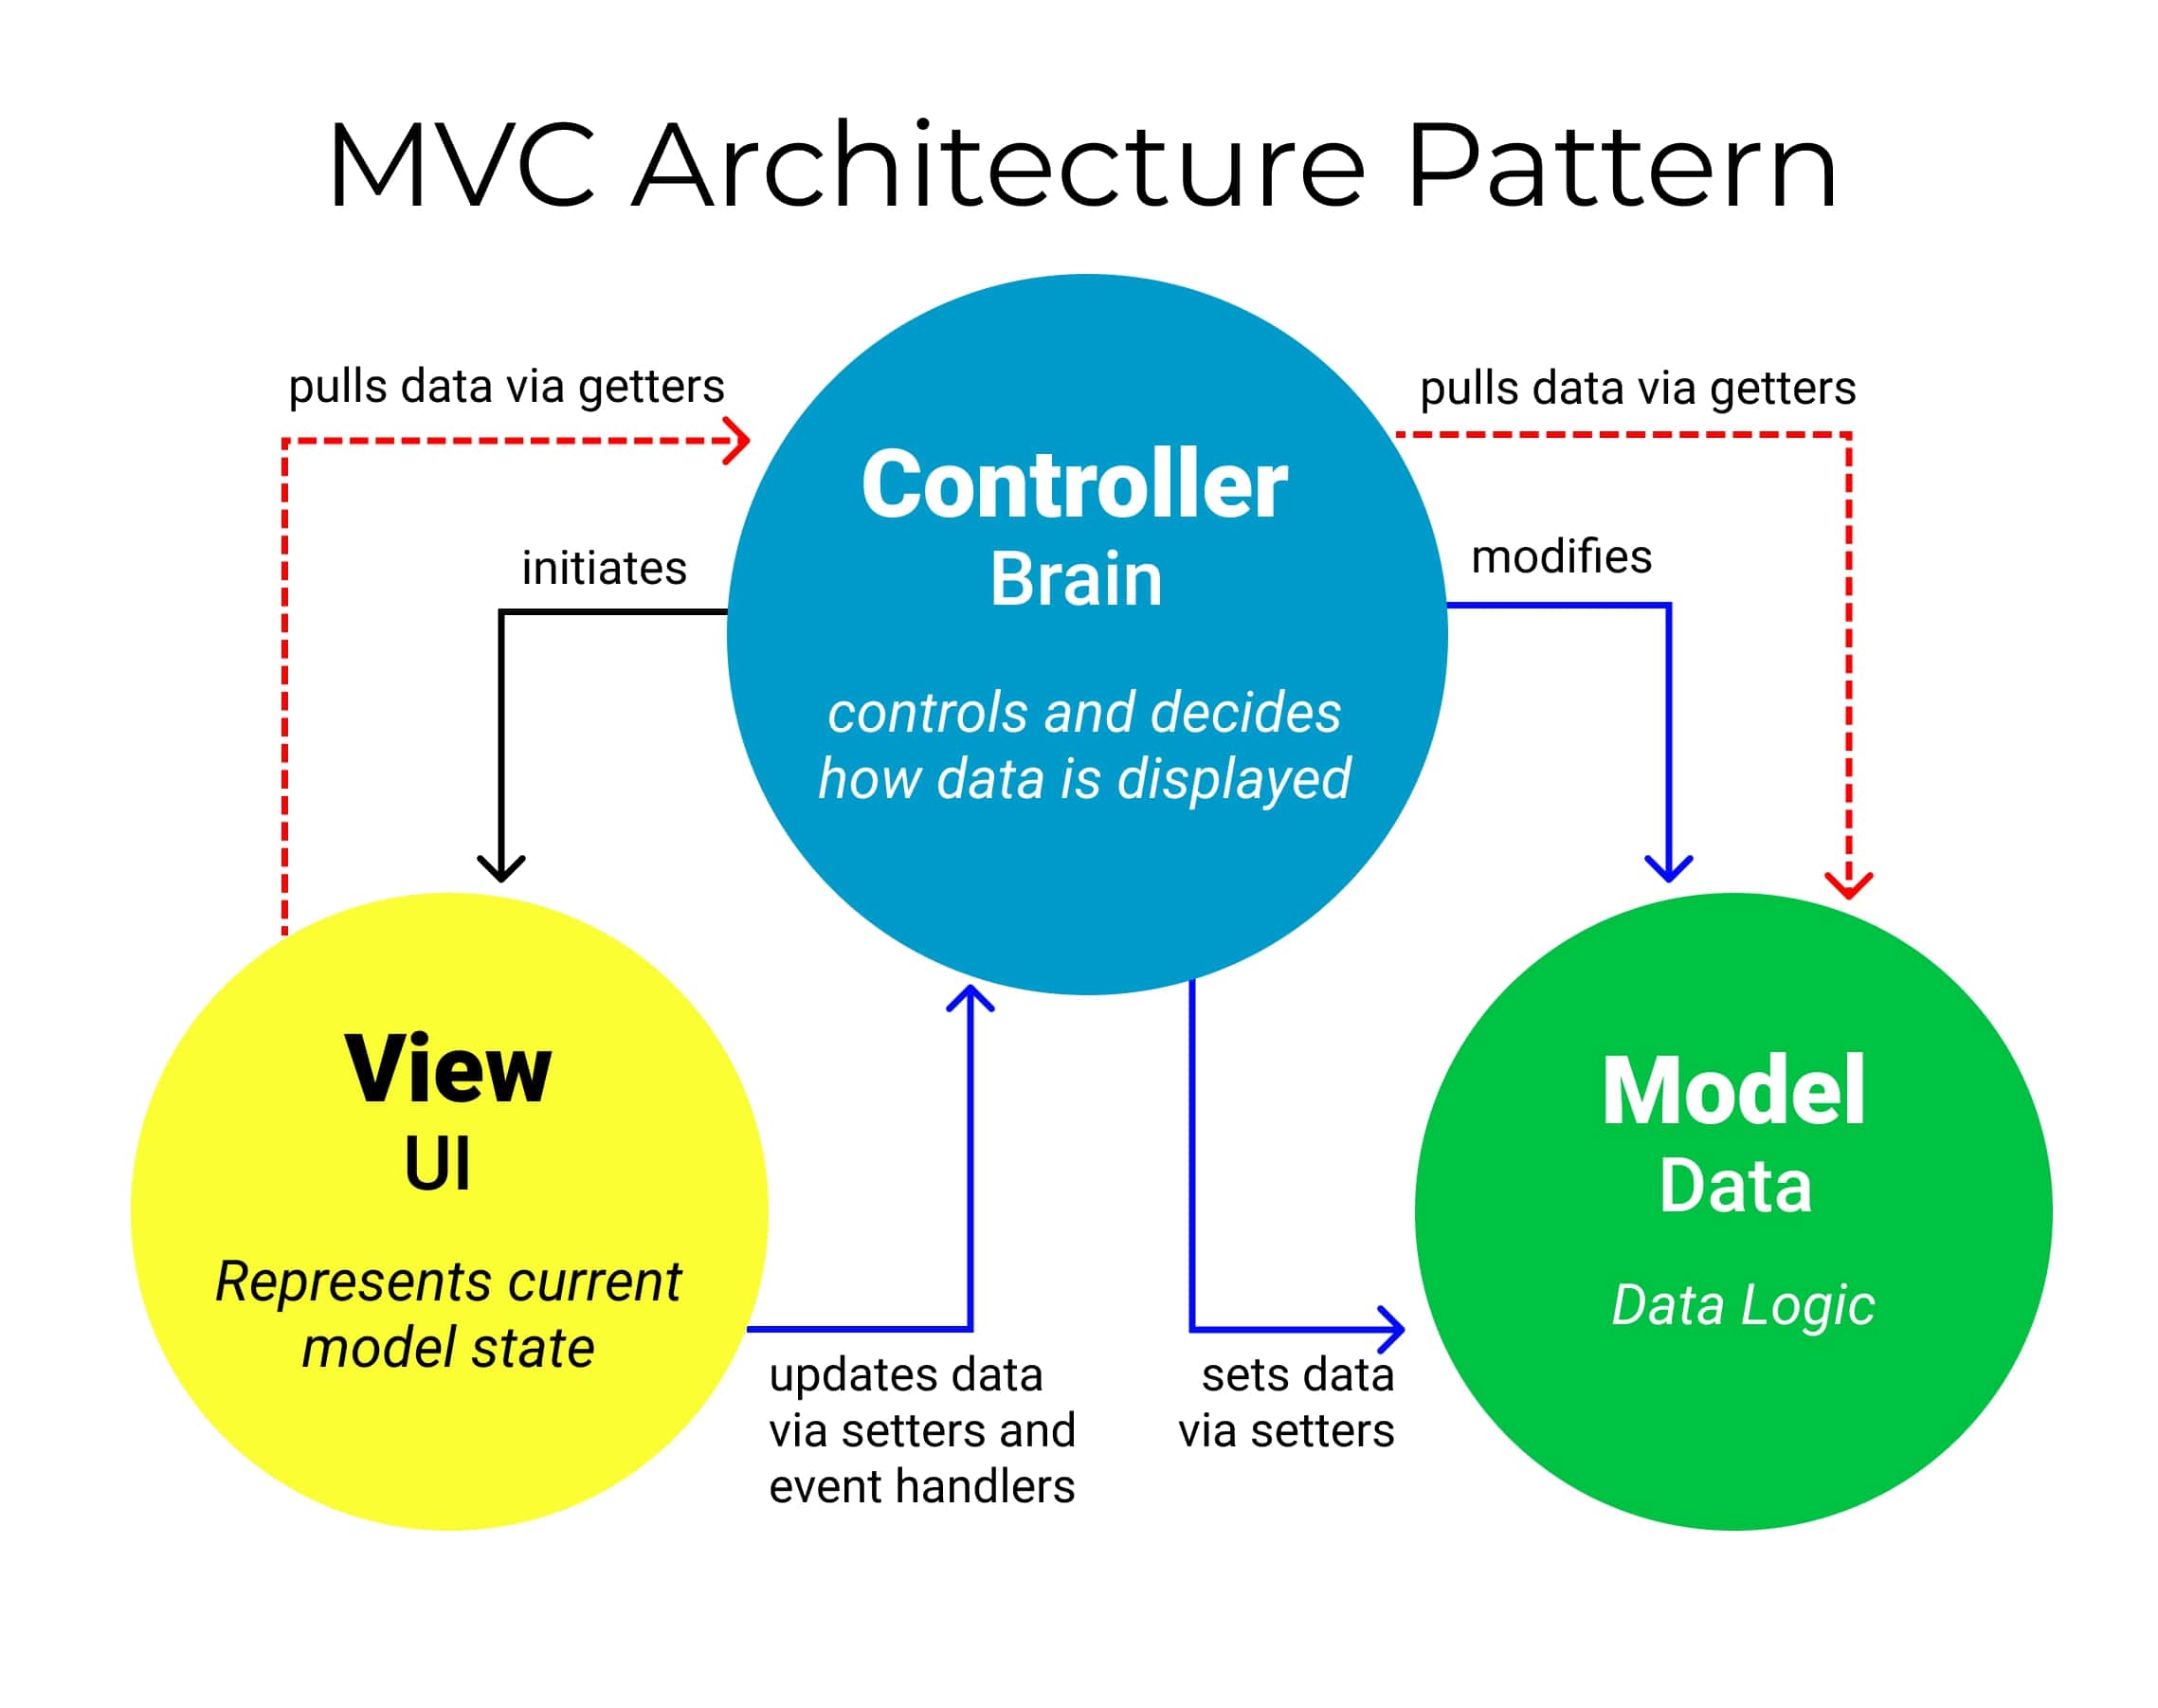
The Controller acts as an intermediary, handling user input and coordinating interactions between the Model and the View. It is the “when” of the application, determining when to update the Model based on user actions and when to refresh the View based on Model changes. The Controller interprets user input (e.g., a button click, a joystick movement, a touch gesture) and translates it into actions that affect the Model or the View.
For advanced drone systems, the Controller’s role is critical:
- Command Interpretation: Receiving pilot commands from a remote controller or a GCS (e.g., “take off,” “land,” “move to waypoint X,Y,Z,” “change flight mode”).
- Autonomous Decision-Making: In autonomous flight scenarios, the Controller processes sensor data (from the Model) and, based on defined algorithms (also part of the Model’s logic), issues commands to the drone’s flight controller, updating the drone’s state in the Model.
- User Interface Interactions: When a user draws a new flight path on a map interface (View), the Controller intercepts this input, translates it into flight plan updates, and instructs the Model to store the new plan. It then might notify the View to re-render the map with the updated path.
- System Event Handling: Responding to events like low battery warnings, GPS signal loss, or obstacle detection by triggering appropriate safety protocols or notifications.
The Controller ensures that the Model remains ignorant of the presentation (View) and that the View remains ignorant of the business logic (Model), fostering a clean separation and promoting independent evolution of each component.
Benefits of MVC in Drone Tech & Innovation
The application of the MVC pattern offers significant advantages for developing sophisticated drone-related software and pushing the boundaries of technological innovation.
Enhanced Modularity and Maintainability
By cleanly separating concerns, MVC makes individual components easier to understand, test, and maintain. For drone applications, this means:
- Independent Development: Teams can work on different parts of the system concurrently (e.g., one team on flight control algorithms, another on the user interface, and a third on sensor data processing) without stepping on each other’s toes.
- Easier Debugging: Issues can often be isolated to a specific component. If a display bug occurs, the problem likely resides in the View; if data integrity is compromised, the Model is the place to look.
- Reduced Complexity: Breaking down a complex drone system into smaller, manageable parts makes the overall architecture less daunting and more comprehensible. This is particularly important for systems involving real-time data, complex algorithms, and critical safety features.
Improved Scalability and Flexibility
As drone technology evolves, so do the demands on software systems. MVC’s structure inherently supports scalability and flexibility:
- New Views for Existing Models: The same core flight data (Model) can be presented in multiple ways (Views) – for a pilot, for a ground crew, or for automated analytics. Adding a new type of display doesn’t require rewriting the underlying data or logic.
- Adaptable to Changing Requirements: If new sensors are added to a drone, the Model can be extended to include their data. If new AI features are introduced, the Controller can be updated to interact with these new Model components and the View to display their results, all without a complete overhaul.
- Cross-Platform Development: The Model, containing core business logic, can often be reused across different platforms (e.g., a web-based GCS, a desktop application, a mobile app), with only the View and Controller needing adaptation for each specific environment.
Facilitating Collaboration and Testing
MVC’s structured approach is a boon for development teams and quality assurance:
- Clear Responsibilities: Each developer knows exactly which part of the application they are responsible for, leading to more efficient collaboration.
- Unit Testing: Individual components (especially the Model and Controller) can be thoroughly unit-tested in isolation. This is critical for drone software, where the reliability and correctness of algorithms and data processing are paramount for safe and effective operation.
- Test-Driven Development (TDD): MVC naturally lends itself to TDD, where tests are written before the code, ensuring robust and error-free components from the outset.

MVC in Modern Drone Software Development
The principles of MVC are pervasive in modern drone software, whether explicitly named or adopted through frameworks that abstract these patterns. From autonomous flight systems managing complex waypoints and obstacle avoidance to advanced mapping applications processing vast amounts of sensor data and generating 3D models, MVC-inspired architectures underpin many of these innovative solutions.
For instance, consider a drone designed for autonomous inspection of infrastructure. The Model would encompass the drone’s real-time position, camera status, sensor readings (e.g., detecting corrosion), the pre-programmed inspection path, and the historical data of previous inspections. The View might be a detailed 3D rendering of the infrastructure with the drone’s live position, highlighting areas of interest or anomalies detected by sensors, accessible via a tablet or a control room display. The Controller would interpret user commands (e.g., “start inspection,” “focus on point X”), process real-time sensor inputs to adjust the drone’s flight path for optimal data collection, and update the Model with new inspection data. If the AI detects a critical anomaly, the Controller might trigger an alert in the View and update the anomaly status in the Model.
In essence, MVC provides a robust and scalable blueprint for constructing the sophisticated software infrastructure that powers the cutting-edge capabilities of drones, enabling developers to build, maintain, and innovate with greater efficiency and precision. It allows for the intricate dance between data, presentation, and control, which is fundamental to the advanced technological landscapes of modern drone applications.