
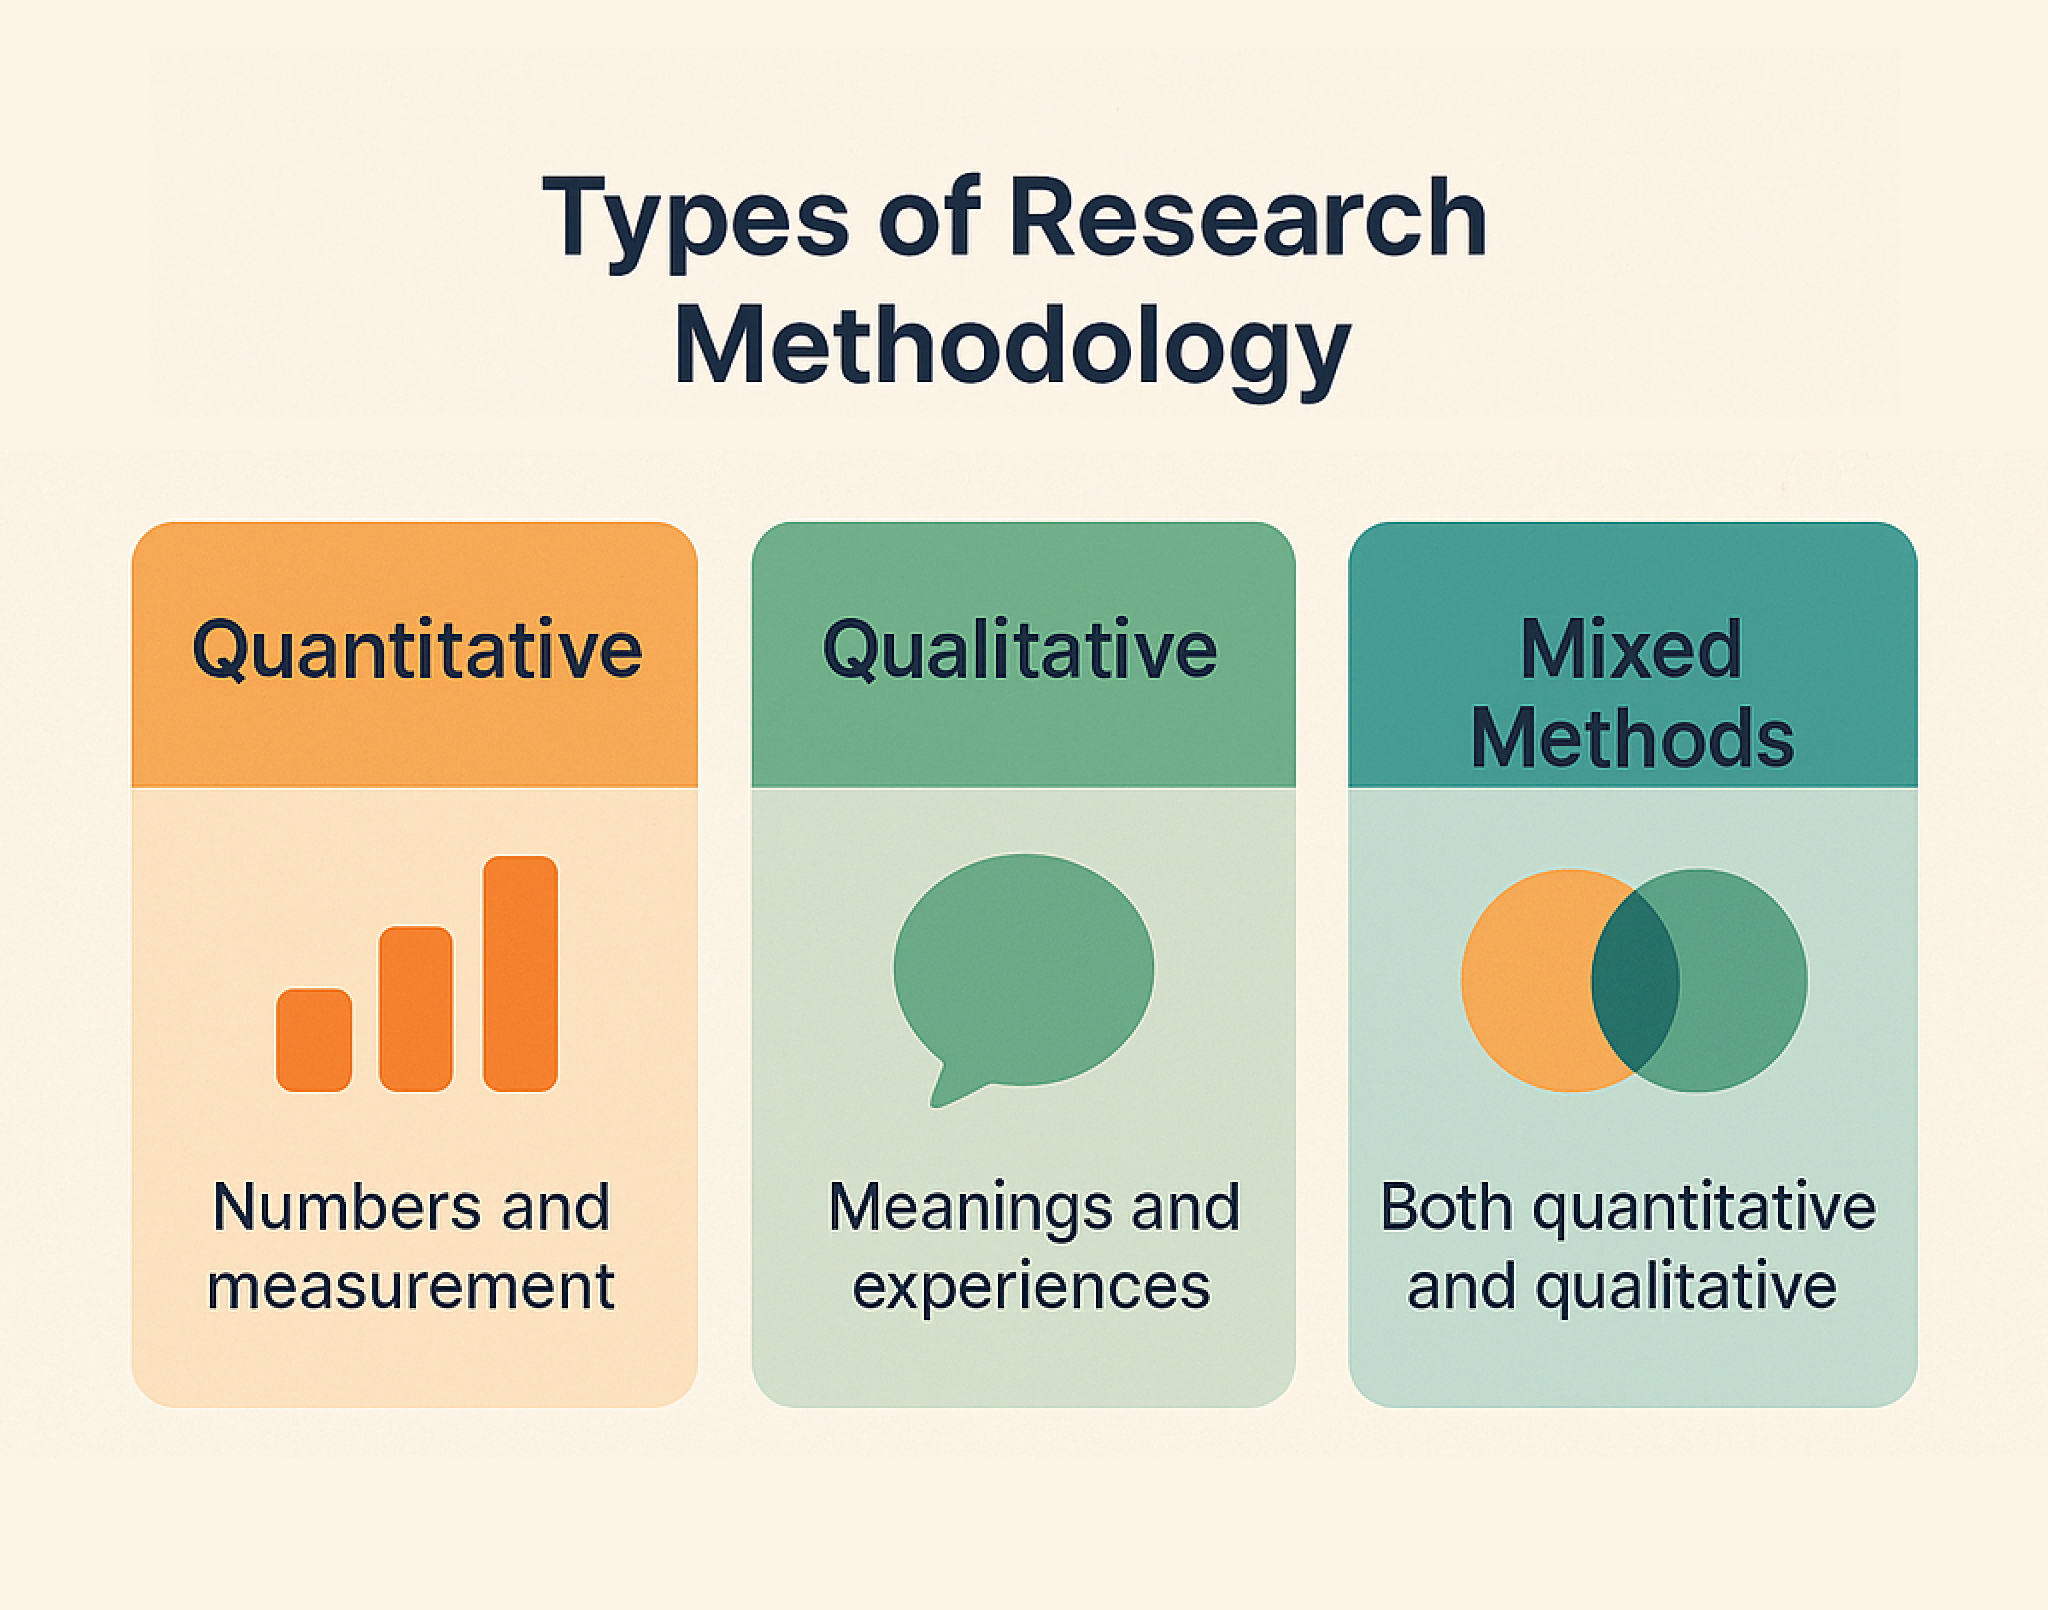
The rapid advancement of drone technology has opened unprecedented avenues for innovation, particularly in areas like autonomous flight, AI-powered features, sophisticated mapping, and remote sensing. Understanding the underlying research methodologies that drive these innovations is crucial for appreciating their scientific rigor, validity, and potential impact. “The research” in this context refers to the systematic inquiry and development processes employed by engineers, scientists, and innovators to push the boundaries of what drones can achieve, transforming them from mere flying cameras into intelligent, versatile platforms. These methodologies are diverse, drawing from computer science, robotics, electrical engineering, data science, and cognitive psychology, ensuring a robust framework for discovery and application.
Conceptualization and Problem Definition in Drone Innovation
Every significant innovation begins with a clearly defined problem or a compelling research question. In the realm of drone tech and innovation, this initial phase is critical for setting the trajectory of the entire research project. Researchers identify gaps in current capabilities, address existing operational challenges, or explore novel applications that leverage emerging technologies. For instance, developing an “AI Follow Mode” might stem from the problem of manual tracking being inconsistent or resource-intensive, while improving “Autonomous Flight” capabilities often targets reducing human intervention and enhancing safety in complex environments.
Identifying Research Gaps and Opportunities
This involves comprehensive literature reviews, market analysis, and engagement with industry experts. Researchers scrutinize existing drone systems, AI algorithms, and sensing technologies to pinpoint limitations or areas ripe for improvement. Are current obstacle avoidance systems robust enough for urban environments? Can remote sensing drones collect data with higher precision and less post-processing? These questions guide the initial conceptualization. For “Mapping” and “Remote Sensing” innovations, this might involve assessing the resolution, spectral bands, or processing speed of current solutions and envisioning ways to overcome their drawbacks.
Hypothesis Formulation
Once a problem is defined, researchers formulate testable hypotheses. A hypothesis acts as a proposed explanation or a prediction that can be empirically validated. For a new “AI Follow Mode,” a hypothesis might state: “A deep learning model trained on diverse human movement patterns will achieve higher tracking accuracy and responsiveness compared to traditional vision-based tracking algorithms.” For “Autonomous Flight,” it could be: “Integrating real-time sensor fusion with predictive control algorithms will significantly reduce navigation errors in GPS-denied environments.” These hypotheses guide the subsequent research design and experimentation.
Research Design and Data Acquisition Strategies
With a clear conceptual framework, the next step involves designing the research methodology and acquiring the necessary data. This phase is highly dependent on the nature of the innovation being pursued, ranging from purely theoretical models to extensive field experiments. The chosen design dictates how data will be collected, processed, and analyzed to test the formulated hypotheses.
Experimental Design
Many innovations in drone tech require rigorous experimental designs to validate performance. This involves creating controlled environments where variables can be manipulated and their effects observed. For instance, testing a new “Obstacle Avoidance” system might involve setting up a controlled obstacle course with varying complexities and lighting conditions to measure the system’s reaction time, detection accuracy, and collision avoidance success rate. Such experiments often compare the performance of a novel approach against existing benchmarks or control groups. When developing advanced “Autonomous Flight” algorithms, simulations play a crucial role, allowing for the testing of thousands of scenarios without the risks and costs associated with real-world flight.
Data Collection for AI and Sensing
Data is the lifeblood of many modern drone innovations, especially those leveraging AI and advanced sensing. For “AI Follow Mode,” extensive datasets comprising video footage of objects in motion, annotated with their precise trajectories, are essential for training machine learning models. Similarly, “Mapping” and “Remote Sensing” innovations rely on collecting vast amounts of geospatial data – high-resolution imagery, LiDAR point clouds, multispectral or hyperspectral data – under various environmental conditions.
Methods of data acquisition include:
- Sensor Integration: Developing custom sensor payloads (e.g., integrating novel thermal cameras with specific optical lenses for agricultural remote sensing).
- Field Surveys: Conducting systematic flights over target areas to collect raw imagery and sensor data. This requires careful flight planning, adherence to safety protocols, and often includes ground truth data collection for calibration and validation.
- Crowdsourcing/Public Datasets: Utilizing existing large-scale datasets, sometimes augmented by community contributions, especially for general computer vision tasks that can be adapted for drone applications.
- Simulation Environments: Generating synthetic data within high-fidelity simulation platforms (e.g., AirSim, Gazebo, Carla) that mimic real-world physics and sensor outputs. This is invaluable for initial algorithm development and testing, particularly for “Autonomous Flight” and complex “Obstacle Avoidance” scenarios, allowing researchers to explore extreme conditions safely.
Algorithm Development and Implementation
At the heart of “Tech & Innovation” in drones lies the development and implementation of sophisticated algorithms. This phase translates theoretical concepts and data-driven insights into functional software that powers intelligent drone behaviors and data processing capabilities.
Machine Learning and Deep Learning
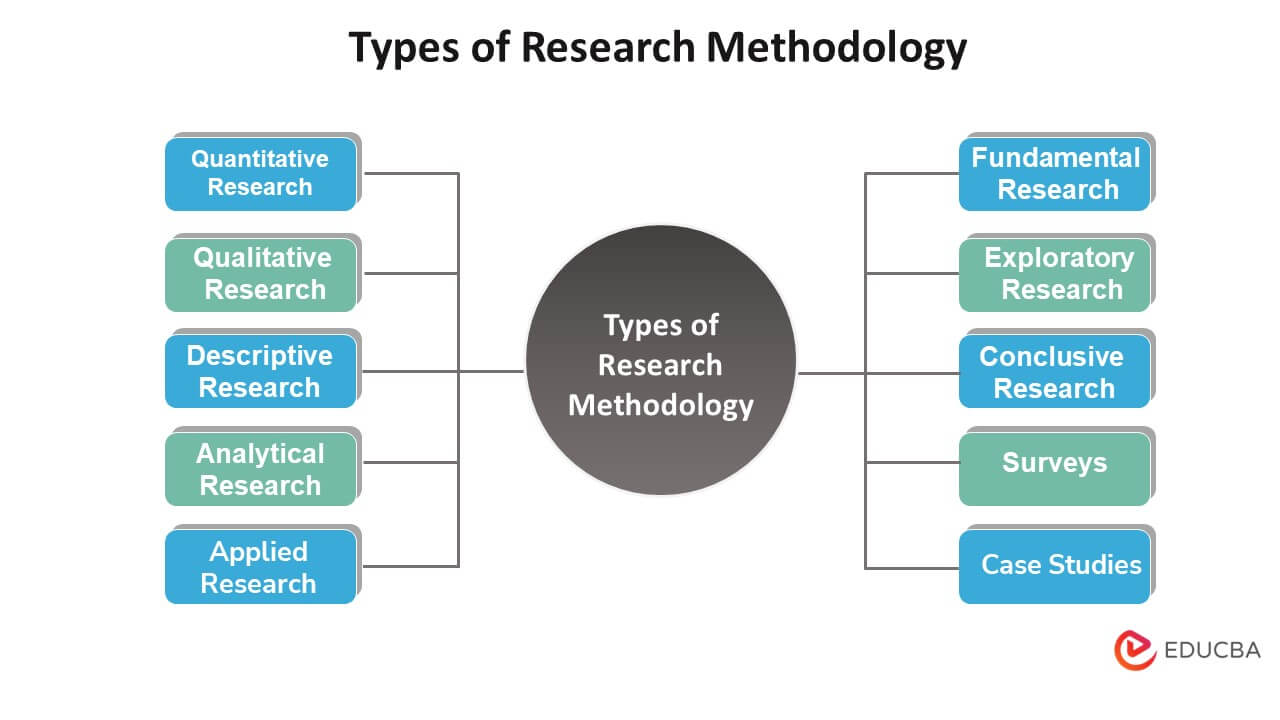
For features like “AI Follow Mode” or advanced object recognition in “Remote Sensing,” machine learning (ML) and deep learning (DL) algorithms are paramount. This involves:
- Model Selection: Choosing appropriate neural network architectures (e.g., CNNs for image processing, RNNs/Transformers for temporal data) or traditional ML models based on the problem characteristics.
- Training and Optimization: Feeding vast amounts of collected data to the models, iteratively adjusting their parameters to minimize prediction errors. This often requires significant computational resources, utilizing GPUs or specialized AI accelerators.
- Deployment: Optimizing the trained models for efficient execution on resource-constrained drone hardware, often involving model compression or quantization techniques.
Control Systems and Navigation Algorithms
“Autonomous Flight” heavily relies on robust control systems and navigation algorithms. This includes:
- Path Planning: Algorithms that compute optimal trajectories for the drone to follow, considering obstacles, waypoints, and efficiency constraints. This can range from simple waypoint navigation to complex real-time re-planning in dynamic environments.
- State Estimation: Using sensor fusion techniques (e.g., Kalman filters, EKF, UKF) to accurately estimate the drone’s position, velocity, and orientation from noisy sensor data (GPS, IMU, vision sensors).
- Flight Control: Developing PID controllers, LQR, or model predictive control (MPC) strategies to maintain stable flight and execute desired maneuvers based on estimated states and planned paths.
- Obstacle Avoidance: Integrating perception systems (LiDAR, stereo cameras, radar) with planning algorithms to detect and react to obstacles in real-time, preventing collisions.
Data Processing for Mapping and Sensing
Innovations in “Mapping” and “Remote Sensing” involve developing algorithms for processing the vast amounts of sensor data collected by drones. This includes:
- Photogrammetry and SfM (Structure from Motion): Algorithms for reconstructing 3D models and orthomosaics from overlapping 2D images, crucial for high-precision mapping.
- Point Cloud Processing: Techniques for filtering, segmenting, and classifying LiDAR data to create detailed digital elevation models (DEMs) or 3D object models.
- Image Classification and Segmentation: Applying ML/DL to multispectral/hyperspectral imagery for tasks like crop health assessment, land-use classification, or environmental monitoring.
Testing, Validation, and Performance Evaluation
After algorithms are developed and implemented, the rigorous process of testing and validation begins. This phase is critical for ensuring the reliability, accuracy, and safety of the drone innovations, especially for applications involving “Autonomous Flight” and complex decision-making.
Simulation-Based Testing
Initial testing often occurs in high-fidelity simulation environments. Simulators provide a safe, repeatable, and cost-effective platform to evaluate algorithm performance under various conditions, including scenarios that are difficult or dangerous to replicate in the real world (e.g., sensor failures, extreme weather, complex obstacle fields). This allows researchers to quickly iterate on designs and identify major flaws before real-world deployment. Metrics such as navigation error, collision rate, tracking accuracy, and mission completion rate are typically measured.
Controlled Environment Testing
Once simulation results are promising, prototypes are tested in controlled physical environments. This might involve indoor flight arenas with motion capture systems for precise ground truth tracking, or outdoor test ranges with known parameters. This bridges the gap between simulated and real-world performance, revealing hardware-software integration challenges and real-world sensor noise characteristics. For “AI Follow Mode,” this means testing with human subjects or vehicles in a safe, open area, meticulously logging the drone’s movements and comparing them against desired trajectories.
Field Testing and Real-World Validation
The ultimate test for any drone innovation is its performance in actual operational environments. Field testing for “Autonomous Flight” involves deploying drones in diverse outdoor settings, often with varying terrain, weather conditions, and GPS availability. For “Mapping” and “Remote Sensing,” this means conducting surveys over representative landscapes (farmlands, construction sites, forests) to assess the accuracy, resolution, and utility of the generated data products against established benchmarks or traditional methods. This stage also highlights unforeseen challenges related to environmental factors, communication reliability, and regulatory compliance.
Performance Metrics and Evaluation
A robust methodology includes defining clear performance metrics and evaluation protocols. For “Autonomous Flight,” metrics might include trajectory tracking error, power consumption, task completion time, and robustness to disturbances. For “AI Follow Mode,” accuracy (e.g., root mean square error of distance to target), latency, and stability of tracking are crucial. In “Mapping” and “Remote Sensing,” evaluation often focuses on spatial accuracy (RMSE), completeness of data, processing time, and the quality of derived products (e.g., classification accuracy for crop health). Statistical analysis is then applied to the collected data to draw meaningful conclusions about the innovation’s effectiveness and reliability.
Ethical Considerations and Future Directions
Beyond technical validation, a complete research methodology in drone tech and innovation must also address the broader implications of the developed technologies, particularly concerning ethical considerations and societal impact. This includes privacy, safety, and accountability. Researchers must anticipate potential misuses or unintended consequences and strive to build safeguards into their designs and deployment strategies.
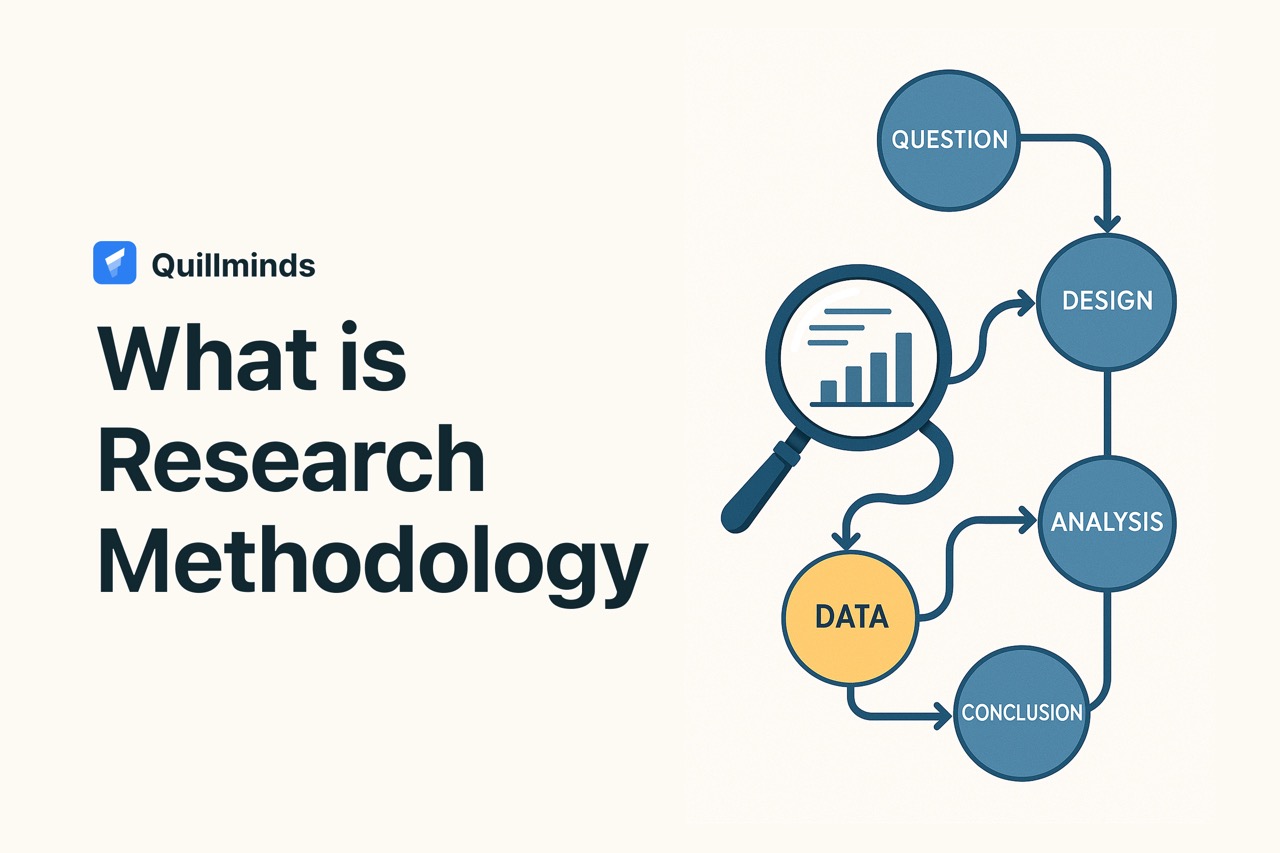
Furthermore, research methodology is not a static endpoint but an iterative process. Findings from validation often lead to new research questions, refinements in algorithms, or the identification of entirely new areas for exploration. The insights gained from one project in “Autonomous Flight” might inform the next generation of “AI Follow Mode” algorithms, or advanced “Remote Sensing” capabilities could pave the way for more sophisticated “Mapping” applications. By continuously engaging in this cyclical process of inquiry, development, testing, and reflection, the field of drone tech and innovation continues to evolve, pushing the boundaries of what these remarkable machines can achieve for the benefit of society.