
Velocity, a cornerstone concept in physics and engineering, transcends a simple definition to become a fundamental parameter driving the most advanced drone technologies. While often used interchangeably with “speed” in common parlance, velocity carries a far more precise and critical meaning, especially in the realm of modern aerial robotics and autonomous systems. At its core, velocity defines not only how fast an object is moving but also in what direction. This vectorial quality is what makes velocity indispensable for the sophisticated functionalities seen in today’s drones, from autonomous navigation to intelligent tracking and precise mapping.
The Core Concept: Velocity Defined for Advanced Systems
Understanding velocity is the bedrock upon which complex drone operations are built. Without a precise grasp of an aircraft’s velocity vector, autonomous functions would be impossible, and even basic flight would be unstable.
Speed vs. Velocity: A Crucial Distinction
The primary differentiator between speed and velocity lies in direction. Speed is a scalar quantity, indicating only the magnitude of motion—how fast an object is traveling (e.g., 50 kilometers per hour). Velocity, conversely, is a vector quantity, encompassing both magnitude and direction (e.g., 50 kilometers per hour due north).
In the context of drone technology, this distinction is paramount. A drone’s flight controller doesn’t just need to know its speed; it critically needs to know its velocity in three-dimensional space. Is it moving forward, backward, left, right, up, or down, and at what rate in each of these axes? This vectorial information allows the flight control system to make informed decisions about thrust adjustments, course corrections, and attitude stabilization, ensuring the drone adheres to its programmed path and reacts appropriately to external forces or commanded movements. For instance, maintaining a constant ground speed during mapping is insufficient; the drone must maintain a constant ground velocity in a specific direction to ensure uniform image overlap.
Vectorial Nature and Components
A drone’s velocity is typically broken down into its components along the X, Y, and Z axes in a defined coordinate system (e.g., north-east-down or body-fixed frame). For example:
- Vx: Velocity along the X-axis (e.g., forward/backward).
- Vy: Velocity along the Y-axis (e.g., left/right).
- Vz: Velocity along the Z-axis (e.g., up/down).
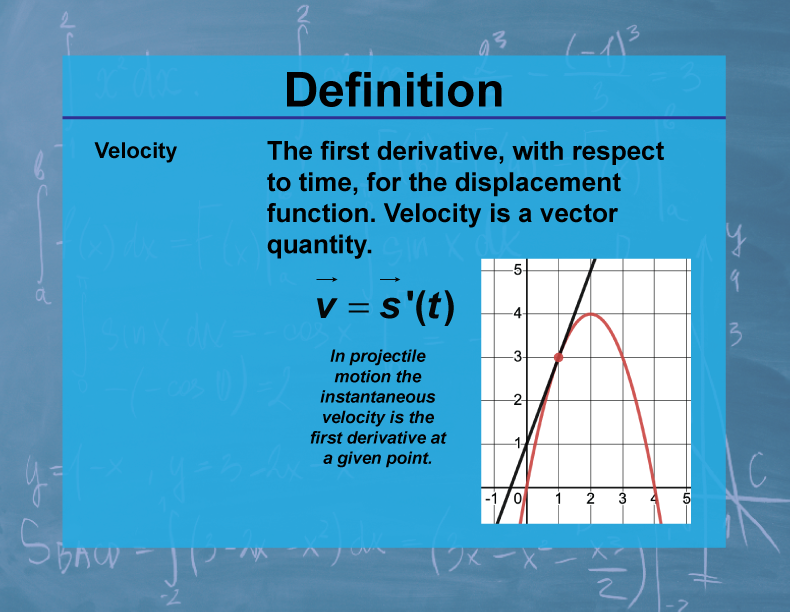
These components are continuously measured by various onboard sensors, including GPS (for ground speed and direction), inertial measurement units (IMUs) combining accelerometers and gyroscopes (for instantaneous changes in velocity and angular rates), and sometimes optical flow sensors or radar/lidar for relative velocity to nearby objects. Sensor fusion algorithms then combine this disparate data to provide a robust and accurate estimate of the drone’s true velocity vector. This fused velocity data is the lifeblood of advanced drone functions, enabling everything from smooth cinematic movements to pinpoint autonomous landings.
Velocity’s Indispensable Role in Autonomous Flight
Autonomous flight represents the pinnacle of drone innovation, and velocity is its core enabler. For a drone to navigate, avoid obstacles, and execute complex missions without human intervention, it must have an exquisite understanding and control over its velocity.
Path Planning and Trajectory Following
Autonomous drones rely on sophisticated path planning algorithms to determine the most efficient and safe route from a starting point to a destination. This involves calculating a series of waypoints and the precise velocity vectors required at each point to transition smoothly and accurately. Trajectory following then becomes the real-time execution of this plan, where the flight controller continuously adjusts motor speeds and propeller thrusts to match the commanded velocity vector. Deviations from the planned velocity due to wind, payload shifts, or sensor errors are immediately detected, and corrective actions are initiated. Without precise velocity control, a drone would drift off course, consume excessive power, or fail to reach its target with the required accuracy. This is crucial for applications like automated inspection of infrastructure or drone delivery, where deviations can have significant safety and operational consequences.
Dynamic Obstacle Avoidance
One of the most challenging aspects of autonomous flight is dynamic obstacle avoidance. This requires the drone to not only detect obstacles but also predict their future positions based on their observed velocities and then calculate an evasive maneuver that alters the drone’s own velocity to avoid a collision. Sensors like lidar, radar, and stereo vision cameras provide data on object positions and, crucially, their relative velocities to the drone. Algorithms then process this information to compute collision probability and dynamically generate new, safe flight paths, adjusting the drone’s velocity vector in real-time. This capability transforms drones from simple remote-controlled vehicles into intelligent, perception-aware systems.
Precision Landing and Takeoff
For many advanced applications, such as package delivery, charging at an autonomous base station, or operating in confined spaces, precision landing and takeoff are non-negotiable. Achieving sub-meter accuracy often relies on specialized vision systems or ultra-wideband (UWB) radio positioning, but these systems output positional data. It is the integration with highly accurate velocity estimates that allows the drone to smoothly decelerate, arrest its horizontal motion, and precisely descend onto a target. During takeoff, controlled acceleration and a vertical velocity profile are essential to safely clear obstacles and transition into forward flight. Any inaccuracies in velocity estimation can lead to unstable approaches, missed landing pads, or even damage to the drone or its surroundings.
Enhancing AI Follow Mode with Velocity Data
AI Follow Mode, a popular feature in consumer and professional drones, exemplifies how velocity data powers intelligent, responsive, and cinematic tracking. This capability moves beyond simple GPS following to anticipate subject movement and maintain optimal framing.
Predictive Tracking for Smooth Motion
Instead of merely reacting to the current position of a subject, advanced AI Follow Modes utilize velocity data to predict the subject’s future trajectory. By continuously monitoring the subject’s speed and direction, along with its own, the drone can apply predictive algorithms (like Kalman filters) to estimate where the subject will be in the next few milliseconds. This allows the drone to initiate smooth, proactive movements, adjusting its velocity to stay ahead or alongside the subject, rather than lagging behind. The result is fluid, natural-looking footage that feels professionally orchestrated, even when the subject’s movement is erratic.
Adapting to Subject Speed and Direction
A key aspect of effective AI tracking is the drone’s ability to adapt its own velocity dynamically to match or anticipate the subject’s. If a subject suddenly accelerates, the drone must instantly calculate the required velocity change to maintain its relative position and angle. Similarly, if the subject changes direction, the drone needs to compute a new velocity vector to execute a smooth turn or arc around the subject. This requires constant real-time processing of both the drone’s and the subject’s velocity, allowing the drone to be a responsive and intelligent aerial companion. Without this sophisticated velocity management, the drone would either overshoot, undershoot, or lose track of the subject entirely.
Maintaining Optimal Distance and Framing
Beyond simply following, AI Follow Mode often incorporates parameters for maintaining a specific distance and framing. This involves constantly adjusting the drone’s velocity along the X, Y, and Z axes to keep the subject centered or positioned according to user-defined cinematic rules. For example, if the subject speeds up and moves further away, the drone will increase its forward velocity to close the gap while also potentially adjusting its altitude (vertical velocity) to maintain a consistent framing. This multi-axis velocity control, guided by AI, transforms a tracking mission into a seamless storytelling tool, delivering consistent and visually appealing shots regardless of the subject’s motion.
Velocity for Accurate Mapping and Remote Sensing
In mapping and remote sensing applications, drones collect vast amounts of geospatial data, often used to create highly accurate 2D orthomosaics, 3D models, and digital elevation models. The precision of these outputs is directly tied to the drone’s velocity management during data acquisition.
Georeferencing and Data Acquisition
For images and sensor data to be accurately georeferenced—meaning linked to precise geographical coordinates—the drone’s position and orientation at the exact moment of data capture are critical. Just as important, however, is the drone’s velocity. Consistent, controlled velocity along predefined flight lines ensures uniform ground sampling distance (GSD) and proper image overlap, which are vital for photogrammetric processing. Any significant deviation in velocity can lead to inconsistent coverage, gaps in data, or distortions that compromise the final map’s accuracy. Advanced mapping drones often integrate RTK (Real-Time Kinematic) or PPK (Post-Processed Kinematic) GPS systems to provide centimeter-level positional accuracy, but it is the precision control of velocity that ensures these accurate positions are maintained throughout the mission, preventing “smearing” of data points.
Compensating for Motion Blur
Motion blur is a common challenge in aerial imaging, particularly when capturing high-resolution photos or videos from a moving platform. The drone’s velocity relative to the ground, combined with the camera’s shutter speed, determines the extent of blur. Advanced drone systems use velocity data to compensate for this. By knowing its exact velocity vector, the drone can adjust its camera’s gimbal to counteract the motion (gimbal stabilization), or, in more sophisticated setups, inform the camera’s shutter timing or even mechanically shift the sensor slightly during exposure (similar to image stabilization in handheld cameras) to minimize blur. For video, precise velocity control allows for smoother pans and tilts, reducing visual judder caused by inconsistent movement.
Creating Orthomosaics and 3D Models
The creation of seamless orthomosaics (geometrically corrected aerial images) and accurate 3D models from drone imagery relies heavily on the quality of the input data. Consistent flight velocity ensures that each image in a sequence captures a uniform portion of the ground with appropriate overlap, enabling photogrammetry software to accurately stitch them together. Inconsistent velocity can lead to irregular image spacing, making it difficult for software to find common points between images, resulting in misalignments, distorted models, or gaps. Furthermore, for generating dense point clouds for 3D modeling, precise knowledge of the drone’s velocity and attitude throughout the flight allows for robust bundle adjustment and reconstruction, leading to highly accurate and detailed digital representations of real-world environments.
The Future of Velocity Control in Drone Innovation
As drones become more autonomous and integrated into complex ecosystems, the mastery of velocity will continue to be a driving force behind innovation.
Real-time Kinematics (RTK) and Post-Processed Kinematics (PPK)
RTK and PPK technologies enhance the precision of GPS data, providing centimeter-level positional accuracy. While primarily concerned with position, their true power in advanced drone operations lies in how they refine velocity estimation. By delivering highly accurate, low-noise positional updates at high frequencies, RTK/PPK systems allow for more precise calculation of the drone’s instantaneous velocity. This improved velocity data translates directly into better autonomous navigation, more stable flight, and significantly enhanced data quality for mapping and inspection, enabling critical applications in surveying, construction monitoring, and agricultural management where absolute accuracy is paramount.
Advanced Sensor Fusion
The future of drone velocity control will rely even more heavily on advanced sensor fusion techniques. Integrating data from GPS, IMUs, vision-based systems (optical flow, stereo cameras), lidar, and even ultrasonic sensors will create a more robust and fault-tolerant understanding of the drone’s velocity in highly complex and dynamic environments. AI and machine learning algorithms will play an increasingly significant role in intelligently weighing and combining this sensor data, allowing drones to maintain precise velocity control even in GPS-denied environments or amidst heavy electromagnetic interference. This will lead to drones capable of navigating intricate indoor spaces, flying safely in dense urban canyons, and performing intricate maneuvers with unparalleled accuracy.
Machine Learning for Trajectory Optimization
Machine learning (ML) is poised to revolutionize how drones manage velocity for optimal performance. Instead of relying solely on pre-programmed flight dynamics models, ML algorithms can learn from flight data to dynamically optimize velocity profiles for specific missions, payloads, and environmental conditions. This could include learning the most energy-efficient velocity to carry a particular payload, the optimal velocity to maintain camera stability in turbulent winds, or the best deceleration profile for the smoothest landing. Predictive ML models can anticipate environmental changes or subject behaviors, allowing the drone to adjust its velocity proactively, further enhancing autonomy, safety, and efficiency across a wide spectrum of drone applications, from package delivery to environmental monitoring.
In essence, velocity is far more than just “how fast.” It is the directional force that shapes a drone’s capabilities, transforming simple flight into intelligent, autonomous, and incredibly precise operations that are continually pushing the boundaries of what aerial technology can achieve.