
In the rapidly evolving landscape of drone technology and innovation, where data fuels everything from autonomous flight paths to advanced remote sensing analytics, understanding the nuances of data sets is paramount. Raw data, in its unrefined form, can often be chaotic, filled with anomalies, and misleading. To transform this raw influx into actionable intelligence, robust statistical tools are indispensable. Among these, the interquartile range (IQR) stands out as a powerful, yet often underappreciated, metric for discerning the true spread and identifying critical deviations within a data set. Far more resilient to extreme values than simpler measures like the standard deviation, the IQR offers a clearer window into the central tendencies and variability that define the performance and outcomes of drone operations, mapping endeavors, and AI-driven systems.
The Foundation of Data Distribution: Understanding the IQR
Every drone operation, whether it’s a high-precision LiDAR scan for urban planning or an agricultural survey using multispectral cameras, generates a deluge of data. This data, when collected, forms a data set—a collection of values pertaining to a specific measurement or observation. To make sense of this collection, we need statistical measures that describe its central tendency (like the mean or median) and its dispersion or spread. While the range (the difference between the maximum and minimum values) provides a basic idea of spread, it is heavily influenced by outliers. Similarly, the standard deviation, while widely used, can also be disproportionately affected by extreme data points.
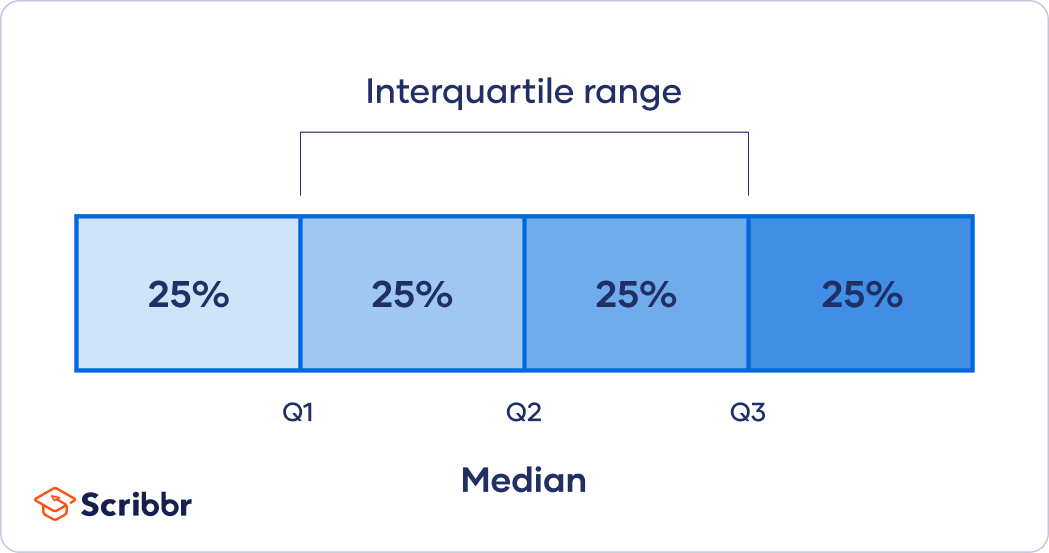
This is where the interquartile range offers a more robust perspective. The IQR is a measure of statistical dispersion, specifically depicting the spread of the middle 50% of the data. To comprehend the IQR, one must first understand quartiles. Imagine sorting all the data points in a set from the smallest to the largest.
- Q1 (First Quartile / Lower Quartile): This is the median of the lower half of the data set. It represents the 25th percentile, meaning 25% of the data falls below this value.
- Q2 (Second Quartile / Median): This is the true median of the entire data set, dividing it into two equal halves. It represents the 50th percentile.
- Q3 (Third Quartile / Upper Quartile): This is the median of the upper half of the data set. It represents the 75th percentile, meaning 75% of the data falls below this value (and 25% falls above it).
The interquartile range is simply the difference between the third quartile (Q3) and the first quartile (Q1):
IQR = Q3 – Q1
This single value effectively quantifies the spread of the central portion of the data, providing an insightful measure of variability that is notably less sensitive to outliers compared to the full range or even the standard deviation. For drone data analysts, this robustness is critical when dealing with potentially noisy sensor readings or transient anomalies that might otherwise skew interpretations.
Calculating the Interquartile Range: A Step-by-Step Guide
The calculation of the interquartile range is a straightforward process, yet its accuracy depends on a methodical approach. Understanding these steps is crucial for anyone working with data sets, particularly those derived from complex drone operations.
Ordering the Data
The very first and most critical step is to arrange all the data points in ascending order, from the smallest value to the largest. This sequential arrangement forms the foundation for accurately identifying the median and quartiles. Without a sorted data set, any subsequent calculations will be flawed and meaningless.
Identifying the Median (Q2)
Once the data is ordered, the next step is to find the overall median (Q2).
- If the data set contains an odd number of observations, the median is the middle value.
- If the data set contains an even number of observations, the median is the average of the two middle values.
The median effectively divides the data set into two halves: a lower half and an upper half. It’s important to note whether the median itself is included in either half when determining Q1 and Q3. Standard practice typically excludes the median from the halves if the data set has an odd number of observations.
Determining Q1 and Q3
With the data divided, Q1 is found by calculating the median of the lower half of the data set. Similarly, Q3 is found by calculating the median of the upper half of the data set. The same rules for finding the median (for odd/even number of points) apply to these halves.
The Final Calculation
Finally, subtract the value of the first quartile (Q1) from the value of the third quartile (Q3). The result is the interquartile range (IQR).
Example:
Consider a drone’s flight efficiency data in terms of energy consumption (Joules/meter) for 10 missions:
[4.2, 3.8, 5.1, 4.0, 3.9, 4.5, 4.3, 3.7, 5.0, 4.1]
- Order the data: [3.7, 3.8, 3.9, 4.0, 4.1, 4.2, 4.3, 4.5, 5.0, 5.1]
- Identify Q2 (Median): Since there are 10 points (even), Q2 is the average of the 5th and 6th values: (4.1 + 4.2) / 2 = 4.15
- Determine Q1: The lower half is [3.7, 3.8, 3.9, 4.0, 4.1]. Q1 is the median of this half, which is the 3rd value: 3.9
- Determine Q3: The upper half is [4.2, 4.3, 4.5, 5.0, 5.1]. Q3 is the median of this half, which is the 3rd value: 4.5
- Calculate IQR: IQR = Q3 – Q1 = 4.5 – 3.9 = 0.6
An IQR of 0.6 tells us that the middle 50% of the drone’s energy consumption data varies by 0.6 Joules/meter, providing a concise measure of the typical spread in its operational efficiency.
The Interquartile Range in Tech & Innovation: Drone Applications
The utility of the interquartile range extends deeply into the operational and analytical challenges faced in drone-related tech and innovation. Its ability to provide a robust measure of data spread and identify outliers makes it invaluable across various applications, from ensuring data quality to optimizing autonomous decision-making.
Enhancing Data Quality in Remote Sensing & Mapping
Drones equipped with advanced sensors for remote sensing and mapping—such as LiDAR, multispectral, hyperspectral, and thermal cameras—collect an enormous volume of geospatial data. This data forms the bedrock of highly accurate 3D models, vegetation health maps, and environmental monitoring reports. However, sensor noise, atmospheric interference, environmental variability, or transient hardware glitches can introduce spurious readings or outliers into these critical datasets.
The IQR is an indispensable tool for data quality control. For instance, in a LiDAR point cloud representing terrain elevation, the IQR can be calculated for elevation values within specific localized areas. An unusually large IQR could indicate significant noise or errors in data acquisition, or possibly reflect genuine, but extreme, topographical features that warrant further investigation. Similarly, when analyzing Normalized Difference Vegetation Index (NDVI) values from agricultural drones, a specific range of healthy vegetation might exhibit a tight IQR. Values falling far outside this range (often defined as Q1 – 1.5IQR or Q3 + 1.5IQR) could be flagged as potential outliers due to sensor calibration issues, shadows, or diseased plant patches requiring agronomist review. By identifying and, if appropriate, excluding or correcting these outliers, the overall accuracy and reliability of the derived maps and models are significantly enhanced, leading to more precise decision-making in precision agriculture, construction, and environmental management.
Optimizing Autonomous Flight and AI Systems
Autonomous drones and AI-powered flight modes rely heavily on real-time sensor data for navigation, obstacle avoidance, and dynamic decision-making. Inertial Measurement Units (IMUs), GPS receivers, ultrasonic sensors, and vision systems continuously feed data streams crucial for maintaining stable flight and executing complex maneuvers. The consistency and reliability of this sensor data are paramount for safe and effective autonomous operation.
The IQR can play a critical role in monitoring the health and performance of these sensor inputs. For example, by calculating the IQR of GPS positional accuracy over a short time window, an autonomous drone can detect if its current positional uncertainty is unusually high, potentially triggering a switch to an alternative navigation method or a safe loiter/land protocol. Similarly, in a drone equipped with AI Follow Mode, the system tracks the subject’s movement. By analyzing the IQR of the subject’s speed or direction changes, the AI can develop a robust understanding of typical movement patterns. Sudden, extreme deviations that fall outside the IQR-defined normal bounds could be flagged as an anomaly, prompting the AI to adjust its predictive models more aggressively or issue a warning, preventing potential loss of tracking or collision. Applying IQR to telemetry data such as motor RPMs, battery cell voltages, or IMU drift rates can also help identify incipient hardware failures before they lead to critical incidents, bolstering the safety and reliability of autonomous systems.
Performance Analysis and System Diagnostics
Beyond real-time applications, the IQR is a powerful metric for post-flight performance analysis and long-term system diagnostics for drone fleets. Analyzing historical data helps uncover trends, optimize operational parameters, and schedule predictive maintenance.
Consider a fleet of delivery drones. Analyzing the IQR of battery discharge rates across hundreds of missions can reveal valuable insights. A tightly clustered IQR would indicate consistent battery performance, while a widening IQR or specific outliers could point to individual batteries degrading faster than expected, prompting proactive replacement. Similarly, evaluating the IQR of flight stability metrics (e.g., pitch/roll deviation from target) for different drone models or under varying environmental conditions can help identify which designs perform best in specific scenarios, informing future procurement or design iterations. In remote sensing, comparing the IQR of ground sample distance (GSD) measurements from different cameras or flight altitudes can ensure image quality consistency across projects. The IQR provides a robust measure to track the “normal” operating window of critical drone components and system behaviors, facilitating early detection of performance degradation and ensuring optimal fleet readiness.
Beyond the Basics: IQR’s Role in Robust Data Analysis
The value of the interquartile range extends beyond mere calculation; it forms the basis for more sophisticated data analysis techniques, particularly where data integrity and clarity are paramount, as is often the case with drone-generated data.
Robustness to Outliers
One of the most compelling advantages of the IQR is its inherent robustness to outliers. Unlike the standard deviation, which calculates spread based on the mean and is therefore highly sensitive to extreme values, the IQR focuses solely on the spread of the middle 50% of the data. This means that a few exceptionally high or low readings from a malfunctioning sensor, a sudden gust of wind affecting a single data point, or a transient communication error will have little to no impact on the calculated IQR. This makes IQR an ideal measure for characterizing the typical variability in noisy drone data streams without being unduly skewed by anomalies that might not represent the underlying system behavior. For critical applications in autonomous flight or precision mapping, this resilience helps prevent false alarms or misinterpretations of data trends.
Visualizing Data Spread: Box Plots
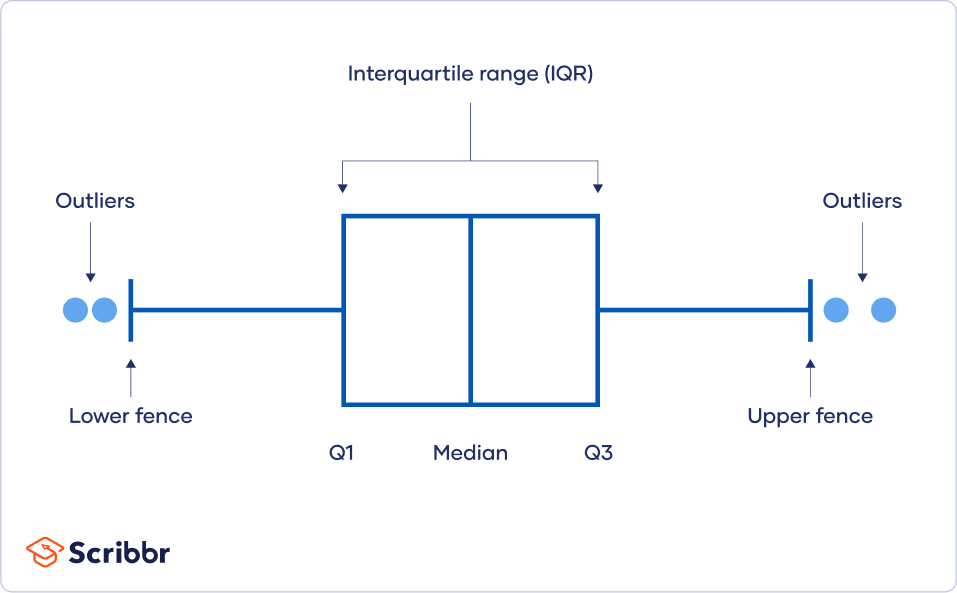
The quartiles (Q1, Q2, Q3) and the IQR are the fundamental components of a box plot, also known as a box-and-whisker plot. This graphical representation is an extremely effective way to visualize the distribution of a data set, especially when comparing multiple distributions. A box plot visually displays:
- The median (a line inside the box).
- The IQR (the length of the box itself, from Q1 to Q3).
- The overall range of the data (whiskers extending from the box).
- Potential outliers (individual points beyond the whiskers, typically calculated as values outside Q1 – 1.5IQR or Q3 + 1.5IQR).
For drone data analysts, box plots generated from telemetry data, sensor readings, or performance metrics offer an immediate, insightful summary of data distribution. For example, comparing box plots of battery temperature data from different drone models operating in diverse climates can quickly reveal which model maintains a more consistent and safe operating temperature range, and whether certain models are prone to overheating (indicated by higher medians and more outliers). This visual power allows for rapid comparative analysis and identification of performance discrepancies at a glance.

Comparative Analysis
The IQR facilitates powerful comparative analysis across different drone systems, sensor types, mission profiles, or environmental conditions. By comparing the IQR of specific performance metrics, developers and operators can gain objective insights into variability and consistency. For instance, in evaluating the altitude hold capabilities of two different drone navigation systems, one might collect barometer data from identical flight paths. A system exhibiting a smaller IQR for altitude deviations would be deemed more consistent and precise in its altitude control. Similarly, comparing the IQR of data latency for communication links between various ground control stations and drone models can highlight which configurations offer the most stable data transmission—a crucial factor for FPV piloting or remote control of critical operations. This comparative power of IQR enables data-driven decisions in hardware selection, software development, and operational planning within the demanding world of drone technology.