
The Foundation of Drone Communication: An Overview
Modern drone technology, a vibrant frontier of innovation, relies heavily on sophisticated communication systems to execute its diverse range of tasks. From precision aerial mapping and autonomous inspection to high-speed FPV racing and critical remote sensing operations, drones constantly exchange vast amounts of data with ground stations, other drones, and cloud-based processing centers. This data encompasses everything from real-time flight telemetry, sensor readings, and high-definition video feeds to complex control commands, firmware updates, and mission-critical navigational instructions.
At the heart of this intricate digital dialogue lie fundamental networking protocols, specifically the Transmission Control Protocol (TCP) and the User Datagram Protocol (UDP). While both serve the overarching purpose of data transmission over an Internet Protocol (IP) network, they achieve this through fundamentally different methodologies, each offering distinct advantages and disadvantages critical to specific drone applications. Understanding these differences is not merely an academic exercise; it is crucial for architects of drone systems to design robust, responsive, and reliable platforms that push the boundaries of aerial robotics and intelligent automation. The choice between TCP and UDP, or often, the strategic combination of both, directly impacts a drone’s operational capabilities, its responsiveness to commands, the integrity of its collected data, and its overall performance in an increasingly connected aerial ecosystem.
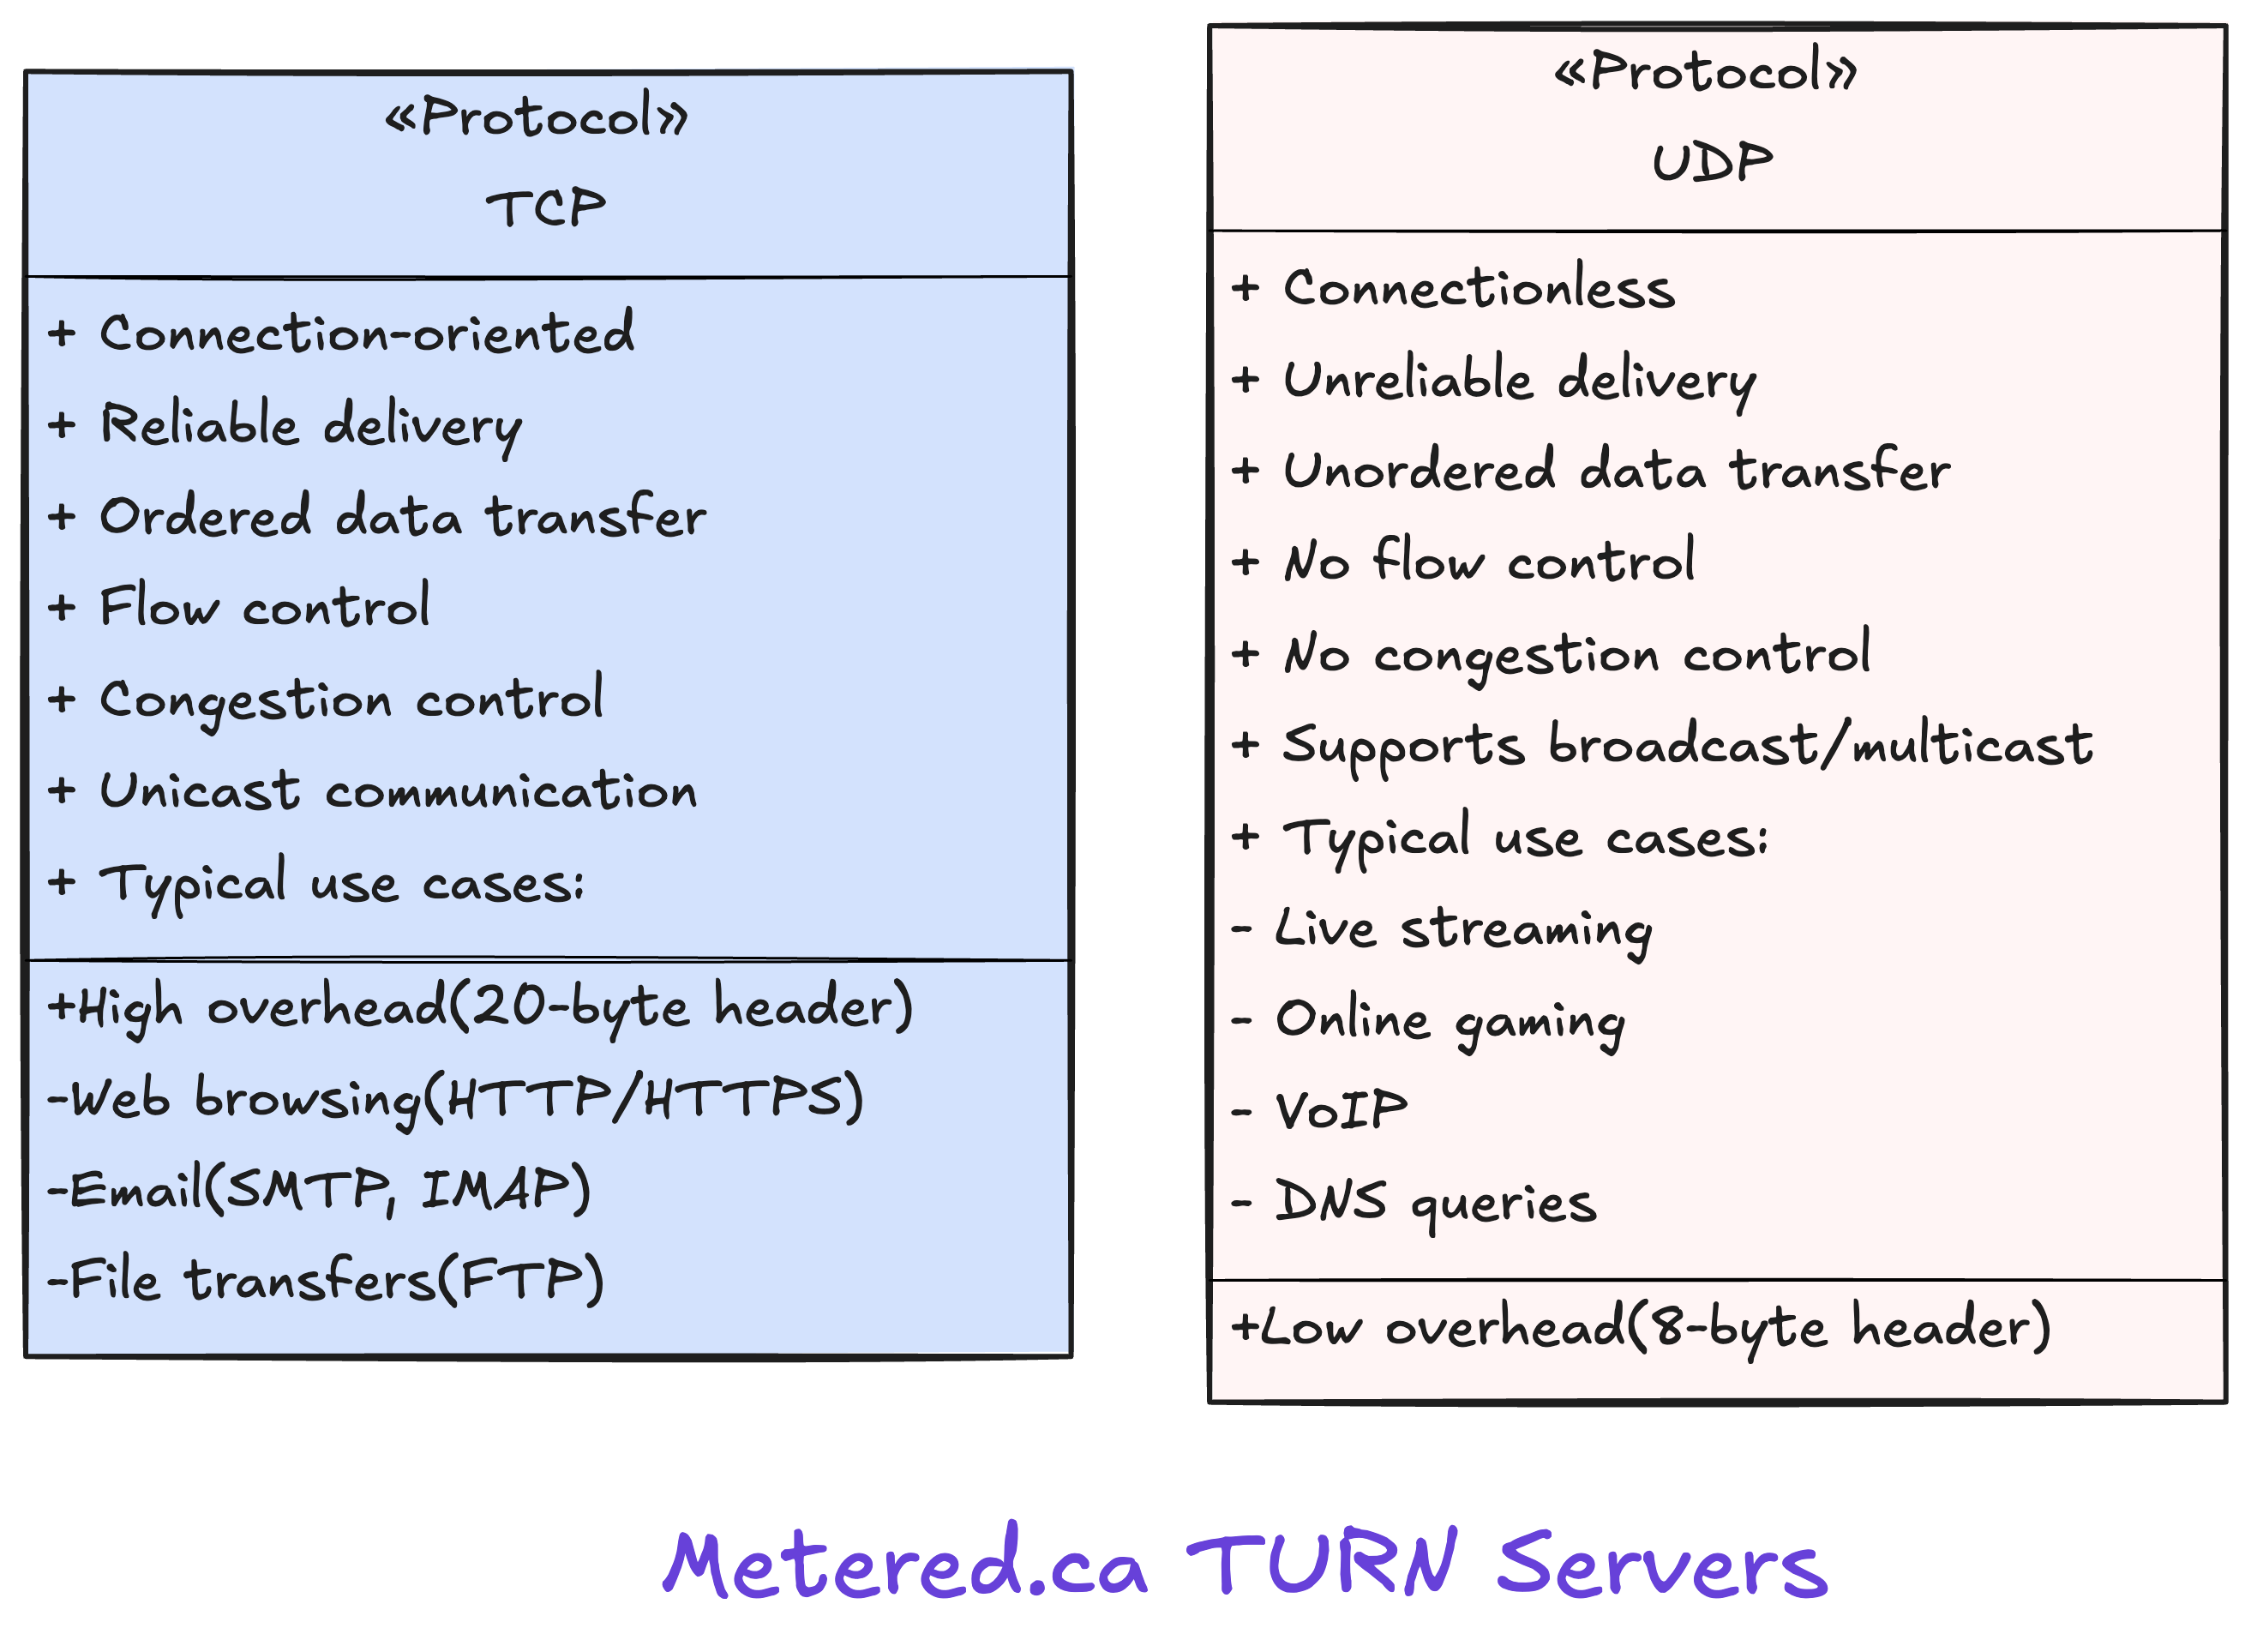
TCP: Reliability for Critical Drone Operations
The Transmission Control Protocol (TCP) stands as a cornerstone of reliable data communication, offering a robust, connection-oriented service designed to ensure that data packets arrive at their destination completely, in order, and without error. Its meticulous approach makes it indispensable for drone applications where data integrity and guaranteed delivery are paramount, often overriding concerns about minimal latency.
Guaranteed Delivery and Order
The hallmark of TCP is its commitment to reliability, achieved through a sophisticated mechanism of acknowledgments and retransmissions. When a connection is established between a drone and its ground control station using TCP, a “three-way handshake” initiates the session, confirming that both ends are ready to communicate. Once data transmission begins, TCP segments the data into packets and assigns a sequence number to each. As the receiver (e.g., the ground station) receives a packet, it sends back an acknowledgment (ACK) for that specific sequence number. If an ACK is not received within a predetermined timeout period, TCP assumes the packet was lost or corrupted and automatically retransmits it. This constant back-and-forth ensures that every piece of data sent eventually reaches its intended recipient.
For drone systems, this guaranteed delivery is critical in numerous scenarios. Consider the transmission of vital firmware updates to a drone. Any corruption or loss of data during this process could render the drone inoperable or introduce severe safety risks. Similarly, uploading high-accuracy photogrammetry data for 3D mapping after a flight requires absolute data integrity; even a single missing or corrupted pixel can compromise the entire model’s precision. Mission-critical commands, such as an emergency return-to-home instruction or the activation of a parachute system, demand the certainty of TCP to ensure they are received and acted upon without fail. While the overhead of ACKs and retransmissions can introduce latency, the integrity of these specific data types far outweighs the need for instantaneous delivery. TCP also guarantees that data segments are reassembled in the correct order, which is vital for large data transfers where out-of-order arrival could lead to significant processing errors at the application layer.
Flow and Congestion Control
Beyond guaranteed delivery, TCP incorporates sophisticated mechanisms for flow control and congestion control, further enhancing its reliability and stability, particularly in dynamic drone operating environments. Flow control prevents a fast sender from overwhelming a slow receiver, ensuring that the drone or ground station can process incoming data at its own pace. This is crucial when, for instance, a powerful ground station is sending detailed mission plans to a drone with more limited processing capabilities. TCP dynamically adjusts the transmission rate based on the receiver’s capacity, using a “windowing” mechanism to manage the amount of unacknowledged data outstanding.
Congestion control, on the other hand, aims to prevent network overload, especially vital when drones operate in environments with varying signal strengths or shared network resources. TCP intelligently detects signs of network congestion, such as increased round-trip times or packet loss, and responds by temporarily reducing its transmission rate. This cooperative behavior helps to maintain overall network stability and prevents the drone’s communication channel from collapsing under strain. For autonomous drones operating over long distances or in complex urban environments, where wireless link quality can fluctuate significantly, TCP’s adaptive nature ensures a more stable and resilient communication link for critical data, even if it means occasional temporary reductions in throughput. This stability is paramount for maintaining persistent connections for complex AI-driven tasks or data-intensive remote sensing missions.
UDP: Speed and Efficiency for Real-time Drone Applications
In stark contrast to TCP’s emphasis on reliability, the User Datagram Protocol (UDP) prioritizes speed and efficiency. It is a connectionless protocol that operates with minimal overhead, making it the preferred choice for drone applications where real-time performance and low latency are paramount, even at the cost of potential packet loss.
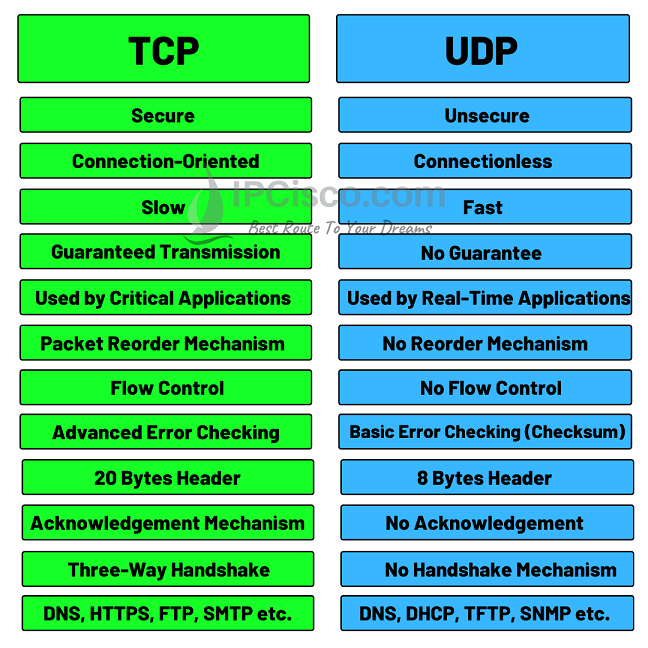
Connectionless and Lightweight
UDP is often described as a “fire and forget” protocol. Unlike TCP, it does not establish a persistent connection with a three-way handshake before transmitting data, nor does it require acknowledgments for received packets. When a drone sends data via UDP, it simply packages the information into datagrams and sends them to the destination without any guarantee of delivery, order, or duplication prevention. This connectionless nature eliminates the overhead associated with setting up and tearing down connections, managing sequence numbers, and processing acknowledgments.
The immediate benefit of this minimalist approach is significantly reduced latency and higher throughput. For many real-time drone applications, even a few milliseconds of delay can be critical. Consider FPV (First Person View) video streaming: drone pilots rely on an instantaneous video feed to maneuver their aircraft effectively, especially in racing or complex freestyle flying. A slight delay in the video can lead to crashes or missed maneuvers. UDP is ideal here because the continuous stream of video frames can tolerate occasional lost packets (resulting in a minor visual glitch) far better than a cumulative delay caused by retransmitting every single lost frame. Similarly, real-time joystick commands, crucial for responsive drone control, are often sent via UDP. If an occasional command packet is lost, the next command arrives almost immediately, often making the loss imperceptible to the pilot. The immediate response of the drone is prioritized over the absolute certainty of every single command’s arrival.
Tolerance for Packet Loss
The inherent characteristic of UDP is its tolerance for packet loss. While TCP’s retransmission mechanisms would halt a stream until a lost packet is recovered, UDP simply moves on. This might seem like a disadvantage, but for many streaming and real-time interactive applications in drone tech, it is a crucial advantage. In scenarios like live telemetry updates, such as battery voltage, altitude, or GPS coordinates, these are typically small, frequent data bursts. If one or two telemetry packets are lost, the subsequent packets quickly provide updated information, rendering the brief lapse in data insignificant. The application can interpolate or simply discard the missing information, prioritizing the freshness of the data.
This tolerance for loss is especially beneficial in environments where network conditions are unstable or bandwidth is limited, which is common in many drone operating scenarios (e.g., flying behind obstacles, operating at the edge of control range). TCP in such conditions would aggressively retransmit, potentially worsening congestion and dramatically increasing latency. UDP, by simply pushing new data, allows the application layer to manage the consequences of loss, often designing the application to gracefully handle minor imperfections. This principle extends to various drone-based IoT (Internet of Things) applications, where numerous sensors might be sending small, continuous updates, and the collective stream of data is more important than the absolute guarantee of each individual data point. The lean nature of UDP also translates to less bandwidth consumption, as it avoids the substantial header and payload overhead of TCP, making it efficient for transmitting small, frequent bursts of data from multiple drone sensors.
Strategic Protocol Selection in Drone Systems
The choice between TCP and UDP is rarely a one-size-fits-all decision in the sophisticated world of drone technology. Instead, designers and engineers strategically select the most appropriate protocol based on the specific requirements of each data stream, often employing hybrid approaches to leverage the strengths of both.
Hybrid Approaches and Application Layer Decisions
Sophisticated drone systems frequently employ a judicious mix of TCP and UDP. For instance, a single drone might use UDP for its primary FPV video feed and joystick controls to ensure minimal latency, while simultaneously maintaining a TCP connection for critical telemetry data logging, software updates, or pre-flight mission plan uploads. This hybrid approach ensures that real-time responsiveness is preserved where it matters most, without compromising the integrity of crucial data.
Moreover, developers often build custom protocols and application-layer solutions on top of UDP to achieve a balance between speed and reliability. For critical control commands sent over UDP, an application might implement its own lightweight acknowledgment and retransmission scheme. This means the application itself checks for the arrival of vital commands and resends them if necessary, but only for those specific, high-priority messages, thus avoiding the general overhead of TCP for the entire data stream. For example, a command to initiate an emergency landing might be sent via UDP for speed but with an application-level acknowledgment to confirm receipt, ensuring swift execution while verifying success. This allows for fine-grained control over reliability and latency trade-offs, tailoring the communication to the exact needs of the drone’s operational profile. The decision tree for protocol selection involves evaluating factors such as data criticality, acceptable latency, required throughput, network conditions, and the processing power available on the drone and ground station.
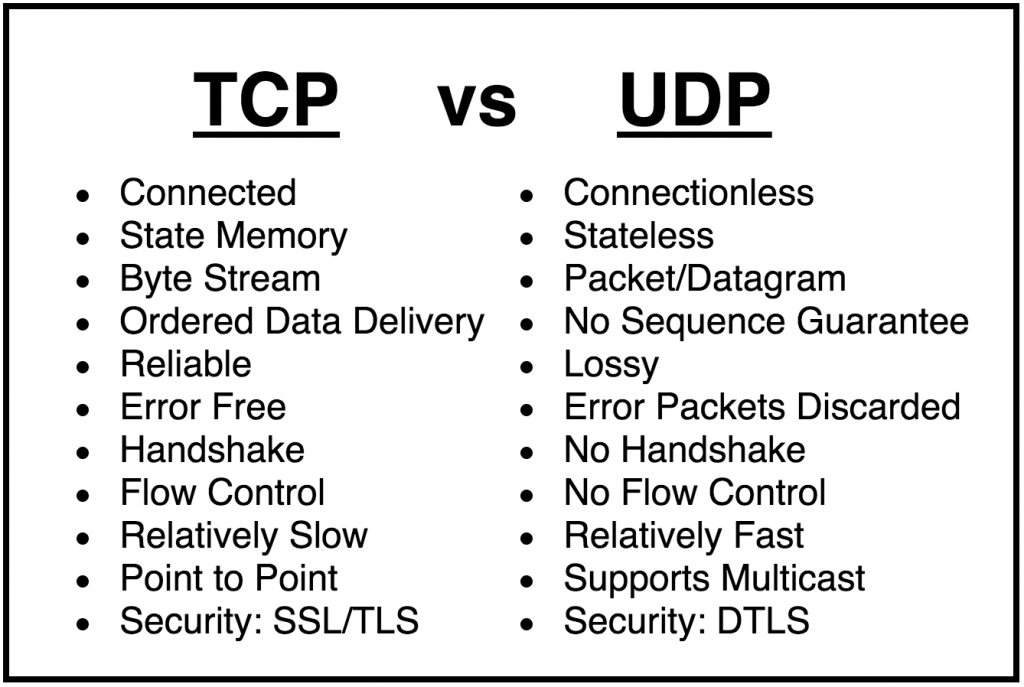
Impact on Innovation and Performance
The intelligent selection and implementation of TCP and UDP have a profound impact on the trajectory of drone innovation and performance. UDP’s low-latency characteristics are fundamental to the advancements in high-speed drone racing, where millisecond delays can determine victory or defeat, and in precise industrial inspection drones requiring immediate feedback for navigation in complex environments. Without UDP, the fluid, real-time control necessary for these applications would be severely hampered, limiting operational agility and the development of advanced piloting skills.
Conversely, TCP’s reliability underpins the integrity of data for cutting-edge drone applications in remote sensing, mapping, and autonomous flight. Ensuring that every byte of a LIDAR scan, multispectral image, or AI training dataset is transmitted perfectly allows for accurate environmental monitoring, precise agricultural analysis, and robust decision-making by onboard artificial intelligence. For AI-driven autonomous flight modes, where the drone is making real-time decisions based on complex sensor fusion, reliable data transfer for critical updates and mission parameters is non-negotiable. Furthermore, as drones integrate with 5G networks and edge computing paradigms, the judicious use of both protocols will become even more critical. 5G’s ultra-low latency capabilities can be maximally leveraged by UDP for real-time control and high-bandwidth streaming, while its enhanced reliability for critical data paths will benefit from TCP. This strategic protocol differentiation enables drones to perform increasingly complex tasks, communicate seamlessly within vast networks, and contribute to fields from logistics and surveillance to environmental protection, continually pushing the boundaries of what aerial technology can achieve.