
Modern flight technology, particularly in the realm of drones and Unmanned Aerial Vehicles (UAVs), hinges on sophisticated control mechanisms that govern everything from basic stability to complex autonomous navigation. While the term “circulatory systems” might initially evoke biological processes, in the context of engineering and automation, it can be conceptually understood as the flow and processing of information within a system to achieve a desired outcome. This information flow, especially regarding feedback, defines the fundamental distinction between open-loop and closed-loop control systems—a distinction critical to the precision, reliability, and advancement of aerial platforms.

Understanding Control Systems: The Core of Flight Dynamics
At its heart, any control system aims to manage, command, direct, or regulate the behavior of other devices or systems. In drone technology, these systems are the brains behind the brawn, translating pilot inputs or autonomous mission plans into physical actions by the drone’s actuators (motors, servos). Without effective control systems, a drone would be an unstable, unflyable machine, unable to defy gravity safely or execute precise maneuvers.
The primary function of a flight control system is to maintain the drone’s stability, manage its altitude, control its speed, and navigate its path. This involves a continuous interplay of inputs, processing, and outputs. Inputs can range from a pilot’s joystick commands to data from an array of sensors like accelerometers, gyroscopes, magnetometers, GPS receivers, barometers, and even optical flow sensors. The control system processes this information, often through complex algorithms running on a flight controller board, to generate outputs that adjust the drone’s motor speeds or control surface deflections.
The intelligence and complexity of these systems determine a drone’s capabilities. Simple control systems might only allow basic manual flight, while advanced ones enable fully autonomous missions, obstacle avoidance, and dynamic environmental adaptation. The foundational principle differentiating their operational models, and consequently their capabilities, lies in how they handle feedback—or the lack thereof—from the system’s output.
Open-Loop Systems: Simplicity, Limitations, and Niche Applications
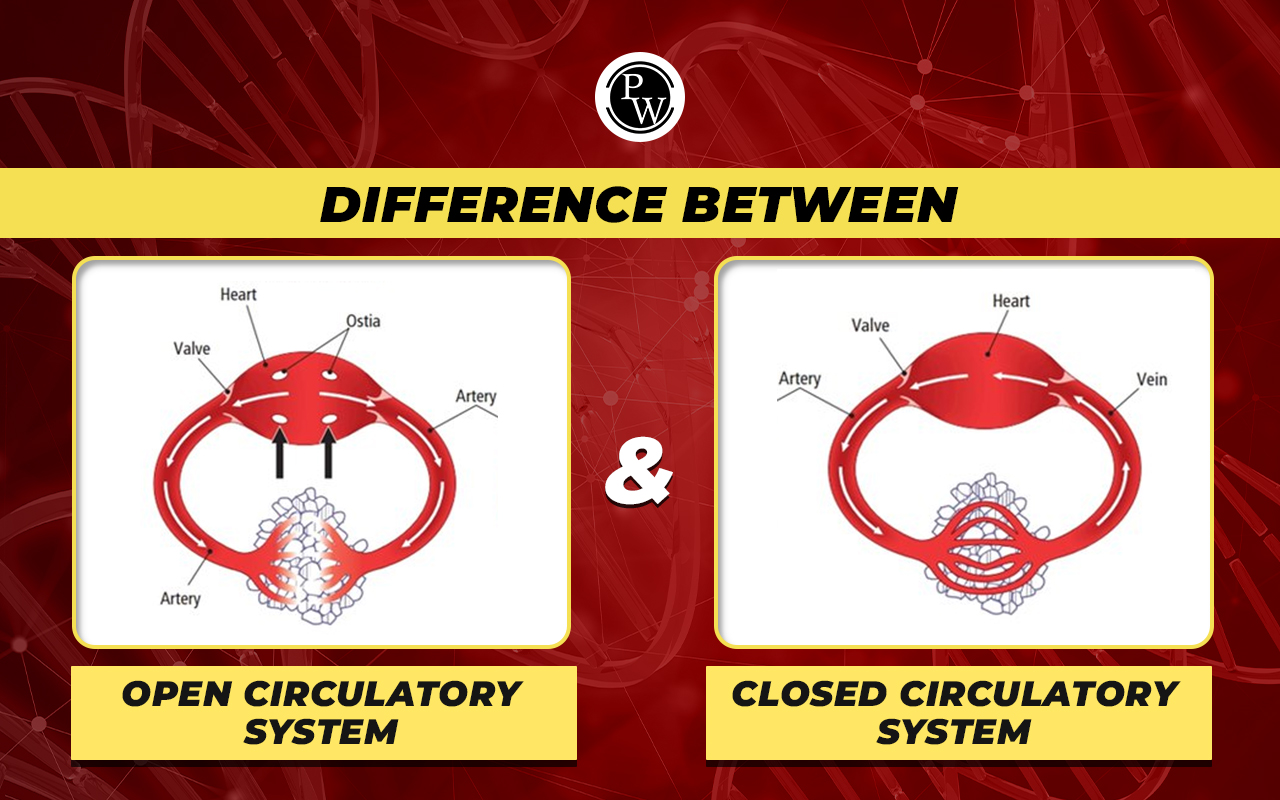
An open-loop control system is characterized by the absence of a feedback loop between the output and the control action. In such a system, the control action is entirely independent of the output. The system acts based on pre-programmed instructions or direct manual inputs, without any mechanism to measure the actual outcome and adjust its behavior accordingly.
Imagine a simple scenario: you press a button to activate a drone’s motors at a specific power level for a fixed duration, expecting it to ascend to a certain height. In an open-loop setup, the system would simply execute that command regardless of whether the drone actually reached the intended height. It wouldn’t know if a sudden gust of wind pushed it sideways, if a dying battery prevented it from generating enough thrust, or if a payload change affected its lift. The control action is fixed, and there’s no “information circulation” from the output back to the input to correct deviations.
Examples in Flight Technology (or analogous simpler systems):
- Basic Timer-Based Operations: Early, rudimentary drone functions might have used open-loop principles, such as a timer to activate a camera shutter without verifying if the drone was in the correct position or if the subject was in frame.
- Pre-programmed Trajectories (without correction): In some very niche, controlled environments, a drone might follow a pre-calculated path by simply applying specific motor commands over time, assuming perfect conditions. Any deviation due to external factors would go uncorrected.
- Simple Actuator Control: A basic remote-controlled toy helicopter might have largely open-loop control for its main rotor speed, relying purely on the pilot’s manual adjustments rather than automated feedback loops for stability.
Advantages of Open-Loop Systems:
- Simplicity: They are generally easier and less expensive to design and implement due to fewer components and less complex algorithms.
- Stability: If the system is well-calibrated for predictable conditions, it can be stable, as there are no feedback loops that could potentially introduce oscillations or instability if improperly tuned.
Disadvantages of Open-Loop Systems:
- Lack of Accuracy and Robustness: They are highly susceptible to external disturbances (wind, temperature changes, battery voltage fluctuations) and internal variations (motor wear, payload changes). They cannot compensate for unexpected events.
- No Error Correction: Errors or deviations from the desired output cannot be detected or corrected automatically.
- Limited Adaptability: They are not suitable for dynamic environments or tasks requiring high precision and flexibility.
- Require Calibration: Often need frequent re-calibration if operating conditions change.
For the demanding and inherently unstable nature of flight, purely open-loop systems are largely insufficient for modern drones beyond the most trivial tasks.
Closed-Loop Systems: Precision, Adaptability, and Modern Autonomy
In stark contrast, a closed-loop control system, also known as a feedback control system, incorporates a feedback mechanism. This means the system continuously monitors its output, compares it to the desired input (the setpoint), and uses the resulting error signal to adjust its control action. Information “circulates” from the output back to the input, creating a continuous loop of sensing, comparing, and correcting.
This feedback loop is what gives modern drones their remarkable stability, agility, and autonomous capabilities. The system doesn’t just issue a command; it verifies that the command had the intended effect and adjusts if it didn’t.
Key Components of a Closed-Loop System:
- Input (Setpoint): The desired value or target (e.g., desired altitude, target GPS coordinates, desired attitude angle).
- Controller: The “brain” (e.g., the drone’s flight controller unit) that calculates the necessary control action based on the error.
- Process (Plant): The system being controlled (e.g., the drone’s motors and airframe).
- Output: The actual measured state of the process (e.g., current altitude, actual GPS coordinates, current attitude).
- Sensor: Measures the output and provides feedback (e.g., barometer, GPS receiver, IMU).
- Feedback Path: The channel through which the sensor data is sent back to the input.
- Comparator: Compares the input (setpoint) with the feedback (measured output) to generate an error signal.
- Error Signal: The difference between the desired and actual output, which drives the controller’s adjustments.
Examples in Drone Flight Technology:
- Flight Stabilization Systems: This is perhaps the most fundamental application. Inertial Measurement Units (IMUs) containing gyroscopes and accelerometers continuously sense the drone’s orientation and angular velocity (output). This feedback is sent to the flight controller (controller), which compares it to the desired stable orientation (input). Any deviation (error) triggers immediate adjustments to the motor speeds (actuator) to bring the drone back to level flight.
- Altitude Hold: A barometer or sonar sensor measures the drone’s current altitude (output). This is fed back to the flight controller, which adjusts throttle commands to the motors to maintain a set altitude (input), compensating for drafts or air density changes.
- GPS Position Hold (Loiter Mode): The GPS receiver provides continuous feedback on the drone’s current position (output). The flight controller compares this to a desired fixed GPS coordinate (input) and makes precise, minute adjustments to motor thrust vectors to keep the drone stationary relative to the ground, even in windy conditions.
- Obstacle Avoidance: Proximity sensors (LiDAR, ultrasonic, vision sensors) detect obstacles (output). The flight controller processes this feedback, compares it to a safe distance (input), and automatically alters the flight path (control action) to avoid collisions.
- Gimbal Stabilization: Gyroscopes on a camera gimbal provide feedback on the camera’s orientation (output). Motors on the gimbal then actively counteract any drone movement to keep the camera perfectly steady and level, ensuring smooth footage.
Advantages of Closed-Loop Systems:
- High Accuracy and Precision: They can maintain outputs very close to the desired setpoint, even under varying conditions.
- Robustness and Disturbance Rejection: They can automatically compensate for external disturbances and internal system changes, making them highly reliable.
- Automatic Error Correction: Any deviation from the desired state is detected and corrected without human intervention.
- Adaptability: They can adapt to changing operational parameters, such as different payloads or wind conditions.
- Foundation for Autonomy: Essential for complex autonomous functions like waypoint navigation, follow-me modes, and automatic landings.
Disadvantages of Closed-Loop Systems:
- Complexity: More complex to design, implement, and tune due to the need for sensors, feedback mechanisms, and sophisticated control algorithms (e.g., PID controllers).
- Cost: Higher component count and processing power can increase the overall cost.
- Potential for Instability: If not properly designed and tuned, feedback loops can lead to oscillations, overshoot, or even instability, where the system overcorrects repeatedly.
- Sensor Reliance: Performance is heavily dependent on the accuracy and reliability of the sensors.

Hybrid Architectures and the Future of Flight Control
In practice, most modern drones don’t rely solely on one type of system but employ a hybrid approach. Critical flight control functions like attitude stabilization, altitude hold, and GPS navigation are almost universally closed-loop. However, some ancillary functions or high-level mission directives might leverage open-loop principles. For instance, once a closed-loop navigation system guides a drone to a precise location, an open-loop command might be issued to trigger a payload release or a specific photographic sequence for a predetermined duration, without real-time feedback on the success of that specific action.
The evolution of flight technology is characterized by increasingly sophisticated closed-loop systems. Advances in sensor technology (miniaturized, multi-spectral, higher resolution), faster processors, and more intelligent algorithms (including machine learning and artificial intelligence) are continually enhancing the precision, robustness, and autonomy of drones. Sensor fusion techniques, which combine data from multiple disparate sensors (e.g., GPS, IMU, optical flow, LiDAR) to provide a more accurate and robust understanding of the drone’s state, are a prime example of refining closed-loop feedback.
The distinction between open and closed control systems is fundamental to understanding how aerial platforms operate and evolve. While open-loop systems offer simplicity for basic tasks, it is the sophisticated feedback mechanisms of closed-loop systems that empower the precision, adaptability, and autonomy defining the cutting edge of drone flight technology. This continuous “circulation” of information, from the drone’s environment back into its control brain, is what allows these machines to perform complex missions, adapt to dynamic conditions, and ultimately achieve what once seemed like science fiction.