
In the intricate world of flight technology, particularly concerning unmanned aerial vehicles (UAVs), the concept of “time” extends far beyond mere chronological progression. While an immediate answer to “what is the current Central Standard Time” might seem like a simple query, its implications for drone operations, navigation, data integrity, and regulatory compliance are profoundly complex and critical. For sophisticated flight systems, understanding and utilizing precise temporal data, often referenced against global standards and then localized, is fundamental to every aspect of their design, deployment, and performance. This exploration delves into how time, from universal coordinated time (UTC) to specific local zones like CST, underpins the very fabric of modern flight technology.

The Indispensable Precision of Time in Drone Navigation
Accurate timekeeping is the silent architect behind the reliability and precision of modern flight technology. Without rigorously synchronized time, the sophisticated navigation, stabilization, and data acquisition systems that power contemporary drones would be utterly dysfunctional. Every component, from a GPS receiver to an Inertial Measurement Unit (IMU), operates within a temporal framework that demands unwavering accuracy.
GPS and Global Timekeeping: Beyond Local Zones
At the core of virtually all modern drone navigation is the Global Positioning System (GPS), or its equivalents like GLONASS, Galileo, and BeiDou. These satellite constellations function by transmitting precise time signals. A drone’s GPS receiver calculates its position by measuring the time delay between receiving signals from multiple satellites. This time-of-flight measurement, when triangulated, reveals the receiver’s exact location. The accuracy of this calculation is directly proportional to the accuracy of the time signals and the receiver’s internal clock.
GPS satellites carry highly stable atomic clocks that are synchronized with each other and with Universal Coordinated Time (UTC), the primary time standard by which the world regulates clocks and time. UTC is the reference point for all global navigation systems. Local time zones, such as Central Standard Time (CST), are merely offsets from UTC. For instance, during standard time, CST is UTC-6. This distinction is crucial: while ground crews and mission planners might operate based on CST for convenience and local context, the drone’s internal navigation and flight control systems typically rely on UTC for their core computations to maintain global consistency and prevent errors when transitioning across time zones or interacting with global data sets. The drone’s onboard computer will internally manage the conversion from UTC to local time as needed for human-readable logs or operational displays, ensuring that regardless of the local time zone, its fundamental positioning remains globally precise.
Synchronizing Sensors for Optimal Performance
Beyond GPS, every sensor on a modern drone system generates data that must be precisely time-stamped. An IMU measures angular velocity and linear acceleration; an altimeter provides altitude data; lidar systems map environments; and cameras capture visual information. For these disparate data streams to be fused effectively into a cohesive understanding of the drone’s state and environment, their acquisition times must be perfectly synchronized.
Consider a drone performing autonomous obstacle avoidance. Its onboard computer receives inputs from multiple sensors: a vision camera identifying a potential obstruction, ultrasonic sensors measuring proximity, and an IMU tracking the drone’s instantaneous movement. If these sensor readings are not accurately time-stamped and synchronized, the flight controller might attempt to react to an obstacle that has already been passed, or misinterpret the relative positions of the drone and the obstacle, leading to a collision. Sensor fusion algorithms depend on precise temporal alignment to accurately combine data from different sources, creating a more robust and reliable representation of the drone’s environment than any single sensor could provide. This synchronization is often achieved through high-frequency internal clock signals, ensuring that all data points are correlated to the same precise moment in time, irrespective of external time zone considerations.
Operational Planning and Regulatory Adherence
While a drone’s internal systems operate on universal time standards, human-centric operations, planning, and regulatory compliance are inextricably linked to local time zones. Understanding and applying Central Standard Time, or any relevant local time, is paramount for efficient, safe, and legal drone deployment.
Mission Scheduling Across Geographies
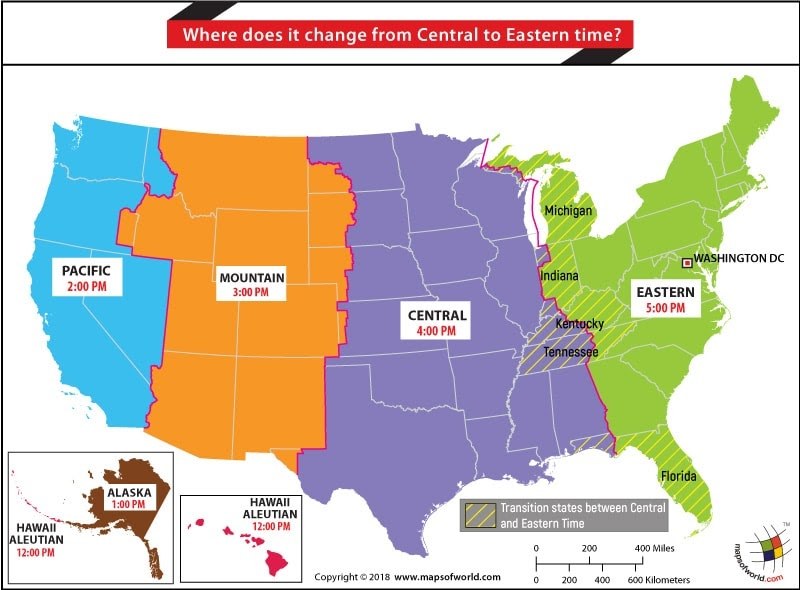
Drone operations, particularly in commercial or industrial applications, frequently involve coordinating flights across vast geographical areas. A company managing a fleet of drones for infrastructure inspection might have teams operating simultaneously in different time zones. A mission planner in Pacific Time (PT) might need to schedule a drone inspection flight in a region observing Central Standard Time (CST). Without a clear understanding of the current CST and its offset from PT or UTC, scheduling conflicts, delays, or missed operational windows are inevitable.

For instance, a flight might be mandated to occur between 9:00 AM and 5:00 PM local time to avoid high human activity or to align with specific environmental conditions (e.g., light levels for photography, wind patterns). If the planner in PT mistakenly schedules a flight for 9:00 AM PT, which corresponds to 11:00 AM CST, they might miss an early morning observation window or clash with other planned activities. Accurate knowledge of local time zones ensures that ground crews, data analysts, and support teams are all synchronized, leading to seamless handovers and coordinated operations. This synchronization extends to battery management and charging schedules, ensuring fresh batteries are available for flights timed to local conditions.
Airspace Management and Time-Sensitive Operations
Airspace regulations often contain specific time-based restrictions designed to ensure safety and mitigate risks. These regulations are almost universally expressed in local time. For example, Temporary Flight Restrictions (TFRs) around special events, agricultural spraying windows, or construction activities might only be active during specific hours of the day. Similarly, some drone operations might be restricted to daylight hours, defined as civil sunrise to civil sunset, which varies significantly by location and time of year within a specific time zone like CST.
Pilots operating in the Central Standard Time zone must be acutely aware of the current CST to accurately determine permissible flight times, assess daylight availability, and comply with any time-bound NOTAMs (Notices to Airmen) or local ordinances. Misinterpreting the local time can lead to violations, potential hazards, and severe penalties. Effective flight technology incorporates features that display local time, calculate sunrise/sunset times, and alert pilots to time-sensitive airspace restrictions, integrating this crucial human-facing temporal data into the operational workflow.
Data Integrity and Autonomous System Reliability
The value of data collected by drones is directly tied to its integrity, which in turn is heavily dependent on accurate time-stamping. For autonomous systems, precise chronological execution of commands is paramount for safety and mission success.
Time-Stamping for Post-Flight Analysis
Every piece of data recorded by a drone – from flight path coordinates and altitude readings to sensor data like photographic images or thermal scans – is associated with a timestamp. This temporal metadata is invaluable for post-flight analysis, incident reconstruction, and regulatory auditing. If a drone encounters an anomaly or an unexpected event, accurate timestamps allow engineers and investigators to correlate various data logs (flight controller logs, motor data, sensor outputs) to pinpoint the exact moment of failure or deviation.
For example, if a drone experiences a sudden loss of altitude, reviewing flight logs with precise UTC timestamps can help reconstruct the sequence of events: did a motor fail at the exact moment the control signal changed, or did an unexpected gust of wind affect the drone? When data is collected over an extended period or across multiple flights, consistent time-stamping (ideally in UTC, then converted to local time like CST for human review) ensures that datasets can be accurately merged, compared, and analyzed for long-term trends or changes. This is critical for applications like environmental monitoring, where comparing imagery of the same location over weeks or months requires exact temporal referencing.
Autonomous Flight Path Execution and Chronological Accuracy
Autonomous flight systems operate on pre-programmed flight plans that include specific waypoints, altitudes, speeds, and actions (e.g., take a photo, activate a payload) tied to either spatial triggers or, critically, temporal triggers. For a drone programmed to perform a series of actions at specific times, the accuracy of its internal clock and its synchronization with a global time standard are non-negotiable.
Consider an autonomous drone tasked with monitoring crop health, programmed to fly a specific grid pattern every day at a certain local time to capture images under consistent lighting conditions. If the drone’s internal clock drifts or is improperly synchronized, it might perform the mission at the wrong time, rendering the collected data incomparable or less valuable. In more complex scenarios, like swarm operations where multiple drones execute coordinated tasks, precise synchronization of their internal clocks is absolutely vital. If drones in a swarm operate on slightly different timebases, their synchronized maneuvers could fall apart, leading to collisions or mission failure. Therefore, ensuring that autonomous drone systems maintain rigorous time accuracy, often through periodic synchronization with GPS signals (which provide UTC), is a cornerstone of their reliability and safety.
Future Innovations: Hyper-Synchronized Aerial Systems
As flight technology continues to evolve, the demands for temporal precision will only increase. Future innovations in areas like urban air mobility, autonomous delivery networks, and complex swarm robotics will necessitate hyper-synchronized aerial systems. This will involve not just accurate internal clocks, but also robust mechanisms for real-time external time synchronization, potentially leveraging emerging technologies like 5G networks for high-precision timing signals that complement or augment GPS. Understanding the current Central Standard Time, or any specific local time zone, will continue to be a crucial interface between these advanced, globally synchronized machines and the human operators, regulations, and environments that govern their deployment. The seemingly simple query about CST thus unlocks a deeper appreciation for the profound role of time in shaping the capabilities and limitations of modern flight technology.