
Unpacking the Concept of Tacit Learning
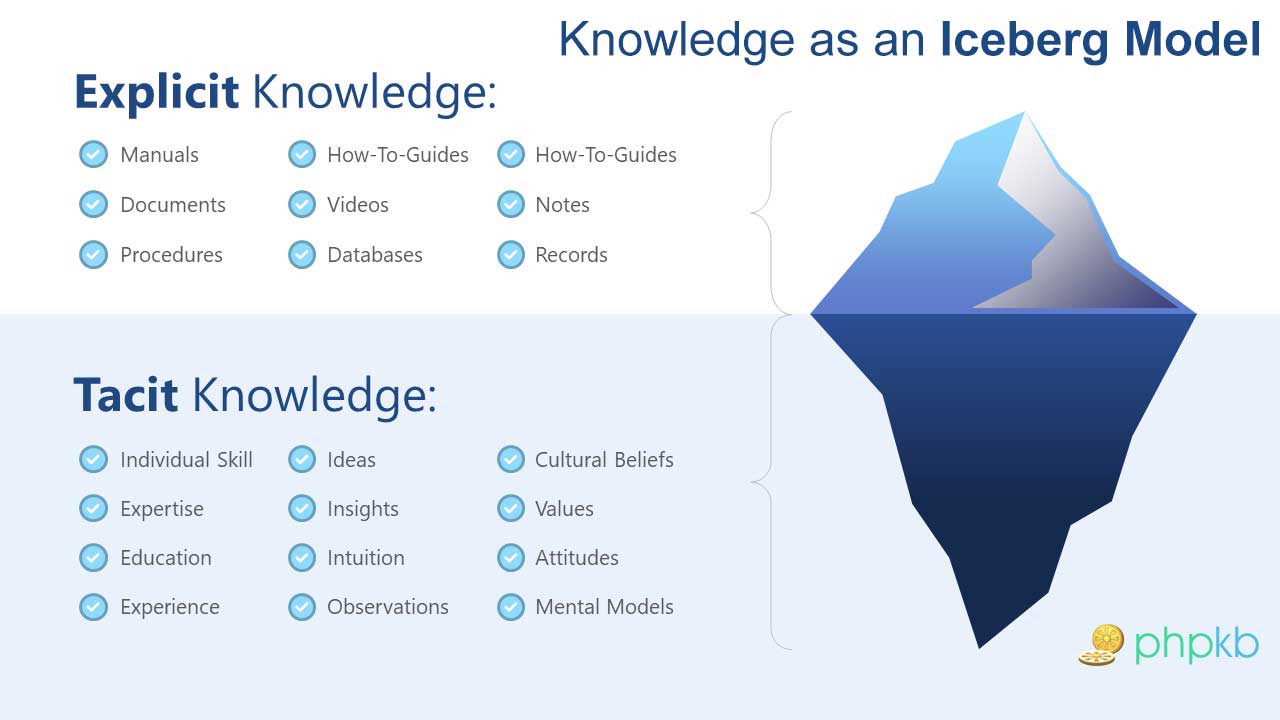
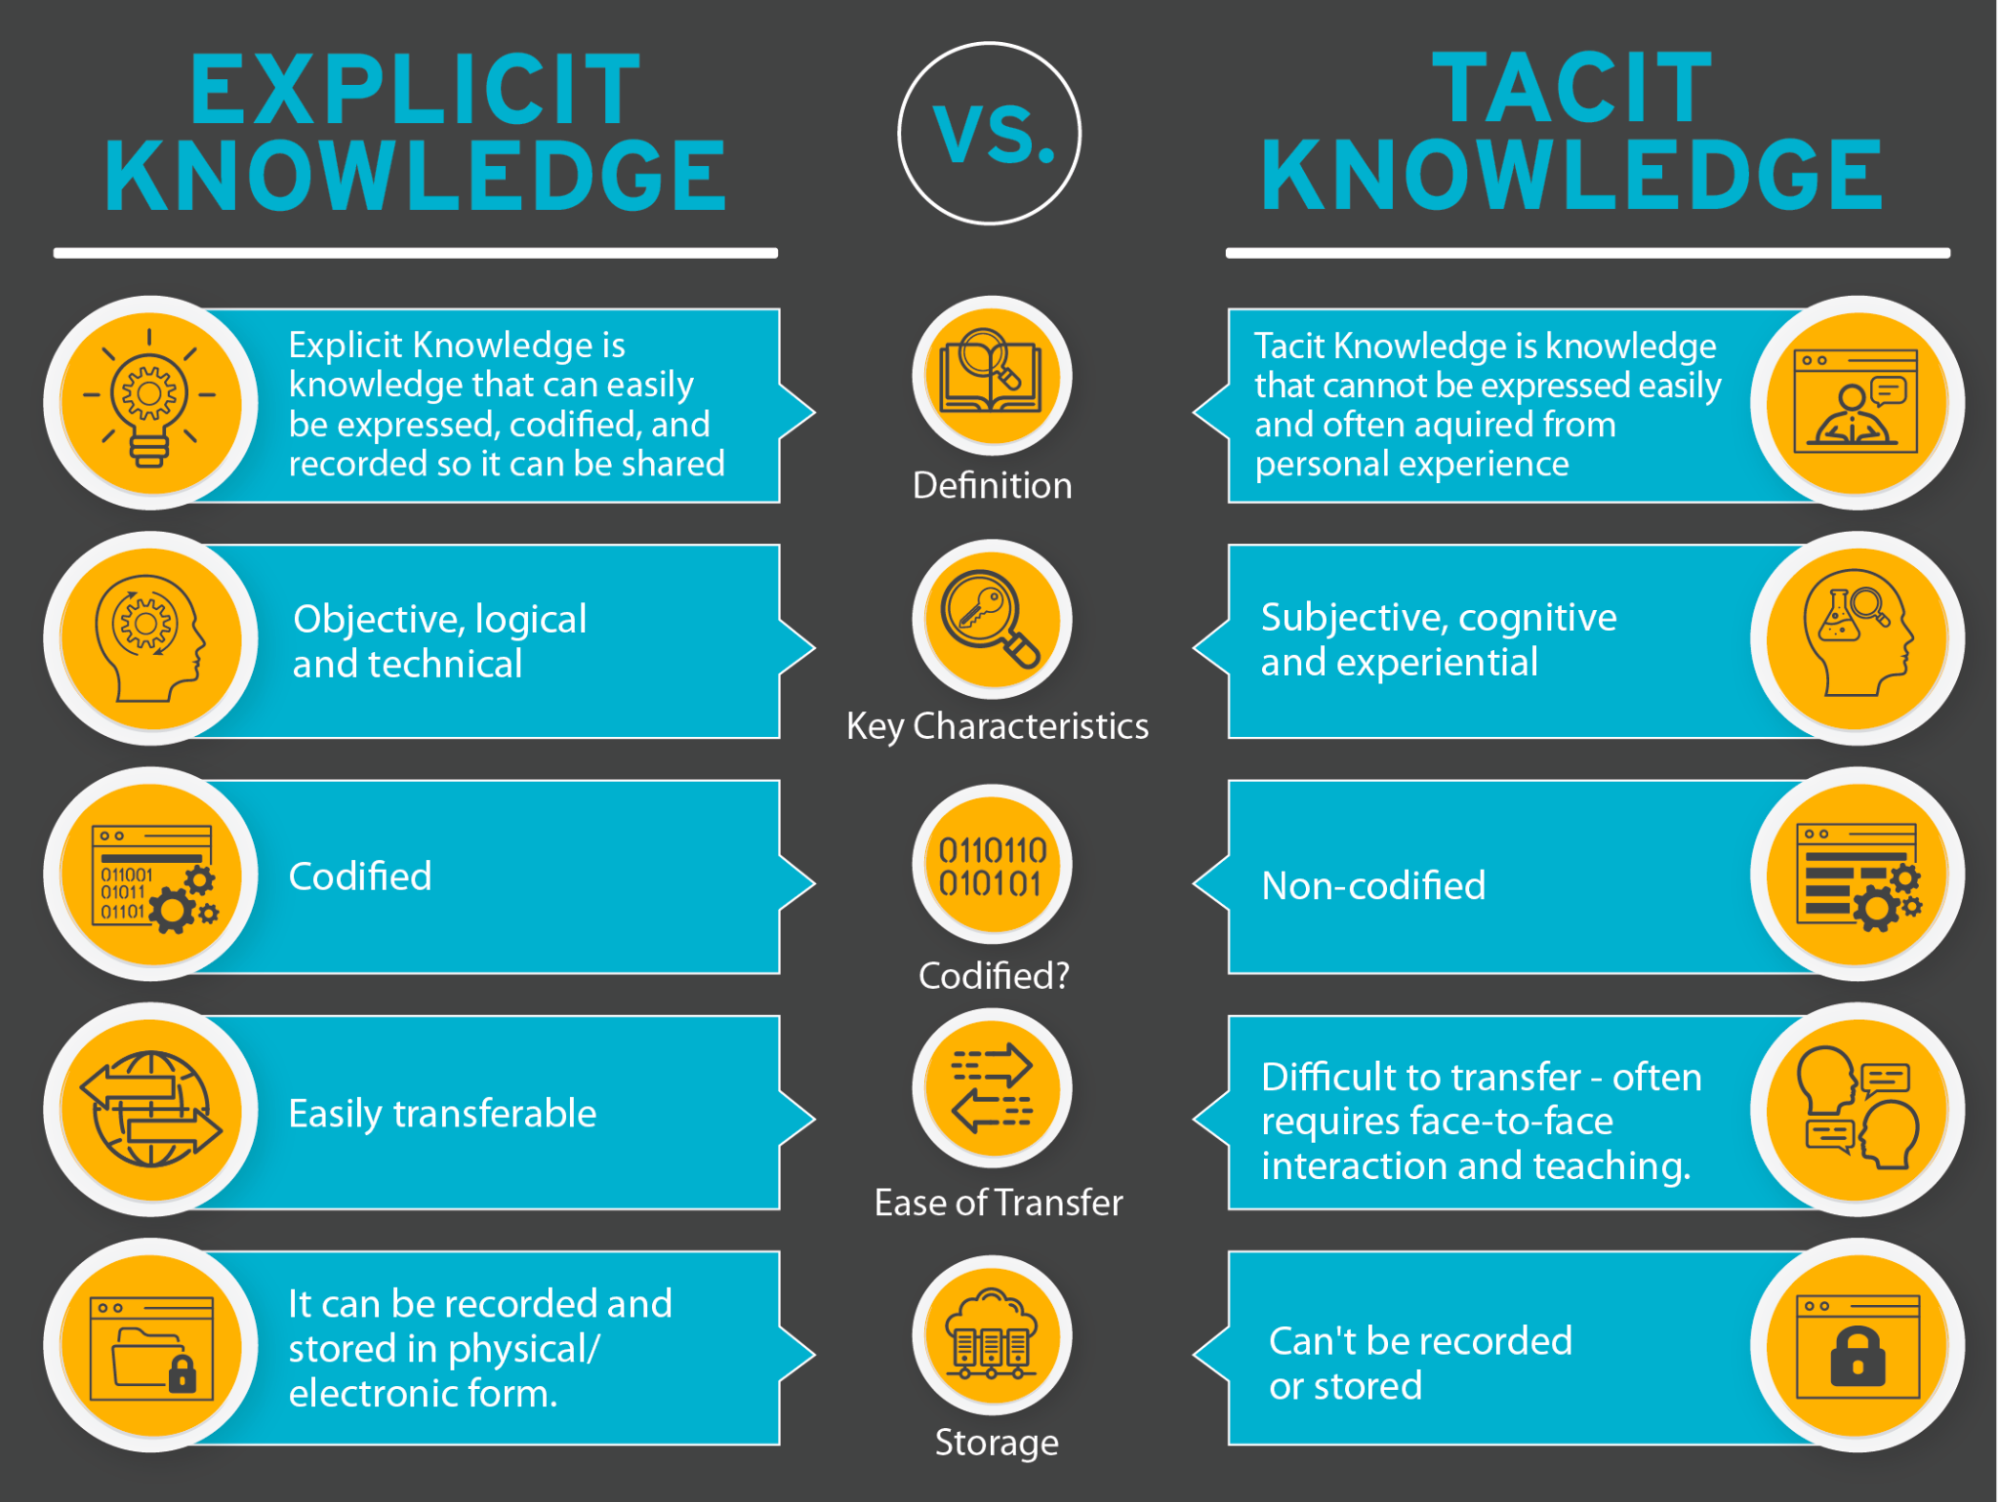
Tacit learning represents a profound and often underappreciated form of knowledge acquisition, distinct from its explicit counterpart. While explicit learning involves conscious assimilation of facts, procedures, and data—what we can articulate and document—tacit learning refers to knowledge gained implicitly, often through experience, practice, and observation, without conscious awareness of the learning process itself. It is the “knowing how” rather than the “knowing that,” deeply embedded in our actions, intuitions, and practical understanding. This form of learning manifests as skills, insights, and understandings that are difficult to verbalize, codify, or transmit through formal instruction. In the rapidly evolving landscape of drone technology and innovation, understanding tacit learning is crucial, impacting everything from human pilot proficiency to the development of sophisticated autonomous AI systems. It underpins the subtle, adaptive capabilities that push the boundaries of what drones can achieve, moving beyond programmed instructions to intuitive mastery and intelligent autonomy.
Human Tacit Learning in Drone Operations: The Intuitive Pilot
The operation of advanced drone systems, particularly in dynamic and unpredictable environments, heavily relies on the tacit knowledge developed by human pilots. Beyond memorizing flight manuals and explicit procedures, experienced drone operators cultivate a rich reservoir of tacit understanding that allows them to react instinctively, adapt creatively, and achieve outcomes that sheer explicit knowledge alone cannot guarantee.
Mastering Complex Maneuvers and Adaptability
Consider the FPV (First Person View) racing drone pilot, or the aerial cinematographer navigating a drone through a dense forest or over a tumultuous seascape. While they initially learn explicit controls and flight mechanics, true mastery comes from countless hours of practice. This practice instills a tacit understanding of aerodynamics, momentum, inertia, and environmental factors like wind gusts or thermal currents. Pilots develop an intuitive “feel” for the drone’s behavior, predicting its movements and responding with micro-adjustments before consciously processing the need for them. This implicit knowledge allows them to execute complex maneuvers—tight turns, precise dives, delicate hovers—with fluid grace and precision that seems almost effortless. It’s not about following a checklist but about an internal model of the drone’s physics and dynamics, shaped by experience, that guides their hands on the controller. This adaptive capacity, born of tacit learning, is invaluable when encountering unforeseen obstacles or rapidly changing conditions, enabling pilots to troubleshoot in real-time without falling back on explicit problem-solving steps.
Strategic Awareness and Decision-Making
Beyond mere control, tacit learning also profoundly influences a pilot’s strategic awareness and decision-making. An experienced pilot develops an intuitive understanding of the operational environment, recognizing subtle cues that might escape a novice. This could involve an immediate assessment of lighting conditions for optimal camera exposure, an innate sense of safe distances from obstacles in complex terrain for mapping missions, or anticipating the behavior of wildlife during a conservation survey. These are not decisions made through explicit calculation but through a holistic, pattern-recognition process derived from vast experience. They “know” the right angle for a shot, the optimal flight path for data collection, or the precise moment to abort a mission due to deteriorating weather, often without being able to fully articulate why they know it. This level of judgment, critical for both safety and mission success, is a prime example of tacit knowledge in action, underscoring the innovative human element in drone technology.
Bridging Tacit Knowledge to Artificial Intelligence in Drones
The principles of tacit learning, initially observed in human cognition, find fascinating parallels and powerful applications in the realm of artificial intelligence and machine learning within drone technology. As drones move towards greater autonomy, the ability for AI systems to acquire “knowledge” implicitly, without explicit programming for every scenario, is central to their innovation.
Machine Learning’s Implicit Knowledge Acquisition
Modern AI, particularly through machine learning, often mimics a form of tacit learning. For instance, in an autonomous drone tasked with object recognition for package delivery or search and rescue, neural networks are trained on vast datasets of images and videos. While no human explicitly programs the network to recognize “a person” or “a delivery box” based on a rigid set of rules, the network implicitly learns the complex features, patterns, and relationships within the data that constitute these objects. Its “knowledge” of what defines a human or a package isn’t a list of explicit rules but rather a complex configuration of weighted connections within its layers—a form of implicit, unarticulable understanding. This tacit knowledge allows the drone’s AI to generalize and identify objects in novel environments and varying conditions, much like a human develops an intuitive recognition ability.
Reinforcement Learning and Emergent Behaviors
Reinforcement learning (RL) represents another powerful paradigm where AI systems acquire tacit knowledge through trial and error, akin to how humans learn complex motor skills. In RL, an AI agent, such as an autonomous navigation system for a drone, interacts with an environment and receives rewards or penalties based on its actions. Over time, through iterative exploration and optimization, the agent learns a “policy”—a set of behaviors or strategies that maximize its cumulative reward. This policy is often highly complex and emergent; the AI doesn’t explicitly understand the underlying physics or optimal paths in an explicit sense. Instead, it develops an implicit, tacit understanding of how to navigate, avoid obstacles, or perform tasks efficiently within its environment. For example, an autonomous drone trained through RL might discover novel, highly efficient flight paths or obstacle avoidance strategies that were not explicitly programmed by human engineers. This emergent “tacit knowledge” is vital for autonomous drones operating in unstructured, dynamic, and unpredictable real-world environments, such as navigating through dense urban canyons or performing complex inspections. The drone’s AI develops an intuitive “feel” for its environment and its own capabilities, making it adaptable and robust.
The Synergistic Future of Tacit Knowledge and Drone Innovation
The recognition and intentional integration of tacit learning principles, both human and artificial, are set to drive the next wave of innovation in drone technology. This synergy promises more intuitive human-machine interfaces, more robust autonomous systems, and ultimately, drones that are more capable and versatile in their applications.
Enhancing Autonomous Systems Through Tacit Principles
Future drone innovation will increasingly focus on designing autonomous systems that can acquire and leverage tacit knowledge more effectively. This involves developing AI that isn’t just explicitly programmed but can continuously learn and adapt from experience, mimic human intuition, and even infer user intentions implicitly. Imagine drones that, after observing human experts perform complex tasks like aerial inspections or agricultural surveys, can develop their own tacit models for optimal sensor placement, flight patterns, or data interpretation, even in slightly varied contexts. This learning could involve advanced neural networks that develop “common sense” understanding of real-world physics, or reinforcement learning agents that gain a tacit understanding of nuanced operational parameters beyond what explicit rules could ever cover. Such systems would be less brittle, more resilient to unforeseen circumstances, and capable of operating with greater independence and sophistication, pushing the boundaries of what is currently feasible in autonomous flight and data collection.

Designing User Interfaces for Intuitive Interaction
On the human-machine interface front, understanding tacit learning will lead to the development of drone control systems that are more intuitive and responsive to the operator’s implicit intentions. Instead of requiring explicit commands for every action, future interfaces could leverage technologies like gaze tracking, gesture recognition, or even neuro-interfacing to infer a pilot’s tacit desires for a particular flight path, camera angle, or object of interest. This would allow operators to control complex drone fleets or execute intricate maneuvers with a fluidity that mirrors their own intuitive thought processes, reducing cognitive load and enhancing performance. Furthermore, training programs for drone pilots can be enhanced by deliberately fostering tacit learning through immersive simulations and hands-on experience, recognizing that true mastery often comes from implicit knowledge rather than solely from explicit instruction. By designing drones and their interfaces with an eye towards facilitating and leveraging both human and machine tacit learning, we pave the way for a future where drone technology is not just powerful, but also profoundly intelligent, adaptive, and seamlessly integrated into complex operations.