
The Unseen Architect of Flight Technology
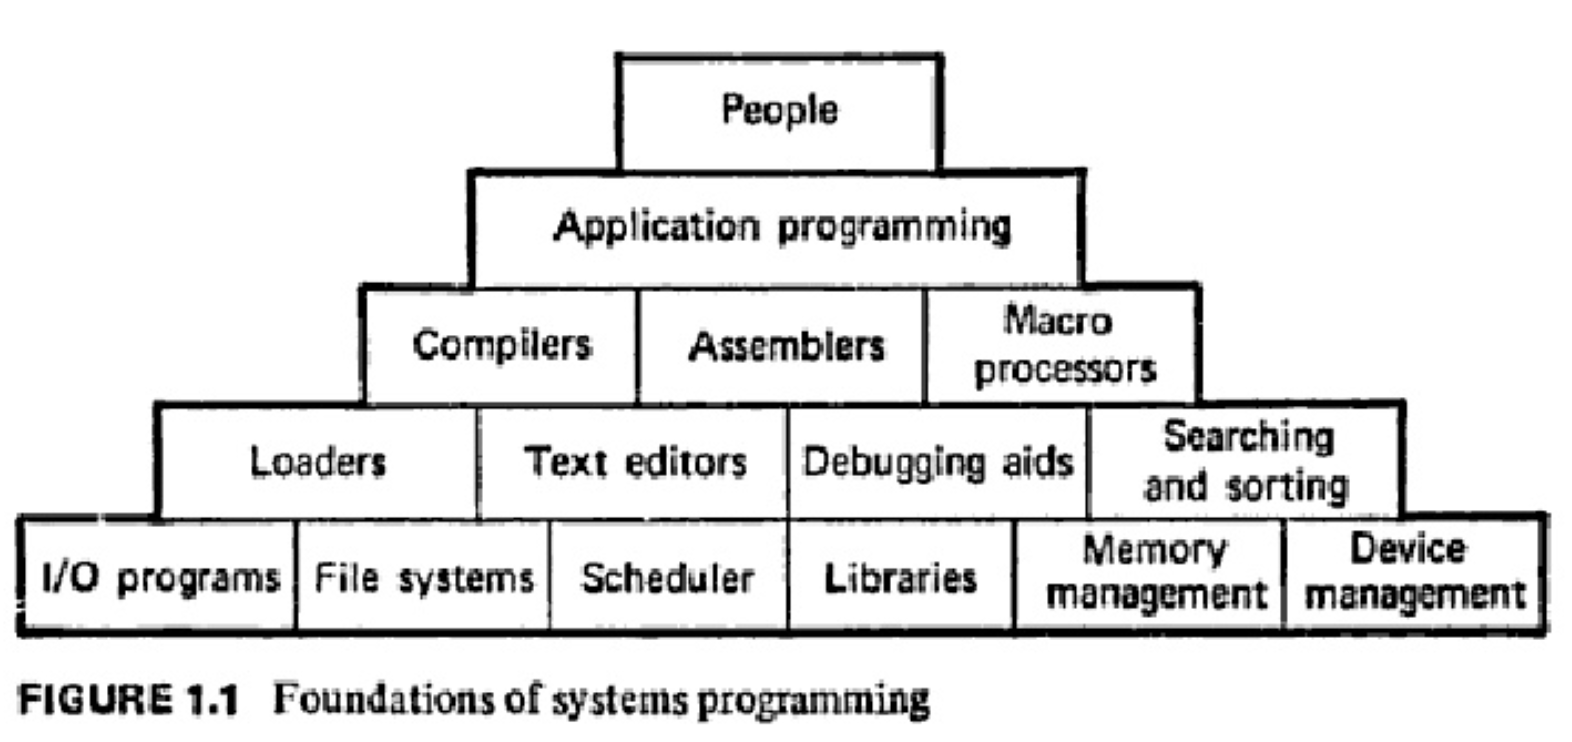
Systems programming is the bedrock upon which all advanced flight technology is built, though its intricate workings often remain invisible to the end-user. At its core, systems programming is the discipline of creating software that interfaces directly with hardware, manages system resources, and provides a platform for higher-level applications. For drones and other aerial vehicles, this means crafting the fundamental code that enables navigation, stabilization, sensor interpretation, and obstacle avoidance. It’s the meticulous engineering that translates electrical signals from an Inertial Measurement Unit (IMU) into actionable data for flight control, or that orchestrates the precise timing required for a Global Positioning System (GPS) module to lock onto satellites and provide accurate location data. Without robust systems programming, the sophisticated flight maneuvers, autonomous capabilities, and safety features we expect from modern drones would simply not exist. It’s the silent force empowering the precise and reliable operation of every component, from motors to sensors, ensuring seamless interaction within a complex embedded system.
Core Pillars: Real-Time Operating Systems and Firmware
The complexity and real-time demands of drone flight necessitate specialized software infrastructure. Two critical components defined by systems programming are Real-Time Operating Systems (RTOS) and the embedded firmware itself.
Real-Time Operating Systems (RTOS) for Deterministic Flight
Unlike general-purpose operating systems found in computers or smartphones, an RTOS is specifically designed to guarantee that certain tasks execute within a strict timeframe. This determinism is non-negotiable for flight technology. Imagine a drone in mid-air needing to adjust its motor speed based on an unexpected gust of wind. If the operating system delays the sensor data processing or the motor command by even a few milliseconds, the drone could lose stability or even crash. An RTOS on a flight controller prioritizes critical tasks like reading sensor data (accelerometers, gyroscopes, magnetometers), executing PID (Proportional-Integral-Derivative) control loops for stabilization, and sending commands to Electronic Speed Controllers (ESCs) to adjust motor thrust. It meticulously manages concurrent processes, ensuring that high-priority functions are always handled promptly, regardless of other activities. Popular RTOS examples in the drone world include NuttX, FreeRTOS, and ChibiOS, each optimized for resource-constrained environments while providing the essential timing guarantees required for agile and safe flight.
Firmware: The Drone’s Brain Code
Firmware represents the specific low-level software that is permanently programmed into a drone’s hardware components, acting as the drone’s primary brain. This code is responsible for defining the basic functionalities of the flight controller, GPS module, ESCs, and even specialized sensors. For the main flight controller, firmware encompasses everything from startup routines and hardware initialization to the implementation of various flight modes (e.g., manual, altitude hold, position hold, return-to-home). It directly interprets commands from the remote controller or autonomous flight algorithms, translates them into precise motor control signals, and continuously processes sensor data to maintain stable flight. The efficiency, reliability, and bug-free nature of this firmware are paramount. Any errors can lead to unpredictable behavior, degraded performance, or catastrophic failure. Systems programmers meticulously craft this code, often in languages like C or C++, optimizing for speed, memory usage, and robust error handling to ensure the drone operates safely and predictably under all flight conditions.
Bridging Hardware and Software: Device Drivers and Sensor Integration
For a drone to navigate intelligently and avoid obstacles, its flight controller must be able to “understand” the physical world through its array of sensors. This understanding is facilitated by specialized systems programming components: device drivers and the seamless integration of various sensing technologies.
Device Drivers: Translating Hardware Signals
Device drivers are a cornerstone of systems programming, serving as the essential intermediaries that enable the flight controller’s main processor to communicate with peripheral hardware components like gyroscopes, accelerometers, magnetometers, barometers, GPS modules, and more advanced sensors such as LiDAR or ultrasonic rangefinders. When a sensor gathers data – be it angular velocity from a gyroscope or atmospheric pressure from a barometer – it does so in a raw, often complex, electrical format. The device driver’s role is to interpret these raw signals, convert them into meaningful digital data (e.g., degrees per second, altitude in meters), and make this data available to the operating system and higher-level flight algorithms. Systems programmers must intimately understand the specific communication protocols (like I2C, SPI, UART) and data sheets of each sensor to write drivers that are not only accurate but also performant, ensuring minimal latency in data acquisition. This real-time data flow is absolutely critical for the drone’s flight controller to continuously update its understanding of its own orientation, position, and environment.
GPS and Navigation Systems
The integration of GPS into drone flight technology is a prime example of systems programming at work. The GPS module itself is a complex embedded system that receives signals from satellites, calculates its position, and outputs this data. A dedicated device driver and associated systems-level code are responsible for interfacing with this module, parsing the NMEA (National Marine Electronics Association) sentences or other data streams, and extracting precise latitude, longitude, and altitude information. Beyond mere data acquisition, systems programming integrates this GPS data into the drone’s overall navigation framework, often employing sophisticated Kalman filters or other estimation algorithms to fuse GPS data with IMU data for highly accurate position and velocity estimates. This refined position data then enables critical flight modes such as position hold, waypoint navigation, and autonomous flight paths, allowing drones to execute predefined missions with remarkable precision.
Obstacle Avoidance and Environmental Sensing
Modern drones often feature sophisticated obstacle avoidance capabilities, which rely heavily on real-time environmental sensing. Systems programming is fundamental to enabling this. Sensors such as ultrasonic rangefinders, LiDAR units, and stereo cameras generate vast amounts of data about the drone’s immediate surroundings. Systems-level software processes this raw sensor data at extremely high speeds, identifying potential collision threats and feeding this information to the flight controller’s decision-making algorithms. For example, a systems programmer might write optimized code to filter noise from ultrasonic readings or process point clouds from LiDAR in real-time on a resource-constrained embedded processor. This low-level processing is then used by higher-level path planning algorithms, which, in turn, issue real-time commands to the flight control system to alter the drone’s trajectory and safely navigate around detected obstacles. The seamless and rapid execution of these sensory inputs and corrective actions is a direct outcome of robust systems programming.
The Pursuit of Precision: Control Loops and Optimization
The very essence of stable and agile flight in drones is rooted in highly precise control mechanisms and relentless performance optimization, both of which are direct outcomes of systems programming expertise.
Stabilization Systems: PID Control and Beyond
At the heart of every stable drone lies a series of high-frequency control loops, most notably the PID (Proportional-Integral-Derivative) controller. Systems programming is responsible for implementing these critical feedback loops, which continuously adjust the drone’s motor speeds to maintain a desired orientation and position. The flight controller uses data from the IMU (gyroscopes and accelerometers) to detect even the slightest deviation from the commanded attitude (roll, pitch, yaw). The PID algorithm, meticulously coded and tuned by systems programmers, calculates the necessary corrective action, sending precise commands to the ESCs to increase or decrease the thrust of individual motors. This entire process – from sensor reading to motor command – must occur hundreds, if not thousands, of times per second with extremely low latency to ensure instantaneous responsiveness and smooth, stable flight. Systems programming ensures that these calculations are performed efficiently, minimizing computational overhead and maximizing the frequency at which the drone can react to internal and external disturbances.
Resource Management and Performance Optimization
Embedded systems like drone flight controllers operate with severe constraints on processing power, memory, and energy. Systems programming is crucial for effectively managing these limited resources to achieve optimal performance and flight endurance. This involves techniques such as direct memory access (DMA) for efficient data transfers between peripherals and memory without CPU intervention, clever interrupt handling to prioritize time-critical tasks, and bare-metal programming to squeeze every bit of performance out of the hardware. Systems programmers also focus on writing highly optimized code, often utilizing assembly language for critical sections or leveraging compiler-specific optimizations, to ensure that complex algorithms for navigation, stabilization, and obstacle avoidance can execute within the tight real-time deadlines. Efficient resource management extends to power consumption, where carefully designed low-power states and optimized code paths contribute directly to longer flight times, a vital metric for drone operations.
Ensuring Reliability and Security in the Air
Beyond mere functionality, systems programming plays an indispensable role in ensuring the fundamental reliability, safety, and security of drone flight technology. In applications ranging from recreational flying to critical infrastructure inspection, these aspects are paramount.
Error Handling and Fault Tolerance
A drone operating autonomously in the sky faces numerous potential points of failure, from sensor malfunctions and communication dropouts to unexpected environmental conditions. Systems programming is pivotal in building fault-tolerant systems that can detect, isolate, and often recover from such errors. This involves implementing sophisticated error detection mechanisms, such as checksums for data integrity, redundant sensor readings for validation, and continuous self-diagnostics. When an anomaly is detected, the systems-level code must execute predefined fail-safe procedures. This could range from switching to an alternative sensor, ignoring corrupted data, or, in critical situations, initiating an autonomous return-to-home sequence or a controlled emergency landing. The careful design of these error handling and recovery protocols ensures that even in the face of component failures, the drone can maintain a degree of operational integrity, greatly enhancing flight safety and preventing costly accidents.

System Security and Integrity
As drones become more integrated into commercial and public operations, their security and integrity are increasingly important. Systems programming addresses these concerns at the foundational level. Protecting the drone’s firmware from unauthorized access, modification, or even malicious injection is critical. This involves implementing secure boot processes, where the drone’s processor verifies the authenticity and integrity of the firmware before execution, often using cryptographic signatures. Systems programmers also work on securing communication channels between the drone and its ground control station or remote controller, employing encryption protocols to prevent eavesdropping or hijacking. Beyond preventing external threats, ensuring the internal integrity of the software stack—preventing unintended interactions or vulnerabilities that could lead to erratic behavior—is a constant focus. By embedding robust security measures directly into the lowest layers of the drone’s software, systems programming helps safeguard against both cyber threats and operational vulnerabilities, ensuring trustworthy and secure flight operations.