
The trigonometric function sine, particularly at the value of π/2 radians (or 90 degrees), plays a surprisingly significant role in various aspects of modern technology, especially within the realm of flight and navigation systems. While seemingly an abstract mathematical concept, its practical applications are foundational to how many advanced unmanned aerial vehicles (UAVs) and other flight technologies operate with precision and reliability. Understanding the value of sin(π/2) is not just about memorizing a number; it’s about appreciating its function in describing fundamental physical phenomena that enable sophisticated flight capabilities.
The Mathematical Foundation of Sin π/2
At its core, trigonometry deals with the relationships between the angles and sides of triangles. The sine function, denoted as sin(θ), is one of the fundamental trigonometric ratios. In a right-angled triangle, the sine of an angle is defined as the ratio of the length of the side opposite the angle to the length of the hypotenuse.
Understanding the Unit Circle
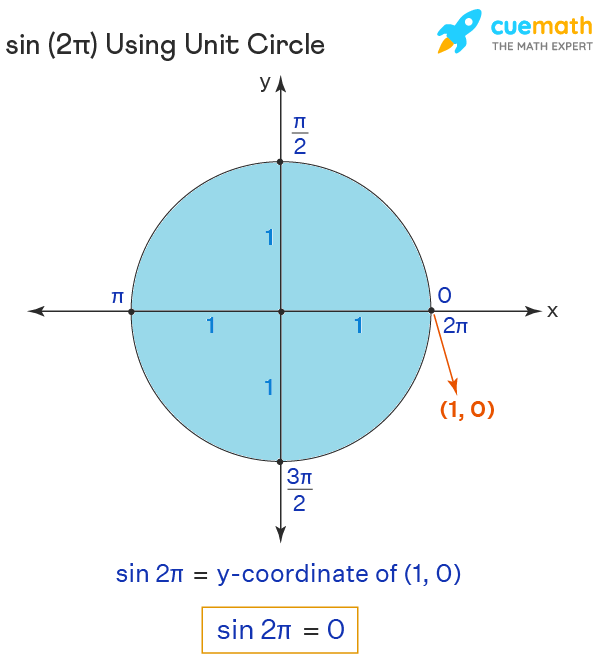
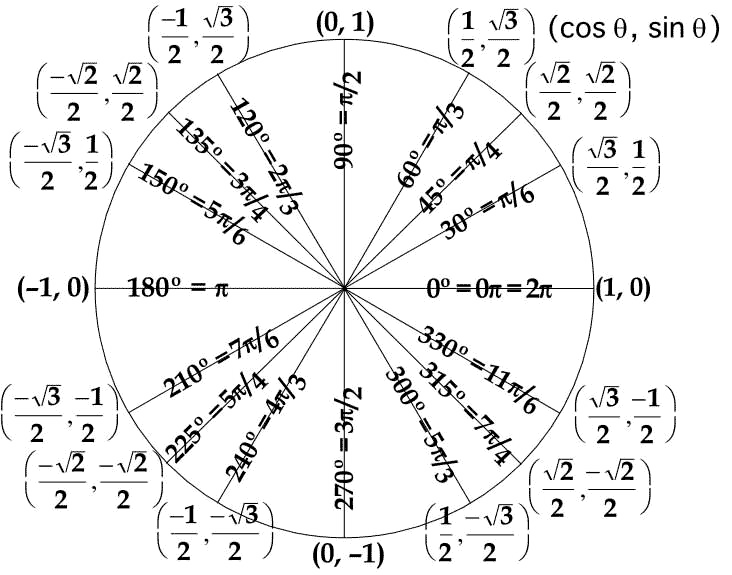
The most intuitive way to visualize the sine function and its values across all angles is through the unit circle. The unit circle is a circle with a radius of one centered at the origin (0,0) of a Cartesian coordinate system. An angle θ, measured counterclockwise from the positive x-axis, intersects the unit circle at a point (x, y). For any point on the unit circle, the x-coordinate represents cos(θ) and the y-coordinate represents sin(θ).
When the angle θ is π/2 radians (which is equivalent to 90 degrees), the point on the unit circle is located directly on the positive y-axis. At this position, the x-coordinate is 0 and the y-coordinate is 1. Therefore, sin(π/2) = 1.
The Significance of Sin(θ) = 1
The value of 1 for sin(π/2) signifies a maximum positive amplitude. In the context of periodic functions, which sine waves are, a value of 1 represents the peak of the wave. This peak value is crucial in many physical phenomena that oscillate or vary cyclically.
In mathematics, sin(π/2) = 1 is a straightforward result of its definition. However, its importance transcends pure mathematics when we consider its application in fields that rely on precise measurements and calculations of angles and rotations.
Applications in Flight Stabilization and Navigation
The principles of trigonometry, including the value of sin(π/2), are deeply embedded in the algorithms that govern flight stabilization and navigation for drones and other aircraft. These systems rely on accurate processing of sensor data and precise control of actuators to maintain stability and follow desired flight paths.
Inertial Measurement Units (IMUs) and Orientation
A key component in modern flight systems is the Inertial Measurement Unit (IMU). An IMU typically comprises accelerometers and gyroscopes. Accelerometers measure linear acceleration, while gyroscopes measure angular velocity. By integrating data from these sensors, the flight controller can determine the drone’s orientation in three-dimensional space – its pitch, roll, and yaw.
The calculation of these angles, and the subsequent correction maneuvers, heavily involves trigonometric functions. For instance, when a drone experiences a tilt, the accelerometers will detect a component of gravity along their axes. To accurately determine the true orientation, the raw accelerometer readings need to be processed using trigonometric transformations. In situations where the drone is perfectly level (pitch and roll are zero), the accelerometer readings align perfectly with the axes of the drone. However, as the drone tilts, gravity’s vector is decomposed into components along the drone’s axes, requiring sine and cosine functions to resolve.
Consider the pitch angle (rotation around the lateral axis). The accelerometer readings along the forward and downward axes are influenced by gravity. If the drone is tilted by an angle θ, the component of gravity sensed along the forward axis is proportional to sin(θ), and along the downward axis, it’s related to cos(θ). When the pitch angle is π/2 (90 degrees, meaning the drone is upside down), sin(π/2) = 1, and the accelerometer would register the full force of gravity along the forward axis if it were aligned that way. While this is an extreme example, it illustrates how the sine function directly relates to the projected force of gravity based on orientation.
Gimbal Stabilization
For cameras mounted on drones, maintaining a stable image is paramount, especially for aerial filmmaking and surveying. Gimbals are electromechanical devices that use motors to counteract unwanted camera movements, keeping the camera level or pointed in a desired direction regardless of the drone’s attitude.
A typical three-axis gimbal stabilizes pitch, roll, and yaw. The control algorithms for these gimbals are replete with trigonometric calculations. When the drone pitches forward, the gimbal’s pitch motor needs to tilt the camera backward by an equal amount to maintain a level view. The required angle of correction is directly determined by the drone’s measured pitch angle, which is itself derived using trigonometric functions from IMU data.
The synchronization between the drone’s movement and the gimbal’s compensation involves continuous calculation of angles and their trigonometric values. For example, if the drone rolls by an angle φ, the gimbal’s roll motor must counteract this by tilting the camera by –φ. The precision of this counteraction relies on the accurate calculation of trigonometric functions for these angles.
In a simplified scenario, if a gimbal motor is responsible for counteracting roll and needs to achieve a specific output based on an input angle, the relationship might involve a sine function. If the motor’s torque or position output is directly proportional to sin(angleerror), then when the angleerror is π/2, the motor exerts its maximum corrective force or moves to its maximum extent. This highlights how sin(π/2) = 1 represents a peak operational state for such control systems.
GPS and Navigation Algorithms
While GPS primarily provides position data, integrating this information into a navigation system involves understanding direction and movement vectors. Bearing calculations and course plotting often utilize spherical trigonometry, which itself relies on plane trigonometry principles.

When calculating the course to steer to a waypoint, the system determines the angle between the drone’s current heading and the heading towards the waypoint. This angle calculation, and the subsequent steering commands, involve trigonometric functions. If the drone needs to make a sharp turn to face directly towards a target, the necessary turning angle will be processed through these functions.
Furthermore, in complex navigation scenarios, such as when compensating for wind drift, the flight controller calculates the required airspeed and heading to maintain a ground track. This involves vector addition and decomposition, where trigonometric functions are essential for resolving velocities and forces into their horizontal and vertical components.
Role in Sensor Data Processing and Control Systems
Beyond stabilization and navigation, sin(π/2) and other trigonometric values are fundamental to processing data from a wide array of sensors and implementing sophisticated control logic in advanced flight technologies.
Obstacle Avoidance Systems
Modern drones are increasingly equipped with obstacle avoidance systems that use sensors like LiDAR, ultrasonic sensors, or stereo cameras to detect and navigate around objects. The interpretation of data from these sensors often involves mapping distances and angles to identify potential collision risks.
For instance, if a LiDAR sensor sweeps its laser beam across an area, it measures the distance to the first object encountered at each specific angle. To create a 3D map of the environment, these distance measurements are converted into Cartesian coordinates using trigonometry. If the laser beam is directed at an angle θ relative to a reference axis, the x and y coordinates of the detected object would be calculated as distance * cos(θ) and distance * sin(θ), respectively.
In a scenario where the sensor is precisely pointing upwards (an angle of π/2 or 90 degrees relative to the horizontal plane), the sine function would be used to determine the vertical component of any detected object’s position relative to the sensor. If the system is designed to identify objects directly overhead, and the angle is measured from the horizontal, an angle of π/2 would signify looking straight up. In this case, sin(π/2) = 1, meaning the horizontal component of the object’s relative position would be zero, and the vertical component would be equal to the measured distance. This allows the system to accurately plot the object’s coordinates and assess the risk.
Control Loop Design
The control systems that manage a drone’s flight are often designed using feedback loops. These loops continuously measure the drone’s state (e.g., altitude, speed, attitude) and compare it to the desired state. The difference, or error, is then used to calculate corrective commands for the motors.
The mathematical models used to design these control loops frequently employ transfer functions and frequency domain analysis. Trigonometric functions are inherent in the representation of sinusoidal signals, which are commonly used to analyze the stability and performance of control systems. For example, when testing a drone’s response to a disturbance, engineers might apply a sinusoidal input to simulate a gust of wind. The system’s response, often characterized by its gain and phase shift, is analyzed using Fourier transforms, which decompose signals into their sinusoidal components. The amplitude and phase of these components are directly related to trigonometric values.
The concept of resonance, where a system is highly sensitive to inputs at a specific frequency, is also described using trigonometric relationships. If a control system has a resonant frequency where its response is amplified, this amplification might be related to a situation where the trigonometric terms in its transfer function reach a maximum value, such as sin(π/2) = 1.
Advanced Flight Modes
Many sophisticated flight modes, such as autonomous waypoint navigation, object tracking, and complex aerial maneuvers, rely on advanced algorithms that heavily integrate trigonometric calculations.
For example, in an “AI Follow Me” mode, the drone needs to maintain a specific distance and relative position to a moving subject. This requires continuously calculating the subject’s position in 3D space and adjusting the drone’s flight path accordingly. The calculations involve determining the angles between the drone, the subject, and fixed reference points, and using these angles in trigonometric equations to predict future positions and plan evasive or corrective maneuvers.
If the drone is programmed to orbit a subject, the circular path it follows is described by parametric equations involving sine and cosine. The speed and radius of the orbit are directly controlled by the parameters in these equations. At specific points in the orbit, the drone’s velocity vector will be precisely tangential to the circle. The mathematical description of this tangential velocity vector, and its projection onto the drone’s axes, would involve trigonometric functions, with peak values occurring at angles like π/2.
The Broader Impact on Flight Technology
The ubiquity of trigonometric functions, including the specific value of sin(π/2), underscores their fundamental importance in the development and operation of modern flight technology. From the basic principles of geometry that describe spatial relationships to the complex algorithms that enable autonomous flight, mathematics provides the essential language and tools.
Precision and Reliability
The ability to accurately calculate sin(π/2) = 1, and to apply this knowledge in a computational context, directly contributes to the precision and reliability of flight systems. Whether it’s stabilizing a camera for cinematic shots, guiding a survey drone over vast terrain, or enabling an autonomous delivery drone to navigate a complex urban environment, the underlying mathematical operations are critical.
Errors in these calculations, even minute ones, can compound over time and lead to significant deviations in flight path, orientation, or performance. Therefore, the accuracy and efficiency of trigonometric computations are vital for the overall success of these technologies.
Innovation and Future Development
As flight technology continues to advance, incorporating elements like artificial intelligence, machine learning, and enhanced sensor fusion, the reliance on robust mathematical frameworks will only increase. New algorithms for predictive control, adaptive navigation, and complex swarm behaviors will undoubtedly continue to leverage the power of trigonometry.
The understanding of fundamental trigonometric values like sin(π/2) is not merely academic; it is a cornerstone that supports the ongoing innovation and expansion of possibilities within the drone and flight technology industries. It represents a simple yet profound relationship that translates directly into complex, real-world capabilities.