
The evolution of unmanned aerial vehicles (UAVs) has been a relentless pursuit of enhanced autonomy and intelligence, fundamentally changing how these machines interact with and understand their environments. Within the realm of Tech & Innovation, the concept of a drone “seeking” is central to its operational purpose—be it seeking a target, a path, data, or even a solution. To understand “what is seek in past tense” in this context is to delve into the historical methodologies, technological breakthroughs, and foundational algorithms that enabled drones to perform these functions, charting their progression from rudimentary observation platforms to sophisticated autonomous entities. This historical perspective illuminates the ingenious approaches developers sought to implement, shaping the intelligent systems we rely on today.

The Dawn of Drone Pursuit: Early Concepts of Seeking
In the early days of drone technology, the act of “seeking” was largely a human-driven endeavor, often limited by the capabilities of the platform and the visual acuity of the operator. However, even these initial efforts laid the groundwork for the autonomous seeking capabilities that would later emerge. Understanding what drones sought in their nascent forms provides critical insight into the foundation of modern drone intelligence.
Initial Pilot-Guided Reconnaissance
Initially, military and later commercial drones sought to extend human visual and surveillance capabilities beyond traditional limits. Operators, often utilizing First-Person View (FPV) cameras or ground control station monitors, manually steered these early UAVs to seek out specific targets, gather reconnaissance, or monitor designated areas. The “seeking” was primarily a direct extension of the human pilot’s intent, translating their visual identification and manual control inputs into the drone’s flight path and sensor orientation. For instance, in military applications, a drone sought to locate enemy positions or assess battle damage based on explicit human direction. In environmental monitoring, it sought to survey vast tracts of land for changes or anomalies, with the pilot interpreting the live video feed and adjusting the drone’s trajectory accordingly. This direct, manual engagement defined the earliest form of drone pursuit, where the drone served as a remote eye, its mission defined and executed moment-by-moment by a human intelligence seeking specific information.
The Birth of Automated Search Parameters
As drone technology matured, the limitations of purely manual seeking became apparent, especially for large-scale or repetitive tasks. This prompted engineers to seek more automated solutions. Early attempts at automation involved pre-programmed flight paths, where a drone sought to follow a predetermined sequence of waypoints, effectively performing a grid search or patrol pattern. While not truly intelligent “seeking,” this represented a significant leap from continuous manual control. These systems sought to cover an area systematically, gathering data along a defined route. For agricultural applications, drones sought to fly over fields in a predefined pattern to capture multispectral imagery for crop health analysis. In search and rescue missions, UAVs sought to systematically scan designated areas based on grid patterns uploaded prior to flight, reducing human workload and increasing coverage efficiency. These foundational steps, though rigid, were crucial in establishing the concept of an automated mission, where the drone itself sought to complete a task without constant human intervention, paving the way for more sophisticated algorithmic seeking.
Foundational Algorithms: How Drones First Sought Understanding
The shift from simple automation to genuine “seeking” intelligence required the development of algorithms that could enable drones to interpret their sensor data and make decisions. This era saw the emergence of rudimentary computational capabilities that allowed drones to seek patterns, identify objects, and navigate complex environments with a degree of autonomy previously unimaginable.
Early Object Detection and Tracking Mechanisms
As processing power improved and sensor technology became more sophisticated, drones began to seek specific objects or features within their field of view. Early object detection algorithms, often based on traditional computer vision techniques like feature matching, edge detection, and color segmentation, sought to identify predefined shapes or characteristics in real-time video feeds. For instance, a drone might have been programmed to seek vehicles by identifying rectangular shapes and specific color ranges, or to track moving objects by analyzing changes in pixel clusters over consecutive frames. While prone to errors in complex environments and sensitive to lighting conditions, these algorithms represented the drone’s first attempts to independently seek and understand elements in its operational space. These initial object detection systems sought to free the human operator from constant visual scrutiny, flagging potential points of interest or maintaining a lock on a moving subject, thereby automating a key aspect of “seeking” that had previously been exclusively manual.
Navigational Seeking: Mapping the Unseen
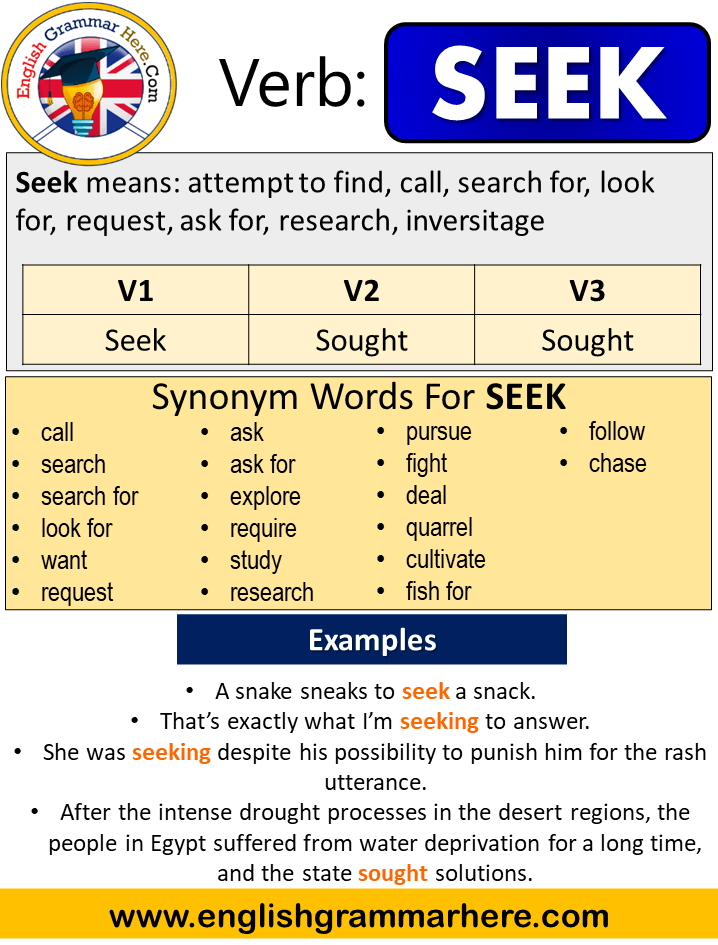
Beyond identifying objects, a critical aspect of drone intelligence involved the ability to seek and understand its own position and surroundings, a process fundamental to autonomous navigation and mapping. Early navigational algorithms sought to integrate data from various sensors—GPS, inertial measurement units (IMUs), and later, ultrasonic or infrared sensors—to build a spatial understanding. Simultaneous Localization and Mapping (SLAM) algorithms, in their nascent forms, were developed as drones sought to construct maps of unknown environments while simultaneously localizing themselves within those maps. For instance, an indoor drone might have sought to map a warehouse by identifying walls and obstacles, thereby building a navigable path. Outdoor drones, while heavily reliant on GPS, sought to refine their positional accuracy and understand terrain features through altimeter data and basic visual odometry. These pioneering efforts in “navigational seeking” allowed drones to move beyond simple waypoint following, giving them the capacity to seek safe paths, avoid obstacles, and autonomously explore new territories, a foundational capability for future complex missions.
The Evolution of Autonomous Sensing: From Reactive to Proactive Seeking
The mid-to-late stages of drone development witnessed a profound shift in how drones “sought” information. Moving beyond mere detection and reactive navigation, advanced systems began to incorporate predictive capabilities, enabling more proactive and intelligent pursuit of objectives. This era was characterized by the integration of multiple sensor types and the transformative influence of machine learning.
Sensor Fusion: A More Comprehensive Quest
As the array of sensors available for drones expanded—incorporating lidar, thermal cameras, advanced optical zoom, and more precise GPS modules—the need to intelligently combine and interpret this disparate data became paramount. Engineers sought to develop sophisticated sensor fusion algorithms that could merge inputs from multiple sources to create a more robust and comprehensive understanding of the environment. For example, a search and rescue drone sought to locate missing persons by combining thermal imagery (to detect heat signatures), optical zoom (to visually confirm), and GPS data (to pinpoint location). The fused data provided a richer context, allowing the drone to seek targets with greater accuracy and reliability, overcoming the limitations of any single sensor. This holistic approach to information gathering meant that drones no longer just sought isolated pieces of data but rather sought a coherent, multi-dimensional representation of their operational sphere, enhancing their ability to make informed decisions autonomously.
Machine Learning’s Influence on Predictive Seeking
The advent and rapid progression of machine learning (ML) and artificial intelligence (AI) revolutionized the drone’s ability to “seek.” Initially, ML models were trained on vast datasets to enable drones to seek and classify objects with unprecedented accuracy. Instead of rigid rule-based detection, a drone could now seek to identify specific types of vehicles, classify flora, or even detect anomalies indicative of structural damage, having learned from countless examples. Beyond simple classification, ML allowed drones to transition from reactive seeking to proactive and even predictive seeking. For instance, in an AI follow-mode, the drone sought not just to track a subject’s current position but to anticipate its future movements, using learned patterns of human behavior. In smart agriculture, drones sought to predict areas susceptible to disease or drought based on historical data and current sensor readings. This profound shift meant that drones could seek not only what was present but also what was likely to happen, empowering them with a level of foresight that transformed their operational effectiveness.
Modern Implications: The Persistent Legacy of Sought Knowledge
Today’s sophisticated drone systems are direct descendants of these foundational “seeking” capabilities. The knowledge and techniques sought and implemented in the past form the bedrock of current innovations in autonomous flight, intelligent data acquisition, and complex mission execution. The question of “what is seek in past tense” now extends to how these historical endeavors continue to inform the cutting edge of drone technology.
AI-Driven Target Identification and Analysis
The legacy of early object detection and tracking has culminated in highly advanced AI-driven target identification systems. Modern drones, leveraging deep learning architectures, can now seek and identify a vast array of objects, from specific individuals to complex machinery, often under challenging conditions. For example, in urban surveillance, drones autonomously seek to identify anomalous activities or specific individuals based on facial recognition or gait analysis, operating with a high degree of precision. In industrial inspection, they seek to pinpoint minute structural faults in pipelines or wind turbines by analyzing thermal and optical data against known defect signatures. Furthermore, these systems don’t just identify; they seek to analyze and understand the context, providing actionable insights. The ability to autonomously seek, categorize, and analyze targets has fundamentally transformed applications ranging from public safety to environmental conservation.
Future Frontiers: The Continuous Pursuit of Intelligence
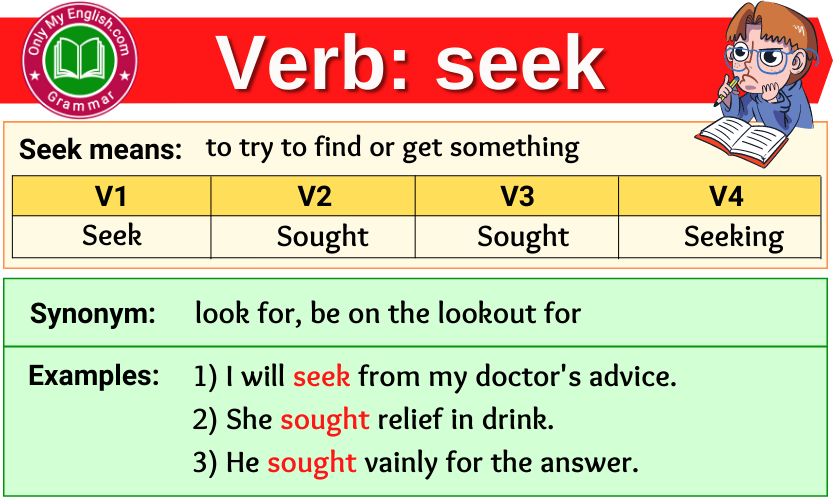
Looking ahead, the drone industry continues its relentless pursuit of enhanced intelligence, building directly upon the “seeking” capabilities developed over decades. Future innovations will see drones that can seek to learn and adapt in real-time, operating in highly dynamic and unpredictable environments with minimal human oversight. This includes advanced swarm intelligence, where multiple drones seek to coordinate their actions to achieve complex goals, such as comprehensive search and rescue over vast, challenging terrains or cooperative mapping of disaster zones. Drones will also seek to engage in more sophisticated human-drone interaction, understanding nuanced commands and anticipating human needs. The continuous development of neuromorphic computing and truly general AI promises drones that can seek novel solutions to unforeseen problems, exhibiting a form of creative problem-solving. The historical “seeking” of solutions, from manual control to autonomous learning, underpins this ambitious future, where drones are not just tools but increasingly intelligent partners in exploration, monitoring, and innovation. The past tense of “seek” in drone technology is a rich tapestry of ingenuity, each thread contributing to the autonomous wonders of today and inspiring the visionary capabilities of tomorrow.