
In the rapidly evolving world of uncrewed aerial vehicles (UAVs), commonly known as drones, the reliability and safety of flight technology are paramount. As manufacturers continually introduce innovations, ranging from enhanced navigation algorithms to more sophisticated sensor packages and obstacle avoidance systems, ensuring that new code deployments or system updates do not inadvertently compromise fundamental operational capabilities becomes a critical challenge. This is where sanity testing, a focused and rapid form of software testing, plays a non-negotiable role in drone flight technology development.
The Critical Role of Sanity Testing in UAV Systems Development
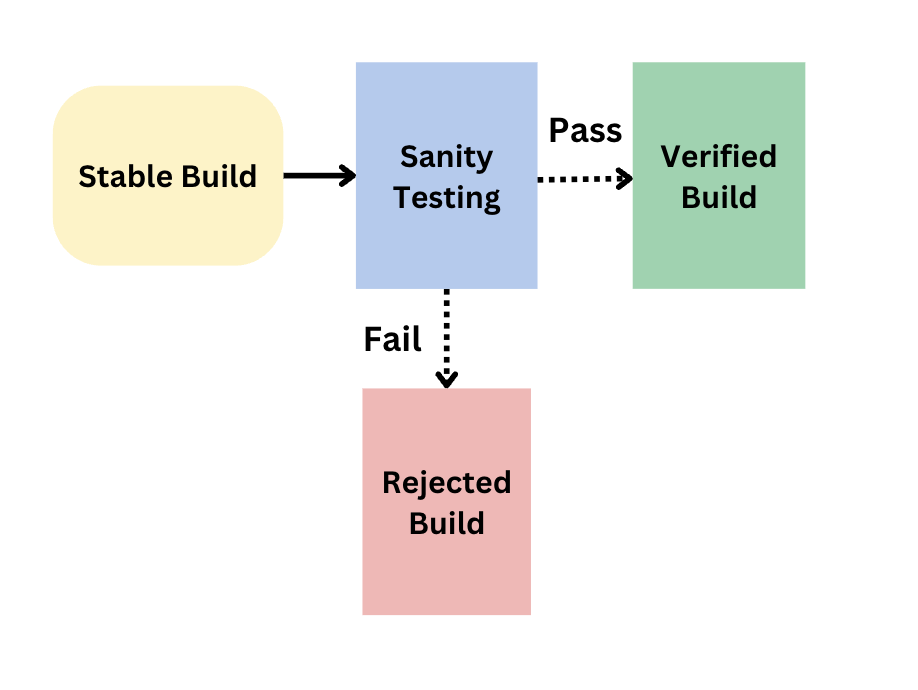
Sanity testing, at its core, is a quick, high-level verification process designed to ascertain whether a new build, software update, or patch has addressed its intended issues without introducing critical regressions. In the context of drone flight technology, this means swiftly confirming that the core functionalities responsible for stable and safe flight remain intact after any modification to the underlying firmware, software, or integrated hardware systems. It acts as a gatekeeper, preventing unstable or fundamentally flawed builds from progressing to more extensive and time-consuming testing phases.

Defining Sanity Testing for Core Flight Components
For UAVs, sanity testing focuses on the most vital “sanity” checks that determine if the drone is even capable of a basic, safe flight. This isn’t about exhaustive testing of every edge case or performance metric; rather, it’s about answering fundamental questions: Does the drone power on correctly? Can it acquire GPS lock? Do the propellers spin as commanded? Does the flight controller respond to basic inputs? Can it maintain a stable hover? These are the foundational elements of flight that, if broken, render the entire system unusable or, worse, dangerous.
Consider a scenario where a drone’s firmware receives an update designed to improve GPS accuracy in urban canyons. Before investing hours in comprehensive regression testing of every flight mode and sensor interaction, a sanity test would quickly verify:
- Can the drone still acquire a GPS fix?
- Does the GPS module report reasonable coordinates?
- Are basic navigation commands (e.g., hover, simple translational movements) still functional and stable, even if the accuracy improvement hasn’t been fully validated yet?
If any of these fundamental checks fail, the build is deemed “insane” – unfit for further testing or deployment – and is immediately sent back to development for remediation. This rapid feedback loop is crucial in accelerating development cycles while maintaining a baseline of operational integrity.
Why Quick Verification is Non-Negotiable for Flight Integrity
The consequences of flight technology failure can range from mission aborts and economic losses to physical damage and, in the worst cases, personal injury or death. Unlike many software applications, a drone’s operational environment is inherently physical and often complex, involving aerodynamics, real-time sensor data processing, and precise motor control. Introducing a bug that compromises basic stability or navigation could lead to uncontrolled flight, crashes, or deviation into restricted airspace.
Therefore, the ability to quickly verify that core flight integrity has not been compromised after any change is not merely an efficiency measure; it’s a fundamental safety requirement. Sanity testing provides that initial, crucial layer of defense. It allows developers and QA teams to catch major issues early in the pipeline, preventing them from propagating into later stages where they are far more costly and time-consuming to identify and fix. This rapid verification ensures that critical systems like navigation, stabilization, and obstacle avoidance maintain a baseline level of functionality throughout the iterative development process, underpinning the drone’s overall reliability.
Core Flight Technology Components Subject to Sanity Checks
Sanity testing in drone flight technology is specifically tailored to the vital systems that enable safe and controlled aerial operation. Each of these components has critical baseline behaviors that must be verified.
Global Positioning System (GPS) and Navigation Modules
The GPS module is the drone’s primary means of understanding its global position, velocity, and time. Navigation relies heavily on this data, combined with other sensors. Sanity checks for GPS and navigation modules would include:
- GPS Lock Acquisition: Does the drone acquire a sufficient number of satellites and achieve a 3D fix within a reasonable timeframe after power-up?
- Position Reporting: Does the reported latitude and longitude roughly correspond to the drone’s known location? Is the altitude reading plausible?
- Velocity Estimation: Is the reported velocity consistent with the drone’s state (e.g., zero when stationary, non-zero when moving)?
- Basic Waypoint Following (if applicable): Can the drone initiate and attempt to follow a very simple, short waypoint path, even if precision isn’t fully validated yet? This confirms the navigation stack’s fundamental ability to process and act on positional commands.
Inertial Measurement Units (IMUs) and Stabilization Algorithms
IMUs, comprising accelerometers, gyroscopes, and magnetometers, are fundamental for sensing the drone’s orientation, angular velocity, and linear acceleration. These data feeds are critical for the flight controller’s stabilization algorithms. Sanity checks involve:
- Sensor Data Readout: Are all IMU sensors reporting data? Are the values plausible (e.g., gravity vector from accelerometers, reasonable rotation rates from gyroscopes)?
- Attitude Estimation: Does the flight controller’s estimated attitude (roll, pitch, yaw) accurately reflect the drone’s physical orientation? If the drone is placed level, do the roll and pitch estimates read near zero?
- Basic Stabilization: Can the drone maintain a stable hover or, if manually controlled, respond predictably to stick inputs without erratic movements or oscillations? This confirms the stabilization loops are fundamentally active and responding.
- Calibration Integrity: After an update, are sensor calibrations still loaded and applied correctly, preventing significant drifts or biases?
Sensor Fusion Pipelines for Environmental Awareness
Modern drones integrate data from multiple sensors (GPS, IMU, barometer, lidar, vision sensors, etc.) through complex sensor fusion algorithms (e.g., Extended Kalman Filters) to create a robust and accurate state estimate. Sanity testing here ensures this fusion process hasn’t been broken:
- Data Integration: Are all expected sensor inputs being received by the fusion algorithm?
- Consistency Checks: Are the fused outputs (position, velocity, attitude) consistent across different sensor inputs? For instance, does the barometer-derived altitude generally align with GPS altitude when available?
- Redundancy Fallback: If a primary sensor (e.g., GPS) is intentionally blocked or fails, does the system gracefully degrade and rely on other available sensors for a degraded but still sane state estimate?
Obstacle Avoidance and Path Planning Logic
For drones equipped with advanced obstacle avoidance (OA) systems, sanity checks verify the most basic operational aspects of these safety features:
- Sensor Activation: Are the OA sensors (ultrasonic, vision, lidar) active and reporting data?
- Detection Indication: When an obvious obstacle is placed directly in front of or below the drone, does the system register its presence and provide a clear indication (e.g., visual cue, audible warning)?
- Basic Reaction: Does the drone attempt a basic avoidance maneuver (e.g., stopping, slowing down) when an obstacle is detected, rather than continuing to fly into it? This is not about validating the full avoidance capability but ensuring the detection-reaction chain is fundamentally operational.
Flight Controller Responsiveness and Command Execution
The flight controller is the brain of the drone, processing inputs and executing commands. Sanity tests verify its fundamental responsiveness:
- Motor Control: Do all motors respond to arming commands and throttle inputs? Do they spin up and down predictably?
- Control Loop Engagement: Are the control loops (attitude, velocity, position) active and stable?
- Safety Protocols: Are basic safety mechanisms, such as geofence boundaries (if enabled) or low battery warnings, still active and triggering appropriately? Does the kill switch function as expected?
- Remote Control Input Processing: Does the flight controller correctly interpret and act upon basic commands from the remote controller (e.g., takeoff, landing, simple directional movements)?
Methodologies for Implementing Sanity Testing in Flight Systems
Effective sanity testing for drone flight technology requires a blend of automation and structured manual checks, integrated seamlessly into the development and deployment pipeline.
Automated Scripting for Firmware and Software Updates
Automation is key to the speed and repeatability required for sanity testing. For firmware and software updates, automated sanity checks often involve:
- Unit Tests on Core Modules: Small, rapid tests that verify the functionality of individual software components (e.g., a specific GPS parsing function, an IMU data processing algorithm).
- Hardware-in-the-Loop (HIL) Simulation: Running the actual flight controller software on real hardware, connected to simulated sensor inputs and motor outputs. This allows for quick, repeatable “virtual flights” where basic behaviors like hover stability or GPS lock acquisition can be verified without physically flying the drone.
- Automated Log Analysis: Scripts that parse flight logs or telemetry data immediately after a test, looking for critical errors, unexpected values, or signs of system instability. For instance, checking if the estimated position diverged excessively or if sensor readings were out of bounds.
These automated scripts are typically executed immediately after a new build is generated, serving as the very first line of defense.
Manual Pre-Flight Checks and Initial Take-off Tests
While automation covers much of the ground, certain aspects of flight technology still benefit from quick, targeted manual sanity checks, especially before the first physical flight of a new build:
- Visual Inspection: Physically inspect the drone for obvious issues (e.g., loose propellers, damaged wiring) that might have been overlooked.
- Ground Checks: Powering on the drone and performing basic system health checks via a ground control station (GCS). This includes verifying battery voltage, CPU load, sensor status (e.g., GPS fix status, IMU health), and communication link integrity.
- Controlled Take-off and Hover: A brief, controlled take-off to a low altitude (e.g., 1-2 meters) followed by a stable hover is often the ultimate manual sanity check. This quickly confirms the flight controller’s ability to interpret sensor data, execute motor commands, and maintain basic stability in a real-world, dynamic environment. Any erratic behavior, strong drift, or unresponsiveness would immediately halt further testing.
Test Data Management and Environment Simulation
Creating consistent and repeatable test environments is crucial. For sanity testing, this means:
- Standardized Test Scenarios: Defining a minimal set of highly focused test cases that cover the core functionalities of each flight technology component.
- Representative Data Sets: For HIL or software-in-the-loop (SIL) simulations, using pre-recorded or synthetically generated sensor data that represents typical operating conditions (e.g., a clear sky for GPS, stable flight for IMU).
- Version Control for Test Assets: Ensuring that test scripts, simulation models, and configurations are version-controlled alongside the flight software itself, maintaining consistency and preventing test setup issues.
The Impact of Robust Sanity Testing on Drone Operations
The integration of robust sanity testing protocols directly translates into tangible benefits for drone manufacturers, operators, and the industry at large.
Enhancing Safety and Preventing Critical Failures
By catching fundamental flaws early, sanity testing directly enhances the safety profile of drone operations. An update that inadvertently disables a sensor or corrupts a critical navigation algorithm could lead to a flyaway or a crash. Sanity checks act as a primary filter, ensuring that only builds with a verified baseline of operational integrity move forward, significantly reducing the risk of critical failures in the field. This proactive approach to safety builds trust and compliance within regulatory frameworks.
Streamlining Development and Deployment Workflows
Imagine a complex drone project with dozens of developers contributing daily. Without sanity testing, a faulty code commit could break core flight functionality, halting the entire testing pipeline for hours or even days while the issue is triaged and resolved. Sanity testing prevents this bottleneck. By providing immediate feedback, it allows developers to quickly identify and fix their own regressions before they contaminate the main build. This rapid iteration capability accelerates the entire development lifecycle, enabling faster feature delivery and more frequent, reliable updates to customers. It saves valuable resources by avoiding the execution of extensive regression test suites on unstable builds.

Maintaining Reliability Across Diverse Flight Scenarios
While sanity testing doesn’t cover every operational scenario, it ensures that the fundamental building blocks of flight technology are consistently reliable. Whether a drone is destined for aerial photography, package delivery, or industrial inspection, its ability to navigate, stabilize, and avoid obstacles is universal. By confirming the “sanity” of these core systems after every change, manufacturers can assure a baseline level of performance that holds true across the diverse applications and dynamic environments in which drones operate. This foundational reliability is what allows for the safe exploration and expansion into more specialized and demanding flight scenarios.