
Safety, in the realm of flight technology, transcends the mere absence of accidents. It is a meticulously engineered state achieved through the proactive design, integration, and continuous refinement of systems and protocols aimed at minimizing risks, ensuring reliable operation, and safeguarding operators, equipment, property, and the public. This involves a multifaceted approach, embedding robustness, predictability, and resilience into every layer of flight control and execution. True flight safety is an ongoing commitment to mitigating potential hazards through technological innovation, rigorous testing, and adherence to best practices, ultimately enabling confident and responsible utilization of airborne systems.
Core Technological Pillars of Flight Safety
The robust safety profile of modern flight technology, particularly within unmanned aerial systems (UAS), is built upon several critical technological pillars. Each component contributes to a comprehensive safety net, designed to prevent failures, detect anomalies, and react intelligently to unforeseen circumstances. Understanding these foundational technologies provides clarity on what constitutes safety in a dynamic aerial environment.
Precision Navigation and Positioning
Accurate spatial awareness is paramount for safe flight. Without precise knowledge of its location, an aircraft cannot adhere to flight plans, avoid restricted airspace, or prevent collisions.
- Global Navigation Satellite Systems (GNSS): Systems like GPS, GLONASS, Galileo, and BeiDou are fundamental. By triangulating signals from multiple satellites, a flight controller can determine its position with remarkable accuracy. Example: Preventing a drone from inadvertently drifting into a designated no-fly zone, such as near an airport or sensitive government facility, by providing continuous, real-time positional data that allows the system to enforce geo-fencing restrictions. Should the drone approach a boundary, its navigation system can automatically apply brakes or initiate a controlled return, ensuring compliance and preventing potential security breaches or air traffic interference.
- Real-Time Kinematic (RTK) and Post-Processed Kinematic (PPK) Systems: These advanced GNSS techniques employ a ground-based reference station to correct satellite signal errors, achieving centimeter-level accuracy. Example: For high-precision industrial inspections, an RTK-enabled drone can follow an exact pre-programmed flight path around a complex structure like a wind turbine blade or a bridge pillar. This precision ensures consistent data capture without the risk of deviation that could lead to physical contact with the structure, thus preventing damage to both the asset and the drone, and guaranteeing the integrity of the inspection data.
- Visual Positioning Systems (VPS): In environments where GNSS signals are weak or unavailable (e.g., indoors or under heavy tree cover), VPS uses downward-facing cameras and optical flow sensors to track features on the ground. Example: When operating a drone inside a warehouse for inventory management, the absence of GPS makes indoor flight challenging. A VPS allows the drone to maintain a stable hover and precise movement by constantly comparing visual patterns on the floor, preventing it from drifting uncontrollably into shelving or machinery, thereby ensuring safe indoor navigation and data collection without human intervention.
Robust Stabilization and Control Systems
Maintaining stable flight and responsive control is essential for safety, especially when confronted with environmental disturbances or demanding maneuvers.
- Inertial Measurement Units (IMUs): Comprising accelerometers, gyroscopes, and magnetometers, IMUs continuously measure the drone’s orientation, angular velocity, and linear acceleration. Example: During flight in gusty wind conditions, the IMU detects sudden shifts in pitch, roll, and yaw. The flight controller then rapidly processes this data and sends corrective commands to the motors, enabling the drone to immediately counteract the wind’s force and maintain a level, stable flight path, preventing uncontrolled tilting or drifting that could lead to a loss of control or collision.
- Flight Controllers (FCs): Often considered the “brain” of the drone, the FC integrates data from all sensors (IMU, GNSS, barometer, etc.) and executes flight algorithms to control motor speeds via Electronic Speed Controllers (ESCs). Example: A flight controller executing a complex autonomous mission will manage hundreds of calculations per second to ensure the drone follows precise waypoints, maintains correct altitude, and performs necessary turns smoothly. This prevents jerky movements or sudden unintended accelerations that could destabilize the drone or cause it to deviate from its intended path, safeguarding both the mission and the aircraft.
- Electronic Speed Controllers (ESCs) and Motors: These components translate commands from the flight controller into precise rotational speeds for each propeller. Example: If one motor experiences a slight power fluctuation or propeller drag due to minor damage, the ESC and flight controller work in tandem to dynamically adjust the power output of the other motors. This compensation prevents the drone from tipping or spinning unexpectedly, maintaining balance and allowing for a controlled flight even with minor asymmetries in thrust, thus averting a potential crash.
Advanced Obstacle Avoidance and Detection
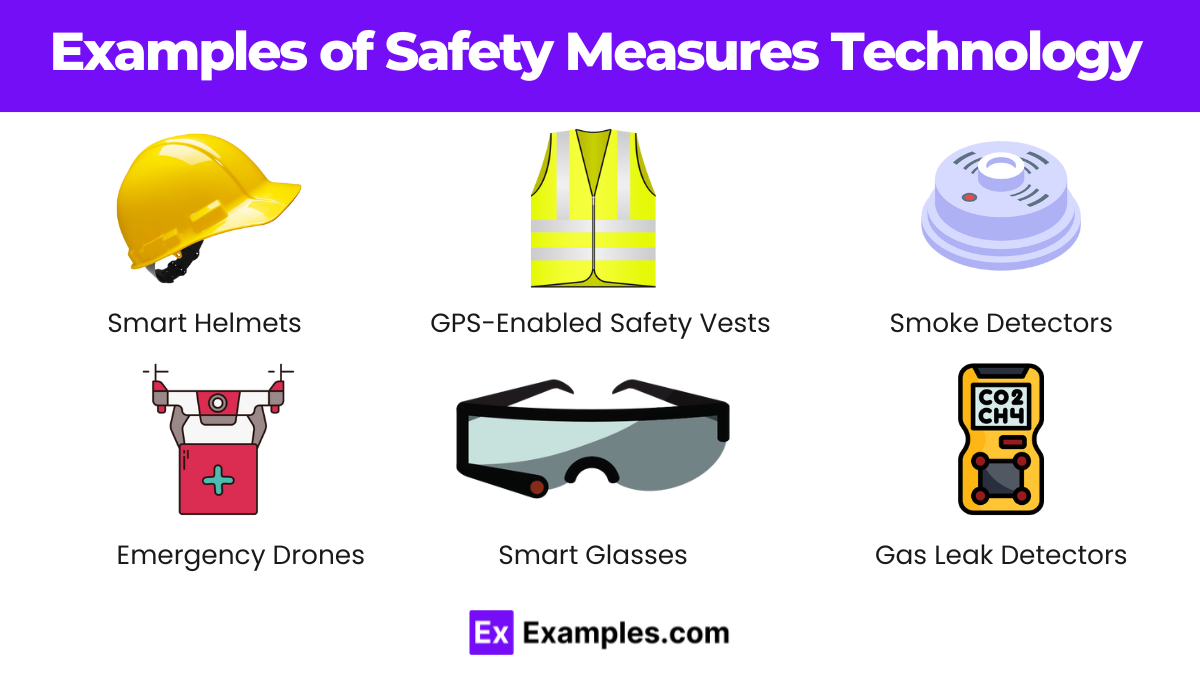
The ability to perceive and react to environmental hazards in real-time is a critical safety feature, moving beyond simple navigation to active collision prevention.
- Vision-Based Systems (Stereo and Monocular Cameras): These systems use advanced algorithms to process video feeds, construct 3D maps of the environment, and identify obstacles. Stereo cameras provide depth perception similar to human eyes. Example: During an autonomous inspection of a building façade, a vision-based system can detect an unexpected protruding antenna or an open window. Instead of colliding, the drone’s intelligent flight controller, informed by the vision system, can dynamically adjust its flight path to safely circumnavigate the obstacle, continuing its mission without interruption or damage.
- LiDAR (Light Detection and Ranging): LiDAR sensors emit laser pulses and measure the time it takes for them to return, creating highly accurate, dense 3D point clouds of the surrounding environment. Example: When flying in a complex, GPS-denied industrial environment with numerous pipes, machinery, and support structures, LiDAR can create a precise real-time map. This allows the drone to meticulously thread its way through tight spaces, automatically detecting and avoiding even thin wires or small protrusions that might be invisible to other sensors, ensuring safe operation in highly cluttered areas.
- Ultrasonic Sensors: These sensors emit sound waves and measure the echo, typically used for short-range distance sensing. Example: During an autonomous landing sequence, ultrasonic sensors mounted on the drone’s underside can accurately determine the exact distance to the ground. If an unexpected object or an uneven surface is detected directly below during the final descent, the system can pause the landing, adjust its position, or warn the pilot, preventing a hard landing or collision with ground obstacles.
Essential Failsafe and Redundancy Mechanisms
Even with advanced perception and control, unforeseen events can occur. Failsafe mechanisms and redundancy act as critical last lines of defense.
- Return-to-Home (RTH): A pre-programmed function that, when activated, guides the drone back to its takeoff point autonomously. Example: If a drone loses signal connectivity with its remote controller or experiences critically low battery levels during a mission over a large area, the RTH failsafe automatically initiates. The drone ascends to a safe altitude, navigates back along a pre-defined path to its home point, and performs a controlled landing, preventing a fly-away incident or an uncontrolled crash due to power depletion.
- Low Battery Warnings and Auto-Landing: Flight controllers constantly monitor battery voltage. As it approaches a critical threshold, warnings are issued, and an automatic landing sequence can be initiated. Example: During a long mapping mission, the flight system detects that the remaining battery life is insufficient to complete the mission and safely return. Instead of risking a power-off crash, the system alerts the pilot and, if unaddressed, autonomously initiates a controlled descent to the nearest safe landing spot, ensuring the drone’s recovery and preventing damage.
- Lost Signal Protocol: This defines the drone’s behavior when communication with the controller is lost. Options include hovering in place, initiating RTH, or immediately landing. Example: If a drone performing an agricultural survey flies beyond the controller’s range due to an unexpected signal interference, the lost signal protocol could be set to immediately hover. This prevents the drone from continuing on an uncontrolled trajectory, giving the pilot a chance to regain signal or the drone to initiate RTH if the signal isn’t restored within a set timeframe.
- Component Redundancy: Incorporating duplicate critical components to provide backup in case of failure. Example: Many professional drones feature dual IMUs or multiple GNSS modules. If the primary IMU experiences a hardware fault or generates erroneous data, the flight controller can seamlessly switch to the secondary IMU, ensuring uninterrupted, stable flight control and preventing the loss of the aircraft due to a single point of failure.
The Interplay of Technology and Operational Safety
While the technologies themselves are foundational, their true safety value is realized in how they integrate with operational procedures and regulatory compliance. Flight technology provides the tools, but operational safety ensures these tools are used effectively and responsibly.
- Regulatory Compliance through Geo-fencing: Modern flight technology integrates digital maps of restricted airspaces (e.g., airports, military zones, national parks). Example: A drone’s GPS and flight controller enforce geo-fencing limits, preventing the aircraft from even taking off or automatically stopping its flight if it approaches a designated no-fly zone, thereby upholding aviation regulations and preventing unauthorized incursions.
- Pre-flight System Diagnostics: Advanced flight controllers conduct comprehensive self-checks before takeoff. Example: Upon powering up, the drone’s system automatically runs diagnostics on all critical sensors (IMU calibration, GPS lock, battery health, motor response). If a compass error is detected or a motor fails to respond correctly, the system issues an explicit warning, preventing the pilot from initiating a flight with compromised hardware that could lead to an in-flight failure.
- Data Logging and Analysis: Flight controllers record extensive telemetry data, including GPS coordinates, altitude, speed, motor RPMs, and sensor readings. Example: After an incident where a drone behaved unexpectedly, reviewing the logged flight data can pinpoint the exact moment a sensor failed, a specific command was sent, or an environmental factor (like a sudden wind gust) influenced its behavior. This post-flight analysis is crucial for identifying root causes, implementing software updates, or adjusting operational protocols to prevent similar incidents in the future, thus continuously enhancing safety.

Future of Flight Safety Through Innovation
The horizon of flight safety is continually expanding through cutting-edge technological innovations, promising even more robust and intelligent systems for unmanned aerial operations.
- AI and Machine Learning for Predictive Maintenance: AI algorithms can analyze vast amounts of flight data, including motor vibration patterns, battery discharge cycles, and sensor performance metrics, to predict component failures before they occur. Example: An AI system monitoring a drone fleet could detect subtle anomalies in a motor’s operational signature, indicating impending bearing failure. It would then alert the maintenance team to schedule a proactive replacement, preventing an in-flight motor failure and ensuring consistent fleet readiness and safety.
- Swarm Intelligence and Collaborative Safety: As multiple drones operate simultaneously, swarm intelligence allows them to communicate and share real-time positional and environmental data, collectively enhancing safety. Example: In a large-scale agricultural spraying operation involving a dozen drones, each drone continuously transmits its position, speed, and detected obstacles to the others. If one drone detects an unexpected ground hazard or an incoming manned aircraft, it can alert the entire swarm, allowing all drones to collectively adjust their flight paths in a coordinated manner, preventing multi-drone collisions or conflicts with other airspace users.
- Unmanned Aircraft System Traffic Management (UTM) Integration: UTM systems are designed to manage low-altitude airspace for drones, much like air traffic control for manned aircraft. Integrating drone flight technology with UTM is key for large-scale, safe operations. Example: A delivery drone submitting its flight plan to a central UTM system might have its route dynamically altered by the system if it conflicts with a medical emergency helicopter’s flight path or another drone’s trajectory. This seamless, automated coordination prevents mid-air collisions in increasingly crowded low-altitude airspaces, ensuring the safety of all aerial vehicles and ground populations.