
Understanding Systemic Obstructions in Flight Technology
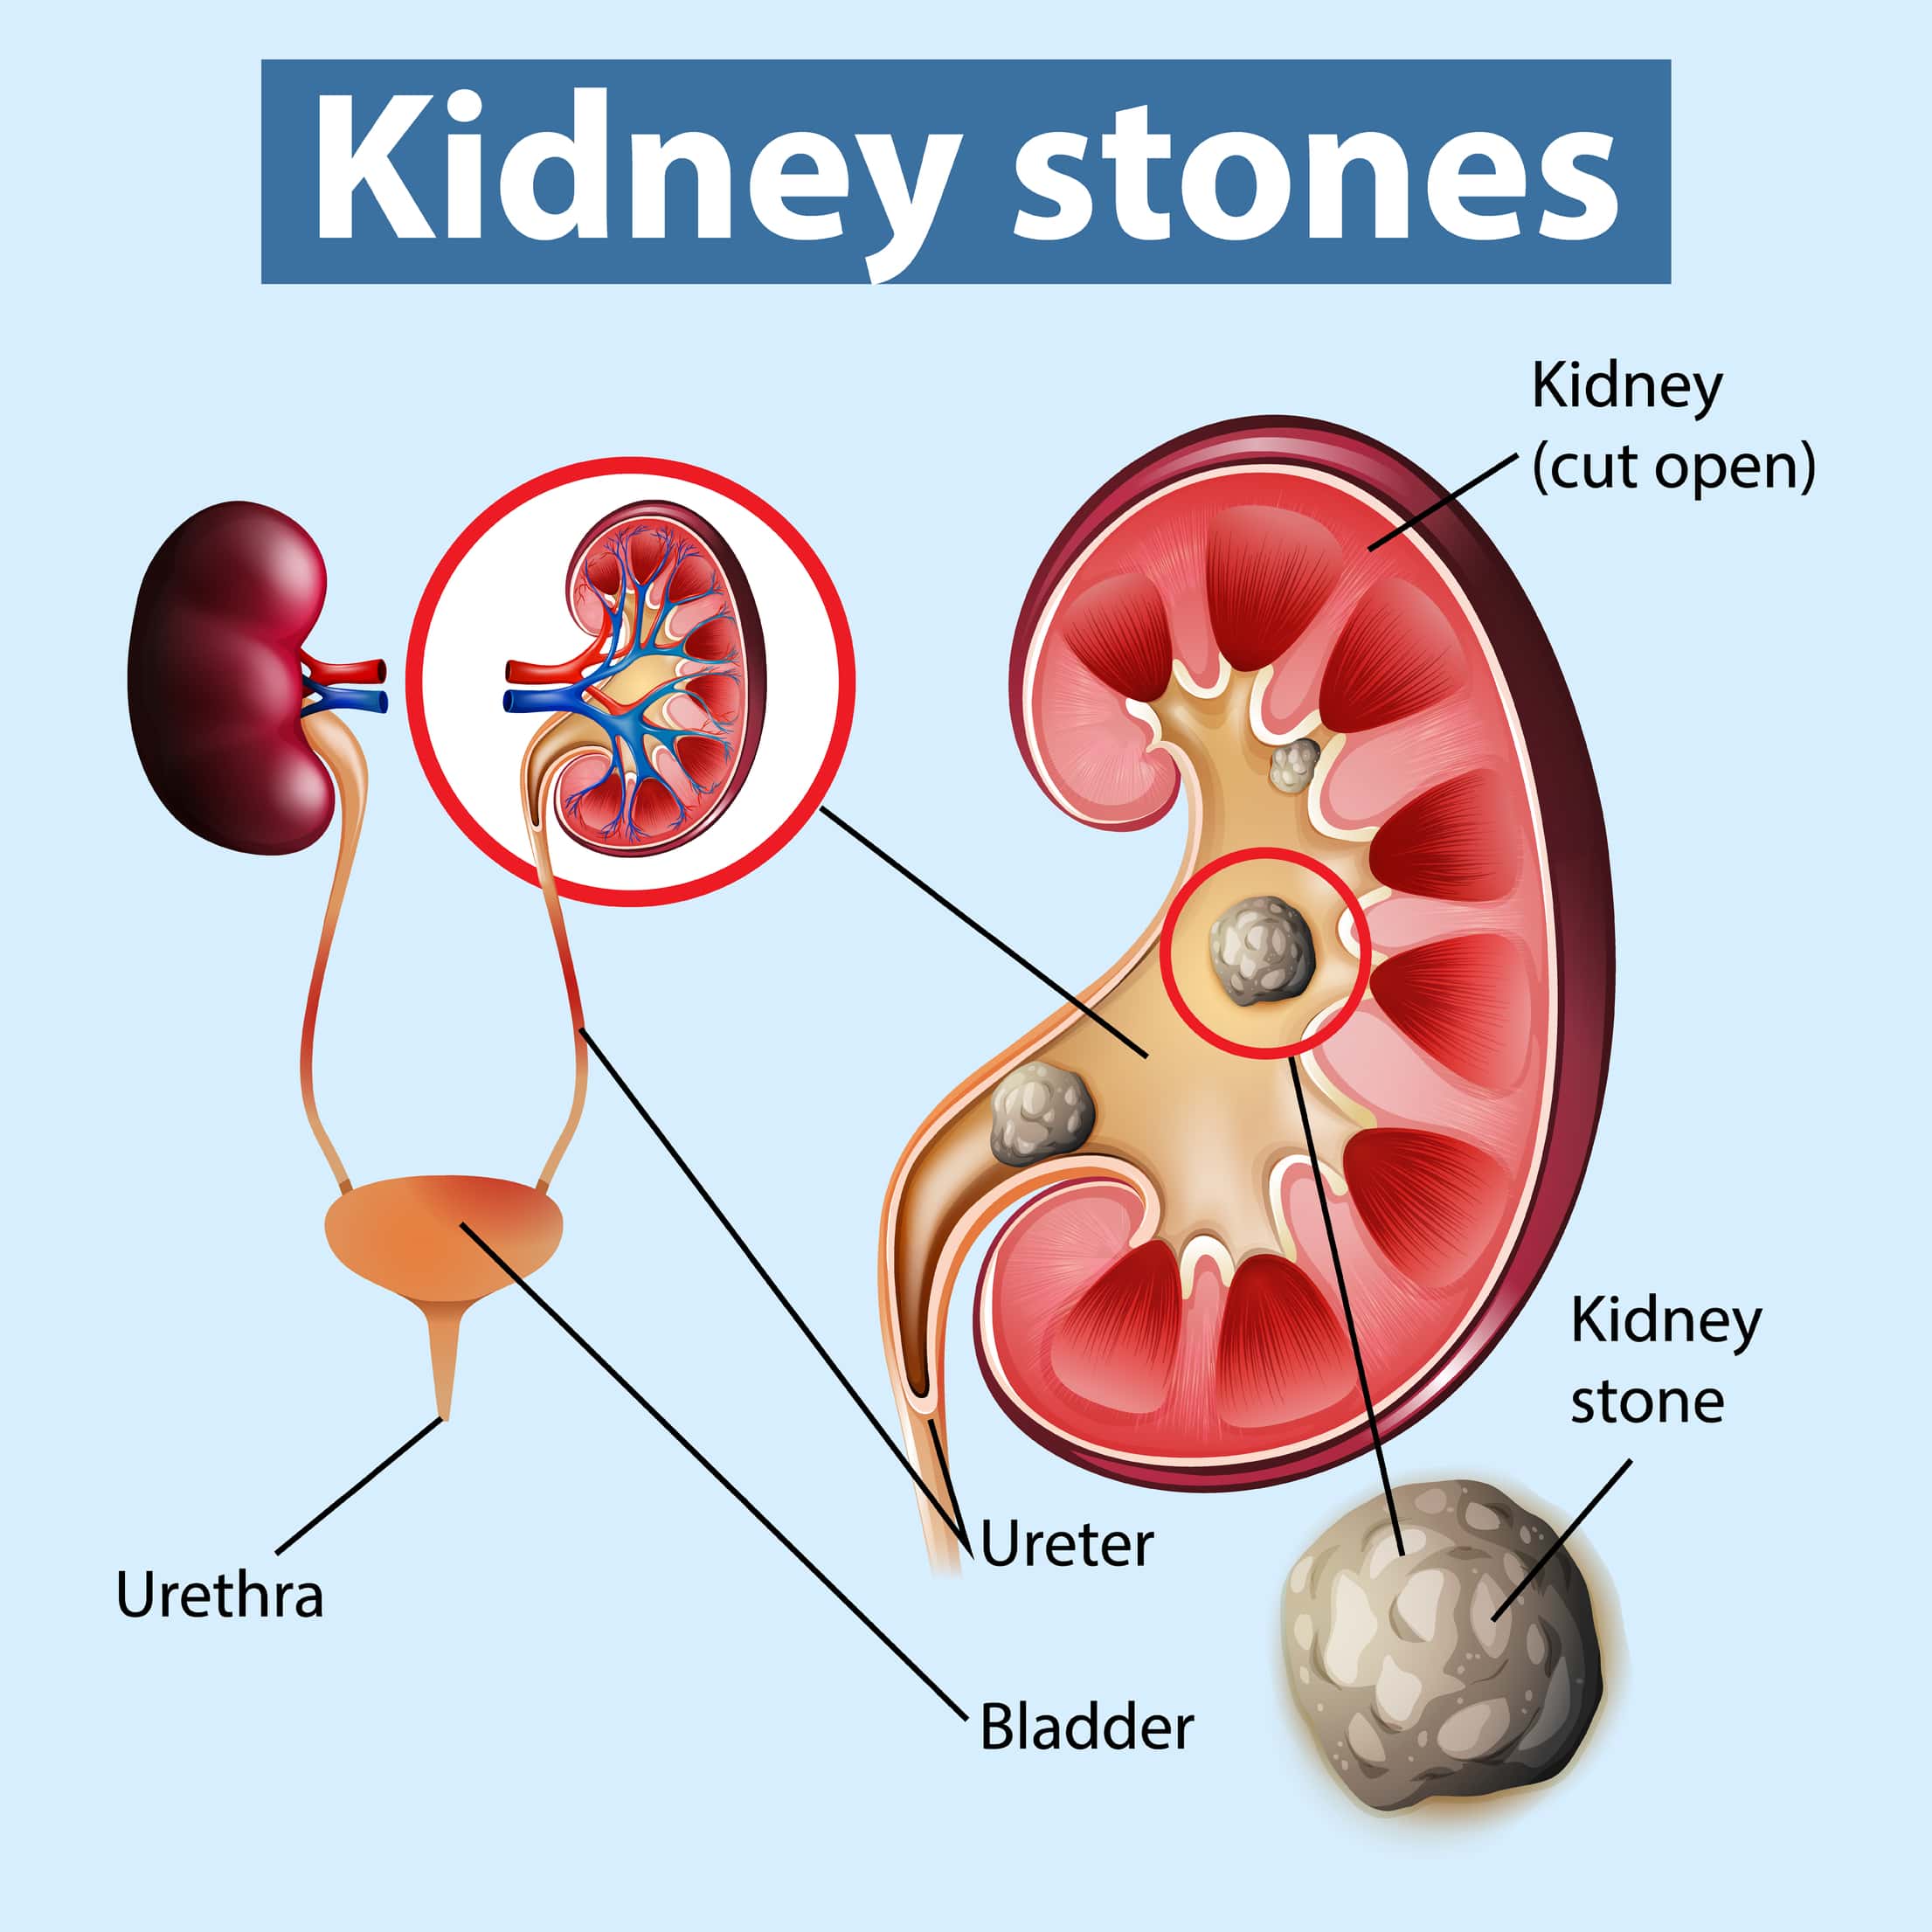
In the intricate world of advanced flight technology, particularly within the burgeoning domain of autonomous and remotely operated aerial systems, the concept of “renal calculi” offers a compelling, albeit metaphorical, analogy for critical systemic obstructions. While traditionally referring to kidney stones, these formations represent internal blockages that impede the natural function of a vital system. In the context of drones, UAVs, and other sophisticated aerial platforms, “renal calculi” can be understood as hidden, accumulating issues or fundamental flaws that, if left unaddressed, can severely compromise performance, stability, and ultimately, mission success. These can manifest as subtle hardware degradations, complex software bugs, or even environmental interferences that collectively form a ‘calculus’ impeding the smooth operation of the flight system.
The Analogy to Digital and Physical Blockages
The analogy is particularly apt because, much like their biological counterparts, these technical “calculi” are often hard to detect in their nascent stages. They may begin as minor anomalies – a slight drift in sensor calibration, an infrequent data packet loss, or a microscopic defect in a propeller blade. Over time, these seemingly insignificant issues can accumulate, solidify, and grow into substantial impediments. A digital “calculus” might be a recurring memory leak in a navigation algorithm that, over prolonged flight, culminates in a system crash. A physical “calculus” could be the gradual accumulation of dust and debris within sensitive gimbal mechanisms, leading to erratic camera movements or outright failure. These blockages prevent optimal data flow, disrupt control signals, or degrade mechanical efficiency, echoing the way a kidney stone obstructs the flow within the renal system. Understanding these parallels is crucial for developing robust, resilient flight technologies capable of sustained, reliable operation.
Impact on Navigation and Stability
The presence of such “calculi” can have profound implications for the core functions of flight technology: navigation and stability. Precise navigation relies on the seamless integration and processing of data from multiple sensors, including GPS, IMUs (Inertial Measurement Units), and altimeters. A “calculus” in any of these data streams – perhaps an intermittent GPS signal dropout due to electromagnetic interference, or an accumulating error in gyroscope readings – can lead to positional inaccuracies, unstable flight paths, and even complete loss of orientation. Similarly, stability, which is governed by complex control algorithms interpreting real-time sensor feedback to adjust motor speeds and wing surfaces, is highly susceptible to these internal obstructions. A delayed response from a flight controller dueled to a software “calculus” or a physical imbalance caused by a micro-fracture in a propeller (a mechanical “calculus”) can result in uncontrolled oscillations, loss of altitude, or catastrophic failure. The integrity of these foundational aspects of flight is paramount, making the early identification and mitigation of these ‘systemic calculi’ a critical engineering challenge.
Identifying ‘Calculi’ in Autonomous Systems
The challenge in modern flight technology lies not just in recognizing the existence of these “calculi,” but in developing sophisticated methods for their early and accurate identification within complex autonomous systems. Unlike traditional, human-piloted aircraft where a pilot can often detect subtle operational changes, autonomous drones rely entirely on their internal diagnostics and algorithmic processing. This necessitates advanced monitoring and analytical tools capable of discerning nascent issues before they escalate into critical failures.
Sensor Data Anomalies and Filtration
Sensors are the eyes and ears of any flight system, providing the vast streams of data necessary for perception, navigation, and control. “Calculi” can manifest as subtle but persistent anomalies within this data. This might include an uncharacteristic spike in temperature readings from a motor, minor but consistent deviations in GPS coordinates, or unusual noise patterns in accelerometer data. Identifying these requires intelligent data filtration and anomaly detection algorithms that can distinguish genuine problems from expected variations or environmental noise. Techniques such as Kalman filtering, Bayesian inference, and machine learning models trained on vast datasets of healthy flight patterns are employed to detect deviations that signify an emerging ‘calculus’. The goal is to filter out the noise while flagging the specific, consistent patterns that indicate a growing internal obstruction, whether it’s a failing component or a data processing bottleneck.
Algorithmic Bottlenecks and Latency
Another common form of “calculus” in autonomous flight systems lies within the algorithms themselves, particularly in terms of processing bottlenecks and latency. As drones become more sophisticated, processing vast amounts of sensor data in real-time for tasks like obstacle avoidance, object recognition, and complex path planning, the computational load increases. If an algorithm is not optimally designed or if the onboard processing unit is overwhelmed, this can lead to delays (latency) in critical decision-making or command execution. These delays act as a “calculus,” slowing down the system’s responsiveness and potentially leading to errors in dynamic environments. Identifying these algorithmic “calculi” involves rigorous profiling of software performance, stress testing under peak loads, and using specialized tools to visualize data flow and execution times. Optimizing code, leveraging parallel processing, and distributing computational tasks across multiple processors are common strategies to prevent these bottlenecks.
Hardware Degradation and Micro-failures
Beyond software and data, physical hardware degradation and micro-failures represent a tangible form of “calculi.” Components like motors, ESCs (Electronic Speed Controllers), batteries, and even the structural frame of a drone are subject to wear and tear. Over time, vibrations can loosen connections, temperature fluctuations can stress electronic components, and repeated use can lead to fatigue in materials. A barely perceptible crack in a motor mount, a slight reduction in battery capacity, or intermittent contact in a wiring harness can all act as a ‘calculus’, creating instability or intermittent system failures. Advanced diagnostic tools, including vibrational analysis, thermal imaging, and continuous current/voltage monitoring, are used to detect these subtle physical changes. The challenge is to identify these micro-failures before they propagate and lead to catastrophic hardware breakdowns, ensuring the longevity and reliability of the aerial platform.
Mitigation Strategies and Predictive Analytics
Addressing the pervasive threat of “calculi” in flight technology demands a proactive and multi-faceted approach, moving beyond reactive repairs to predictive intervention. This involves engineering resilient systems from the ground up and leveraging cutting-edge analytical capabilities to foresee and counteract potential obstructions.
Redundancy and Self-Healing Architectures
One of the most effective strategies for mitigating the impact of ‘systemic calculi’ is the implementation of redundancy and self-healing architectures. Redundancy involves duplicating critical components or systems, ensuring that if one fails (becomes ‘calcified’), a backup can immediately take over. This is common in high-reliability applications, where drones might feature redundant flight controllers, multiple GPS modules, or even an array of motors designed to compensate for the loss of one. Beyond simple backups, self-healing architectures incorporate intelligent systems capable of detecting a ‘calculus’ and autonomously reconfiguring the system to bypass or repair the issue. This could involve dynamically rerouting data through an alternative processing unit, isolating a malfunctioning sensor while relying on others, or adjusting control parameters to compensate for a degraded motor. Such designs enhance fault tolerance, allowing missions to continue even in the face of partial system failures, effectively dissolving or navigating around the ‘calculi’.
AI-driven Anomaly Detection and Proactive Maintenance
The advent of Artificial Intelligence and Machine Learning has revolutionized the ability to detect and predict the formation of ‘calculi’. AI-driven anomaly detection systems continuously monitor vast streams of flight data – including sensor readings, control inputs, motor performance, and environmental factors. By learning “normal” operational patterns, these AI models can identify subtle deviations that are indicative of an emerging ‘calculus’ long before human operators or traditional thresholds would flag them. For instance, an AI might detect a barely perceptible increase in motor vibration coupled with a slight rise in current draw, predicting a bearing failure several flight hours in advance. This capability enables proactive maintenance, where components are replaced or software patches are applied based on predictive analytics rather than catastrophic failure. This shifts the paradigm from reactive fixes to preventive measures, significantly enhancing safety, reliability, and operational efficiency by dissolving ‘calculi’ before they can fully form.
The Future of Resilient Flight Systems
The ongoing evolution of flight technology, particularly in autonomous and remotely piloted systems, is inextricably linked to the ability to design and maintain resilient platforms. As drones become more ubiquitous and their missions more critical – from package delivery and infrastructure inspection to complex surveillance and scientific research – the tolerance for systemic “calculi” diminishes significantly.
The future of resilient flight systems will be characterized by an even deeper integration of advanced diagnostics and proactive countermeasures. Expect to see widespread adoption of “digital twin” technology, where a virtual replica of each drone continuously mirrors its physical counterpart’s performance. This allows for real-time simulation and predictive modeling, enabling engineers to test mitigation strategies against hypothetical ‘calculi’ and optimize system responses without risk to physical assets. Furthermore, advancements in material science will yield self-healing composites and components that can autonomously repair minor damages, akin to how biological systems recover from injury. This organic approach to engineering will inherently resist the formation of certain physical ‘calculi’. On the software front, increasingly sophisticated AI will move beyond mere anomaly detection to predictive self-optimization, where algorithms dynamically adapt to prevent bottlenecks and maintain peak efficiency even as computational demands fluctuate. The goal is to create truly autonomous systems that are not just robust against failure but are inherently self-aware and adaptive, constantly working to prevent, dissolve, or navigate around any emerging ‘systemic calculi’, ensuring unwavering reliability and extending operational lifespans.