
In the rapidly evolving landscape of drone technology and innovation, the seamless integration of artificial intelligence (AI) is transforming everything from autonomous flight and sophisticated mapping to intelligent remote sensing and dynamic AI follow modes. At the heart of developing robust and reliable AI systems for these applications lies a critical concept known as regularization in machine learning. This technique is not merely an academic footnote; it is a fundamental safeguard that ensures the AI models powering our drones can perform reliably and accurately in the unpredictable real world, rather than just in controlled training environments.

The Imperative of Generalization in Drone AI
For any AI-powered drone system – be it for navigating complex urban environments, precisely identifying crop health from aerial imagery, or maintaining a stable lock on a moving subject – the ultimate goal is not just to learn from past data, but to apply that learning effectively to new, unseen situations. This ability to perform well on data it has not encountered during training is known as generalization. Without strong generalization capabilities, a drone’s AI might falter at critical moments, leading to navigation errors, misinterpretations of sensory data, or unreliable performance in dynamic operational scenarios.
Overfitting: The Enemy of Robust Autonomy
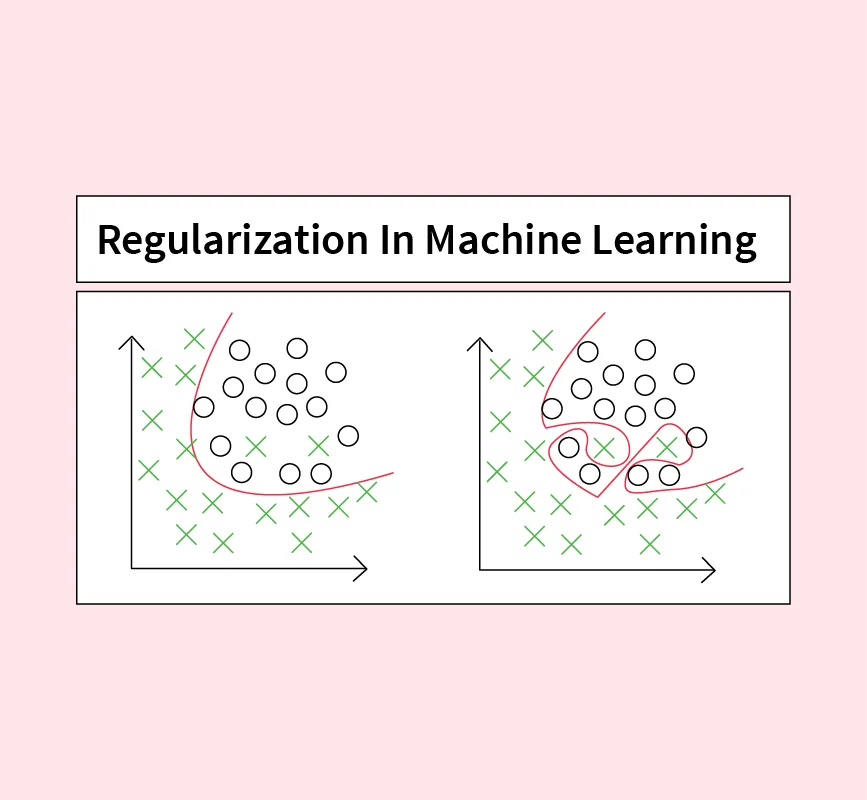
The primary challenge to generalization is a phenomenon called overfitting. Overfitting occurs when a machine learning model, particularly one with many parameters (like deep neural networks used in vision-based navigation or object detection), learns the training data too well. Instead of capturing the underlying patterns and relationships, it starts to memorize the noise, random fluctuations, and specific idiosyncrasies of the training examples. Imagine an autonomous drone trained solely on flight paths in perfectly sunny weather. An overfit model might perform flawlessly in those exact conditions but struggle or even fail to adapt to slight changes in wind, cloud cover, or partial shadows, because it has memorized the “sunny weather pattern” rather than the fundamental physics of flight and obstacle dynamics.
In the context of drone technology, overfitting can manifest in several dangerous ways:
- Obstacle Avoidance Systems: An overfit model might misclassify a common object (like a tree branch) as a non-obstacle if it hasn’t seen that exact angle or lighting during training, leading to collisions. Conversely, it might flag a harmless shadow as an obstacle, causing unnecessary diversions.
- AI Follow Mode: If an AI follow model overfits to a specific person’s clothing or movement style in the training data, it might lose track of the subject when they change clothes or move in an unfamiliar way, severely impacting its reliability.
- Remote Sensing: For agricultural or environmental monitoring, an overfit model might inaccurately classify plant species or identify anomalies if the spectral signature varies slightly due to environmental factors not perfectly represented in its training set.
The Core Principle of Regularization
Regularization is a suite of techniques designed to combat overfitting by discouraging overly complex models. It essentially introduces a penalty for complexity into the model’s training process. While the model is still striving to minimize errors on the training data, it is simultaneously penalized for having large or numerous parameters, or for being excessively sensitive to minor variations. This encourages the model to find simpler, more generalizable solutions, making it more robust and reliable when deployed in real-world drone applications. By balancing the fit to the training data with a preference for simplicity, regularization helps the model capture the essential signals rather than the noise, paving the way for trustworthy AI in aerial systems.
Key Regularization Techniques and Their Application in Aerial Tech
Various regularization techniques exist, each with a unique approach to constraining model complexity. Their judicious application is crucial for developing high-performing AI systems for drones.
L1 Regularization (Lasso) for Feature Selection
L1 regularization, also known as Lasso (Least Absolute Shrinkage and Selection Operator), adds a penalty proportional to the absolute value of the model’s coefficients (weights). A key characteristic of L1 regularization is its ability to drive some coefficients exactly to zero. This effectively performs feature selection, meaning it identifies and eliminates features that are not crucial for the model’s performance.
In drone AI, this can be incredibly beneficial:
- Sensor Fusion: Drones are equipped with numerous sensors (GPS, IMU, lidar, camera, ultrasonic). An L1 regularized model could help identify which sensor inputs are most critical for a specific task (e.g., precise hovering vs. high-speed navigation) and downplay or even ignore noisy or redundant sensor data, simplifying the model and reducing computational load on edge devices.
- Predictive Maintenance: When predicting component failure based on telemetry data, L1 regularization can pinpoint the most influential parameters (e.g., motor temperature, battery cell variance, vibration patterns) while disregarding less relevant data points, leading to more actionable insights and efficient onboard processing.
L2 Regularization (Ridge) for Weight Shrinkage
L2 regularization, or Ridge regression, adds a penalty proportional to the square of the magnitude of the coefficients. Unlike L1, L2 regularization tends to shrink coefficients towards zero but rarely makes them exactly zero. It spreads the “penalty” more evenly across all parameters, preventing any single parameter from becoming excessively large and thus overly sensitive to specific features in the training data.
This technique is vital for:
- Flight Control Systems: In deep learning models that optimize flight stability or fine-tune PID controllers, L2 regularization ensures that the weights applied to various sensor inputs (e.g., gyroscope, accelerometer data) remain balanced. An over-reliance on a single noisy sensor could lead to instability, which L2 helps mitigate by penalizing excessively large weights.
- Object Detection and Tracking: For autonomous navigation and target following, convolutional neural networks (CNNs) are employed. L2 regularization helps prevent individual filters in these networks from becoming overly specialized to detect very specific textures or patterns in the training images, ensuring they generalize well to variations in lighting, background, and object appearance in real-time drone footage.

Dropout for Neural Network Robustness
Dropout is a highly effective regularization technique specifically designed for neural networks. During training, dropout randomly “drops out” (sets to zero) a certain percentage of neurons in a layer, along with their connections. This is done temporarily for each training iteration. The effect is that each neuron becomes less reliant on specific other neurons, forcing it to learn more robust and independent features. It’s like training an ensemble of many different neural networks simultaneously.
Dropout significantly enhances generalization in deep learning applications for drones:
- Autonomous Navigation and Path Planning: Deep reinforcement learning agents that control drone movement can become overfit to specific sequences of observations. Dropout forces the network to learn more generalized strategies for navigating environments, making the drone more adaptable to new layouts or unexpected obstacles.
- Semantic Segmentation for Mapping: When drones generate high-resolution maps, semantic segmentation models classify every pixel (e.g., building, road, tree). Dropout helps these models produce more consistent and accurate classifications across varying aerial imagery, preventing “patchy” or inconsistent segmentation due to over-reliance on local, specific pixel patterns.
- Facial Recognition or Target Identification in AI Follow Mode: If a drone uses deep learning for identifying and tracking a specific person or object, dropout prevents the network from memorizing specific facial features or object textures. Instead, it learns broader, more resilient representations, allowing for robust tracking even with changes in pose, lighting, or partial occlusion.
Practical Implications for Advanced Drone Operations
The successful implementation of regularization techniques directly translates into more reliable, safer, and more capable drone systems across the “Tech & Innovation” spectrum.
Enhancing Autonomous Navigation and Obstacle Avoidance
Regularization is paramount for building highly dependable autonomous navigation systems. An unregulated model might be exceptionally accurate in a simulator or controlled test environment but fail dramatically when encountering novel variations in the real world. By employing regularization, AI models learn to extract the fundamental features defining obstacles and safe paths, rather than memorizing specific visual patterns. This means a drone can reliably distinguish between a real obstacle and a shadow, navigate through dense foliage it hasn’t specifically trained on, or respond appropriately to unexpected environmental changes like sudden gusts of wind or shifting light conditions, all while maintaining its flight path.
Improving Data Interpretation in Remote Sensing
Drones are invaluable tools for remote sensing, collecting vast amounts of data for agriculture, environmental monitoring, urban planning, and infrastructure inspection. Machine learning models process this data to identify patterns, classify objects, detect anomalies, and measure parameters. Regularization ensures that these models do not over-interpret the specific characteristics of the training datasets. For instance, an AI model classifying crop health based on multispectral imagery must generalize across different farms, soil types, and weather conditions. Regularization helps it learn universal indicators of health or stress, rather than simply memorizing the specific spectral signatures of healthy crops on one particular farm on a sunny day. This leads to more accurate and widely applicable insights, enhancing the utility of drone-based remote sensing.
Refining AI-Powered Flight Modes
Features like AI follow mode, gesture control, or intelligent cinematic flight paths rely heavily on robust machine learning. Regularization makes these modes more responsive, reliable, and user-friendly. An AI follow mode that leverages a regularized model will be less prone to losing its subject due to minor changes in appearance or movement. A gesture control system will correctly interpret commands even if the hand gestures are slightly different from the training examples. This leads to a smoother, more intuitive user experience, expanding the practical applications of consumer and professional drones alike.
Future Perspectives: Ensuring Reliable and Adaptable Aerial Intelligence
As drone technology continues to push the boundaries of autonomy and data intelligence, the role of regularization will only grow more critical. The increasing complexity of neural networks and the desire for drones to operate in increasingly dynamic and unpredictable environments necessitate even more sophisticated methods to prevent overfitting and ensure generalization.
Adapting to Unforeseen Environments
Future drone AI systems will need to exhibit even greater adaptability. For missions in disaster zones, search and rescue, or complex industrial inspections, drones will encounter situations never fully represented in training data. Regularization, combined with techniques like transfer learning and domain adaptation, will be essential for building models that can quickly and safely adapt to novel environments without extensive retraining, maintaining high performance under extreme variability.
Mitigating Bias and Improving Fairness
Regularization can also indirectly contribute to mitigating biases in AI systems. Overfitting to biased training data can amplify those biases, leading to discriminatory or unfair outcomes. By encouraging more generalized and less specialized models, regularization can help smooth out some of these biases, creating AI systems that are more equitable and reliable across diverse operational contexts and user groups.
In essence, regularization is more than just an optimization technique; it is a cornerstone of responsible AI development for drones. It is the silent guardian that ensures the powerful machine learning models driving our aerial innovations are not just intelligent, but also dependable, adaptable, and ultimately, trustworthy in the skies of tomorrow.