
In the rapidly evolving landscape of drone technology, where artificial intelligence, autonomous flight, and sophisticated data processing are becoming standard, the underlying computational hardware plays a pivotal role. Often, discussions revolve around powerful processors (CPUs/GPUs), advanced sensors, or innovative software algorithms. However, a critical yet frequently overlooked component influencing the responsiveness and overall capability of a drone’s onboard computer system is its Random Access Memory (RAM) timing. Understanding RAM timing is essential for appreciating how modern drones achieve their impressive feats of real-time perception, decision-making, and intelligent operation.
RAM serves as the short-term memory for a drone’s flight controller, mission computer, or embedded AI processing unit. It’s where data is temporarily stored for immediate access by the processor, enabling rapid execution of instructions and quick manipulation of information. Unlike long-term storage (like flash memory or SSDs), RAM is designed for speed, allowing the system to handle multiple tasks simultaneously and efficiently. RAM timing refers to a set of numerical values that dictate the latency and performance characteristics of these memory modules. These timings, typically expressed as a series of numbers (e.g., 16-18-18-38), represent the number of clock cycles required for various operations within the RAM itself.
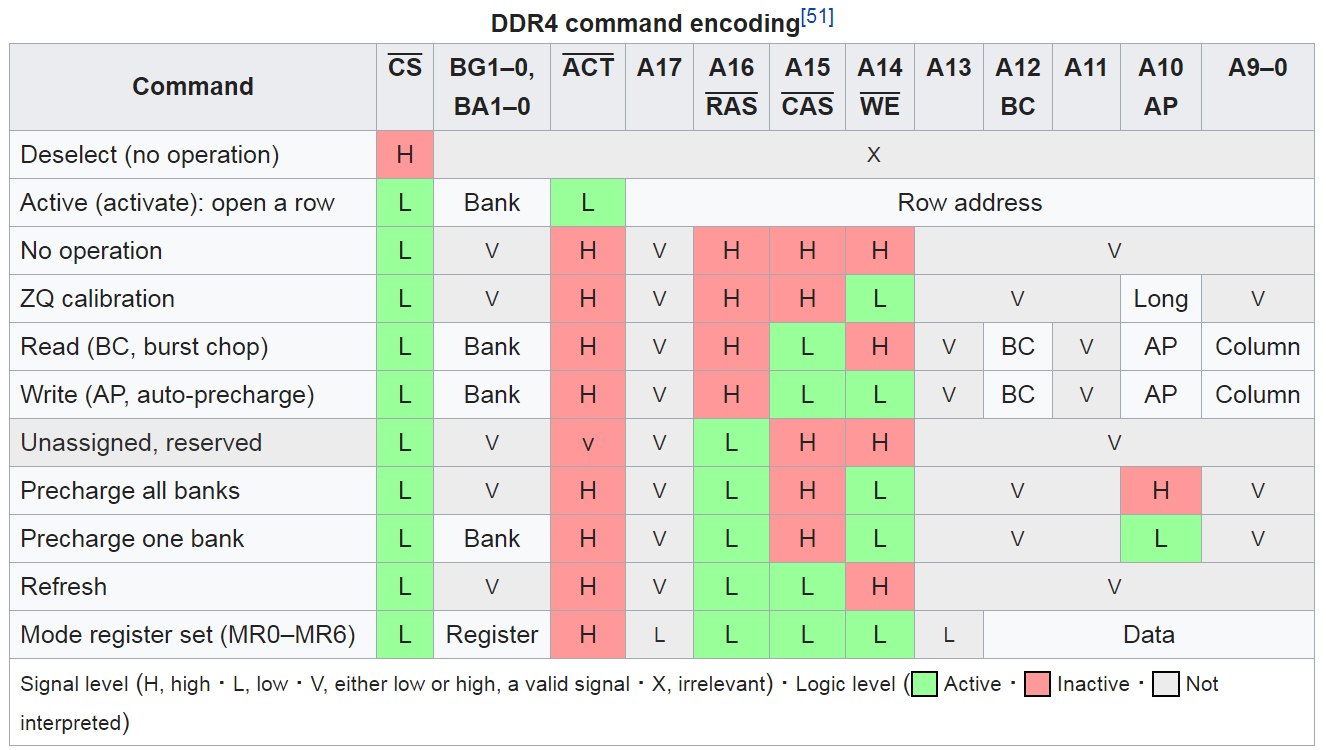
The Core Mechanics of RAM Timing in Drone Systems
At its heart, RAM timing quantifies the delays involved in accessing data from memory. While the clock speed (measured in MHz or GHz) indicates how many operations per second the RAM can theoretically perform, the timings dictate how quickly it can start and complete those operations once requested. A higher clock speed with loose (high number) timings might not always outperform a slightly lower clock speed with tight (low number) timings, especially in scenarios demanding immediate data access.
The most common RAM timing parameters include:
- CAS Latency (CL): This is arguably the most significant timing, representing the delay between the command being issued to the memory controller and the data becoming available. Lower CL means quicker access to data. For a drone constantly crunching sensor data or running AI models, a low CL can mean the difference between real-time obstacle avoidance and a delayed reaction.
- tRCD (Row-to-Column Delay): This specifies the number of clock cycles required to open a memory row and access a column within it. Memory is organized in rows and columns, and accessing specific data often requires opening both.
- tRP (Row Precharge Time): This is the time it takes to close one row of memory and open another. Efficient switching between rows is vital for multi-tasking and processing diverse data streams.
- tRAS (Row Active Time): This indicates the minimum time a row must remain open for writing or reading data before it can be closed. A balance here prevents premature closure, ensuring data integrity.
Collectively, these timings dictate the overall latency of the memory subsystem. In the context of drone technology, where computational resources are often constrained by size, weight, and power (SWaP) limitations, every millisecond of latency reduction can translate into significant performance gains for critical real-time functions. Drones often utilize low-power DDR (LPDDR) variants, which are optimized for energy efficiency, but still benefit immensely from carefully selected and optimized timings to balance power consumption with necessary performance.
Why RAM Timing Matters for Onboard Drone Intelligence
The advanced capabilities of modern drones, such as autonomous navigation, object recognition, and high-fidelity mapping, are not solely dependent on raw processing power. The speed at which data can be moved to and from the processor’s registers and cache, through RAM, is equally crucial. Poor RAM timing can bottleneck even the most powerful drone SoC, leading to performance degradation in demanding scenarios.
Real-time Sensor Data Processing
Drones gather vast amounts of data from an array of sensors: high-resolution cameras, LiDAR, radar, ultrasonic sensors, and Inertial Measurement Units (IMUs). For tasks like real-time obstacle avoidance or precise positional awareness, this data needs to be processed instantaneously. A drone’s flight controller and perception systems must rapidly ingest, filter, and interpret this raw sensor input to construct an accurate understanding of its environment. If the RAM timings are loose, delays in data access can lead to lags in processing, meaning the drone might react to an obstacle slightly later than ideal, potentially leading to a collision or an unstable flight path. Fast RAM ensures that the continuous stream of sensor data can be quickly moved to the processor for immediate analysis, enabling truly real-time decision-making.
AI and Machine Learning Execution
The proliferation of AI and machine learning in drones, particularly for features like AI Follow Mode, autonomous inspection, and intelligent anomaly detection, places immense demands on memory performance. AI models, especially deep neural networks, are data-intensive. When a drone runs an AI inference model onboard to identify objects, classify terrain, or predict trajectories, the model weights, input data (e.g., camera frames), and intermediate computations all reside in RAM.
Slower RAM timings translate directly into longer inference times. For a drone needing to identify a moving object and adjust its flight path within milliseconds, any delay can compromise accuracy and safety. Tighter RAM timings allow the processor to fetch model parameters and input data more quickly, accelerating the entire inference pipeline. This directly impacts the responsiveness of AI-powered features, making the difference between a fluid, intelligent maneuver and a hesitant, potentially dangerous reaction.

Autonomous Flight Algorithms
Sophisticated autonomous flight algorithms, encompassing path planning, dynamic obstacle avoidance, simultaneous localization and mapping (SLAM), and swarm coordination, involve complex computations and constant data exchange. These algorithms require frequent access to spatial maps, environmental models, control parameters, and predicted trajectories. Data about the drone’s own state (position, velocity, orientation) and its surroundings must be continuously updated and processed.
Each loop of these algorithms involves fetching data from RAM, performing calculations, and writing results back to RAM. If the RAM timings are slow, these cycles take longer, reducing the frequency at which the drone can update its understanding of the world and execute control commands. This can manifest as less precise navigation, choppier movements, or even a complete failure to adapt to rapidly changing conditions, undermining the very essence of autonomous flight.
Impact on Advanced Drone Applications
The influence of optimized RAM timing extends across various advanced drone applications, elevating their performance and reliability in critical operational contexts.
High-Fidelity Mapping and Remote Sensing
For applications like photogrammetry, Lidar scanning, and multispectral imaging for agriculture or construction, drones capture vast quantities of raw data. This data then needs to be processed to generate 2D maps, 3D models, or precise agricultural indices. While much of the intensive processing might occur post-flight on ground-based workstations, increasing amounts of preliminary processing, quality control, and even real-time mapping are being performed on the drone itself (edge computing). Efficient RAM timing on the drone allows for faster stitching of images, point cloud generation, and initial data validation, providing immediate feedback to operators and potentially reducing flight time by ensuring data quality on the fly. This accelerates the creation of accurate, actionable insights from aerial data.
AI Follow Mode and Object Tracking
“AI Follow Mode” is a prime example where RAM timing directly impacts user experience and functionality. For a drone to seamlessly follow a moving subject, it must continuously:
- Capture high-definition video frames.
- Process these frames in real-time using object detection and tracking AI models.
- Predict the subject’s future movement.
- Calculate and execute appropriate flight path adjustments.
All these steps are incredibly memory-intensive. The visual data, the AI model’s internal states, and the calculated trajectories all pass through RAM. Low CAS Latency and tight overall timings ensure that the drone can keep pace with fast-moving subjects, maintaining a smooth lock and preventing erratic behavior. Any lag due to slow RAM could result in the drone losing its target or exhibiting jerky, unresponsive movements, diminishing the utility and safety of the feature.
Edge Computing for Enhanced Autonomy
The trend towards edge computing in drones means more complex processing is performed directly onboard, reducing reliance on potentially latency-prone communication links to ground stations or cloud servers. This is crucial for applications in remote areas, for military/security operations, or where immediate decision-making is paramount. For a drone performing complex tasks like real-time structural inspection, disaster assessment, or coordinated swarm operations, the ability to process data, run AI models, and make intelligent decisions autonomously at the edge is transformative. Fast RAM timing facilitates this by ensuring that the drone’s embedded system can handle the increased computational load efficiently, enabling greater autonomy and resilience in challenging environments.

Optimizing RAM for Drone Performance
The selection and optimization of RAM in drone systems involve a careful balancing act between performance, power consumption, and cost – factors that are especially critical for battery-powered aerial platforms. While high clock speeds are often marketed, the practical performance boost derived from tighter RAM timings can be equally, if not more, significant for real-world drone operations.
Drone manufacturers and system integrators often opt for specific types of RAM, such as LPDDR4 or LPDDR5, which are designed for lower power consumption while still offering substantial bandwidth. Within these categories, meticulous attention is paid to selecting modules with the optimal balance of clock speed and timing parameters. Custom firmware and memory controller configurations are frequently employed within the System-on-Chips (SoCs) that power modern drones to fine-tune RAM access and minimize latency. This ensures that the entire memory subsystem is optimized for the specific demands of drone flight, sensor processing, and AI inference, rather than just raw theoretical throughput.
In conclusion, RAM timing is not merely a technical specification for computer enthusiasts; it is a fundamental aspect of computational performance that directly impacts the intelligence, responsiveness, and reliability of advanced drone systems. As drones continue to push the boundaries of autonomy and data processing at the edge, understanding and optimizing RAM timing will remain crucial for unlocking their full potential in an ever-expanding array of innovative applications.