
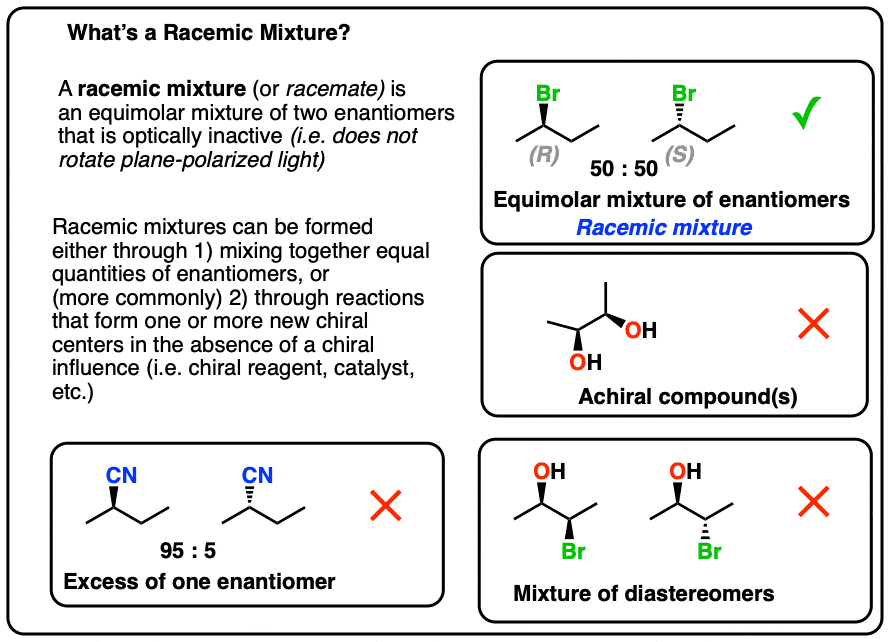
In the intricate world of flight technology, precision, stability, and equilibrium are paramount. While the term “racemic” originates from the field of chemistry, referring to a mixture containing equal amounts of enantiomers that results in a net-neutral effect, its conceptual essence—a state of perfect balance derived from symmetrical, often opposing, components—offers a compelling metaphor for the fundamental principles governing modern drone flight and its advanced systems. Far from a direct application of chemical compounds, understanding “what is racemic” in the context of flight technology means appreciating the sophisticated mechanisms that achieve and maintain dynamic neutrality, ensuring stable navigation, accurate sensing, and robust autonomous operation.
The Quest for Perfect Equilibrium in Drone Flight
At its core, drone flight is a continuous battle against imbalance. A multi-rotor drone, for instance, operates by meticulously balancing four fundamental forces: lift, thrust, drag, and gravity. To achieve a stable hover or precise movement, the drone’s flight controller must constantly make infinitesimal adjustments to motor speeds, precisely counteracting external disturbances and internal dynamics. This active, ongoing process of achieving and maintaining equilibrium is akin to a dynamic “racemic state,” where opposing forces and moments are continuously equalized, resulting in a net-neutral, stable outcome.
Every drone, from a small FPV racer to a large industrial UAV, relies on this intricate dance of forces. Without constant corrections, the drone would inevitably succumb to gravitational pull, wind gusts, or propeller torque imbalances. The “racemic” principle here underscores that true stability isn’t a static condition but an active, dynamic process of achieving neutrality through symmetrical counteractions.
Propulsive Symmetry and Stabilization Systems
Modern drones achieve their remarkable stability through an interplay of propulsive symmetry and sophisticated stabilization systems. In a quadcopter, four propellers generate lift, with two typically rotating clockwise and two counter-clockwise to cancel out rotational torque. For a drone to hover steadily, the sum of all upward thrust vectors must precisely equal the downward force of gravity, and all rotational forces must cancel each other out. This perfect cancellation of opposing torques and forces is a direct application of our “racemic” metaphor.
The flight controller, acting as the orchestrator of this balance, relies heavily on data from an Inertial Measurement Unit (IMU), comprising gyroscopes and accelerometers. Gyroscopes detect rotational rates, while accelerometers measure linear acceleration. When the drone experiences a tilt or drift, these sensors immediately report the deviation. The flight controller then calculates and applies precise, symmetrical adjustments to individual motor speeds, generating counter-forces that restore the drone to its desired attitude. This constant feedback loop of detection and counter-action perfectly embodies the “racemic” ideal: a system striving for a state where the sum of all dynamic inputs and outputs results in a perfectly neutral and stable flight condition, much like a chemical racemic mixture exhibits no net optical activity despite its chiral components.
Navigational Balance and Path Neutrality
Beyond maintaining a stable attitude, the concept of “racemic” equilibrium extends to a drone’s navigational capabilities. When a drone executes an autonomous flight path or maintains a GPS-locked position, it’s not merely holding still; it’s actively correcting for any deviation from its intended trajectory. External factors like wind shear, atmospheric pressure changes, or even minor GPS inaccuracies can push the drone off course.
Navigation algorithms within the flight controller continuously compare the drone’s current position (derived from GPS, barometer, and IMU data) with its desired position. Any discrepancy triggers corrective control inputs—propeller speed adjustments or slight changes in attitude—designed to generate opposing forces that gently guide the drone back onto its “neutral” path. This constant corrective action, where symmetrical forces are applied to counteract drift and maintain a specific, desired state of motion or position, is another manifestation of a dynamic “racemic” process in navigation. It’s about maintaining a neutral balance between deviation and correction, ensuring the drone adheres to its intended journey with unwavering precision.
Sensor Fusion: Achieving a Unified Perception from Diverse Inputs
Advanced drone flight relies on a tapestry of sensory information to build a comprehensive understanding of its environment and internal state. GPS for global positioning, IMUs for attitude and motion, barometers for altitude, and a suite of vision, LiDAR, and ultrasonic sensors for local awareness—each provides a unique perspective. However, these sensors can sometimes offer slightly discrepant or even “mirror-image” interpretations of reality, posing a significant challenge to the flight controller.
The process of sensor fusion is critical here. It’s the art and science of combining data from multiple, often diverse, sensor sources to create a more accurate, reliable, and comprehensive perception than any single sensor could provide. This integration process frequently involves balancing and weighing conflicting information, discerning the true state amidst a variety of inputs that, much like enantiomers, are distinct yet equally plausible in their initial presentation.
Redundancy and Mirror-Image Data Pathways
To enhance reliability and safety, many professional and industrial drones incorporate redundant sensor systems. For example, some high-end UAVs feature dual IMUs or multiple GPS modules. These “mirror-image” redundant pathways continuously provide parallel streams of critical data. If one sensor begins to provide anomalous or suspect readings, the flight controller can switch to or prioritize data from the other.
The system’s intelligence lies in its ability to constantly compare and balance the outputs from these redundant pathways. It evaluates the consistency between them, ensuring that no single “enantiomer” of data—one potentially erroneous reading—dominates the drone’s perception. This active balancing and cross-verification create a robust, “racemic” operational state, where the integrity of the flight system is maintained by the symmetrical availability and processing of critical information, allowing for graceful degradation or seamless failover in the event of component issues.
Obstacle Avoidance and Symmetrical Threat Assessment
In obstacle avoidance, drones employ a range of sensors—stereo vision cameras, LiDAR, ultrasonic sensors—to detect objects in their flight path. These sensors generate spatial data that often presents a symmetrical view of the environment. For instance, a large object directly ahead might appear equidistant from the drone’s left and right stereo cameras.
The drone’s autonomous navigation system must process this potentially symmetrical threat data to identify the safest, most “neutral” path to maneuver around the obstacle. This involves intricate algorithms that weigh the potential risks and clear corridors on all sides, effectively balancing the avoidance trajectory. The decision-making process is a sophisticated form of “racemic” assessment, where the system evaluates symmetrical threats and opportunities, leading to a balanced and optimal avoidance strategy that neutralizes the risk of collision while maintaining the mission objective. It’s not about favoring one side over the other but finding the path where the sum of risks is minimized, leading to a state of safe neutrality.
The Future of “Racemic” Control in Autonomous Systems
As drone technology advances, the underlying principles of balanced, symmetrical, and neutral control become increasingly complex and vital, ushering in a new era of “racemic” control in autonomous systems.
Adaptive Control and Self-Correction
Future autonomous drones will exhibit even greater levels of adaptive control and self-correction. They will continually learn and adjust to dynamic environmental conditions—sudden wind gusts, unexpected changes in payload, or even minor component wear and tear. Their control algorithms will move beyond pre-programmed responses, actively recalibrating to find new “racemic” points of balance under these constantly shifting loads and variables. AI-driven predictive models will anticipate disturbances, allowing drones to pre-emptively balance forces and maintain stability, creating a truly dynamic and continuously optimized “racemic” equilibrium. This involves an ongoing process of sensing, analyzing, and applying symmetrical counteractions to maintain optimal performance in unpredictable scenarios.
Swarm Robotics and Coordinated Neutrality
The emergence of drone swarms represents another frontier for “racemic” control. In a swarm, individual drones must not only maintain their own internal “racemic” balance but also contribute to the overall “racemic”—coordinated and stable—movement of the collective. This involves complex inter-drone communication and collective decision-making, where each drone’s actions are often a symmetrical response to its neighbors’ movements and the swarm’s global objectives.
The challenge lies in balancing individual drone autonomy with the overarching goal of swarm cohesion and task completion. The “racemic” ideal here manifests in algorithms that ensure each drone’s contribution to the swarm’s movement is optimally balanced, creating a harmonious and efficient collective intelligence. The collective behavior achieves a “racemic” state where individual deviations are symmetrically compensated across the swarm, leading to a robust, fault-tolerant, and highly effective coordinated system. This represents a multi-layered application of the racemic principle, from the individual drone’s stability to the entire swarm’s synchronized, balanced operation.