
Decentralized Intelligence in Autonomous Systems
The concept of “parliamentary government,” traditionally understood as a political system defined by collective decision-making, representation, and adherence to established rules, offers a surprisingly insightful metaphor when exploring the cutting edge of autonomous flight and advanced AI systems. In the realm of drones, UAVs, and other intelligent machines, the evolution towards increasingly complex tasks necessitates sophisticated internal governance structures that move beyond simple hierarchical command-and-control. As individual robotic units gain more autonomy, the challenge shifts to how these entities can collaboratively and effectively make decisions, allocate resources, and adapt to dynamic environments without a single, centralized authority. This emerging paradigm often mirrors the distributed and representative nature of parliamentary systems, where individual agents or specialized modules contribute to a collective, emergent intelligence.
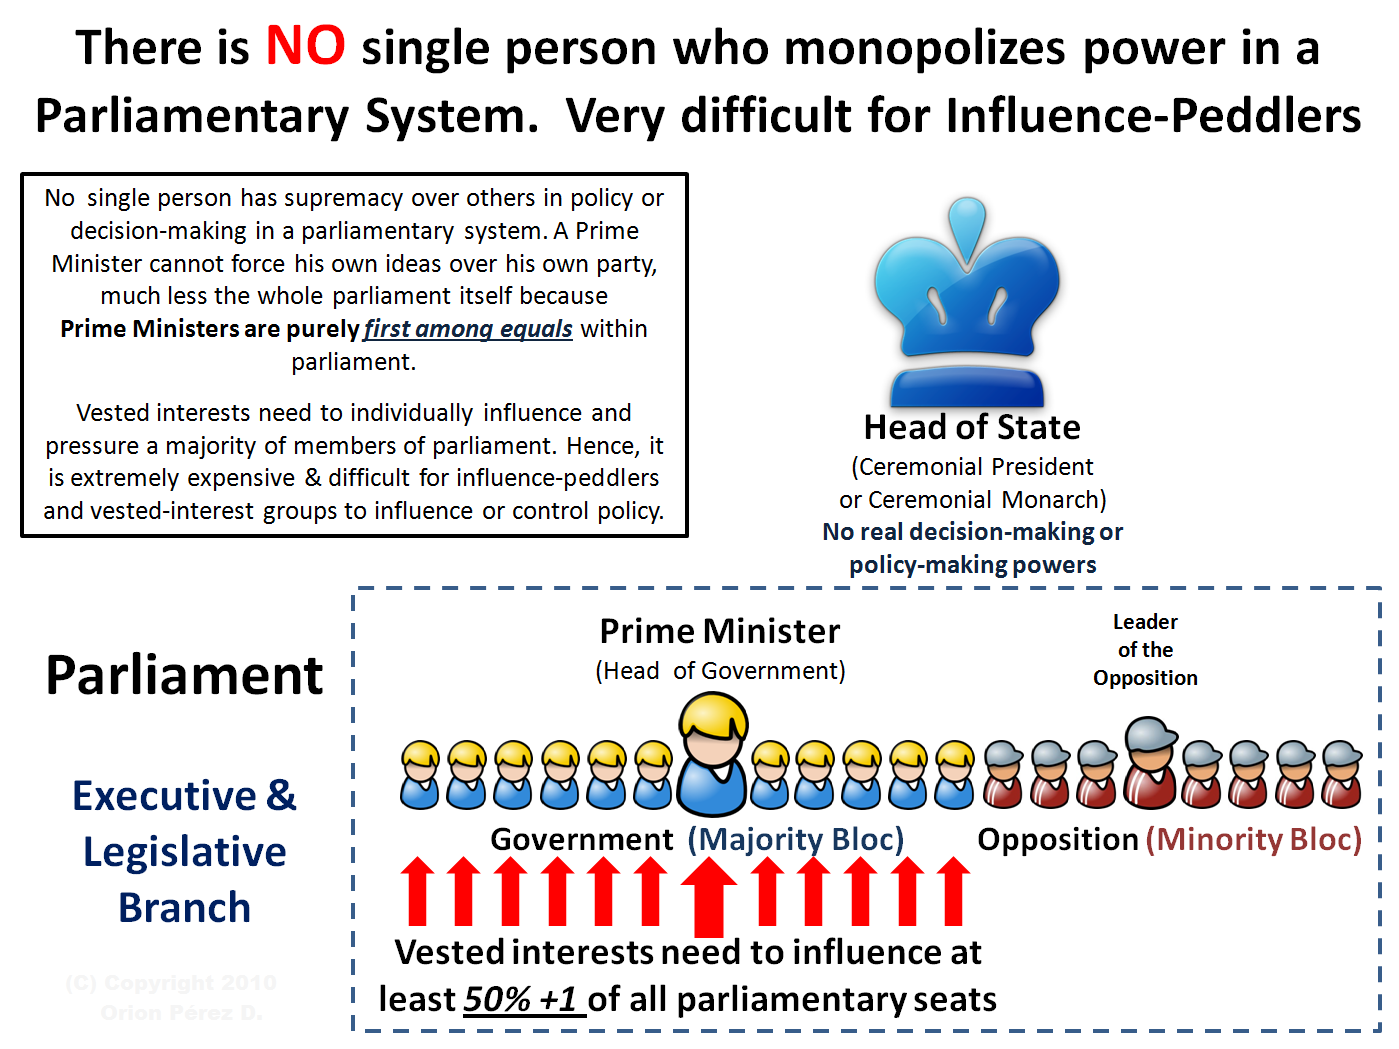
The traditional master-slave architecture, where a central unit dictates every action, becomes a bottleneck in highly dynamic and unpredictable scenarios. Consider a swarm of drones tasked with surveying a vast, complex disaster zone. A centralized approach would require immense computational power for a single entity to process all sensor data, plan every individual flight path, and manage every interaction. A decentralized, or “parliamentary,” approach allows each drone to act as an intelligent agent, processing local information, identifying opportunities or obstacles, and proposing actions. These proposals, much like legislative ideas, are then “voted upon” or reconciled through sophisticated consensus mechanisms embedded within the swarm’s collective AI. This distributed intelligence enhances robustness, as the failure of one “representative” (drone) does not cripple the entire “government” (swarm), much like a single legislator’s absence doesn’t halt a parliament.
The Analogy of a Distributed Legislature
Drawing further on the parliamentary analogy, each drone within a swarm or each module within a complex AI system can be viewed as a “legislator” or a “representative” of a specific function or data stream. For instance, in an autonomous surveillance drone, one AI module might specialize in optical recognition, another in thermal sensing, and a third in navigation and obstacle avoidance. Each of these modules “represents” its specific domain of expertise, feeding data and proposed actions into a central, yet distributed, decision-making framework. This framework acts as the “parliament,” where various “proposals” (e.g., “move left to avoid obstacle,” “focus camera on heat signature,” “adjust altitude for better view”) are weighed, debated (algorithmically, through preference functions and utility calculations), and ultimately integrated into a coherent collective action.
The key here is that no single module or drone holds absolute authority. Instead, decisions arise from a dynamic interplay of information, priorities, and pre-programmed rules. This mimics the checks and balances inherent in parliamentary systems, where different parties or committees hold sway over different aspects of governance, and decisions require broad-based support. In drone technology, this could translate into a system where, for instance, a navigation module’s urgent collision avoidance command might temporarily override a mapping module’s request for a specific, potentially unsafe, flight path. The “strength” of a vote or proposal can be weighted by factors such as urgency, mission criticality, or confidence levels in sensor data, creating a nuanced decision-making process far removed from simple majority rule and closer to a sophisticated form of coalition building.
Consensus Mechanisms in Swarm Robotics
The effective functioning of a “parliamentary” drone system heavily relies on robust consensus mechanisms. Unlike human parliaments that engage in verbal debate, drone swarms utilize sophisticated algorithms to achieve collective agreement. These mechanisms are critical for ensuring that decentralized decisions lead to cohesive and effective actions rather than chaotic individual movements. One common approach involves iterative information sharing and preference aggregation. Each drone, acting as an independent agent, might propose an optimal path or target based on its local sensor data and understanding of the overall mission. These proposals are then broadcast to nearby drones. Through a series of exchanges, drones update their internal states and adjust their proposals, converging towards a collective optimal solution.
This process can involve various techniques such as virtual “voting” systems, where drones assign confidence scores or weights to different options, or gradient descent methods where the collective aims to minimize a global cost function (e.g., minimizing flight time while avoiding obstacles). For example, if a swarm is tasked with identifying a specific object, individual drones might have varying degrees of certainty about its location. The “parliamentary” consensus mechanism would then aggregate these individual “votes” to guide the entire swarm towards the most probable location, adjusting its collective search pattern based on the evolving confidence levels across the network. The robustness of these consensus protocols ensures that even with noisy data or the temporary loss of some “parliamentary members,” the overall system can still reach a viable and effective decision, embodying the resilience sought in complex autonomous operations.
AI Governance and Ethical Frameworks
Extending the parliamentary metaphor, AI governance in advanced autonomous systems addresses how these systems not only make decisions but also ensure those decisions align with predetermined ethical guidelines, mission objectives, and human oversight. The “government” aspect implies a framework for establishing rules, prioritizing actions, and maintaining accountability within the AI itself. As drone technology moves towards truly autonomous flight and AI-driven missions, the need for these internal governance structures becomes paramount, especially when operating in complex or sensitive environments where ethical dilemmas and unforeseen circumstances can arise.
Consider a drone operating autonomously in a delivery or surveillance scenario. Its onboard AI must not only navigate efficiently but also adhere to privacy regulations, safety protocols, and operational boundaries. These constraints act as the “constitution” and “laws” of the AI system. A “parliamentary” approach to AI governance would involve distinct AI modules or agents, each responsible for different aspects of compliance and decision-making, engaging in a continuous internal “dialogue.” For example, an ethical compliance module might “veto” a highly efficient but privacy-invasive flight path proposed by a navigation module, forcing a renegotiation of the optimal route. This distributed responsibility ensures that no single algorithm or data point can unilaterally lead to a decision that violates core principles.
Multi-Agent Systems and Representative Decision-Making

Multi-agent systems inherently embody the spirit of representative decision-making. In these architectures, specialized AI agents, each with unique capabilities and objectives, cooperate to achieve a larger goal. One agent might be responsible for perception, another for path planning, a third for resource management, and a fourth for communication. Each agent acts as a “representative” of its functional domain, presenting its “arguments” or data-driven preferences to the collective. The overall system, acting as a “parliament,” must then synthesize these diverse inputs into a coherent action plan.
For example, an autonomous agricultural drone fleet might have agents focused on crop health analysis, soil moisture detection, and precise pesticide application. When an area of disease is detected, the crop health agent proposes immediate treatment. The pesticide application agent assesses the necessary dosage and trajectory, while the resource management agent checks on available payload. These agents “deliberate” – exchanging information and negotiating – to arrive at an optimized and ethical treatment plan, considering factors like wind speed, proximity to water sources, and the health of surrounding crops. This distributed approach ensures that decisions are robust, multi-faceted, and less prone to single points of failure or bias, much like a well-functioning legislative body balances diverse interests.
Adapting Legislative Principles for AI Autonomy
The principles underlying parliamentary governance – transparency, accountability, checks and balances – are equally crucial for building trustworthy AI systems. Transparency in AI governance refers to the ability to understand how autonomous systems arrive at their decisions. In a “parliamentary” AI, this means designing mechanisms to log the “deliberations” between agents, tracing how various inputs and module “votes” contributed to the final outcome. This audit trail is vital for debugging, performance analysis, and demonstrating compliance with regulations.
Accountability, another cornerstone, requires attributing decisions to specific modules or the collective framework, ensuring that when an error occurs, its source can be identified and rectified. This contrasts with black-box AI models where decision pathways are opaque. Checks and balances are integrated through architectural design, ensuring that no single agent or function can unilaterally make critical decisions without validation or consensus from others, especially concerning ethical boundaries or safety protocols. This “separation of powers” within the AI system prevents any one part from becoming an unchecked authority, fostering a more resilient and ethically aligned autonomous operation. Implementing these principles effectively moves AI autonomy beyond mere functionality towards responsible and justifiable decision-making, akin to how robust legislative processes aim to serve the broader public interest.
Towards Self-Governing Drone Networks
The ultimate vision for future autonomous systems, particularly in large-scale drone operations, is the creation of self-governing networks. These systems would not merely execute pre-programmed tasks but would possess the ability to adapt, learn, and make high-level strategic decisions in dynamic, complex environments, much like a government responding to evolving societal needs. This ambitious goal moves beyond individual drone autonomy to collective, emergent governance within an entire fleet or network of intelligent agents. Such self-governing drone networks could revolutionize fields from urban logistics and disaster response to environmental monitoring and infrastructure inspection, operating with minimal human intervention.
Imagine a fleet of delivery drones navigating a sprawling city. A self-governing network could dynamically re-route deliveries based on real-time traffic, weather, energy levels, and even public events, optimizing for speed, safety, and efficiency across the entire network. This would involve a “parliamentary” system where individual drones (or their onboard AI) report conditions, propose new routes, and collectively agree on the most efficient and compliant network-wide strategy. The “policies” and “laws” governing this network would be defined by overarching objectives (e.g., maximize deliveries, minimize energy consumption) and hard constraints (e.g., no-fly zones, privacy regulations). This collective intelligence would allow the system to self-organize and self-optimize in ways that are impossible for centrally controlled or individually operating drones.
Dynamic Resource Allocation and Policy Enforcement
In a self-governing drone network, dynamic resource allocation becomes a continuous “legislative process.” For instance, during a large-scale search and rescue mission, different areas might require varying concentrations of drones, or specific payloads (thermal cameras, comms relays). The network, acting as its own parliament, would dynamically allocate its “members” (drones) and “budget” (energy, specialized equipment) to areas of greatest need, based on real-time data from the ground. This involves continuous negotiation among individual drone agents, sharing their current status, capabilities, and local environmental data to collectively determine optimal deployment strategies.
Policy enforcement within such a network would be automated and embedded within the AI’s core programming. For example, if a specific drone deviates from a pre-defined no-fly zone, the network’s “policy enforcement agent” might automatically initiate corrective maneuvers, alert human operators, or even trigger a self-landing sequence. These policies are the “laws” of the drone parliament, ensuring that collective action remains within defined ethical and operational boundaries. The system would actively monitor itself, ensuring that individual autonomous actions contribute to the overall mission goals while adhering to safety and regulatory standards, much like a robust government enforces its laws to maintain order and achieve societal objectives.
Human Oversight and the ‘Constitutional’ Framework
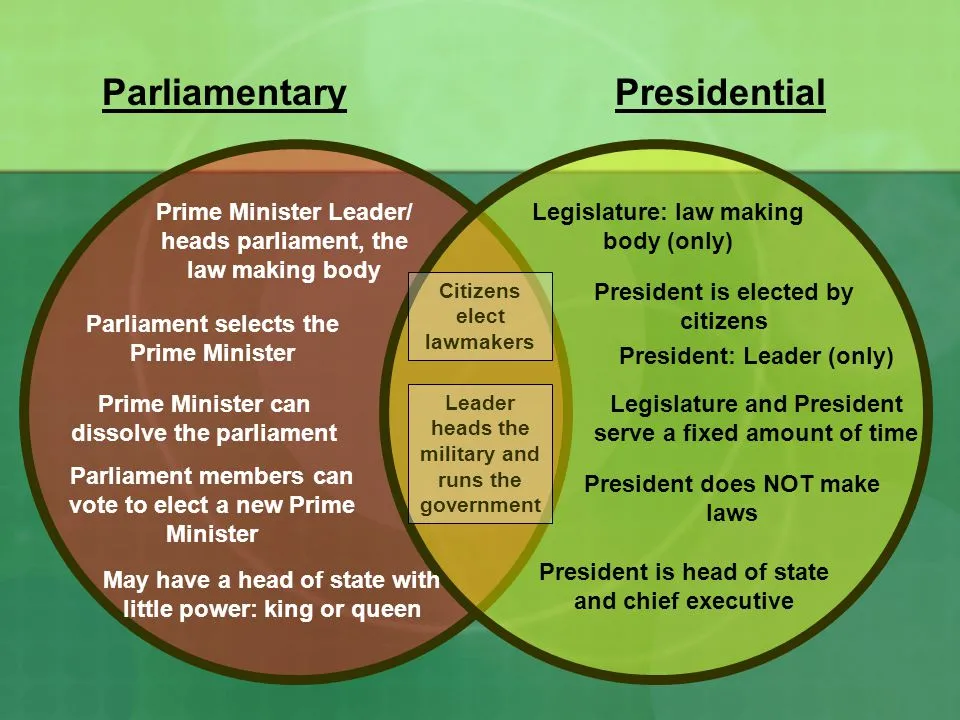
While the vision is of self-governing networks, human oversight remains a critical component, akin to how a citizenry oversees its government. In the context of drone technology, this “constitutional framework” sets the foundational principles, ethical limits, and high-level objectives that guide the AI’s “parliamentary” decision-making. Humans define the mission, establish the ethical “constitution,” and monitor the overall performance and adherence to these principles. They can step in to override decisions, update parameters, or intervene in unforeseen circumstances, acting as the ultimate authority or “electorate.”
The challenge lies in designing an intuitive and effective interface for this human-AI collaboration. This isn’t about micro-managing individual drones, but about providing high-level guidance and receiving actionable insights from the self-governing network. Humans would define the “laws” and “objectives” for the drone parliament, and the AI system would then be responsible for translating these into complex, decentralized actions. This partnership ensures that while autonomous systems can handle the intricate, real-time decision-making burden, human values, and strategic intent remain at the core of their operation, bridging the gap between advanced technology and responsible implementation in an increasingly complex world.