
In the dynamic realm of drone technology and innovation, machine learning (ML) plays a pivotal role, powering everything from autonomous navigation and AI follow modes to sophisticated remote sensing and mapping analytics. The promise of ML lies in its ability to enable drones to perceive, understand, and interact with complex environments. However, a common and critical challenge that developers encounter is “overfitting.” Understanding overfitting is not merely an academic exercise; it is fundamental to building robust, reliable, and safe AI systems for drone operations, where real-world performance is paramount.
Overfitting describes a scenario where an artificial intelligence model learns the training data too well, to the point of memorizing it, including its noise and idiosyncrasies. While this leads to excellent performance on the data it was trained on, the model fails to generalize effectively to new, unseen data. In the context of drone AI, this can manifest as an autonomous system that performs flawlessly in simulated environments or specific test areas but struggles dramatically when deployed in a slightly different real-world scenario.
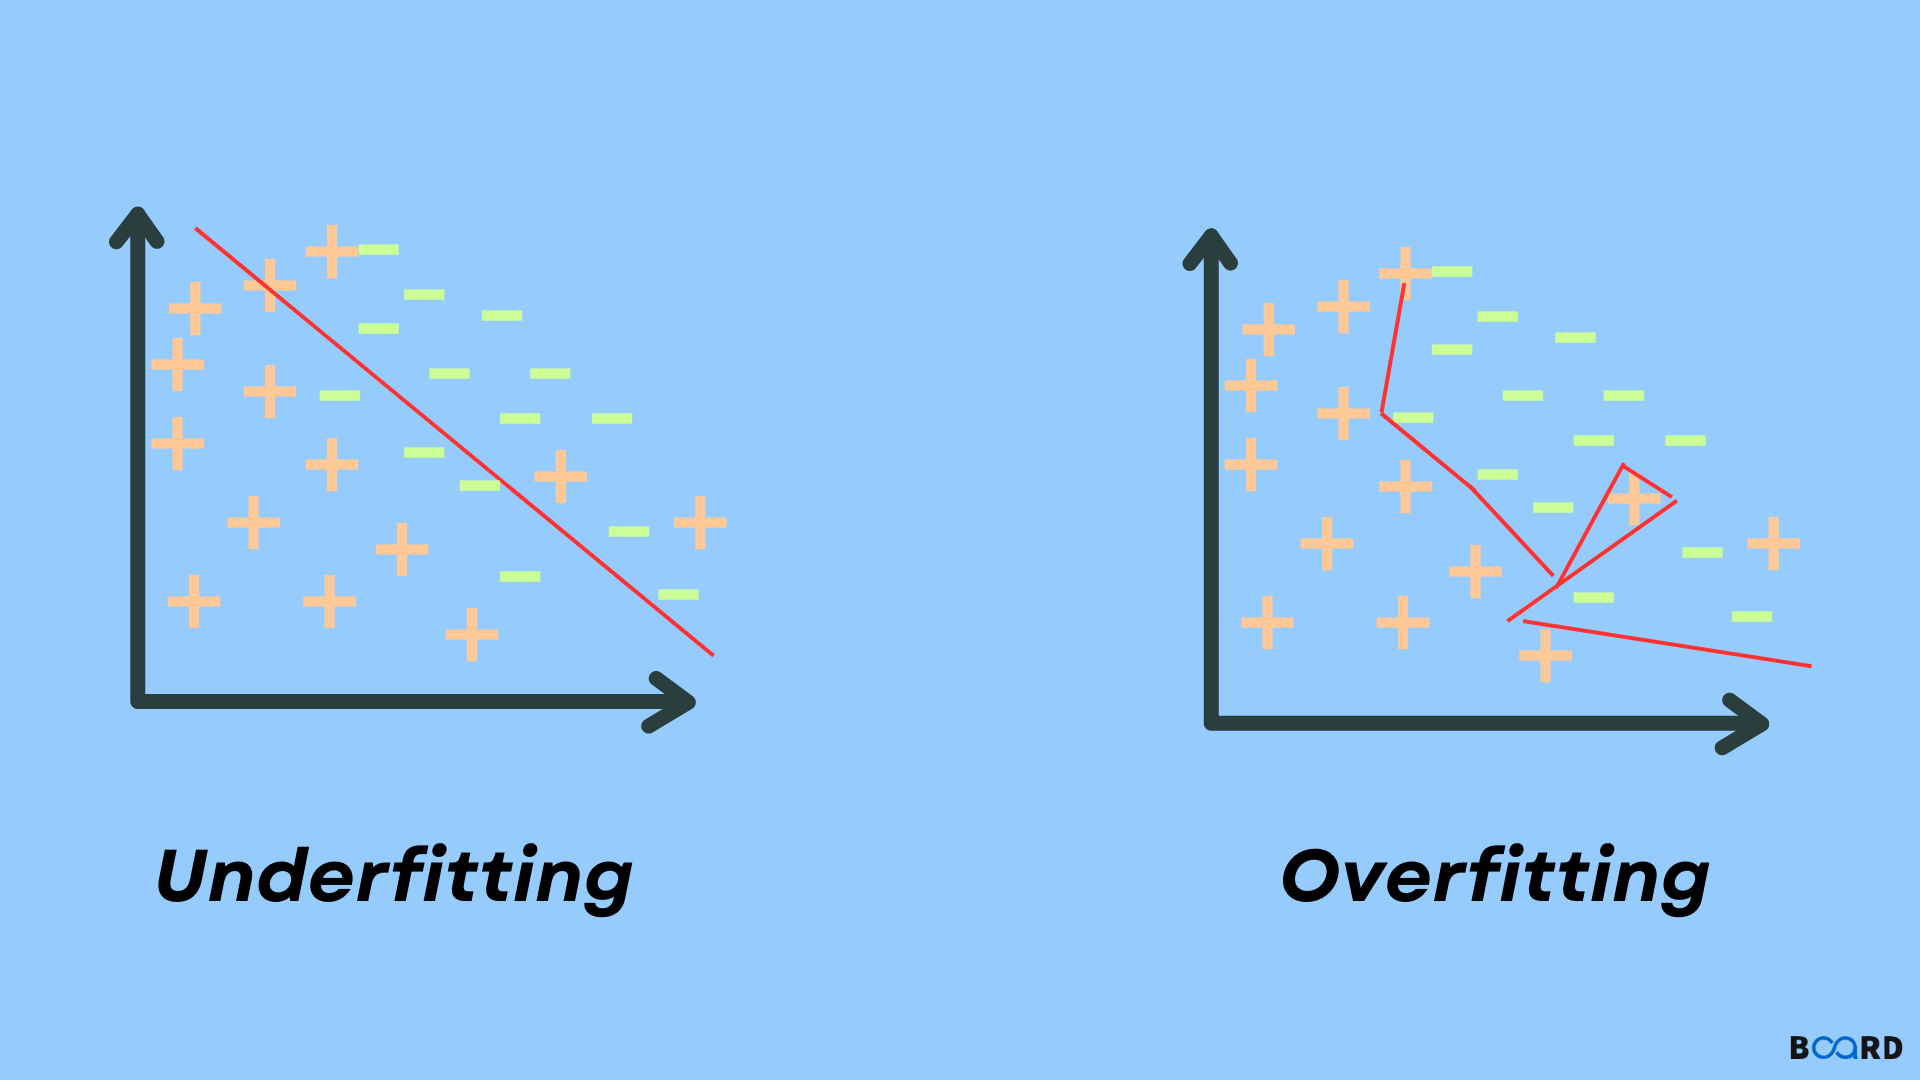
The Core Concept: Learning Too Well from Limited Data
At its heart, overfitting is a problem of generalization. Imagine a highly diligent student preparing for an exam. Instead of understanding the underlying principles and concepts, this student meticulously memorizes every question and answer from past papers. When faced with the exact same questions, they perform perfectly. However, if the exam introduces even slightly different questions or new problem variations, their performance plummets because they lack a true understanding of the subject matter.
Similarly, an overfit machine learning model for a drone application becomes hyper-tuned to the specific patterns, anomalies, and even random noise present in its training dataset. It learns to associate specific features of the training data with particular outcomes, rather than extracting the broader, more generalizable rules. For instance, if an AI obstacle avoidance system is trained exclusively on images of red spherical balloons in a brightly lit indoor environment, an overfit model might learn that “red, spherical, and brightly lit” are the definitive characteristics of an obstacle. Consequently, it could perfectly avoid red balloons but might entirely ignore a blue cube, a tree branch, or even a different type of red object in varying light conditions, leading to disastrous consequences during flight.
The issue stems from the model having too much capacity (being too complex) relative to the amount and diversity of the training data. With excessive capacity, the model essentially “memorizes” the training examples instead of discovering underlying patterns that hold true across various data points.
Manifestations of Overfitting in Drone AI Applications
The implications of overfitting stretch across various critical functionalities within advanced drone systems, potentially compromising safety, efficiency, and data integrity.
Autonomous Navigation & Obstacle Avoidance
Consider an autonomous drone designed for navigating complex industrial sites or dense urban environments. If its obstacle avoidance system is trained predominantly on data collected from a single type of environment – for example, only warehouses with specific shelving units and forklift patterns – an overfit model will exhibit superb performance within that familiar environment. However, when deployed to a construction site with dynamic elements like cranes, loose materials, and human movement, or to a different warehouse layout, the overfit model might fail to recognize novel obstacles or misinterpret safe paths, leading to collisions or inefficient flight paths. The model might have learned spurious correlations specific to the training site, such as “avoid anything that looks like a forklift from this angle,” rather than the general concept of “detect and avoid moving vehicles.”
AI Follow Mode & Object Tracking
AI follow mode is a popular feature where a drone autonomously tracks a moving subject, such as a person, vehicle, or animal. An overfit object tracking model might learn to associate a specific target not just with its general shape or motion, but also with highly particular, transient details from the training data. For instance, if trained solely on footage of a person wearing a bright yellow jacket against a green grassy field, the model might overfit to the combination of “yellow jacket” and “green background.” If the person changes their attire, moves into a different environment (e.g., a forest, a busy street), or if other people with similar characteristics appear, the overfit model could lose track of the subject, mistakenly switch targets, or fail to re-acquire the original target. This reduces the reliability and utility of such advanced creative and operational features.
Remote Sensing & Mapping Data Analysis
Drones equipped with specialized sensors are invaluable for remote sensing, capturing vast amounts of data for applications like agricultural monitoring, infrastructure inspection, and environmental surveying. Machine learning models are often employed to analyze this data, for example, to identify crop diseases, detect anomalies in power lines, or classify land use.
An overfit model for crop disease detection, trained exclusively on images of a specific disease stage from a particular type of crop in uniform lighting, might perform excellently on that exact dataset. Yet, when presented with images of the same disease at an earlier or later stage, on a different crop variety, or under varying weather conditions (e.g., cloudy versus sunny), it would likely fail. The model would have memorized visual cues unique to the training environment rather than learning the general pathological markers. Similarly, in infrastructure inspection, a model overfit to detecting cracks on concrete under direct sunlight might miss critical defects on a cloudy day or when the drone’s shadow obscures the surface.
Why Overfitting Occurs in Drone ML Models
Several factors contribute to the problem of overfitting, especially in the practical application of machine learning to complex, real-world drone operations.
Insufficient & Unrepresentative Training Data
This is arguably the most common cause. If the dataset used to train a drone’s AI model is too small or does not adequately represent the full spectrum of conditions and scenarios the drone will encounter in the real world, the model has little choice but to memorize the limited patterns it sees. For an autonomous delivery drone, training data consisting only of sunny-day flights over suburban areas would be highly unrepresentative if the drone is expected to navigate diverse urban environments, fly in varying weather conditions, or deal with seasonal changes. The model won’t learn to cope with rain, fog, strong winds, or dynamic city traffic.

Model Complexity
An overly complex model, such as a deep neural network with a vast number of layers and parameters, possesses a high capacity to learn intricate relationships. While this capacity is beneficial for extremely complex problems with abundant, diverse data, it becomes a liability with smaller or less varied datasets. With too many parameters relative to the number of training examples, the model can simply “connect the dots” between individual data points, effectively memorizing them rather than distilling general rules. It can fit the noise in the data instead of the underlying signal, creating a highly specific, non-generalizable mapping.
Noise in Training Data
Real-world data is inherently noisy. This noise can come from sensor inaccuracies, labeling errors in the dataset (e.g., an object mistakenly identified, or a boundary drawn incorrectly), or simply natural variations that are not true patterns. An overfit model, with its high capacity, will diligently learn to incorporate this noise as if it were meaningful information. For example, if a small percentage of images in an obstacle avoidance dataset have slight mislabelings where a safe path is marked as an obstacle (or vice-versa), an overfit model might learn these errors, leading to erroneous flight decisions in deployment.
Mitigating Overfitting for Robust Drone AI
Addressing overfitting is crucial for developing reliable and impactful drone AI. Various strategies are employed to encourage models to generalize better.
Data Augmentation & Diversity
The most direct approach is to provide the model with more and more varied data. For vision-based tasks (common in drones), data augmentation techniques are vital. This involves generating new training examples by applying transformations to existing images, such as rotations, flips, zooms, changes in brightness or contrast, and adding simulated noise or occlusions. This vastly increases the effective size and diversity of the dataset without needing to collect entirely new raw footage. Crucially, collecting real-world data from a wide range of environments, weather conditions, lighting scenarios, and operational contexts is indispensable. For autonomous flight, this means data from different terrains, times of day, seasons, and varying object types and densities.
Cross-Validation
Before deployment, models are rigorously evaluated. A standard technique is k-fold cross-validation, where the training data is split into multiple subsets. The model is trained and validated iteratively on different combinations of these subsets. This helps in assessing the model’s performance on unseen data and provides a more robust estimate of its generalization ability than a single train-test split. Monitoring performance on a separate validation set during training is key to detecting overfitting early.
Regularization Techniques
Regularization methods introduce penalties for model complexity, compelling the model to favor simpler solutions.
- L1 and L2 Regularization (Weight Decay): These techniques add a penalty term to the loss function that discourages large weights. By pushing weight values towards zero, they prevent the model from becoming overly reliant on specific features. In essence, they encourage the model to be less sensitive to individual data points.
- Dropout: A powerful technique for neural networks, dropout randomly “switches off” a percentage of neurons during each training iteration. This prevents neurons from co-adapting too much to each other and forces the network to learn more robust features that are useful even when parts of the network are missing. It acts like training an ensemble of many different smaller networks.
Early Stopping
This is a straightforward yet effective technique. During training, the model’s performance is monitored not only on the training data but also on a separate validation set. Typically, training loss continues to decrease, but after a certain point, the validation loss might start to increase, signaling that the model is beginning to overfit. Early stopping involves halting the training process at the point where validation performance starts to degrade, thereby capturing the model before it becomes overly specialized.
Simpler Models (When Appropriate)
While deep learning models are powerful, sometimes a simpler model architecture is sufficient for the task and less prone to overfitting, especially with limited data. Choosing a model complexity that aligns with the complexity of the problem and the size of the dataset can prevent the model from having too much capacity to simply memorize.
Transfer Learning
Transfer learning is highly beneficial in resource-constrained scenarios or when dealing with smaller datasets. It involves taking a pre-trained model (e.g., a large image classification network trained on millions of diverse images like ImageNet) and fine-tuning it on the specific, smaller drone-related dataset. The pre-trained model has already learned highly generalized features (like edge detection, texture recognition) from a vast amount of data. By fine-tuning, we adapt these general features to the specific drone application, requiring far less data to achieve good generalization and significantly reducing the risk of overfitting compared to training a complex model from scratch.

The Imperative for Generalization in Drone Tech
For drones, overfitting is not just an academic challenge; it’s a practical obstacle to achieving reliable, safe, and truly autonomous operations. A drone’s AI must be able to generalize its learned knowledge across a multitude of unpredictable real-world scenarios – from varying weather and lighting conditions to diverse terrains and dynamic obstacles. Overcoming overfitting ensures that AI follow modes remain steadfast, autonomous navigation systems are truly resilient, and remote sensing analytics provide consistently accurate and actionable insights. By diligently applying strategies to mitigate overfitting, innovators in drone technology can build AI systems that are not just intelligent but also dependable, paving the way for the next generation of aerial capabilities.