
In the dynamic and rapidly evolving landscape of drone technology, particularly within the realm of Tech & Innovation, the concept of an “operand” is far more fundamental than it might initially appear. It underpins virtually every intelligent function, autonomous capability, and data processing task that modern drones perform. From sophisticated AI-driven navigation to precise mapping and remote sensing, the ability to define, capture, and manipulate operands is the bedrock of drone intelligence. Understanding what an operand is, and how it functions within drone systems, is crucial for appreciating the computational depth behind these aerial innovations.
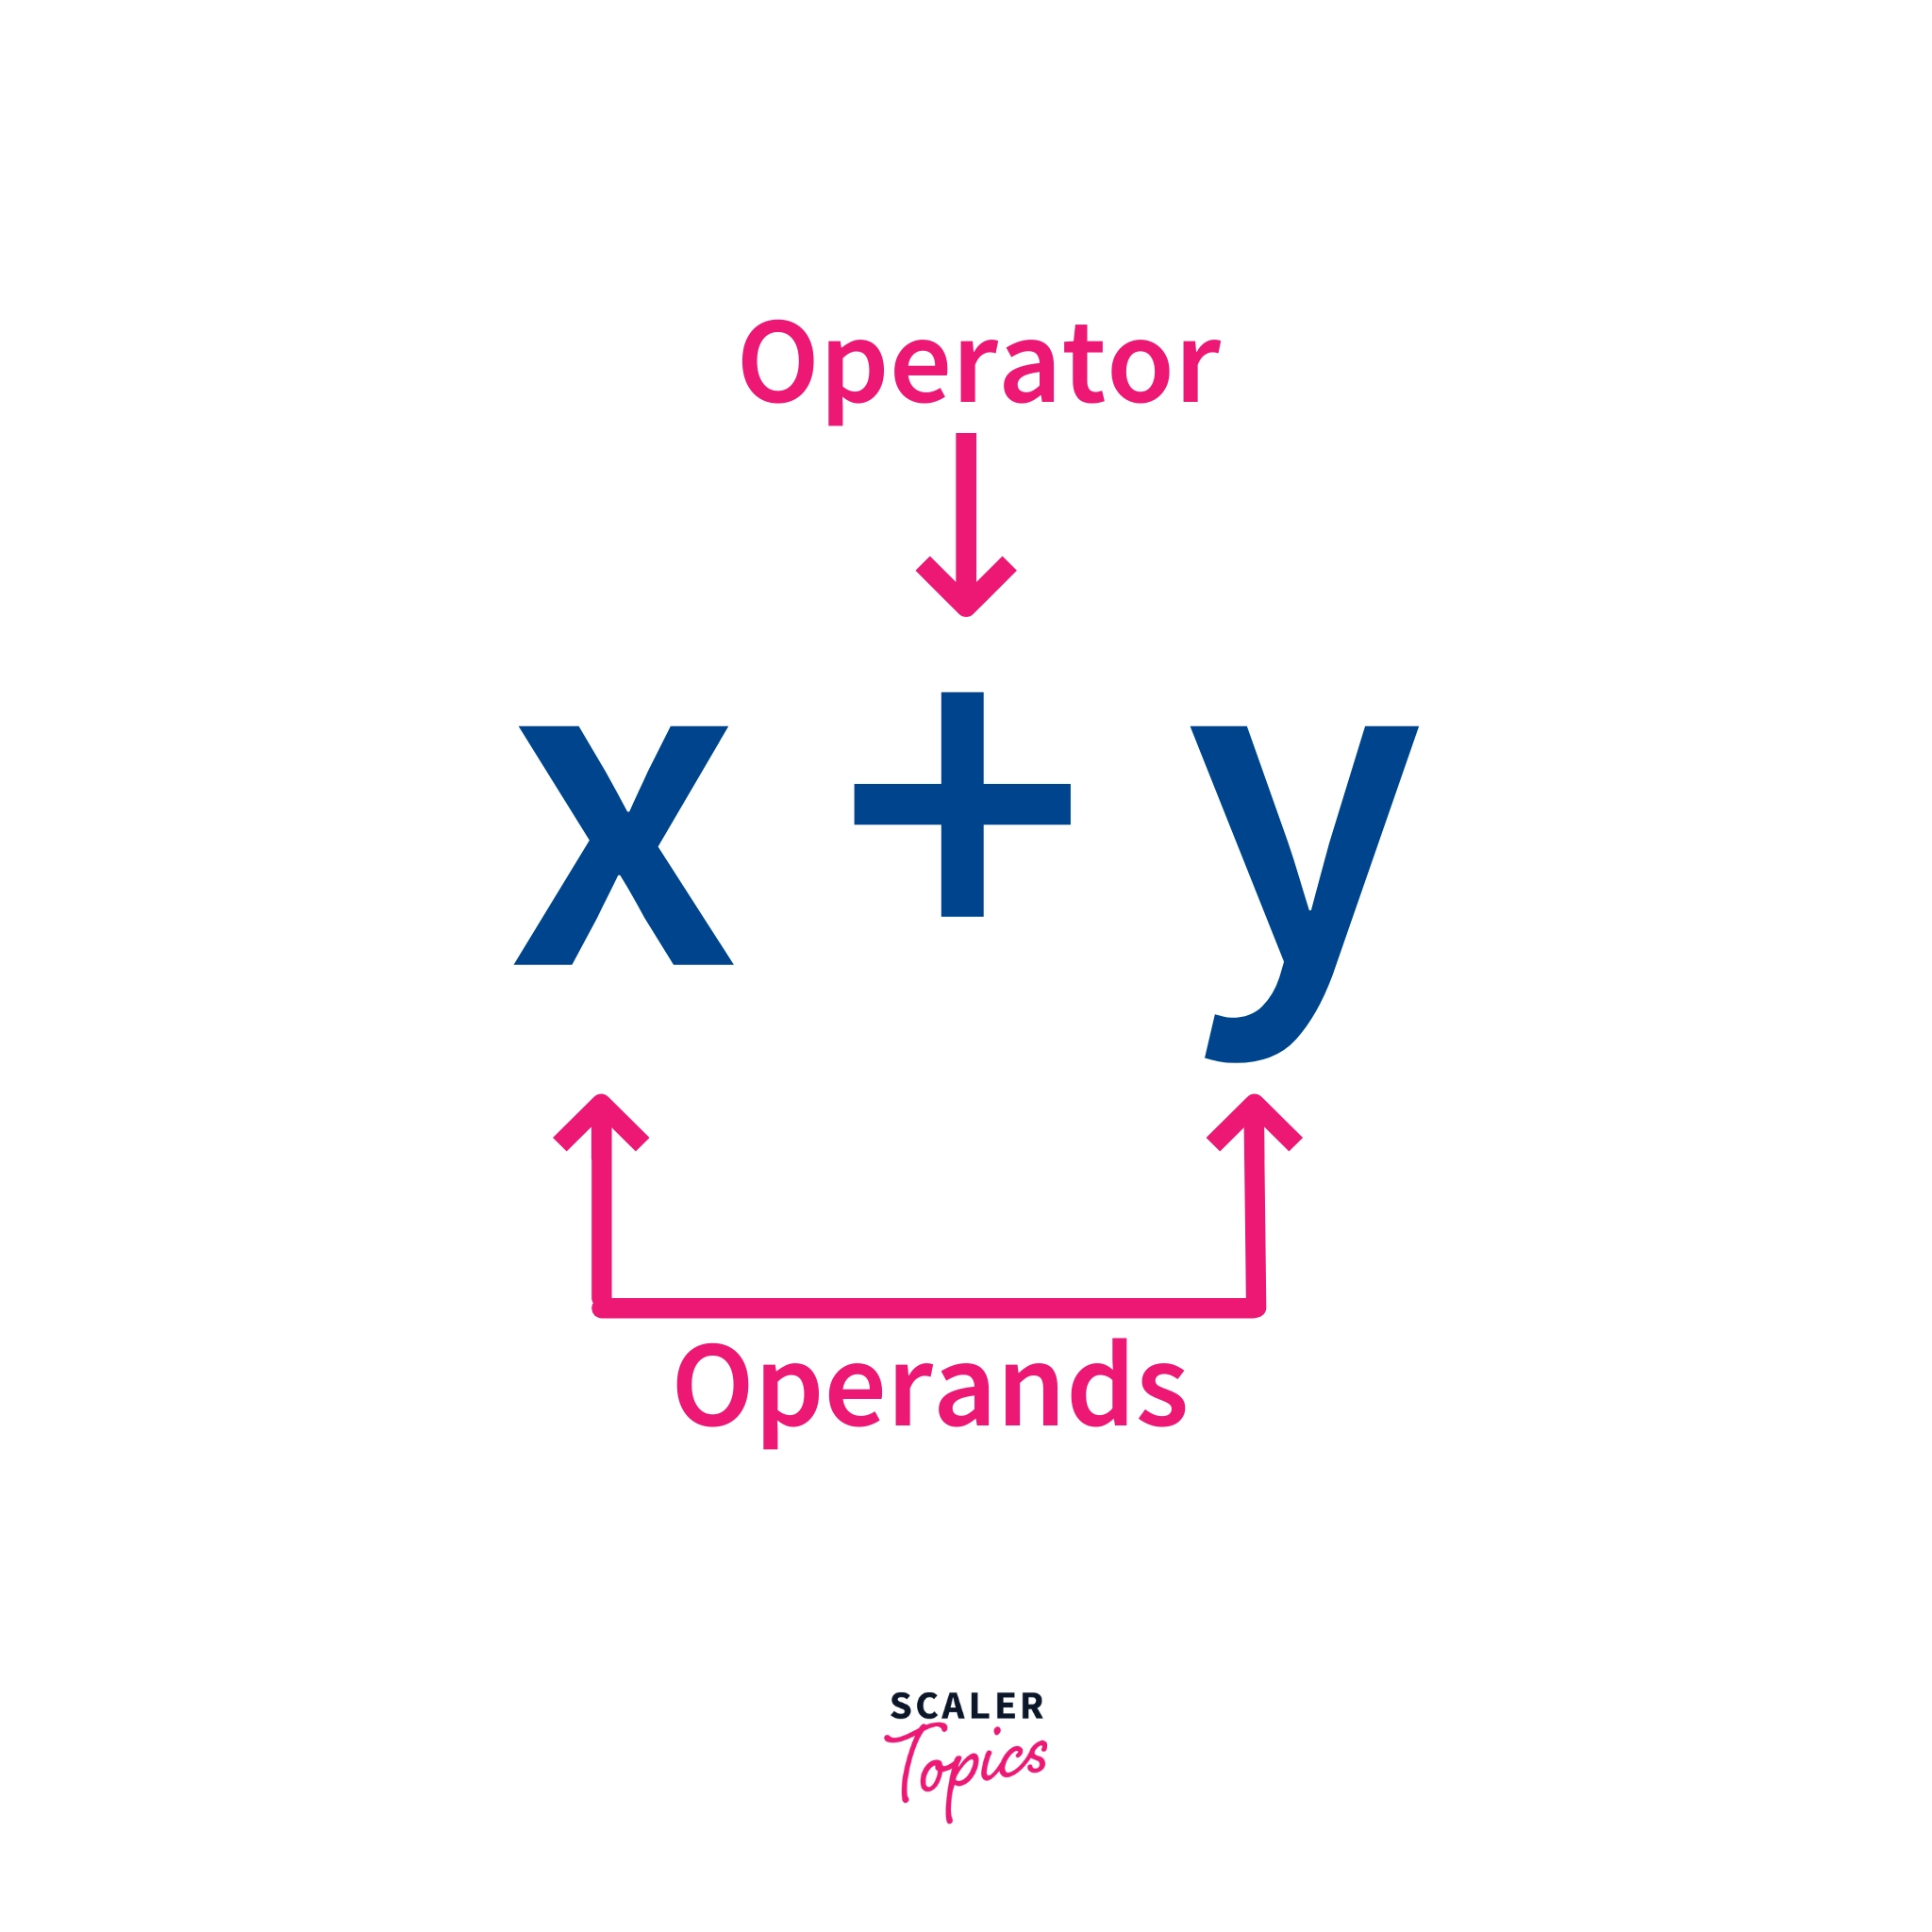
At its core, an operand is an input to an operation. In mathematics, if you have the expression 2 + 3, the numbers 2 and 3 are the operands, and + is the operator. In computer science, this concept extends to any piece of data that a CPU, a processing unit, or an algorithm acts upon. Whether it’s a single binary digit, a vast array of sensor readings, or a complex machine learning model’s input vector, these are all operands that fuel the computational engine of a drone. For drones, this means anything from a pixel in a camera feed, a GPS coordinate, an accelerometer reading, or a user command, all serving as raw material for the drone’s decision-making and operational processes.

Operands in Autonomous Flight and Navigation Systems
The promise of autonomous flight, a cornerstone of drone innovation, rests entirely on the drone’s ability to interpret and act upon a continuous stream of operands. These systems are intricate networks of sensors, algorithms, and actuators that require precise data inputs to function reliably and safely.
Sensor Data as Critical Operands
Every sensor on a drone generates data, which immediately becomes an operand for the flight controller and navigation algorithms.
- GPS Receivers: Output latitude, longitude, and altitude values. These coordinates are operands for path planning algorithms, allowing the drone to calculate its current position relative to a desired waypoint. The difference between current and target coordinates becomes an operand for PID (Proportional-Integral-Derivative) controllers, which determine the thrust adjustments needed to move the drone.
- Inertial Measurement Units (IMUs): Comprising accelerometers, gyroscopes, and magnetometers, IMUs provide data on the drone’s orientation, velocity, and angular rates. The raw acceleration and angular velocity readings are operands that are fed into Kalman filters or complementary filters to estimate the drone’s attitude (roll, pitch, yaw) and its linear velocity. These estimations, in turn, become operands for stabilization algorithms that maintain level flight or execute precise maneuvers.
- Barometers: Supply atmospheric pressure data, which is converted into altitude. This altitude data serves as an operand for maintaining a constant flight height or executing vertical ascent/descent profiles.
- Ultrasonic and Lidar Sensors: Provide distance measurements to obstacles or the ground. These distances are operands for obstacle avoidance systems, enabling the drone to identify potential collisions and adjust its flight path accordingly. In mapping, ground distance becomes a critical operand for creating accurate elevation models.
Flight Control Algorithms and Operand Processing
The drone’s flight controller is a sophisticated computer that constantly processes these diverse operands. It takes sensor data, combines it with mission parameters (e.g., desired speed, altitude, waypoints), and generates new operands in the form of control signals for the motors. These control signals are essentially instructions—operands—that dictate propeller speeds and thus the drone’s movement. For example, if a drone needs to turn left, the IMU reports a deviation from the desired yaw. This deviation is an operand for the yaw control algorithm, which calculates a new motor speed differential (another operand) to correct the heading.
AI, Machine Learning, and Real-time Decision Making
The true cutting edge of drone innovation lies in integrating Artificial Intelligence (AI) and Machine Learning (ML) capabilities. Here, operands take on new dimensions, representing complex data structures that AI models learn from and act upon.
Image and Video Data as Complex Operands

For features like AI Follow Mode, object recognition, and intelligent surveillance, camera feeds are the primary source of operands.
- Raw Pixels: Each pixel in an image or video frame is a fundamental operand. For computer vision algorithms, these pixels are aggregated into higher-level features—edges, shapes, textures—which then serve as more abstract operands.
- Object Detection: In AI Follow Mode, a neural network is trained to recognize specific objects (e.g., a person, a car). The input image is an operand that the network processes through multiple layers. The output, which could be bounding box coordinates and a confidence score for a detected object, then becomes an operand for the flight control system to maintain tracking.
- Environmental Context: Beyond just identifying objects, AI can interpret the broader environmental context. For instance, in an autonomous landing scenario, the AI might process visual operands to distinguish between a safe landing zone and an unsafe one (e.g., uneven terrain, water). The “safeness score” becomes an operand guiding the landing procedure.
Reinforcement Learning and Behavioral Operands
More advanced autonomous systems, especially those using reinforcement learning, learn optimal behaviors through trial and error. In this context:
- State: The drone’s current condition (position, velocity, sensor readings) is an operand representing its “state.”
- Action: The drone’s decision (e.g., increase speed, turn left) is an operand representing an “action.”
- Reward: The feedback received after an action (e.g., positive for moving towards a goal, negative for a collision) is an operand that guides the learning process.
These operands iteratively refine the drone’s policy, teaching it to make better decisions in complex, dynamic environments.
Data Processing for Mapping and Remote Sensing
Mapping and remote sensing are applications where drones excel, providing invaluable data for agriculture, construction, environmental monitoring, and urban planning. The entire process is a sophisticated chain of operand creation, transformation, and analysis.
Raw Sensor Data to Geospatial Operands
- Photogrammetry: Drones equipped with high-resolution cameras capture hundreds or thousands of overlapping images. Each image, or rather the features extracted from it, serves as an operand. Specialized software processes these image operands to identify common points, then triangulates their 3D positions to create a dense point cloud. This point cloud, consisting of millions of individual 3D coordinates, is itself a massive operand for subsequent processing.
- Lidar Data: Lidar sensors emit laser pulses and measure the time it takes for them to return, generating highly accurate 3D point clouds directly. Each return signal, containing XYZ coordinates and intensity values, is an operand. These Lidar point clouds are crucial operands for creating Digital Elevation Models (DEMs), Digital Surface Models (DSMs), and precise volumetric calculations.
- Hyperspectral and Multispectral Data: For remote sensing applications like crop health analysis, drones carry specialized cameras that capture light across various spectral bands. The intensity values for each band at each pixel location are operands. These spectral operands are then used in algorithms (e.g., NDVI calculation) to derive vegetation indices, identify plant stress, or classify land cover types. The results of these calculations become new, more informative operands for agronomists or environmental scientists.
From Raw Data to Actionable Insights
The transformation of raw sensor operands into actionable intelligence involves multiple computational steps. The point clouds from photogrammetry or Lidar are often meshed to create 3D models. These models, with their vertices and faces, are operands for further analysis such as volumetric calculations for quarry management or change detection for construction progress monitoring. For precision agriculture, the derived vegetation maps, themselves complex operands, guide targeted fertilizer application or pest control strategies. Each stage of data refinement creates new, more abstract, and often more valuable operands, moving from basic measurements to profound insights.
The Future: Complex Operands and Advanced Drone Intelligence
As drone technology continues to push boundaries, the complexity and diversity of operands will only increase. Future drones will integrate more sophisticated sensors, process vast amounts of data in real-time, and make increasingly autonomous decisions.
- Swarm Intelligence: In multi-drone operations, the status, intentions, and sensor data of neighboring drones become operands for individual drones, enabling complex coordinated behaviors and distributed task execution.
- Edge Computing and Real-time AI: Processing operands directly on the drone (edge computing) instead of sending them to a ground station will become more prevalent, allowing for near-instantaneous decision-making in critical applications like search and rescue or autonomous package delivery.
- Human-Drone Interaction: Voice commands, gesture recognition, and physiological data from human operators could become operands, allowing for more intuitive and natural ways to interact with and control drones.
In essence, every byte of data generated by a drone’s sensors, every instruction processed by its flight controller, and every parameter learned by its AI models is an operand. These fundamental building blocks of computation are what empower drones to navigate complex environments, perform intricate tasks, and deliver unprecedented levels of innovation across countless industries. The continuous evolution of drone intelligence is, at its heart, a story of increasingly sophisticated operand management and processing.