
In the rapidly evolving landscape of drone technology, where autonomous flight, sophisticated mapping, and real-time remote sensing are becoming commonplace, the underlying communication infrastructure is paramount. Efficient and reliable data transmission is not merely a convenience but a critical enabler for advanced capabilities. This is where Open Shortest Path First (OSPF), a robust and dynamic routing protocol, enters the discussion for its potential to revolutionize how drone fleets communicate and operate. While traditionally associated with enterprise networks, OSPF’s principles of dynamic path optimization and network resiliency are highly applicable to the unique challenges presented by complex drone operations and the burgeoning field of aerial robotics.
The Core Principles of OSPF in a Connected World
OSPF is a link-state interior gateway protocol (IGP) designed to distribute routing information between routers within a single autonomous system. Its primary function is to determine the most efficient and shortest paths for data packets to travel across a network. For drone applications, this translates directly into ensuring that critical control signals, high-bandwidth sensor data, and vital telemetry reach their destinations with minimal latency and maximum reliability. The protocol’s strength lies in its ability to quickly adapt to changes in network topology, a feature essential for dynamic environments where nodes (drones) are constantly moving and connections can be intermittent.
Link-State Routing Explained
Unlike simpler distance-vector protocols, OSPF operates by having each participating node (e.g., a drone equipped with networking capabilities, or a ground station) build a complete topological map of the entire network. This is achieved through the exchange of Link State Advertisements (LSAs), which describe the state of a router’s interfaces and its adjacent neighbors. Once all LSAs are received and processed, each node constructs an identical Link State Database (LSDB). Using Dijkstra’s shortest path first algorithm, each node then independently calculates the shortest path to every other node in the network.
For drone swarms or collaborative aerial mapping missions, this comprehensive understanding of the network topology is invaluable. It allows drones to make intelligent, localized decisions about the best communication path, rather than relying on limited, hop-by-hop information. If a drone in a swarm moves out of range or an unexpected obstacle disrupts a communication link, OSPF can quickly update the LSDB and recalculate optimal paths, ensuring continuous data flow for mission-critical tasks like autonomous navigation, cooperative object tracking, or synchronized data collection.
Hierarchical Network Design
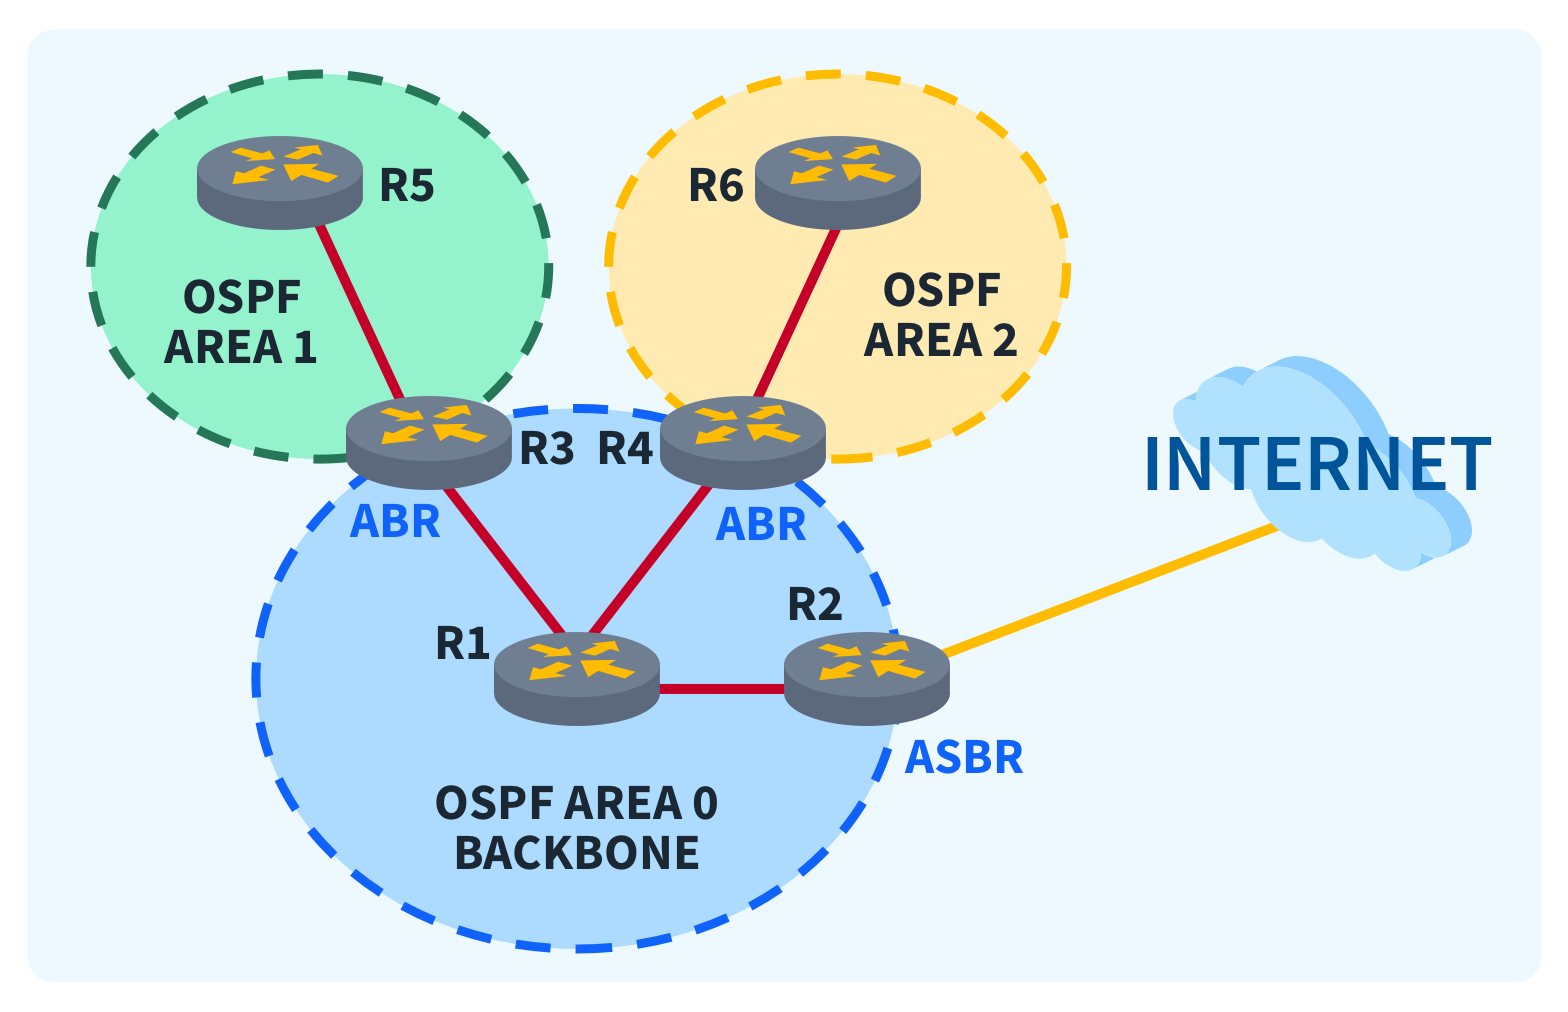
OSPF supports a hierarchical network architecture through the concept of “areas.” A large OSPF network can be divided into smaller, logical groups called areas, all connected to a central “backbone area” (Area 0). This hierarchical design offers significant benefits for scalability and efficiency, particularly for extensive drone deployments.
Imagine a scenario where a fleet of drones is operating across a vast agricultural area for precision farming. Instead of every drone needing to maintain a complete map of every other drone, they could be grouped into areas based on their operational zones. Each area would have its own LSDB, reducing the computational load on individual drone processors. The backbone area could represent the primary ground control station or a central data processing hub, facilitating communication and data aggregation across the different drone groups. This design not only enhances network stability and performance but also simplifies management for large-scale, distributed drone operations, which are increasingly becoming a reality in urban air mobility, logistics, and environmental monitoring.
OSPF’s Role in Autonomous Drone Operations and Swarms
Autonomous flight and drone swarm intelligence are at the forefront of drone innovation. These advanced capabilities are inherently dependent on robust, low-latency, and highly reliable communication. OSPF provides a foundation for achieving these communication requirements, allowing drones to act as intelligent, interconnected nodes in a dynamic network.
Dynamic Path Optimization for Data Transmission
In an autonomous drone operation, conditions can change in an instant. Drones may alter their flight paths, encounter environmental interference, or even experience partial system failures. OSPF’s ability to dynamically recalculate routing paths in milliseconds is a game-changer. For a swarm performing a complex maneuver, uninterrupted communication for coordination signals is critical. If one drone’s communication link becomes degraded or fails, OSPF can swiftly re-route inter-drone messages or commands from the ground station through alternative, healthier paths via other drones acting as relays.
This dynamic optimization is crucial for maintaining real-time control links, ensuring that AI-driven decision-making processes onboard or at edge computing nodes receive timely sensor data, and facilitating the seamless exchange of information between cooperative drones. Whether it’s for cooperative surveillance, distributed payload delivery, or synchronized data capture, OSPF’s adaptive routing capabilities underpin the reliability needed for complex, multi-drone missions.
Ensuring Robust Communication in Challenging Environments
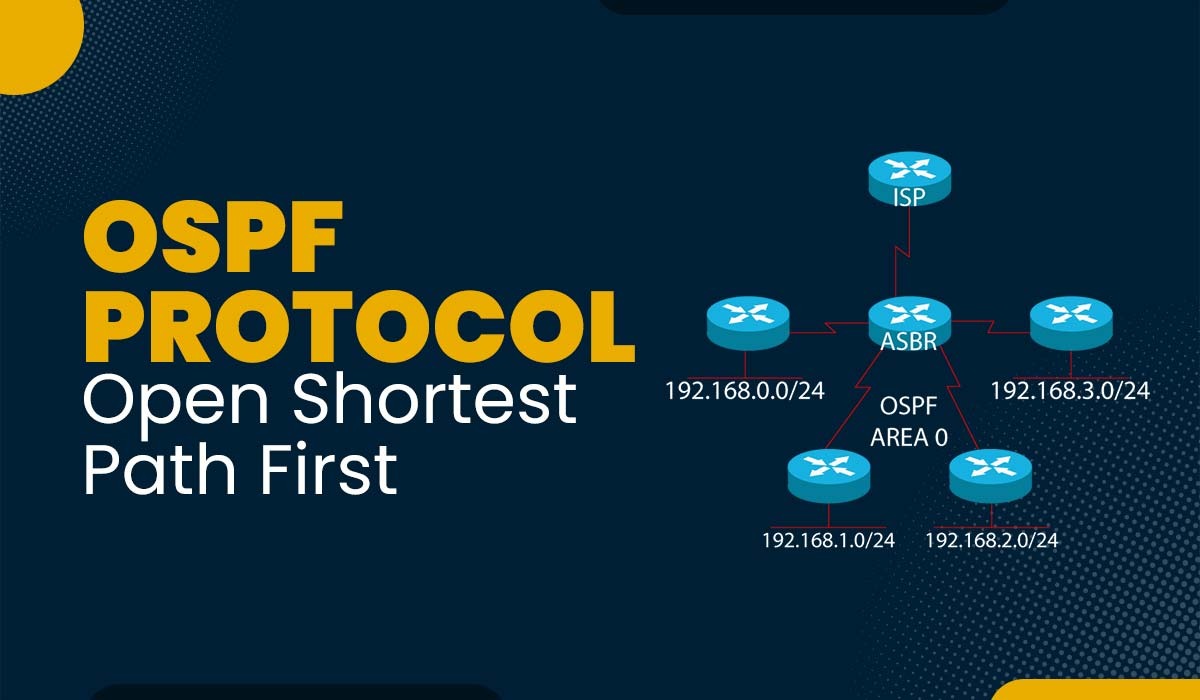
Drones often operate in environments that are far from ideal for wireless communication, such as urban canyons, dense foliage, or areas with electromagnetic interference. In these challenging conditions, traditional fixed-path communication can be fragile. OSPF inherently builds redundancy into the network by identifying multiple potential paths to a destination. If a primary path experiences congestion, interference, or an outright failure, OSPF can automatically and almost instantaneously switch to an alternative, viable path.
This fault tolerance is paramount for mission-critical applications like search and rescue, disaster response, or infrastructure inspection, where communication blackouts can have severe consequences. By enabling drones to form a self-healing mesh network, OSPF ensures that command and control signals, emergency alerts, and vital sensor data continue to flow, significantly enhancing the reliability and safety of autonomous drone operations in unpredictable settings.
Enhancing Mapping and Remote Sensing Through Efficient Data Flow
High-resolution mapping and sophisticated remote sensing applications are incredibly data-intensive. From gigabytes of photogrammetry data to LiDAR point clouds and hyperspectral imagery, drones are generating vast amounts of information that needs to be transmitted, processed, and analyzed. OSPF plays a pivotal role in managing this data deluge, ensuring its efficient and reliable delivery from airborne platforms to ground-based or cloud processing systems.
Real-time Data Ingestion and Processing
For many advanced mapping and remote sensing tasks, real-time data ingestion and processing are crucial. This allows for immediate feedback, enabling drones to adapt their flight paths based on live terrain maps, identify anomalies during an inspection, or track changes in environmental conditions on the fly. OSPF ensures that the substantial data streams generated by drone sensors are routed along the fastest available paths, minimizing latency to edge computing devices or central processing servers.
Consider a drone conducting an environmental survey, collecting high-definition video and multispectral data. As the drone captures this information, OSPF can intelligently route segments of the data through a network of other drones or mobile ground stations to the nearest available processing unit. This distributed approach, facilitated by OSPF’s dynamic routing, not only speeds up data analysis but also reduces the computational burden on individual drones, allowing them to focus on flight and sensing tasks.
Network Resiliency for Critical Missions
Uninterrupted data flow is non-negotiable for producing accurate and complete maps or for continuous remote sensing operations. Any break in transmission can result in incomplete datasets, requiring costly re-flights or compromising the integrity of the collected information. OSPF’s inherent network resiliency and fault-tolerance mechanisms are critical in preventing such disruptions.
For a swarm of drones collaboratively mapping a large area, each drone might be responsible for a specific segment. As they collect data, they transmit it to a central aggregation point. If a communication link between a drone and the aggregator or between two drones acting as relays is lost, OSPF will swiftly re-establish the connection via an alternative path. This continuous, self-healing data pipeline ensures that all collected data reaches its destination, enabling the seamless creation of comprehensive maps and reliable remote sensing insights, even in dynamic and unpredictable operational environments.
Integrating OSPF for Future Drone Innovation
As drone technology continues its rapid advancement, the complexity and scale of drone operations will only increase. Future drone innovation, particularly in areas like urban air mobility, large-scale autonomous logistics, and persistent environmental monitoring, will necessitate network infrastructures capable of handling unprecedented levels of connectivity and data exchange. OSPF’s foundational strengths make it an ideal candidate to support these next-generation capabilities.
Scalability for Large-Scale Deployments
The vision of thousands of drones operating autonomously within a shared airspace, coordinating movements, and exchanging data in real-time requires a highly scalable networking solution. OSPF’s hierarchical design, with its ability to segment a large network into manageable areas, is perfectly suited for managing the network complexity of such vast fleets. It allows for efficient routing information exchange, preventing individual drones from being overwhelmed by network topology data.
This scalability ensures that as drone deployments grow, the underlying communication network can expand and adapt without compromising performance. It provides the framework for building robust and reliable communication backbones that can support future applications involving entire ecosystems of interconnected drones, ground infrastructure, and cloud services.

Adaptive Networks for Evolving Missions
Drone missions are rarely static; they often involve dynamic objectives, changing environmental conditions, and evolving operational parameters. The ability of OSPF to create self-healing and self-optimizing networks is paramount for these adaptive missions. It allows drone networks to intelligently reconfigure themselves in response to new information, altered objectives, or unexpected challenges.
Moreover, OSPF can be integrated with more advanced network management concepts, such as “network slicing,” where different types of drone traffic (e.g., high-priority control signals, medium-priority video feeds, low-priority telemetry) can be allocated distinct network resources and routing priorities. This ensures that critical communications always receive preferential treatment, even in congested networks. By providing a foundation for highly autonomous, intelligent, and flexible communication architectures, OSPF will be instrumental in enabling drones to achieve unprecedented levels of autonomy, adaptability, and operational sophistication in the years to come.