
The realm of modern drone technology is a fascinating intersection of mechanics, aerodynamics, and advanced computing. Beneath the whirring propellers and sophisticated sensor arrays lies a complex digital brain, constantly processing data and executing commands to keep the aircraft aloft, navigate intricate paths, and perform intelligent tasks. At the fundamental heart of this digital brain’s operations is a concept known as the opcode, or operation code. Far from being an abstract theoretical construct, opcodes are the elemental instructions that directly command a processor to perform a specific action, forming the very bedrock upon which all advanced drone innovation, from autonomous flight to AI-powered mapping, is built.
The Core of Machine Execution
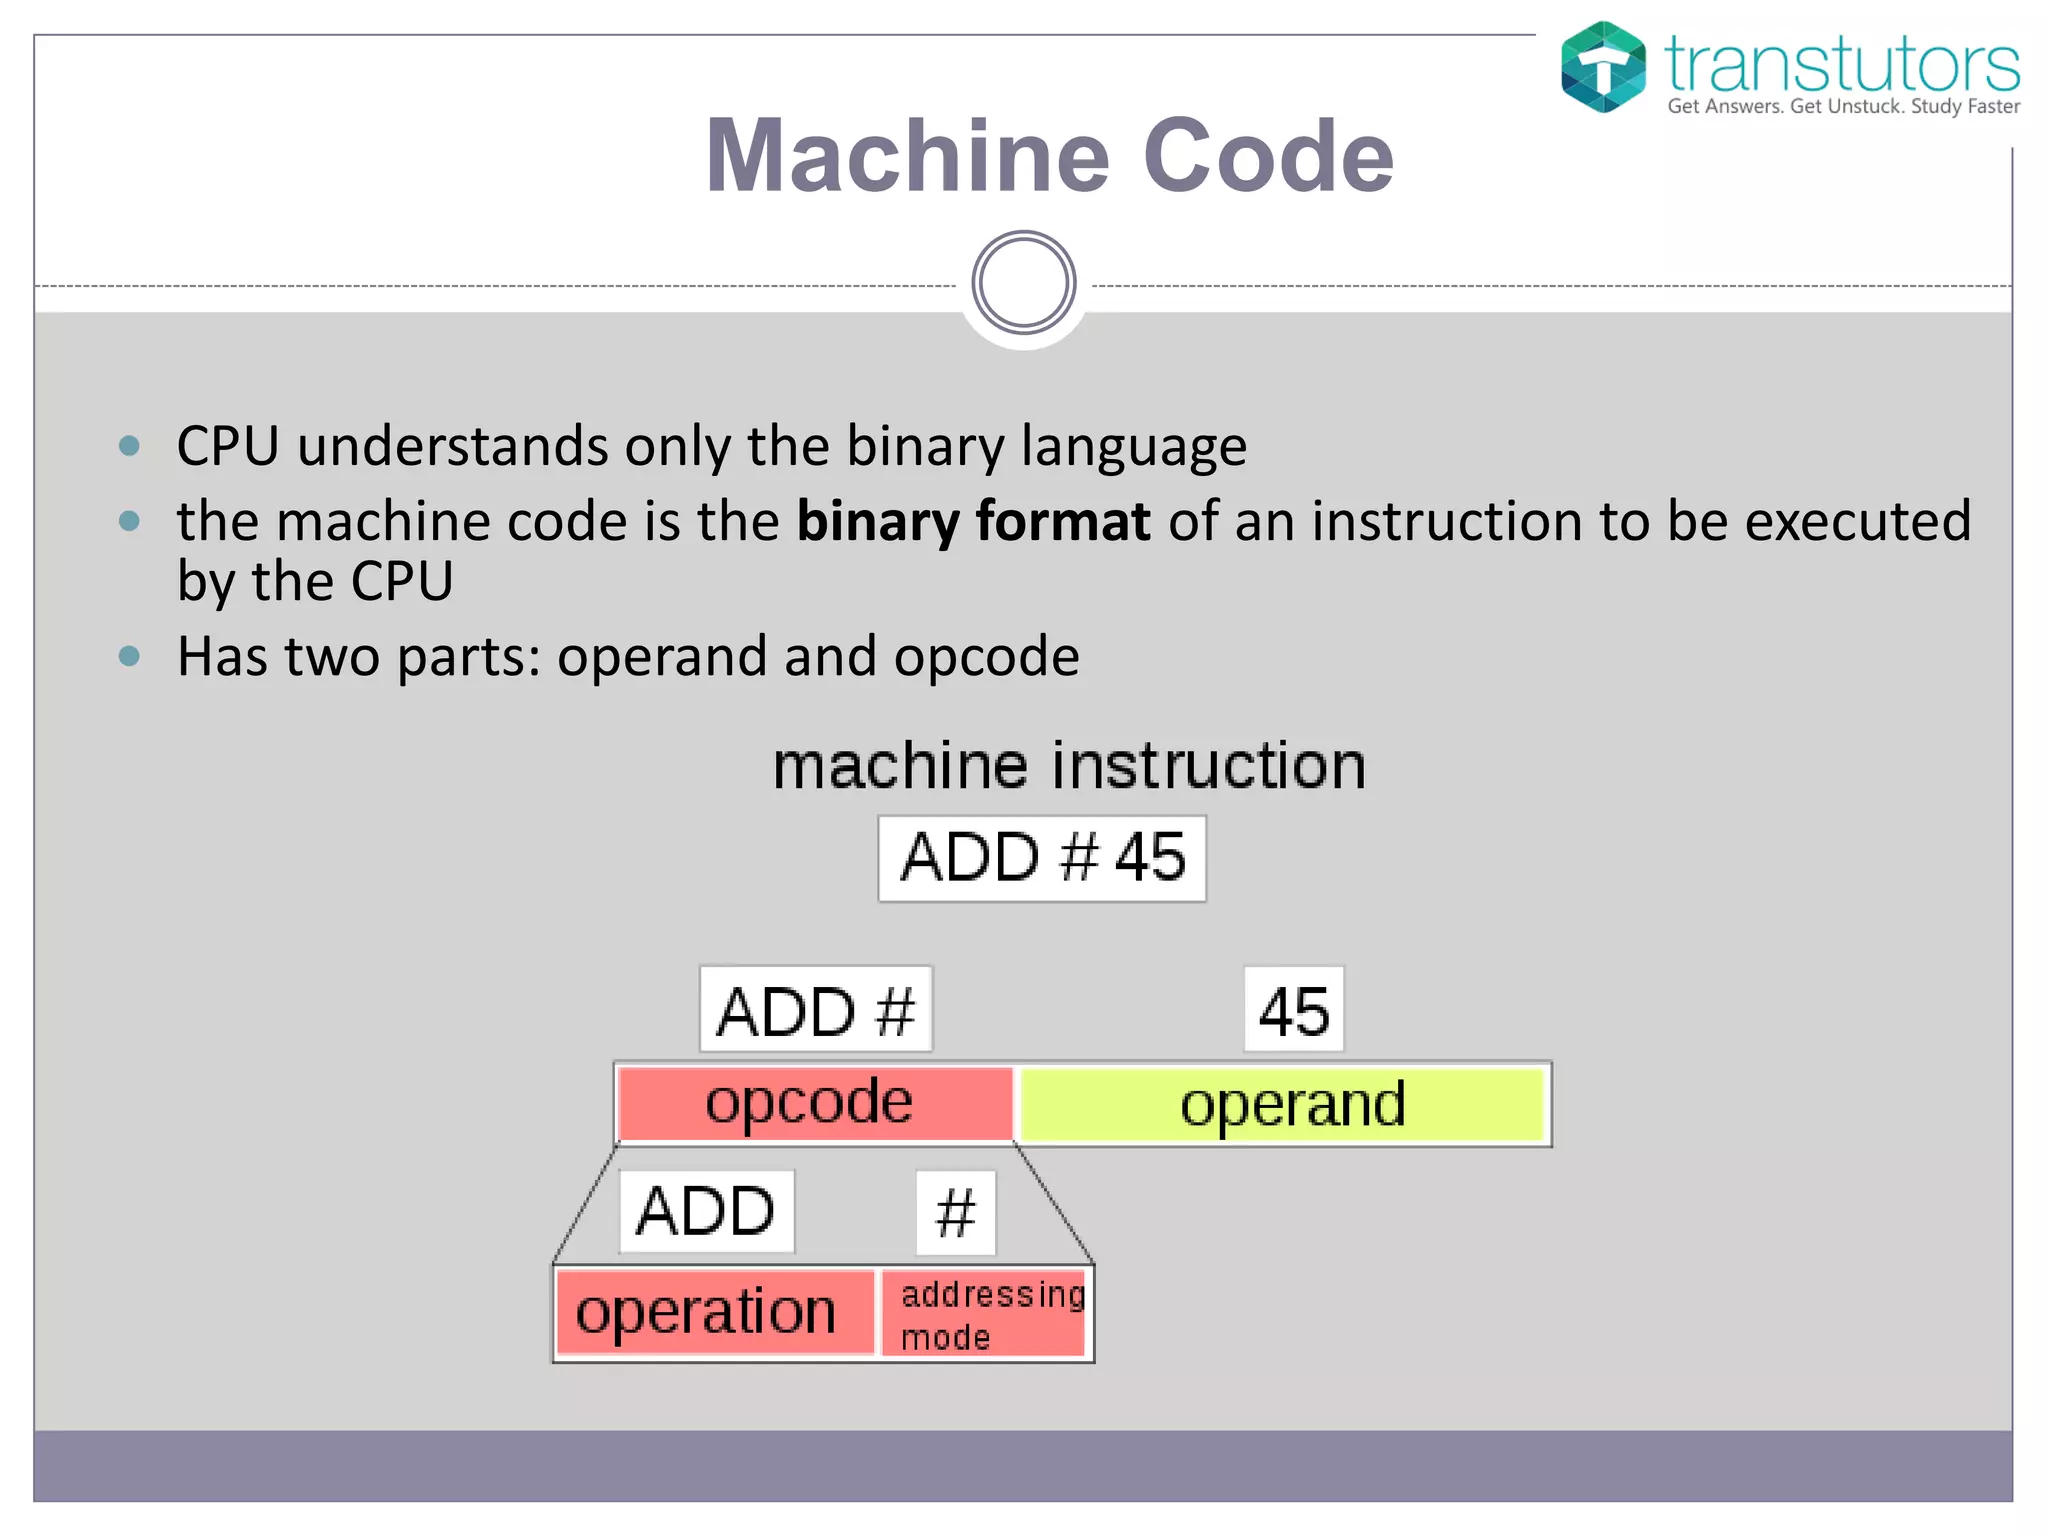
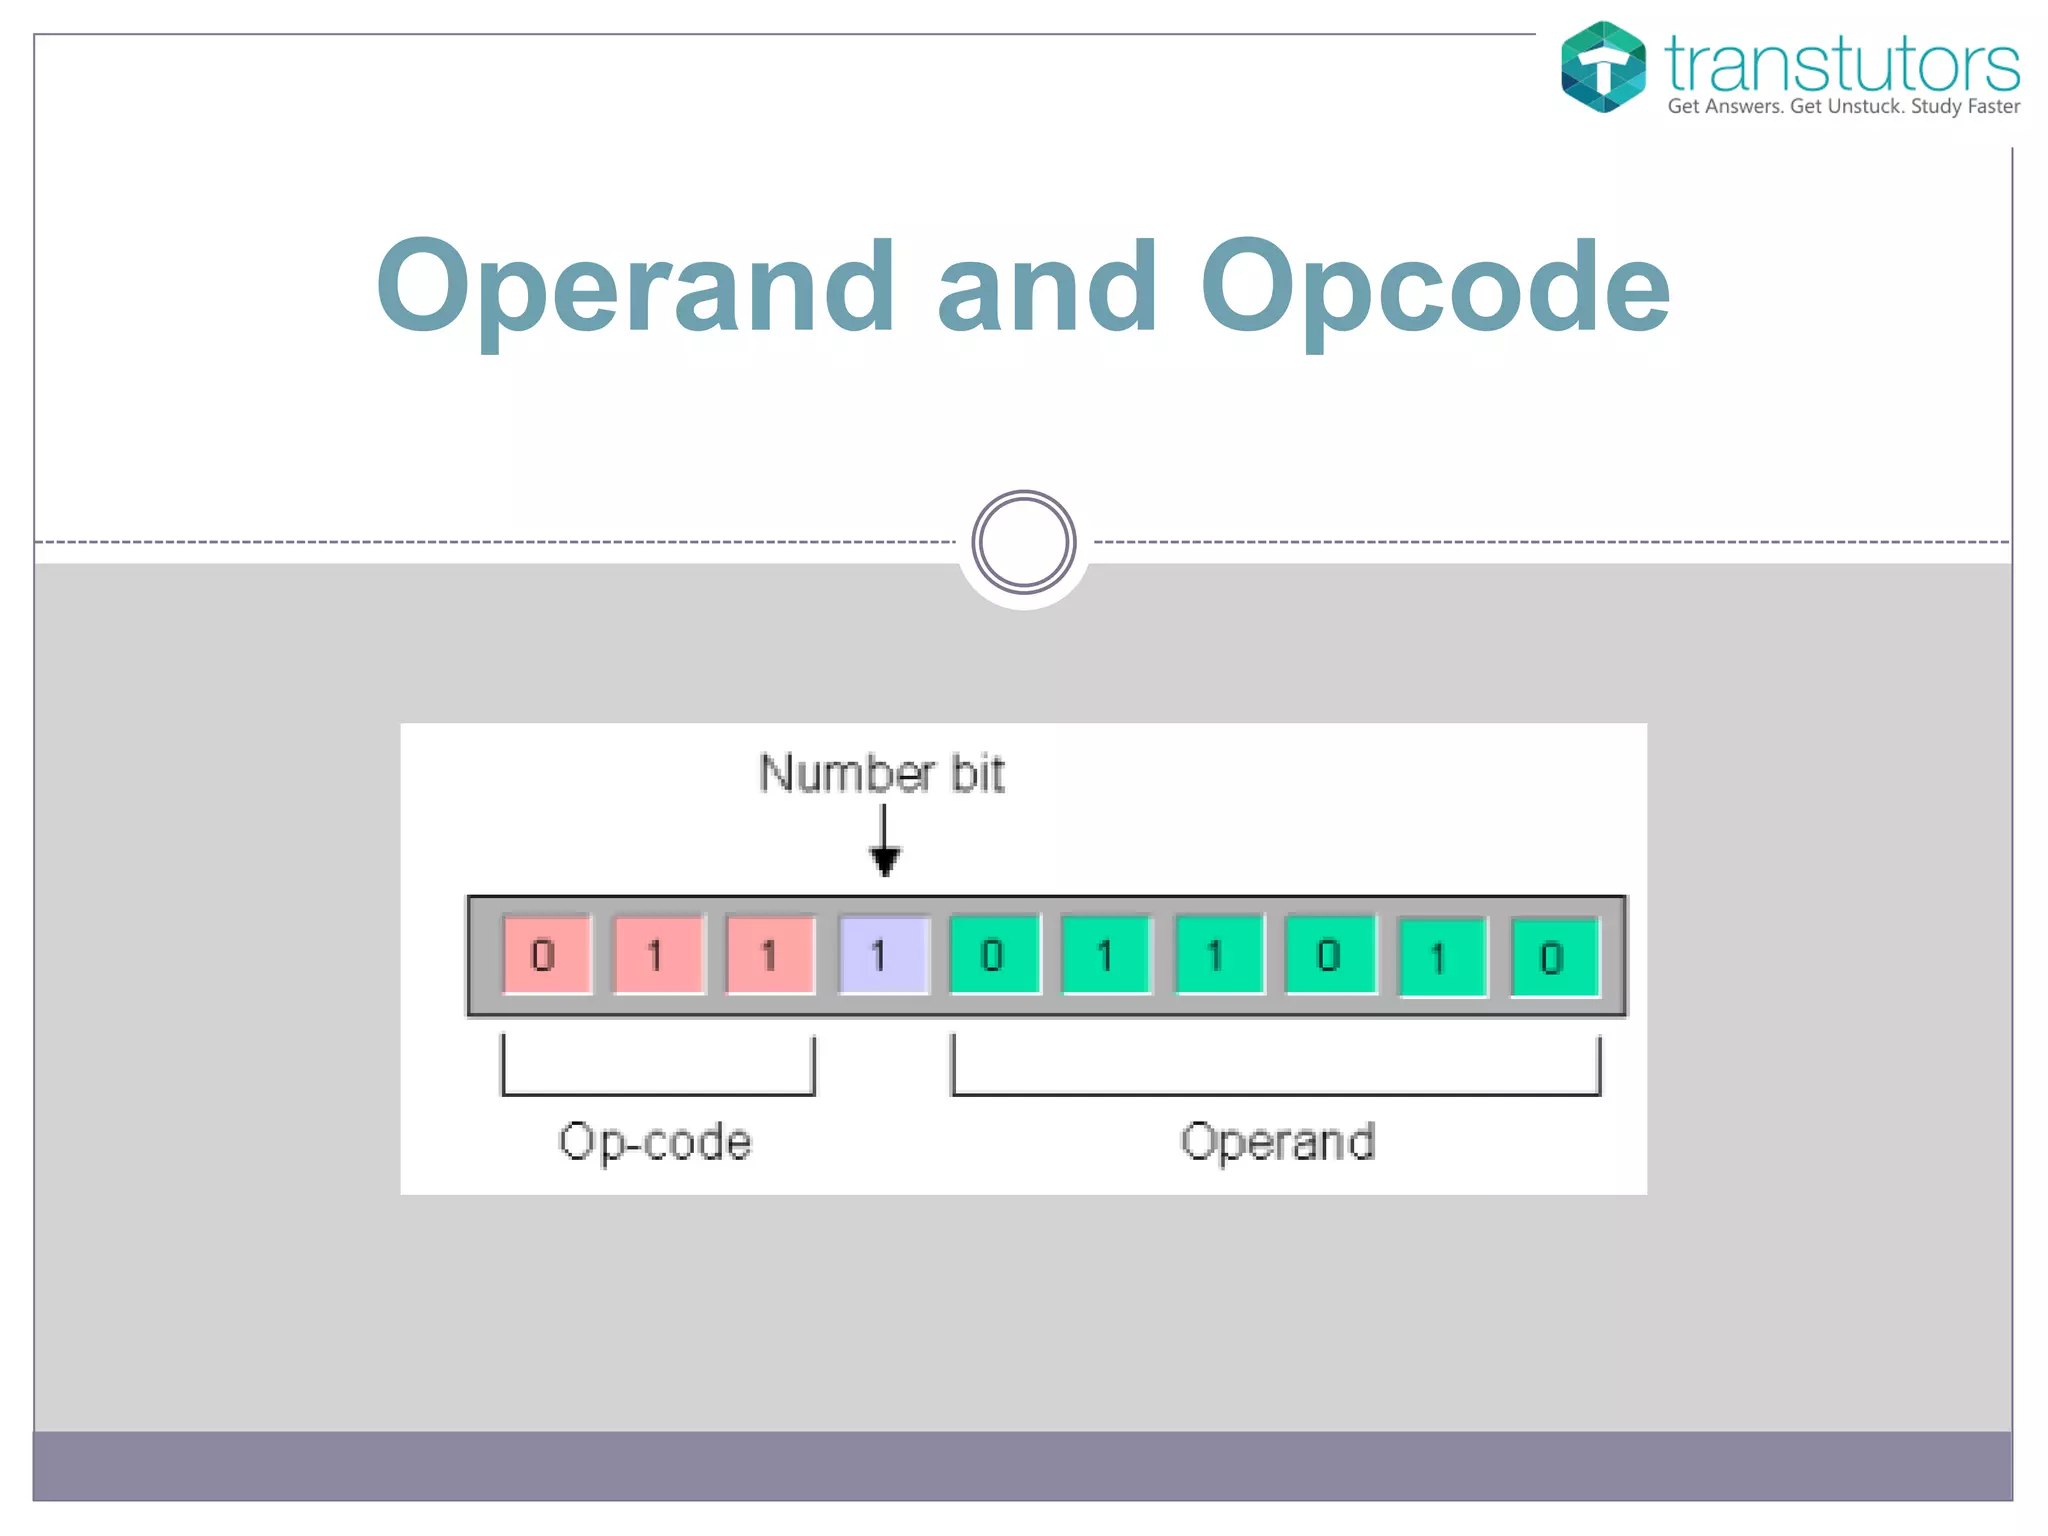
To understand the profound impact of opcodes on drone technology, it’s essential to grasp their role in general computing. An opcode is a unique binary pattern that represents a particular instruction for a computer’s central processing unit (CPU) or a specialized microcontroller. Every action a processor takes – adding two numbers, moving data from one memory location to another, or comparing values – is dictated by a specific opcode.
From High-Level Code to Low-Level Instructions
Drone software, like most modern applications, is typically written in high-level programming languages such as C++, Python, or Rust. These languages are designed to be human-readable and abstract away the complexities of the underlying hardware. However, a processor cannot directly understand these high-level instructions. Before execution, the code undergoes a transformation process:
- Compilation: A compiler translates the high-level source code into assembly language, which is a low-level symbolic representation of machine instructions.
- Assembly: An assembler then converts the assembly language into machine code – a sequence of binary opcodes and their operands (the data or memory addresses upon which the operation acts).
It is this machine code, composed of these precise binary opcodes, that the drone’s onboard processor directly interprets and executes. Without this fundamental translation and the processor’s ability to understand opcodes, no drone could ever lift off, stabilize itself, or perform its programmed functions.
The Processor’s Language
Think of opcodes as the vocabulary of the processor. Each processor architecture (e.g., ARM, x86, RISC-V) has its own unique instruction set architecture (ISA), which defines the complete set of opcodes it can understand and execute. The ISA is crucial because it dictates how software must be written and compiled for that specific processor. In drone applications, where efficiency, speed, and power consumption are paramount, the choice of processor and its underlying ISA significantly impacts performance. An opcode might instruct the processor to:
- Load data from memory into a register.
- Perform an arithmetic operation (e.g., addition, subtraction).
- Store data from a register back into memory.
- Jump to a different section of code based on a condition.
- Initiate an input/output operation (e.g., read sensor data).
Each of these seemingly simple operations, when strung together in complex sequences dictated by millions of opcodes, allows the drone to perform incredibly sophisticated tasks.
Opcode’s Role in Drone Technology
The impact of opcodes is most vividly observed in the advanced technological innovations defining the modern drone landscape. Every intelligent feature, from maintaining stable flight to executing complex autonomous missions, hinges on the precise and rapid execution of these low-level instructions.
Flight Controllers and Embedded Systems
The flight controller is the brain of any drone, an embedded system specifically designed to interpret pilot commands, process sensor data (from accelerometers, gyroscopes, barometers, GPS), and control the motors to achieve desired flight characteristics. These controllers rely on specialized microprocessors that are optimized for real-time operations and low power consumption. The firmware running on these flight controllers is a sophisticated program, painstakingly written and compiled into machine code comprising thousands, if not millions, of opcodes.
For instance, when a drone needs to correct for a gust of wind, the following simplified sequence of events occurs at the opcode level:
- Read Sensor Data: Opcodes instruct the processor to read data from the IMU (Inertial Measurement Unit) sensors, indicating a deviation in attitude.
- Process Data: Opcodes perform calculations to determine the magnitude and direction of the correction needed.
- Execute Control Loop: Opcodes implement the PID (Proportional-Integral-Derivative) control algorithm, a series of arithmetic and logical operations, to compute the necessary motor speed adjustments.
- Send Commands: Opcodes send signals to the Electronic Speed Controllers (ESCs), which in turn adjust motor RPMs.
This entire process must happen thousands of times per second, demanding extreme efficiency in opcode execution to ensure stable and responsive flight.
Enabling Autonomous Flight and AI Features
The cutting edge of drone innovation lies in autonomous capabilities and artificial intelligence. Features like ‘follow me’ mode, obstacle avoidance, precise waypoint navigation, and intelligent object recognition all rely on complex algorithms executed by onboard processors. These algorithms, once compiled, translate into vast sequences of opcodes.
- AI Follow Mode: Involves opcodes that process camera input, identify a target (often using machine learning models), calculate its position and trajectory relative to the drone, and then issue flight control opcodes to maintain the desired distance and angle.
- Autonomous Navigation: Requires opcodes to interpret GPS and visual SLAM (Simultaneous Localization and Mapping) data, compute optimal flight paths, avoid dynamic obstacles by processing LiDAR or ultrasonic sensor data, and execute motor commands based on these calculations.
- Edge Computing: Many advanced drone features now utilize “edge computing,” where AI models are processed directly on the drone itself rather than relying on cloud servers. This demands highly optimized processors that can execute complex AI inference opcodes (e.g., matrix multiplications for neural networks) with minimal latency and power drain.
The efficiency of opcode execution directly impacts the responsiveness and accuracy of these intelligent features, making the difference between a seamless autonomous flight and a hesitant, error-prone one.
Data Processing for Mapping and Remote Sensing
Drones equipped with high-resolution cameras, LiDAR scanners, or multispectral sensors are revolutionizing industries like agriculture, construction, and environmental monitoring. The vast amounts of data collected during mapping and remote sensing missions require significant onboard processing even before the data is transmitted or stored.
- Image Stitching and Orthorectification: Opcodes are used to execute algorithms that correct for lens distortions, align multiple images, and stitch them into a seamless, georeferenced map.
- LiDAR Point Cloud Processing: Opcodes process raw LiDAR returns to filter noise, classify points (ground, vegetation, buildings), and generate 3D models.
- Real-time Anomaly Detection: In some applications, opcodes execute machine learning models to identify anomalies in sensor data in real-time, such as crop diseases or structural damage, enabling immediate action.
The speed at which these opcodes can be executed determines how quickly and effectively a drone can gather and make sense of its environmental data, enhancing its utility in critical applications.
Optimizing Performance Through Instruction Sets
The efficiency of opcode execution is not solely dependent on the processor’s clock speed. The design of the instruction set architecture (ISA) itself plays a pivotal role, influencing everything from power consumption to computational throughput.
RISC vs. CISC Architectures in Drones
The two primary philosophies for designing instruction sets are:
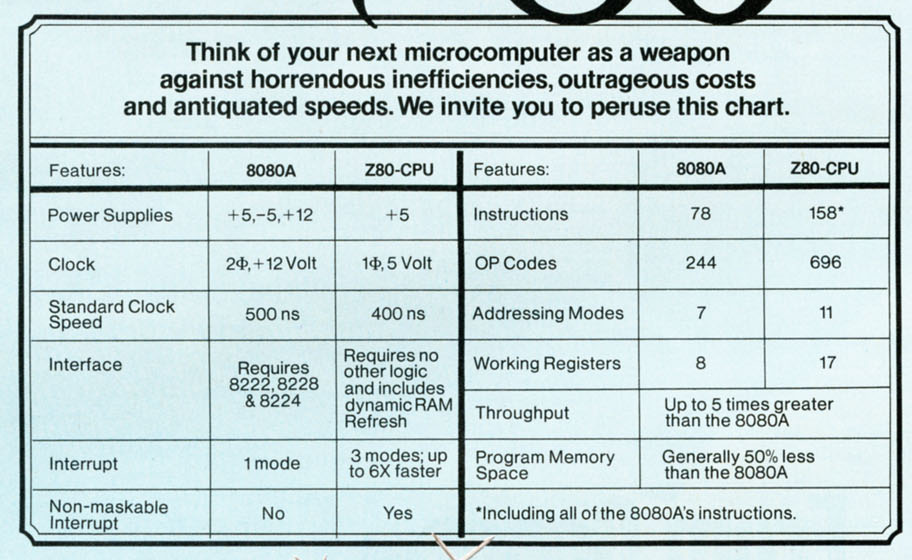
- Complex Instruction Set Computing (CISC): Processors with CISC architectures have a large number of complex opcodes, some of which can perform multiple low-level operations in a single instruction. While a single CISC opcode might do more work, these opcodes can be variable in length and take multiple clock cycles to execute.
- Reduced Instruction Set Computing (RISC): RISC processors, conversely, use a smaller, highly optimized set of simple opcodes. Each RISC opcode typically performs only one simple operation and executes in a single clock cycle. This simplicity allows for highly efficient pipeline execution and lower power consumption.
Most modern drone flight controllers and companion computers, especially those powered by ARM-based System-on-Chips (SoCs), predominantly leverage RISC architectures. This choice is deliberate.
The Impact on Efficiency and Power Consumption
For drones, operating on limited battery power and demanding real-time responsiveness, the benefits of RISC are clear:
- Power Efficiency: Simple opcodes require less complex decoding hardware and often consume less power per instruction cycle. This directly translates to longer flight times and reduced heat generation, critical for small, enclosed drone environments.
- Predictable Performance: The consistent execution time of RISC opcodes allows for highly optimized compilers and more predictable real-time performance, which is vital for flight stability and autonomous control loops.
- Smaller Footprint: Simpler instruction sets can lead to smaller processor cores, freeing up valuable silicon space for other essential components like specialized accelerators for AI or dedicated hardware for sensor interfaces.
While a high-level programmer might never directly interact with opcodes, the underlying ISA and the efficiency with which these low-level instructions are processed are fundamental to the energy envelope and computational prowess of every drone.
Future Implications for Drone Innovation
As drones continue to evolve, the underlying processing capabilities and the efficiency of opcode execution will remain a central pillar of innovation. The quest for more intelligent, more autonomous, and more energy-efficient drones directly translates to advancements in how opcodes are designed, managed, and executed.
Advanced Processor Design
Future drone processors will continue to push the boundaries of opcode efficiency. This includes:
- Specialized Instruction Sets: Developing specific opcodes optimized for common drone workloads, such as sensor data fusion, computer vision algorithms, or motor control loops.
- Heterogeneous Computing: Integrating multiple types of processing units (CPUs, GPUs, FPGAs, NPUs – Neural Processing Units) onto a single chip, each optimized for different opcode sets, to handle diverse tasks concurrently and efficiently. For example, NPUs will feature opcodes explicitly designed for rapid AI inference.
- Dynamic Instruction Scheduling: Advanced hardware that can dynamically reorder opcode execution to maximize pipeline utilization and throughput, especially for unpredictable workloads inherent in real-time autonomous navigation.
Enhanced AI and Real-time Processing
The push towards truly autonomous drones operating in dynamic, unstructured environments requires unprecedented levels of real-time processing. This means faster and more efficient execution of opcodes related to:
- Deep Learning Inference: Accelerating opcodes for neural network operations to allow drones to make complex decisions (e.g., identifying nuanced objects, predicting human intent) with minimal latency.
- High-Bandwidth Sensor Fusion: Rapidly processing and combining data from multiple high-resolution sensors (cameras, LiDAR, radar) to create a comprehensive understanding of the environment, demanding optimized opcodes for data movement and transformation.
- Swarm Intelligence: Orchestrating complex behaviors across multiple drones will require processors capable of executing sophisticated communication and coordination opcodes at lightning speed.
Ultimately, “what is opcode” is more than just a question about computer fundamentals; it’s an inquiry into the very essence of how drones think, act, and innovate. Every advancement in drone technology, from a smoother flight to a groundbreaking autonomous mission, is a testament to the silent, tireless work of billions of opcodes executing in perfect, synchronized harmony. Understanding this foundational layer provides invaluable insight into the potential and challenges of future drone development.