
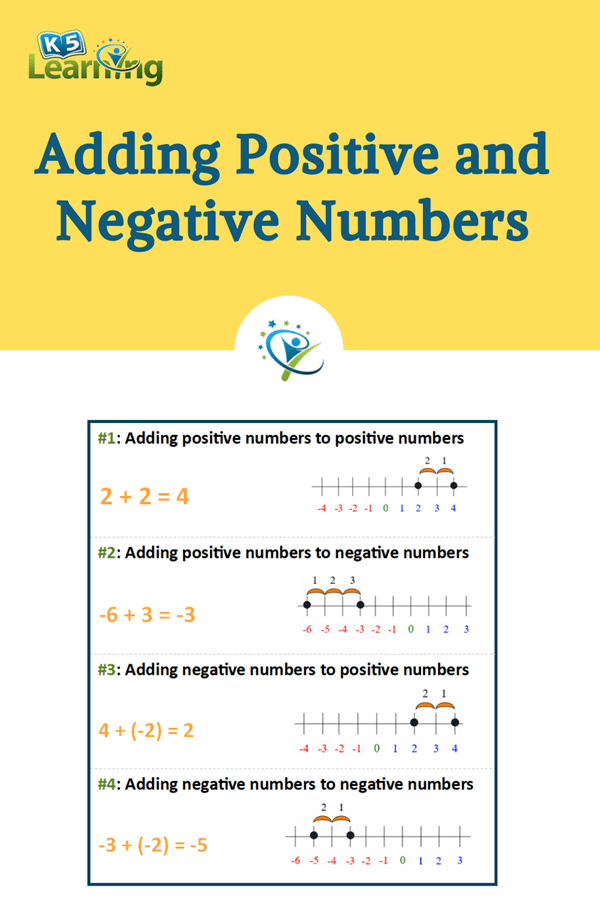
In the realm of advanced technology and innovation, the simple mathematical principle of “negative plus a negative equals a larger negative” transcends basic arithmetic. It serves as a powerful metaphor for understanding how compounding detrimental factors, minor errors, or inherent limitations can aggregate within complex systems, leading to significantly amplified challenges, failures, or suboptimal outcomes. Far from being a mere algebraic curiosity, this concept is a critical consideration in designing, deploying, and maintaining everything from autonomous flight systems and artificial intelligence algorithms to sophisticated remote sensing platforms and intricate mapping solutions. It underscores the profound impact of cumulative imperfections and the necessity for robust, resilient, and adaptive technological frameworks.

The Cumulative Effect of Imperfections in Autonomous Systems
Autonomous systems, whether drones navigating complex airspace or self-driving vehicles on urban roads, operate on a delicate balance of sensor data, algorithmic processing, and environmental understanding. Each component, while engineered to high standards, carries an inherent degree of imperfection or potential for error. When these individual “negatives” are combined, their effects can accumulate, often leading to a much larger, more critical deviation from the intended state or path.
Sensor Drift and Data Fusion Challenges
Consider an autonomous drone executing a precise mapping mission. Its navigation relies on an array of sensors: GPS for global positioning, Inertial Measurement Units (IMUs) for orientation and acceleration, altimeters for height, and vision systems for localized object recognition.
- Negative 1 (GPS Inaccuracy): In dense urban environments or under heavy foliage, GPS signals can be weak, multipath-affected, or even temporarily lost, introducing minor positioning errors.
- Negative 2 (IMU Bias and Noise): IMUs, though highly advanced, are susceptible to drift over time, temperature variations, and vibration-induced noise, leading to small but persistent errors in estimated attitude and velocity.
- Negative 3 (Environmental Factors): Gusts of wind or unexpected thermal updrafts, while not errors in the system, act as external “negatives” forcing constant corrections and potentially pushing the drone off its optimal trajectory.
Individually, each of these “negatives” might be within an acceptable tolerance. However, when these minor inaccuracies accumulate and are fed into data fusion algorithms (like Kalman filters), they don’t simply add up linearly. Instead, they can interact in complex ways, causing the drone’s estimated position and orientation to drift significantly more than any single error source would suggest. A slight miscalculation in position compounded by a subtle error in orientation and an environmental disturbance can lead to a considerable navigational error, potentially resulting in inefficient flight paths, incomplete data capture, or even collision risks. The aggregation of these small negatives creates a substantial, system-wide negative impact.
Algorithmic Vulnerabilities and Model Bias
Beyond hardware, software and algorithms also contribute to this phenomenon. In AI-driven autonomous systems, models are trained on vast datasets.
- Negative 1 (Data Imperfection): Training data might contain subtle biases or be incomplete, leading the model to learn skewed representations of reality.
- Negative 2 (Algorithmic Limitations): The chosen algorithm, while powerful, might have inherent limitations in generalizing to novel situations or processing certain edge cases effectively.
When an autonomous system, armed with a slightly biased model (Negative 2), encounters real-world scenarios that deviate subtly from its incomplete training data (Negative 1), its decision-making capabilities degrade disproportionately. What might seem like two minor negatives combine to produce significantly flawed behavior or decision paralysis, which in an autonomous context, is a critical larger negative.
Compounding Risks in Advanced Robotics and Cyber-Physical Systems
The principle of “negative plus a negative” is also crucial in understanding risk management and security within advanced robotics and cyber-physical systems. Multiple small vulnerabilities, when combined, can create a much larger window for exploitation or system failure.
Software Flaws and Hardware Limitations
Modern robotic systems are intricate blends of hardware and software. Each layer introduces potential points of failure or vulnerability.
- Negative 1 (Software Bugs): A minor bug in a firmware update might cause an intermittent communication dropout.
- Negative 2 (Hardware Aging): A motor bearing might be subtly worn, leading to occasional, uncommanded jitters.
Separately, these might be deemed low-risk issues. However, if the intermittent communication dropout occurs precisely when the worn motor jitters during a critical manipulation task, the system could enter an unforeseen state of instability, leading to equipment damage, or even posing a safety hazard. The two minor negatives converge to create a high-impact, larger negative event.
Cybersecurity and Interconnected Systems
In an increasingly interconnected technological landscape, where drones, sensors, and data platforms communicate constantly, cybersecurity threats embody this compounding effect.
- Negative 1 (Weak Authentication): A system might have slightly weaker authentication protocols for a specific API endpoint.
- Negative 2 (Unpatched Vulnerability): Another component in the network might have a known, but unpatched, vulnerability in an older library.
Individually, neither might be critical enough to warrant immediate, full-scale panic. But a sophisticated attacker could exploit the unpatched vulnerability (Negative 2) to gain initial access, then leverage the weak authentication (Negative 1) to move laterally through the system, escalating privileges and eventually compromising critical functions or exfiltrating sensitive data. The combination of these two “negatives” creates a significant security breach – a much larger negative consequence than either vulnerability would cause in isolation.
Data Degradation and Its Amplified Impact in Mapping & Remote Sensing
In mapping, remote sensing, and environmental monitoring, the quality of data is paramount. The “negative plus a negative” principle manifests starkly when imperfect data meets suboptimal processing or analysis.
Signal-to-Noise Ratio and Data Fidelity
Remote sensing platforms collect vast amounts of data, often under challenging conditions.
- Negative 1 (Environmental Attenuation): Atmospheric conditions (haze, cloud cover, water vapor) can attenuate signals from satellites or aerial sensors, reducing their fidelity.
- Negative 2 (Sensor Limitations): The sensor itself might have inherent noise characteristics, leading to slightly degraded signal-to-noise ratios even under ideal conditions.
When these two negatives occur simultaneously, the resulting imagery or data might not just be slightly blurry or less vibrant; it can become unusable for its intended purpose. For instance, detecting subtle changes in crop health or identifying specific geological features requires high data fidelity. A minor reduction in signal quality combined with inherent sensor noise can push the data below the threshold of analytical utility, rendering the entire data collection effort effectively useless – a significant larger negative for mapping or remote sensing applications.
Processing Inefficiencies and Model Bias in AI-Driven Analysis
Beyond raw data, the processing and interpretation stages also contribute.
- Negative 1 (Suboptimal Pre-processing): If data pre-processing routines are not perfectly tuned (e.g., incorrect radiometric correction parameters), subtle artifacts or inaccuracies can be introduced.
- Negative 2 (Biased AI Models): An AI model trained to interpret this data might have developed biases if its training dataset didn’t fully represent the range of conditions seen in the real world.
When slightly imperfectly pre-processed data (Negative 1) is fed into an AI model with existing biases (Negative 2), the model’s output isn’t merely slightly off; it can produce wildly incorrect classifications or analyses. For example, in precision agriculture, this could lead to misidentifying healthy crops as diseased, or vice-versa, resulting in detrimental economic and environmental impacts. The cumulative negative effect on decision-making is amplified, demonstrating that two small negatives can lead to a profoundly misleading, larger negative outcome.
Mitigating the Compounding Negatives
Recognizing that “negative plus a negative” in tech and innovation often leads to a disproportionately larger negative is the first step toward building more robust and reliable systems. Mitigation strategies focus on reducing individual negatives and preventing their synergistic accumulation.
Robust Design and Redundancy
Engineers employ principles of robust design, incorporating fault tolerance and redundancy. This includes using multiple sensors, diverse algorithms, and backup systems, ensuring that the failure or inaccuracy of one component does not cascade into a system-wide failure. For instance, an autonomous drone might fuse data from GPS, IMU, visual odometry, and LiDAR to maintain position awareness even if one sensor provides erroneous readings.
Continuous Monitoring and Anomaly Detection
Advanced monitoring systems leverage AI and machine learning to continuously analyze system performance and sensor data. These systems are designed to detect subtle anomalies or deviations that could indicate the onset of compounding negatives. By identifying these early warning signs, operators can intervene before a minor issue escalates into a major problem, effectively breaking the chain of accumulating negatives.
Rigorous Testing and Validation
Extensive testing and validation, including simulated environments and real-world trials under diverse conditions, are crucial. This helps in identifying hidden interactions between different “negative” factors that might not be apparent during individual component testing. Stress testing systems to their limits helps reveal how individual imperfections combine and how to design against their amplified impact.

Adaptive Algorithms and Machine Learning
Developing algorithms that are adaptive and capable of learning from dynamic environments helps mitigate the impact of unforeseen negatives. For example, AI models can be designed with uncertainty quantification, allowing them to indicate when their predictions might be less reliable due to ambiguous input data or novel situations, thus preventing confident but incorrect decisions.
In conclusion, the simple algebraic truth that “negative plus a negative” results in a larger negative carries profound implications for the advanced technological landscape. It compels innovators to look beyond individual component performance and consider the intricate interplay of errors, limitations, and risks within complex systems. By understanding and actively mitigating these compounding factors, we can push the boundaries of innovation more safely and effectively, transforming potential pitfalls into pathways for progress.