
Determining one’s Global Positioning System (GPS) position is a fundamental aspect of modern navigation, underpinning countless applications from personal mapping devices to sophisticated autonomous flight systems. At its core, GPS provides highly accurate location and time information anywhere on Earth or near-Earth space where there is an unobstructed line of sight to four or more GPS satellites. For flight technology, understanding the intricacies of GPS positioning is not merely academic; it is critical for navigation, stability, safety, and the very concept of autonomous operation. This exploration delves into the mechanics of how a GPS receiver calculates its position, the factors influencing its accuracy, and its indispensable role in contemporary aerial systems.
Understanding Global Positioning Systems (GPS)
The Global Positioning System is a space-based radionavigation system owned by the United States government and operated by the United States Space Force. It is one of several Global Navigation Satellite Systems (GNSS) that provide global coverage, with others including Russia’s GLONASS, Europe’s Galileo, and China’s BeiDou. Regardless of the specific constellation, the underlying principles of operation for determining position remain largely consistent.
The Satellite Constellation
The GPS system comprises a constellation of at least 24 operational satellites, though typically more are in orbit, circling the Earth in medium Earth orbit (MEO) at an altitude of approximately 20,200 kilometers (12,550 miles). These satellites are distributed across six orbital planes, ensuring that at any given time, at least four to six satellites are visible from virtually any point on Earth. Each satellite continuously transmits radio signals containing precise orbital information (ephemeris), its clock data, and a unique pseudo-random code. The extreme altitude and specific orbital patterns are crucial for maximizing coverage and ensuring signal availability across vast geographical areas, enabling seamless navigation for aerial vehicles traversing long distances.
How Signals Are Transmitted and Received
Each GPS satellite carries atomic clocks, which are incredibly accurate timekeeping devices. These clocks synchronize to a master ground control clock, ensuring precise timing across the entire constellation. The satellites broadcast their position and the exact time the signal was sent. A GPS receiver on Earth, whether in a smartphone, a car, or an advanced flight controller, listens for these signals. Upon receiving a signal from a satellite, the receiver notes the time the signal was received and compares it to the timestamp embedded in the signal. The difference between these two times, multiplied by the speed of light, directly indicates the distance between the receiver and that particular satellite. This seemingly simple calculation forms the bedrock of GPS positioning, requiring highly stable atomic clocks on the satellites and sophisticated signal processing within the receiver.
The Science of Trilateration: Pinpointing Your Location
The fundamental method by which a GPS receiver determines its position is called trilateration. While often confused with triangulation, which uses angles, trilateration relies solely on distance measurements.
Time and Distance Measurement
To perform trilateration, a GPS receiver must first establish its distance from multiple satellites. As explained, it calculates the time delay for signals traveling from the satellite to the receiver. This delay, Δt, multiplied by the speed of light, c (approximately 299,792,458 meters per second), gives the distance d = c * Δt. However, accurately measuring this minuscule time delay requires an extremely precise clock within the receiver. Since consumer-grade GPS receivers do not contain atomic clocks due to cost and size constraints, they have a less accurate quartz clock. This clock difference introduces a uniform bias (error) in all distance measurements.
From Data to Coordinates
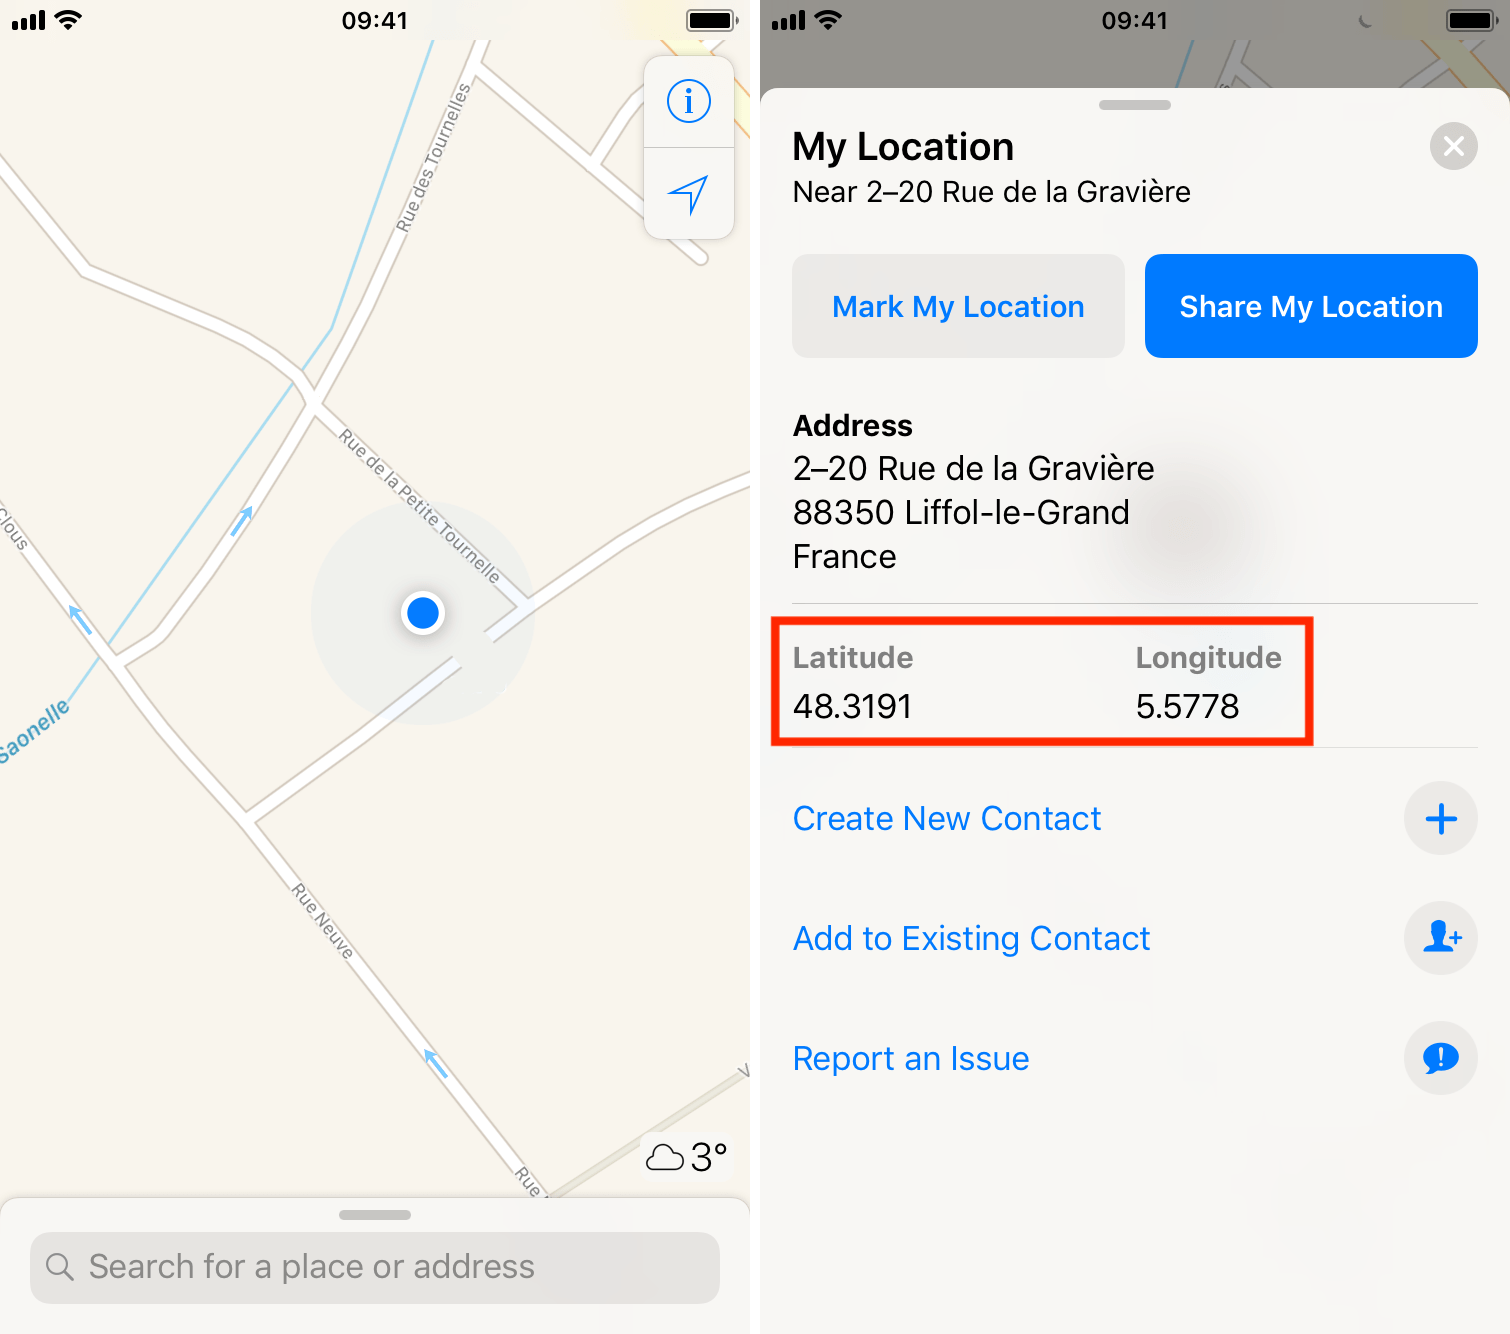
To solve for the unknown receiver position (three spatial coordinates: latitude, longitude, and altitude) and its clock bias (the fourth unknown), a GPS receiver needs measurements from at least four satellites.
- With one satellite, the receiver knows it is located somewhere on the surface of a sphere centered on that satellite, with a radius equal to the calculated distance.
- With two satellites, the receiver knows it is on the intersection of two spheres, which forms a circle in space.
- With three satellites, the receiver’s position is narrowed down to the intersection of three spheres, typically resulting in two possible points. One point is usually nonsensical (e.g., thousands of miles in space or moving at impossible speeds) and can be discarded.
- With four (or more) satellites, the system can simultaneously solve for the three spatial coordinates (x, y, z or latitude, longitude, altitude) and the receiver’s internal clock bias. The additional satellite provides redundancy and allows the receiver to correct for its internal clock’s inaccuracy, effectively making the receiver’s clock as precise as an atomic clock for the purpose of position calculation. This mathematical process transforms raw distance data into precise geographical coordinates, providing the essential “what is my GPS position” answer.
Factors Affecting GPS Accuracy and Reliability
While GPS is remarkably powerful, its accuracy and reliability can be influenced by several factors inherent in signal transmission and reception. Understanding these limitations is crucial for mission planning and ensuring the safe operation of aerial platforms.
Atmospheric Interference and Signal Noise
As GPS signals travel from satellites through the Earth’s atmosphere, they encounter varying densities of gases and water vapor, particularly in the ionosphere and troposphere. These atmospheric layers can bend and slow down the radio signals, causing delays that are not uniformly predictable. This phenomenon, known as atmospheric delay, leads to errors in distance calculations. Furthermore, various sources of electromagnetic interference, from natural phenomena to man-made electronic devices, can introduce noise into the received signals, degrading their quality and making accurate processing more challenging.
Multipath Error and Satellite Geometry
Multipath error occurs when a GPS signal reaches the receiver not only directly but also indirectly after bouncing off surfaces like buildings, terrain, or the aerial platform itself. These reflected signals travel a longer path, causing an erroneous longer distance measurement and thus corrupting the position calculation. In complex environments, such as urban canyons or mountainous regions, multipath can significantly degrade accuracy.
Satellite geometry, often quantified by the Dilution of Precision (DOP), also plays a crucial role. DOP describes the geometrical strength of the satellite configuration as seen by the receiver. When satellites are clustered together in a small part of the sky (high DOP), small errors in distance measurements can result in large position errors. Conversely, when satellites are widely spread out across the sky (low DOP), the geometry is strong, and the same measurement errors lead to smaller position errors. For optimal accuracy, aerial vehicles ideally operate where satellites are well-distributed.
Augmentation Systems: SBAS, RTK, and PPK
To counteract these inherent limitations and enhance positional accuracy, various augmentation systems have been developed.
- Satellite-Based Augmentation Systems (SBAS) like WAAS (Wide Area Augmentation System) in North America, EGNOS in Europe, and MSAS in Japan, use ground stations to monitor GPS satellite signals. These stations calculate real-time errors and broadcast correction messages via geostationary satellites to GPS receivers. SBAS typically improves accuracy to within 1-2 meters.
- Real-Time Kinematic (RTK) GPS and Post-Processed Kinematic (PPK) GPS offer even greater precision, often down to centimeter-level accuracy. These systems use a stationary base station at a known, precisely surveyed location. The base station calculates errors in the GPS signals and transmits these corrections to a moving “rover” receiver (e.g., on an aerial vehicle). RTK provides these corrections in real-time, while PPK applies them after the data collection, offering flexibility for missions where real-time connectivity is challenging. For applications like aerial mapping, surveying, and precision agriculture, RTK/PPK are transformative, enabling highly detailed data collection and accurate flight paths.
GPS as the Cornerstone of Modern Flight Navigation
The precise positioning capabilities of GPS, especially when augmented, have made it an indispensable technology for virtually all forms of modern flight, from commercial airliners to sophisticated autonomous unmanned aerial vehicles (UAVs).
Autonomous Flight and Waypoint Navigation
For autonomous flight systems, GPS is the primary sensor for determining the aerial vehicle’s absolute global position. This information is fed into the flight controller, which then calculates the necessary control inputs to guide the aircraft along pre-programmed flight paths or to specific waypoints. Without accurate GPS data, complex autonomous maneuvers, programmed patrols, or even simple “return-to-home” functions would be impossible. GPS provides the spatial reference framework that allows the flight controller to know exactly where it is, where it needs to go, and how fast it is moving relative to the Earth’s surface.
Geofencing and Safety Protocols
GPS also plays a vital role in implementing safety protocols such as geofencing. A geofence is a virtual boundary defined by GPS coordinates. Flight controllers can be programmed to prevent an aerial vehicle from flying beyond this boundary, automatically returning it or hovering in place if it approaches the limit. This capability is critical for preventing flight into restricted airspace, avoiding sensitive areas, or ensuring operations remain within visual line of sight or designated flight zones. Furthermore, GPS provides critical data for collision avoidance systems, helping identify the positions of other aircraft or obstacles relative to the vehicle’s own trajectory.
Stabilization and Attitude Control
While dedicated Inertial Measurement Units (IMUs) provide the primary data for an aerial vehicle’s attitude (pitch, roll, yaw) and short-term stabilization, GPS data often augments these systems, particularly for velocity and position hold functions. By providing accurate ground speed and drift information, GPS helps the flight controller maintain a stable hover in windy conditions or precisely follow a trajectory, correcting for external forces that an IMU alone might not fully compensate for over longer periods. This integration of GPS with IMUs creates a robust navigation solution, compensating for the drift inherent in IMU systems and enhancing overall flight stability.
The Future of Precise Positioning in Flight
The evolution of GPS and GNSS technology continues to push the boundaries of what’s possible in flight navigation and autonomy.
Multi-Constellation and Multi-Frequency Receivers
Modern GPS receivers are increasingly multi-constellation, meaning they can simultaneously receive signals from GPS, GLONASS, Galileo, and BeiDou satellites. By incorporating more satellites into the position solution, these receivers improve accuracy, availability (especially in challenging environments), and redundancy. Furthermore, multi-frequency receivers are becoming standard. Satellites transmit signals on multiple frequencies (e.g., L1, L2, L5 for GPS). By analyzing signals from different frequencies, receivers can more accurately model and mitigate atmospheric delays, significantly enhancing precision, particularly beneficial for high-accuracy applications like aerial mapping and survey.

Inertial Navigation System (INS) Integration
The tight integration of GPS with Inertial Navigation Systems (INS) represents the pinnacle of modern flight positioning technology. An INS uses accelerometers and gyroscopes to track changes in position and orientation, providing high-rate, short-term accuracy, especially useful during GPS signal outages or in environments with poor satellite visibility. However, INS systems suffer from drift over time. GPS, on the other hand, provides absolute, long-term position accuracy but at a lower update rate and can be susceptible to signal loss. By fusing data from both systems, a robust Kalman filter algorithm can leverage the strengths of each, providing continuous, highly accurate position, velocity, and attitude data that is resilient to individual sensor limitations. This integrated GPS/INS solution is paramount for the most demanding autonomous flight applications, ensuring continuous and reliable “what is my GPS position” answers under a wide range of operational conditions.
Ultimately, GPS technology, in its various forms and integrations, remains the bedrock upon which the precision, safety, and autonomous capabilities of modern flight are built. Its ongoing evolution promises even greater accuracy and reliability, opening new frontiers for aerial innovation.