
In the rapidly evolving landscape of drone technology, where computational demands often outpace traditional processing capabilities, multi-threading emerges as a foundational concept enabling the sophisticated features we now expect from modern unmanned aerial vehicles (UAVs). At its heart, multi-threading is a programming and execution model that allows multiple segments of a program to run concurrently within a single process. Far from a mere technical detail, it is a critical enabler for the real-time responsiveness, complex decision-making, and advanced functionalities that define innovative drone systems, from AI-powered autonomous flight to high-fidelity mapping and remote sensing.
The Core Concept of Concurrency
To understand multi-threading, it’s essential to grasp the idea of concurrency – the ability of different parts of a program or system to be executed independently, potentially at the same time. While true simultaneous execution (parallelism) requires multiple processing cores, concurrency can also be achieved on a single core through rapid switching between tasks, giving the illusion of simultaneous execution.

Single-Threaded vs. Multi-Threaded Execution
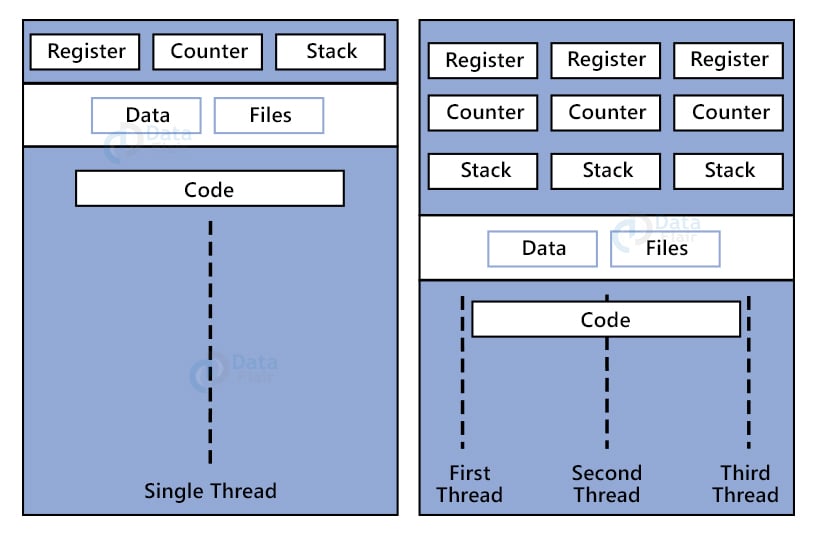
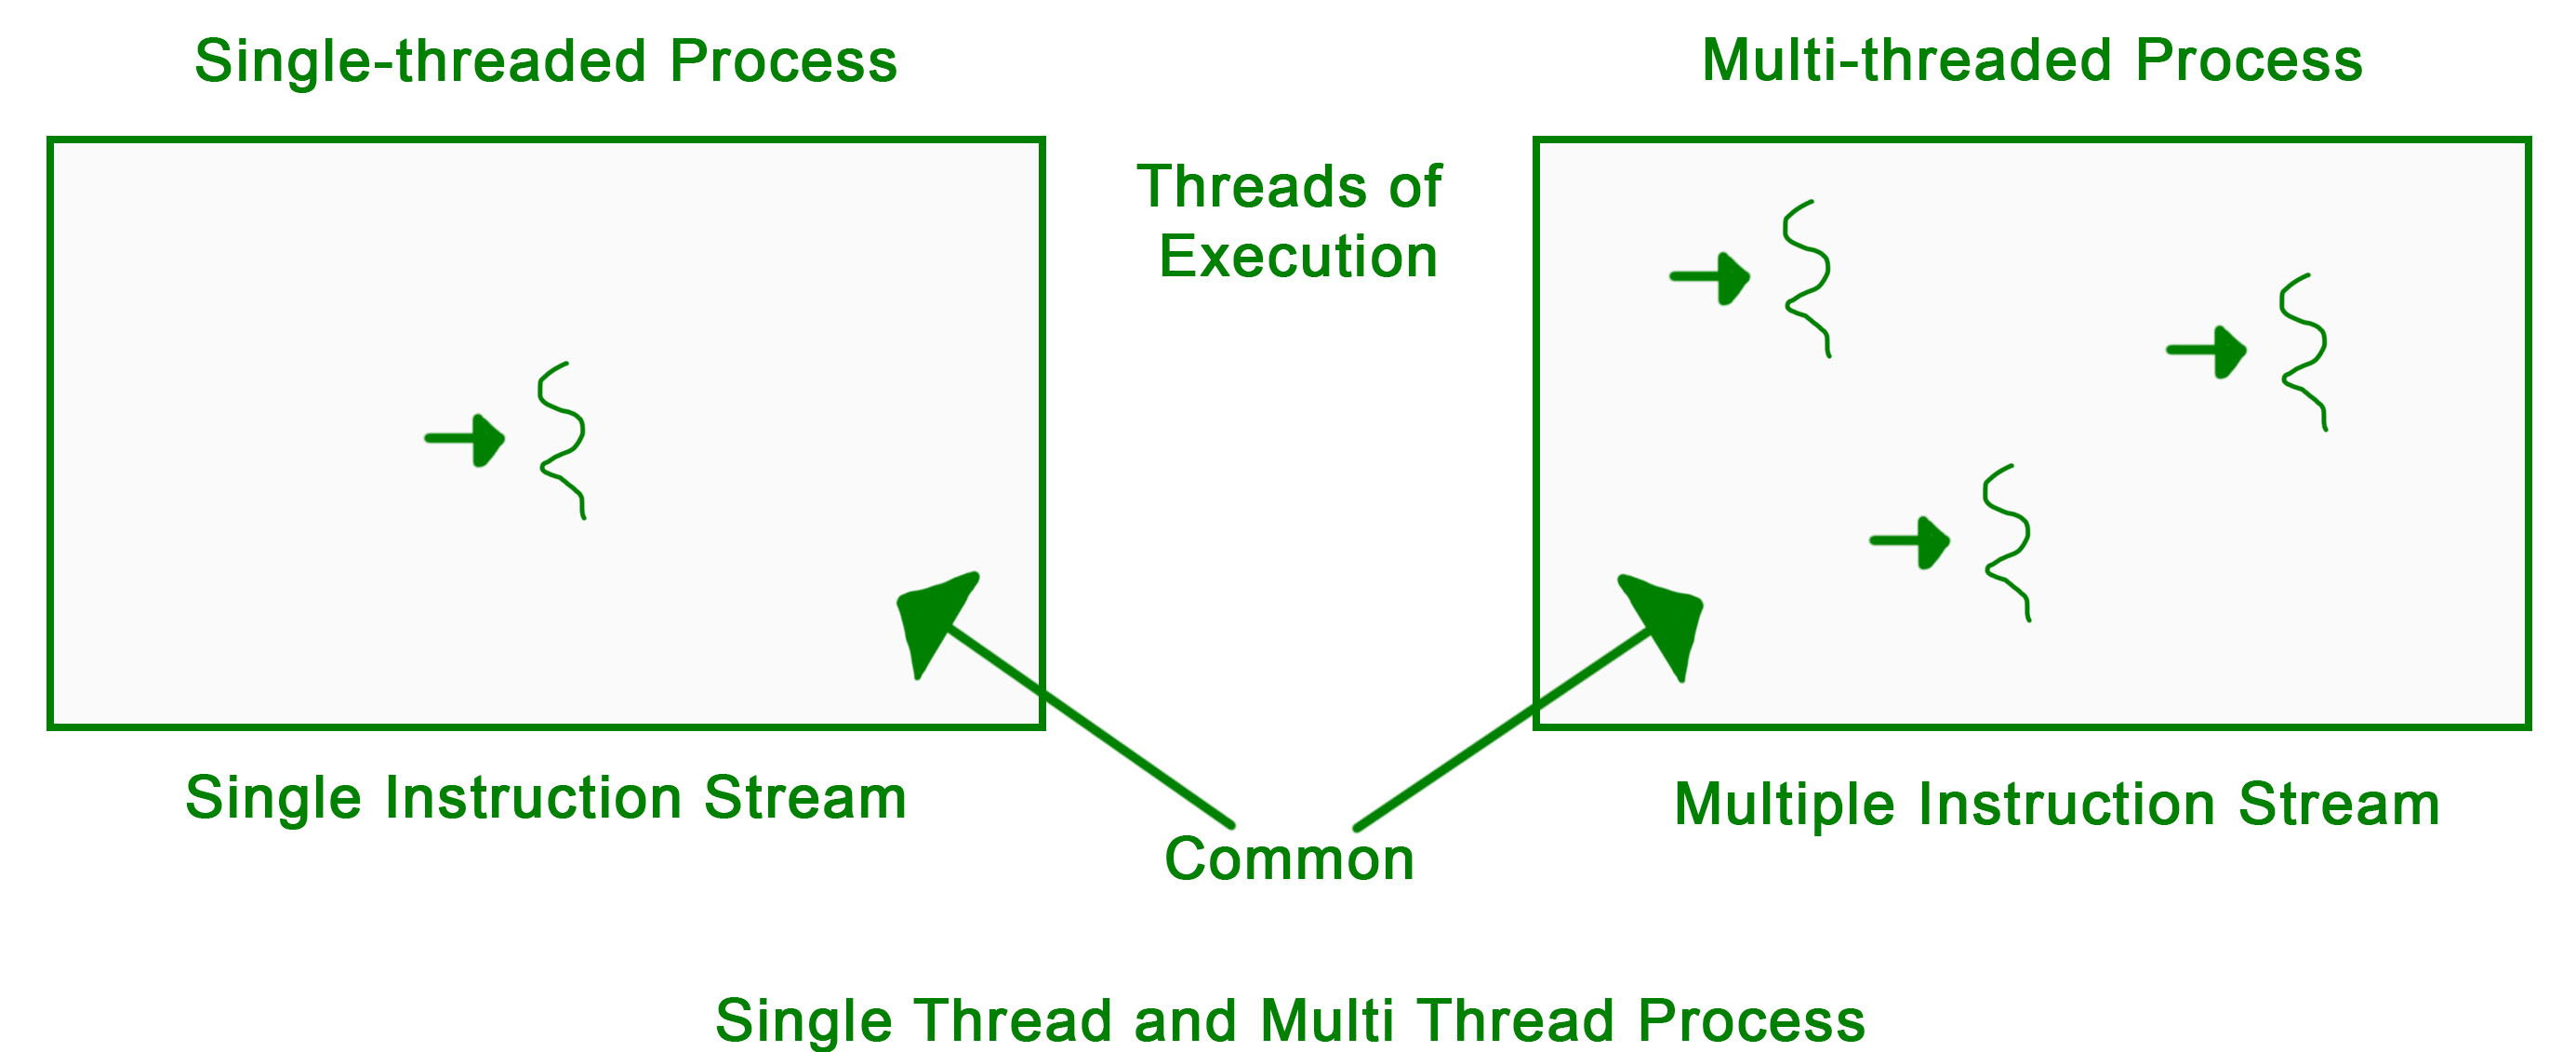
Traditionally, many applications operated in a single-threaded manner. This means that a program executes a sequence of instructions one after another. If one task is computationally intensive or waiting for an external event (like data from a sensor), the entire application can become unresponsive until that task completes. Imagine a drone’s flight controller trying to process video, analyze sensor data, and calculate flight corrections all in a single, sequential stream. Any delay in one task would directly impact the responsiveness of the others, potentially leading to instability or missed critical events.
Multi-threading breaks this paradigm. A multi-threaded program divides its workload into smaller, independent units called threads. Each thread can run somewhat independently of the others. For example, one thread might be responsible for reading sensor data, another for executing the flight control algorithm, a third for transmitting telemetry, and a fourth for processing video feeds. This concurrency allows the drone’s system to perform multiple tasks seemingly at the same time, significantly improving responsiveness and overall efficiency.
Threads and Processes
It’s important to distinguish between threads and processes. A process is an independent execution environment that typically includes its own memory space, files, and resources. Multiple processes generally run independently of each other. A thread, on the other hand, is a lightweight unit of execution within a process. Threads within the same process share the same memory space and resources, making communication and data sharing between them more efficient than between separate processes. This shared resource model is both a strength and a challenge of multi-threading, as it necessitates careful management to prevent conflicts.
Why Multi-threading Matters in Drone Technology
The unique operational environment of drones—characterized by dynamic conditions, stringent safety requirements, and complex, real-time data processing—makes multi-threading not just beneficial, but often indispensable.
Real-Time Performance and Responsiveness
Drones operate in a physical world that demands immediate reaction. A flight controller must constantly sample gyroscopes, accelerometers, magnetometers, and GPS data, then rapidly compute corrective motor commands to maintain stability or follow a path. If these tasks were sequential, even minor delays could lead to instability or loss of control. Multi-threading ensures that critical control loops can run at very high frequencies, unburdened by less time-sensitive tasks like logging data, managing user interface updates, or transmitting video. By dedicating separate threads to these functions, the core flight control can achieve the low-latency responsiveness crucial for safe and precise flight. This is particularly vital for racing drones, FPV systems, and any application requiring swift, agile maneuvers.
Efficient Resource Utilization
Modern drone processors, especially those in more advanced UAVs, often feature multiple CPU cores. Single-threaded applications can only fully utilize one of these cores at any given time, leaving the others idle. Multi-threading allows developers to distribute computational workloads across multiple cores, effectively harnessing the full processing power of the embedded system. This parallel execution dramatically increases throughput, meaning the drone can perform more computations per unit of time. For example, processing high-resolution imagery for mapping or running complex AI algorithms for object recognition benefits immensely from being spread across multiple cores via multi-threading, completing tasks faster and more efficiently. This efficient use of hardware resources directly translates to better performance, lower power consumption (as tasks can finish sooner, allowing the system to idle), and the ability to integrate more sophisticated features without requiring proportionally more powerful, heavier, and more expensive hardware.
Multi-threading in Advanced Drone Applications
The true impact of multi-threading becomes evident when examining the advanced capabilities that define the cutting edge of drone technology.
Autonomous Navigation and Obstacle Avoidance
Autonomous flight relies on a cascade of sensor data processing, environmental modeling, path planning, and real-time control adjustments.
- Sensor Fusion: Drones integrate data from multiple sensors—LIDAR, ultrasonic, stereo cameras, GPS, IMUs. Dedicated threads can simultaneously process data streams from each sensor, performing calibration, noise reduction, and timestamp synchronization. Another thread might then fuse this processed data to create a unified understanding of the drone’s state and environment.
- Environmental Mapping: Building a 3D map of the surroundings for obstacle avoidance or path planning is computationally intensive. Threads can concurrently handle point cloud processing, voxel grid updates, and occupancy grid generation.
- Path Planning and Re-planning: Algorithms for dynamic path planning, especially in complex or unknown environments, benefit from multi-threading. One thread might run the primary path planner, while another continuously monitors for new obstacles and triggers re-planning in a separate thread, ensuring the main control loop isn’t interrupted.
AI-Powered Features (Follow Mode, Object Recognition)
Artificial intelligence is transforming drone capabilities, and multi-threading is a cornerstone of this revolution.
- AI Follow Mode: For a drone to autonomously follow a subject, it must continuously perform several tasks: capture video frames (one thread), detect and track the subject within those frames using machine learning models (another thread), predict the subject’s movement, and generate corresponding flight commands (a third thread) to maintain optimal distance and angle. All these must happen in real-time, often at high frame rates, making multi-threading essential for smooth, reliable tracking.
- Object Recognition and Classification: Drones used for inspection, security, or delivery might need to identify specific objects or anomalies. Processing high-resolution camera feeds through deep learning models for real-time object detection and classification is a heavy computational load. Multi-threading allows different parts of the neural network inference to run in parallel or enables the processing of multiple image regions simultaneously, accelerating the decision-making process.
Data Processing for Mapping and Remote Sensing
Mapping and remote sensing applications involve capturing vast amounts of data (imagery, LiDAR points, multispectral data) and processing it into actionable intelligence.
- Photogrammetry: Creating 3D models and orthomosaics from overlapping 2D images is highly parallelizable. Threads can independently process image pairs for feature matching, depth estimation, and triangulation, significantly reducing the time required to generate detailed maps and models.
- Hyperspectral and Multispectral Analysis: Processing data from specialized sensors for agricultural analysis, environmental monitoring, or geological surveys often involves complex algorithms that can be broken down into parallel tasks for multi-threaded execution. This allows for faster analysis of large datasets, providing timely insights.
- Real-time Edge Processing: Some advanced drones are moving towards processing data on-board rather than sending everything to the cloud. Multi-threading is crucial for these “edge computing” scenarios, enabling the drone to perform complex analytics like anomaly detection or vegetation index calculation in real-time while in flight.
Challenges and Considerations in Multi-threaded Drone Systems
While multi-threading offers immense benefits, it also introduces complexities that require careful engineering.
Synchronization and Data Integrity
Since threads within the same process share memory, there’s a risk of multiple threads trying to access and modify the same data simultaneously. This can lead to race conditions, where the outcome depends on the non-deterministic timing of thread execution, resulting in corrupted data or unpredictable program behavior. Developers must employ synchronization mechanisms like mutexes, semaphores, and locks to ensure that only one thread accesses a critical section of code or shared data at any given time. Proper synchronization is paramount to maintaining data integrity and system stability in a drone, where incorrect sensor readings or flight commands could have catastrophic consequences.
Debugging and Complexity
Multi-threaded applications are inherently more complex to design, implement, and debug than their single-threaded counterparts. Issues like deadlocks (where two or more threads are blocked indefinitely, waiting for each other to release a resource) or livelocks (where threads repeatedly change state without making progress) can be difficult to diagnose and reproduce. Tools for multi-threaded debugging are essential, and a thorough understanding of concurrency principles is required to build robust and reliable drone software. The non-deterministic nature of thread scheduling means that bugs might only appear intermittently, making their identification particularly challenging.
Hardware and Software Synergy
The effectiveness of multi-threading is deeply intertwined with the underlying hardware architecture. An efficient multi-threaded design must consider the number of available CPU cores, cache hierarchies, and memory bandwidth of the drone’s flight controller or companion computer. Software engineers must optimize their thread allocation and workload distribution to maximize parallelism and minimize communication overhead between threads. Furthermore, the choice of operating system (e.g., real-time operating systems like FreeRTOS or Linux variants with real-time patches) and programming languages (e.g., C++ with its robust concurrency libraries, or Python with its Global Interpreter Lock implications) also play a significant role in realizing the full potential of multi-threading in drone systems.
In conclusion, multi-threading is more than just a programming technique; it is a critical enabler for the next generation of drone innovation. By allowing complex tasks to run concurrently, it empowers drones with the responsiveness, intelligence, and processing power necessary to navigate intricate environments, perform sophisticated AI-driven tasks, and deliver advanced data insights, pushing the boundaries of what unmanned aerial systems can achieve.