
The concept of “locus of control,” originating in psychology, refers to the degree to which individuals believe they have control over the outcomes and events that affect their lives. An individual with an “internal locus of control” believes their own actions and efforts primarily determine their destiny, embracing personal responsibility and agency. Conversely, someone with an “external locus of control” tends to attribute outcomes to outside forces, such as luck, fate, or the actions of others. While traditionally applied to human psychology, this fundamental framework offers a remarkably insightful lens through which to understand the evolving dynamics of control, decision-making, and responsibility within advanced drone technology, particularly in the realm of Tech & Innovation. By re-contextualizing this definition, we can better comprehend the intricate interplay between human operators and increasingly autonomous systems, illuminating the shift in where the “control” or “agency” for mission execution resides.

Navigating Autonomy: The Core Concept Applied to Drones
When we apply the concept of locus of control to drone operations, we are not attributing psychological traits to machines, but rather examining where the effective agency for decision-making is located within the operational ecosystem. In the early days of drone technology, the locus of control was unequivocally internal to the human pilot. Every maneuver, every altitude adjustment, every camera pan was a direct consequence of human input. The pilot was the singular orchestrator, bearing the full cognitive load and responsibility for the flight path and mission outcomes.
However, as drone technology rapidly advanced through stages of Tech & Innovation, this clear-cut internal locus began to blur. The introduction of assisted flight modes like GPS position hold, automated return-to-home functions, and basic stability systems marked the first significant steps towards externalizing aspects of control. While the human pilot remained the primary authority, certain micro-decisions and stabilization tasks were offloaded to the drone’s onboard systems. This initial shift laid the groundwork for a more profound transformation, gradually redefining the relationship between human and machine, and challenging the traditional understanding of where the ultimate control resided. Understanding this evolving distribution of control is crucial for both designing future systems and training operators to effectively manage these increasingly intelligent aerial platforms.
Internal Locus: The Pilot as Primary Decision-Maker
In many drone applications, particularly those demanding high precision, real-time adaptation, or creative improvisation, the human pilot remains the indisputable internal locus of control. This paradigm emphasizes human skill, intuition, and immediate responsiveness, positioning the operator as the primary decision-maker and executor of the flight.
Direct Control and Manual Flight: In scenarios like FPV (First Person View) racing, acrobatic displays, or complex aerial cinematography requiring intricate, spontaneous maneuvers, the pilot directly controls every aspect of the drone’s movement. Here, the internal locus of control is absolute; the drone acts as an extension of the pilot’s will, translating their joystick inputs into precise aerial dynamics. The pilot’s spatial awareness, reaction time, and ability to process environmental cues in real-time are paramount. Success or failure is directly attributed to the pilot’s actions and expertise, reinforcing their internal locus of control over the flight outcome. This direct human intervention is irreplaceable when dealing with highly dynamic, unpredictable environments or when artistic interpretation is key.
Responsibility and Accountability: With an internal locus of control firmly vested in the pilot, comes the full weight of responsibility and accountability. In manual flight, the pilot is solely answerable for maintaining safe flight paths, avoiding obstacles, adhering to regulations, and ensuring the successful completion of the mission. This deep sense of ownership is characteristic of an internal locus, where the individual attributes outcomes directly to their own capabilities and decisions. This human-centric control model, while powerful, inherently faces limitations tied to human factors such as fatigue, cognitive overload, line-of-sight restrictions, and the finite speed of human reaction, paving the way for the integration of advanced autonomous systems.
External Locus: The Rise of Autonomous Systems
The exponential growth in drone capabilities, driven by advancements in artificial intelligence, sensor fusion, and computational power, has profoundly shifted the locus of control from the human operator to the drone’s onboard intelligence in many operational contexts. This “externalization” of control refers to the phenomenon where decision-making agency for specific tasks or entire missions resides with the drone’s autonomous systems, rather than constant human input.
AI as the “External” Controller: It’s important to clarify that attributing an “external locus of control” to an autonomous drone does not imply a psychological state within the machine. Rather, it signifies that the operational agency—the real-time decision-making, execution, and adaptation—for certain functions has moved outside the immediate, continuous command of the human pilot. The drone’s intelligent algorithms, powered by its sensors, become the primary decision-maker for specific tasks, effectively acting as an externalized control mechanism from the human’s perspective.

- AI Follow Mode: A prime example is AI Follow Mode, where a drone autonomously tracks a moving subject, adjusting its speed, altitude, and camera angle to maintain a perfect shot without constant human intervention. The locus of control for maintaining the relative position to the subject resides entirely within the drone’s AI system. The human operator typically initiates the mode and monitors, but the granular flight control is externalized.
- Autonomous Flight Planning & Execution: For tasks like infrastructure inspection, agricultural spraying, or mapping, drones can execute complex pre-programmed missions. The human sets the overall parameters (e.g., flight path, altitude, sensor settings), but the drone’s internal navigation and flight control systems manage the detailed execution. It autonomously navigates waypoints, compensates for environmental factors like wind, and can even dynamically adjust its path around detected obstacles. Here, the locus of operational control for mission specifics shifts substantially to the drone’s AI.
- Obstacle Avoidance Systems: Advanced drones are equipped with sophisticated sensor arrays (vision, radar, lidar) that allow them to detect and autonomously avoid obstacles in real-time. If an unforeseen object enters its path, the drone’s externalized control system makes the immediate decision to brake, ascend, or reroute to prevent a collision, often faster and more reliably than a human operator could react. The decision to alter course resides solely with the drone’s intelligent systems.
- Remote Sensing and Precision Mapping: In applications requiring highly accurate data collection, drones often execute precise, grid-based flight patterns. Their internal navigation systems maintain exact altitude, speed, and spacing between flight lines, compensating for terrain variations or wind gusts without continuous pilot input. The locus of maintaining this precision and coverage integrity resides predominantly with the drone’s automated flight controller and mapping software.
Trust, Oversight, and Human-Machine Teaming
This externalization of control fundamentally transforms the human operator’s role from a direct manipulator to a supervisor, monitor, and manager of autonomous systems. This shift necessitates the development of trust in automated systems, a nuanced understanding of their capabilities and limitations, and proficiency in human-machine teaming. Effective Human-Machine Interfaces (HMI) become critical, designed to provide clear situational awareness, facilitate seamless handover of control when necessary, and enable operators to intervene safely and effectively. Crucially, while the “locus of operational control” may shift to the machine, the “locus of ultimate responsibility” for the mission’s outcome, ethical implications, and safety remains with the human operator or the organization deploying the drone. This distinction is vital for regulatory frameworks and accountability.
The Distributed Locus: Swarms and Fleet Management
Beyond individual drone autonomy, the concept of locus of control becomes even more intricate when considering multi-drone operations, known as swarms, and centralized fleet management systems. Here, the control is not merely externalized from a single human to a single machine, but often distributed across multiple agents or managed by a higher-level AI.
Beyond Single-Drone Autonomy: As drone technology matures, the ability to coordinate multiple drones for complex tasks unlocks unprecedented capabilities. This transition moves beyond the simple human-machine dyad to a more complex network of intelligent systems working in concert.
- Swarm Intelligence: In a drone swarm, the “locus of control” is highly distributed. Instead of a single master controller (human or AI) dictating every move, individual drones operate based on simple rules and local information, often reacting to their immediate neighbors and environment. This decentralized approach allows for emergent behaviors that enable the swarm to perform complex tasks, such as collaborative mapping of large areas, coordinated search and rescue, or even artistic light shows. The overall mission objective is set by a human, but the moment-to-moment operational control for achieving that objective is spread across the collective intelligence of the swarm. Defining accountability and predicting emergent behaviors in such highly distributed systems presents unique challenges for the traditional understanding of control.
- Fleet Management Systems: For large-scale commercial and industrial applications—like automated package delivery networks, agricultural monitoring across vast farms, or surveillance of critical infrastructure—a sophisticated, centralized fleet management system often acts as a higher-level “external locus of control.” This advanced AI system manages the entire ecosystem of drones: dispatching missions, optimizing flight paths to avoid congestion and conserve energy, handling charging logistics, and even coordinating responses to unforeseen events. Human operators transition to overseeing the fleet management system itself, setting high-level strategic goals, and intervening only when exceptions or critical anomalies occur. The detailed operational control for an entire fleet of drones rests with this overarching AI.
Ethical Frameworks and Future Regulatory Landscapes
The increasing distribution and externalization of control necessitate profound ethical considerations and a complete overhaul of regulatory frameworks. Who is ultimately accountable when a swarm exhibits unexpected behavior leading to an incident? How do we establish liability when an AI-driven fleet management system makes a decision that results in an adverse outcome, with minimal human intervention? The need for robust auditing trails, explainable AI (XAI) to understand autonomous decision-making processes, and clearly defined lines of responsibility become paramount. Regulators face the complex task of developing new standards for certifying autonomous systems, licensing operators for supervision rather than direct flight, and ensuring public safety in an airspace shared by increasingly intelligent machines, where the “locus of control” for individual flight actions predominantly resides within machine intelligence.
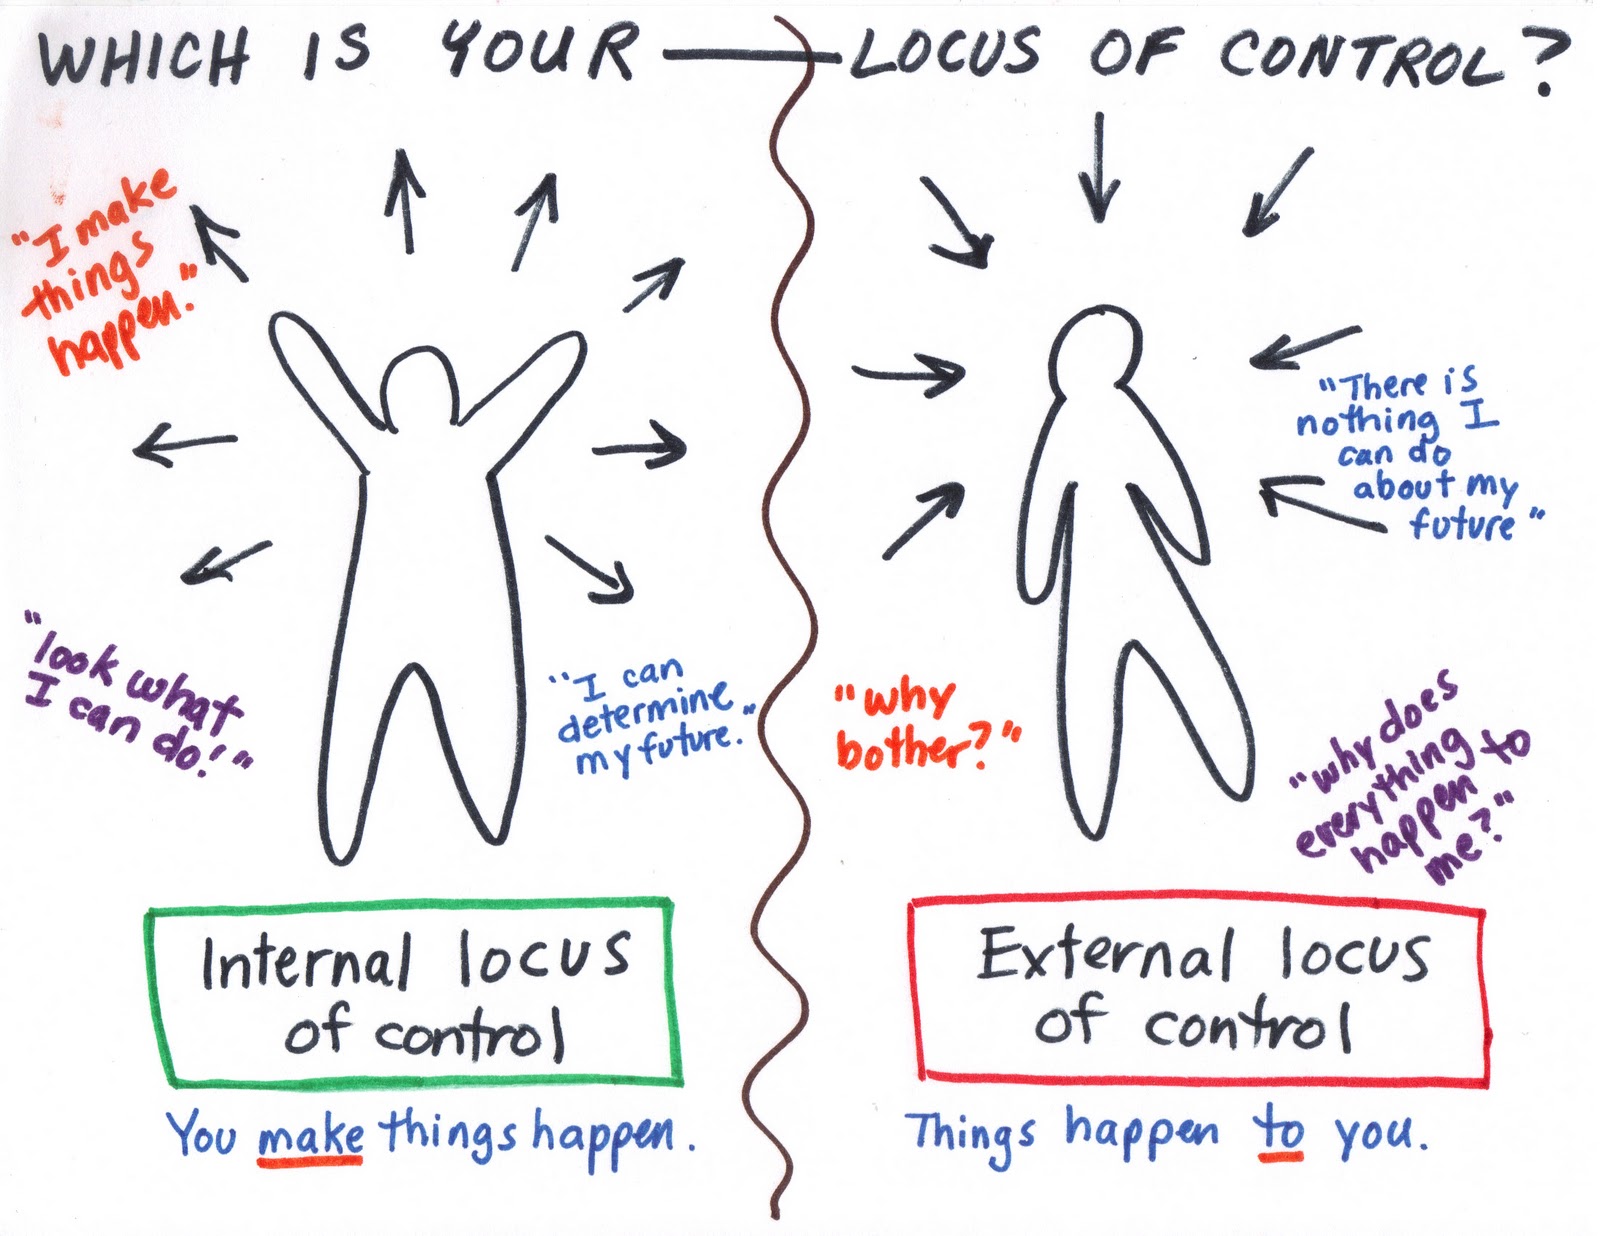
Cultivating the Right Mindset: Internal Locus for Innovation
While advanced drone technologies increasingly externalize the operational locus of control to autonomous systems, the human element—particularly within the domains of development, strategy, and oversight—demands a strong internal locus of control. The very architects, engineers, and strategists behind these innovations must possess an unwavering belief in their capacity to shape the future of autonomous flight. This internal locus fuels the relentless pursuit of technological breakthroughs, the intricate problem-solving required to develop safer and more capable AI, and the ethical foresight needed to deploy these powerful tools responsibly. It’s the conviction that human ingenuity can define and direct the trajectory of drone evolution.
For the operators and supervisors of these complex systems, understanding where the operational locus of control resides at any given moment is critical. However, cultivating an internal locus of control in their own professional approach is equally vital. This involves taking responsibility for understanding the capabilities and limitations of autonomous drones, actively engaging in training to monitor and manage these systems, and possessing the critical judgment to intervene when necessary. It’s about not simply accepting the drone’s autonomous actions but taking ownership of the supervisory role, ensuring mission integrity, and upholding safety standards. This proactive, responsible stance reflects a mature internal locus—the belief that through their oversight, programming, and maintenance, they exert a profound influence on the outcomes. The continuous drive towards more intelligent, resilient, and ethically sound autonomous systems fundamentally relies on this human agency and an internal belief in the power to control and direct technological advancements, ultimately defining the future landscape of drone innovation.