
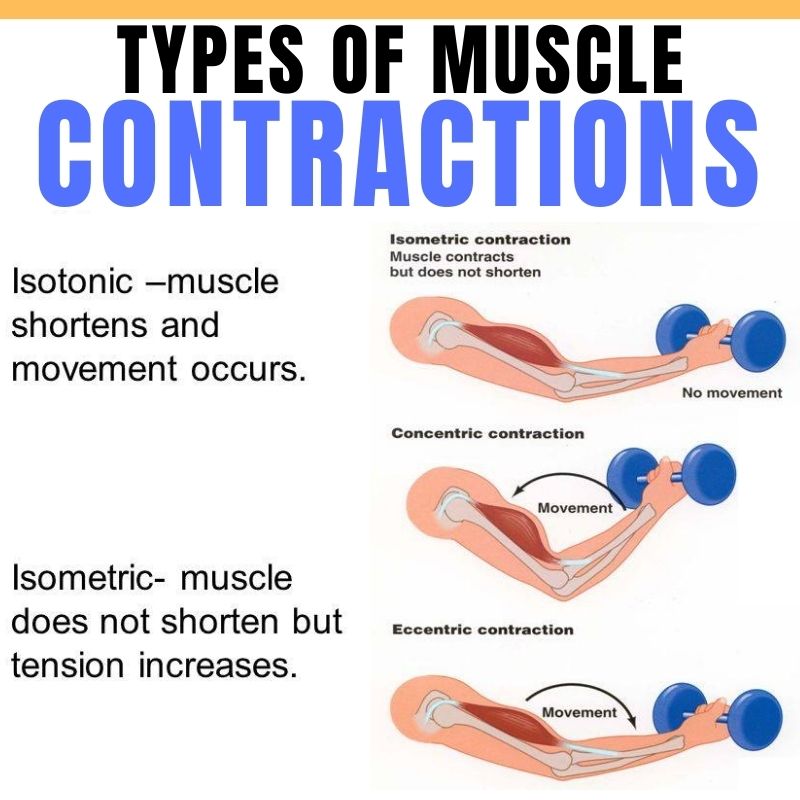
The foundation of precise control and sustained effort in both human operation and advanced robotic systems lies in understanding fundamental biomechanical principles. Among these, isometric muscle contraction stands out as a critical concept, especially when considering the intricate demands of modern flight technology and drone innovation. Unlike dynamic movements, where muscles shorten or lengthen to produce motion, an isometric contraction involves muscle activation without a change in muscle length or joint angle. This seemingly static form of muscular engagement is, paradoxically, the bedrock of stability, sustained force, and fine motor control—qualities indispensable for drone pilots and inspiration for autonomous systems.

The Biomechanics of Static Strength and Stability in Human-Machine Interaction
At its core, an isometric muscle contraction is a form of muscular effort where the muscle generates tension without changing its overall length. Imagine holding a drone controller perfectly still to maintain a precise hover, or gripping it firmly without visible movement in your fingers. In these instances, your muscles are working, energy is being expended, but no gross movement is occurring at the joint. This is in contrast to isotonic contractions, where muscles either shorten (concentric) or lengthen (eccentric) to produce movement against a load. The key distinction for isometric action is that the external resistance precisely matches the force generated by the muscle, resulting in a net zero change in joint position. This principle is vital for understanding how human operators maintain control and how sophisticated drone systems achieve stability.
Understanding Muscle Contraction Fundamentals for Ergonomic Design
Muscles are composed of numerous fibers containing contractile proteins (actin and myosin). When a nerve impulse stimulates a muscle, these proteins slide past each other, creating tension. In an isometric contraction, this sliding action occurs, but the external load or resistance (e.g., the weight of a controller, the resistance of a joystick) is too great, or the intent is to maintain a fixed position, preventing the muscle from shortening. The tension builds up within the muscle, but the origin and insertion points of the muscle remain at a constant distance. This sustained tension generation is energy-intensive, relying on ATP (adenosine triphosphate) for continuous cross-bridge cycling even without gross movement. For ergonomic designers of drone controllers and interfaces, understanding this physiological process is crucial to minimize fatigue and maximize the precision of human input, enabling pilots to perform delicate maneuvers or hold stable positions for extended periods.
The Distinctive Nature of Isometric Engagement in Pilot Control
The significance of isometric contraction extends beyond simple force generation; it is fundamental for posture, stability, and the execution of highly precise movements. For a drone pilot, holding a joystick steady against minor resistance, maintaining a stable wrist position, or bracing the core to absorb vibration during FPV flight all involve continuous isometric engagement of various muscle groups. This type of contraction allows for extremely fine adjustments and the maintenance of static positions, which are crucial for achieving steady shots in aerial filmmaking or executing delicate maneuvers in drone racing. Without the ability to engage muscles isometrically, sustained precision and control would be impossible, leading to jerky, unstable movements that degrade flight performance and imaging quality.
Optimizing Human-Machine Interface Through Isometric Understanding
The advent of sophisticated drone technology, from autonomous flight to AI-driven features, paradoxically highlights the enduring importance of human factors in control and interaction. Understanding isometric muscle contraction offers profound insights into optimizing pilot performance and designing more intuitive interfaces for complex flight systems.
Precision Control and Ergonomics in Drone Operation
For professional drone pilots, especially those engaged in cinematic work, intricate industrial inspections, or emergency response, the ability to maintain a rock-steady hand on the controls is paramount. This requires sustained isometric contractions in the hands, wrists, and arms. Long-duration flights or highly detailed tasks can lead to muscle fatigue, directly impacting precision and safety. Designers of drone controllers, therefore, must consider ergonomics that minimize unnecessary isometric strain while maximizing control fidelity. Features like adjustable stick tension, comfortable grip designs, and balanced controller weight can significantly reduce the fatigue associated with prolonged isometric holds. Research into haptic feedback and force-sensitive joysticks also draws upon an understanding of human proprioception and the subtle forces involved in isometric actions, aiming to provide a more intuitive and less fatiguing control experience that enhances pilot endurance and accuracy.
Pilot Endurance and Advanced Training Regimens
Beyond hardware design, pilot training benefits significantly from an understanding of isometric principles. Specific exercises aimed at improving isometric strength and endurance in the forearms, wrists, and core can enhance a pilot’s ability to maintain stable control over extended periods. This translates directly to better flight performance, reduced errors due to fatigue, and improved overall operational safety, especially in demanding scenarios such as long-range inspections or complex mapping missions. As drone technology evolves, requiring pilots to manage increasingly complex systems and data streams, their physical endurance and fine motor control—heavily reliant on isometric capabilities—become even more critical elements of effective human-machine teaming. Integrating isometric training into pilot programs ensures that human operators are physically prepared to meet the demands of cutting-edge flight operations.
Mimicking Isometric Stability in Autonomous Systems and Robotics
The principles observed in biological isometric contractions serve as a compelling blueprint for innovation in autonomous systems and robotics. Replicating the stability and controlled force generation of isometric action is a key challenge in developing advanced drone capabilities and robotic manipulators.
Stabilization and Force Control in Autonomous Drones
Modern drones utilize sophisticated flight controllers and sensor fusion to achieve incredible stability, effectively mimicking an “isometric hold” in the air. When a drone hovers in place against wind gusts, its motors and control surfaces are constantly making rapid, precise adjustments to counteract external forces without yielding significant position changes. This is analogous to a muscle generating tension to resist a load without shortening. Algorithms for attitude hold, position hold, and even intelligent obstacle avoidance rely on quickly sensing deviations and applying counter-forces to maintain a desired state. This “isometric-like” stability is crucial for accurate mapping, precise payload delivery, maintaining line of sight for remote sensing, and ensuring high-quality data acquisition in a variety of challenging environmental conditions. The continuous, nuanced adjustments made by autonomous flight systems reflect a mechanical embodiment of isometric control.

Actuators and Holding Mechanisms in Robotics and AI
In the broader field of robotics and advanced tech, the concept of isometric force generation is directly applicable to actuator design and robotic end-effectors. Robotic arms designed for delicate manipulation or inspection tasks, such as those that might service a drone in the field or operate its sensors, require mechanisms that can apply and sustain precise forces without unwanted movement. This involves highly sensitive force sensors and sophisticated control loops that allow the robotic joint to “hold” a position or apply a specific pressure without overshooting or shaking—a mechanical analogue to isometric muscle action. Future advancements in “soft robotics” and biologically inspired actuators, potentially leveraging AI to learn and adapt, may further blur the lines, with artificial muscles capable of generating and sustaining isometric tension. This could offer new paradigms for drone manipulation, interaction with the physical world, and the development of highly adaptable robotic systems that excel in environments requiring stable, sustained effort.
By understanding what isometric muscle contraction entails, from its biological roots to its implications for human-machine interaction and robotic design, we gain valuable insights into optimizing both human performance in the drone industry and the development of the next generation of autonomous and innovative flight technologies. It’s a subtle yet powerful principle, underpinning the stability and precision that define excellence in the rapidly advancing world of drones and aerial tech.