
In the dynamic realm of drone technology and innovation, particularly concerning advanced applications like mapping, remote sensing, and autonomous flight, the concept of “internal reliability” takes on paramount importance. While traditionally defined in psychometrics as the consistency of a measure within itself, in the context of complex drone systems, internal reliability refers to the consistent, dependable, and robust performance of integrated components, sensors, algorithms, and processes that work together to achieve a specific outcome. It’s the assurance that the drone’s sophisticated internal mechanisms consistently produce accurate, repeatable, and coherent data or actions, underpinning the trustworthiness of its advanced capabilities.

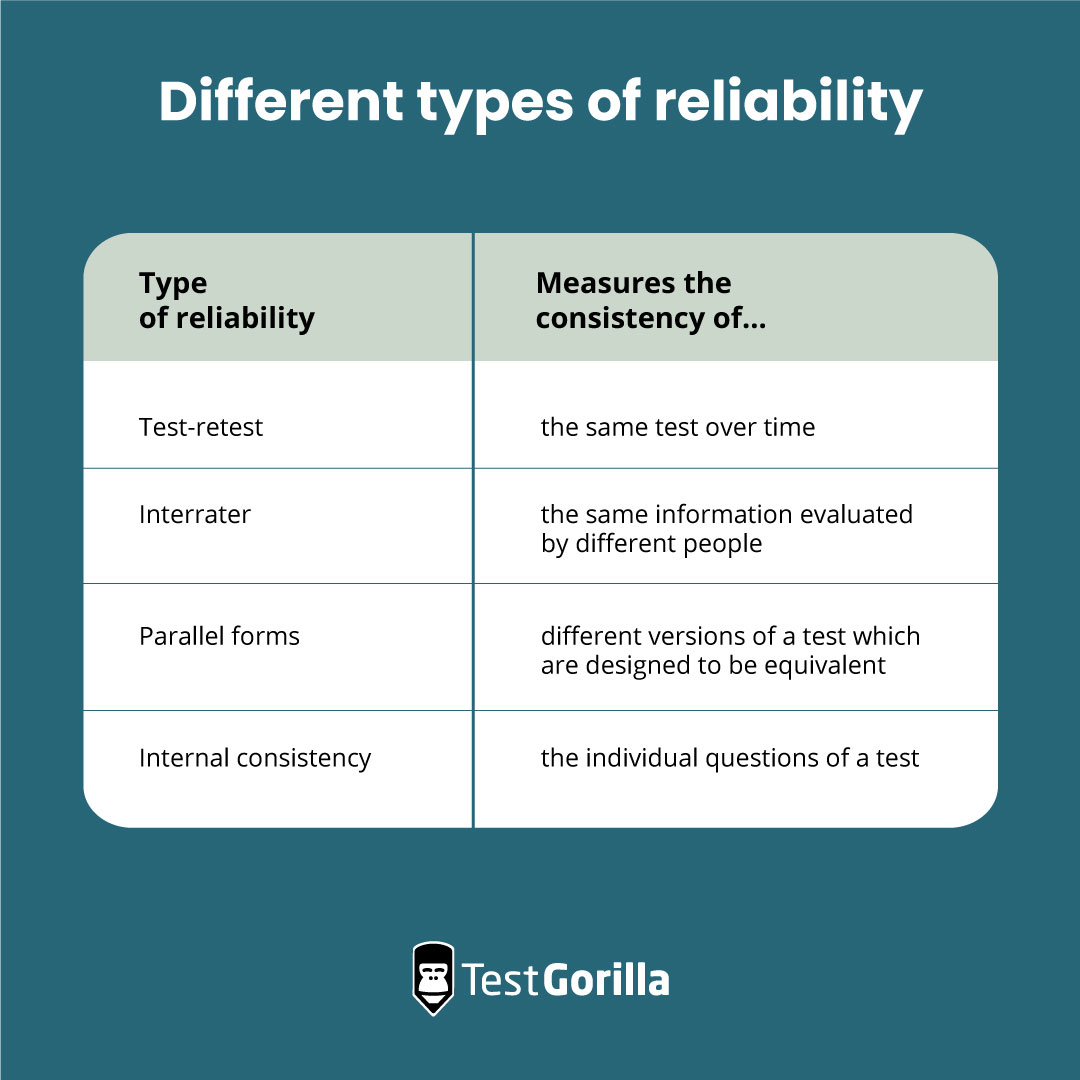
This form of reliability is distinct from external reliability (e.g., test-retest reliability), which assesses consistency over time or across different conditions. Instead, internal reliability focuses on the integrity and harmony within the system itself – how well its various interacting parts contribute consistently to a unified and expected output during a single operation or mission. For a drone engaged in high-stakes mapping or precision agriculture, the internal reliability of its data acquisition and processing chain is directly correlated with the utility and validity of its insights.
Core Principles of Data Consistency in Drone Tech
At its heart, internal reliability in drone technology is about the unwavering consistency of data. Drones are increasingly sophisticated data collection platforms, equipped with an array of sensors designed to capture information across various spectrums and dimensions. The reliability of this data hinges on the consistent operation of each sensor, its calibration, and the harmonious integration of multiple data streams.
Consider a drone conducting a remote sensing mission to assess crop health. It might employ a multispectral camera, a thermal sensor, and a high-resolution RGB camera simultaneously. For the resulting data to be internally reliable, several factors must hold true:
- Sensor Consistency: Each sensor must perform consistently throughout the mission, with minimal drift in calibration, noise levels, or response characteristics. A multispectral sensor’s different bands must maintain their relative spectral sensitivity and accuracy.
- Temporal Coherence: Data captured at different points during a single flight, intended to represent a continuous surface or phenomenon, must exhibit internal consistency. This means that successive measurements of the same feature should be within an acceptable margin of error, reflecting true changes rather than measurement inconsistencies.
- Spatial Consistency: When combining data from overlapping flight paths or multiple passes, the resulting composite dataset must be spatially coherent and consistent. Edges of stitched images or merged point clouds should align accurately, with uniform data density and quality across the entire mapped area.
- Systematic Error Minimization: Internal reliability demands that any systematic errors inherent in the sensors or processing chain are either negligible or consistently corrected for, rather than introducing unpredictable variability into the output.
Ultimately, the goal is to ensure that the sum of the drone’s internal parts functions as a reliable, cohesive whole, providing a stable and trustworthy foundation for its advanced applications.
Sensors, Algorithms, and Data Integrity
The internal reliability of a drone’s advanced capabilities is intrinsically linked to the performance of its sensors and the robustness of its processing algorithms. These two pillars form the bedrock of data integrity for applications such as mapping, 3D modeling, environmental monitoring, and autonomous navigation.
Multispectral and Hyperspectral Consistency
For remote sensing applications, drones often carry multispectral or hyperspectral cameras. These sensors capture light intensity across several discrete (multispectral) or many continuous (hyperspectral) spectral bands. Internal reliability here means that the radiometric calibration of each band is stable throughout the flight, and the relative response between bands remains consistent. If, for instance, a particular band’s sensitivity drifts during a mapping mission, it could lead to inconsistent vegetation indices (e.g., NDVI) across different parts of the same field, compromising the internal reliability of the agricultural analysis. Ensuring consistent exposure settings, proper white balancing, and uniform data quantization across all bands is critical for maintaining this internal consistency.
LiDAR and Point Cloud Reliability
LiDAR (Light Detection and Ranging) systems generate highly accurate 3D point clouds by emitting laser pulses and measuring the time it takes for them to return. The internal reliability of a LiDAR system centers on the consistent emission and reception of pulses, precise timing mechanisms, and stable calibration of the scanner. A reliable LiDAR system will consistently produce dense, uniform, and accurate point clouds, where measurements of the same physical feature (e.g., a building corner or a tree branch) taken from slightly different perspectives during a single flight should align precisely. Inconsistent point density, unexplained gaps, or vertical discrepancies within the same feature across different parts of a point cloud indicate a lack of internal reliability, challenging the integrity of the 3D model.
GPS and Positional Accuracy
While GPS (Global Positioning System) is an external aid, its integration and consistent processing within the drone’s flight controller and navigation systems are crucial for internal reliability. The consistent and accurate estimation of the drone’s position and orientation (attitude) throughout a mission ensures that all sensor data is correctly georeferenced. Any internal inconsistency in GPS signal processing, IMU (Inertial Measurement Unit) data fusion, or RTK/PPK (Real-Time Kinematic/Post-Processed Kinematic) corrections can lead to spatial inaccuracies, misalignments in subsequent data stitching, and a significant reduction in the internal reliability of the overall mapping product. Consistent internal algorithms for Kalman filtering or similar sensor fusion techniques are vital to maintaining stable and accurate positional data.

Algorithms and Processing Robustness
Beyond sensor performance, the algorithms used to process raw data are equally critical for internal reliability. Photogrammetry software, for example, must consistently identify key features, match corresponding points across multiple overlapping images, and accurately reconstruct 3D models. The internal reliability of such algorithms ensures that regardless of the specific image set from a single mission, the resulting 3D model or orthomosaic map is always consistent in its geometric accuracy, texture mapping, and overall representation of the ground truth. Similarly, AI and machine learning models used for object detection, classification, or autonomous decision-making must exhibit consistent performance, avoiding erratic or unpredictable outputs under similar input conditions. Their internal logic and learned parameters must be stable and reliably applied to new data.
Ensuring Reliability in Autonomous Missions
Autonomous flight represents the pinnacle of drone innovation, demanding the highest levels of internal reliability. For a drone to execute complex tasks without direct human intervention, its internal systems must operate with unwavering consistency and precision.
Redundancy in Systems
One primary strategy for enhancing internal reliability in autonomous drones is system redundancy. Critical components like flight controllers, GPS modules, and communication links are often duplicated. If a primary system exhibits an internal anomaly or failure, the redundant system can seamlessly take over, maintaining the mission’s integrity. For instance, dual IMUs can cross-reference data, and if one shows inconsistent readings (e.g., unexpected acceleration values), the flight control system can switch to or fuse data from the healthier unit. This internal checking and switching mechanism is a cornerstone of ensuring consistent performance.
Pre-flight Calibration and Post-processing Validation
Rigorous pre-flight calibration routines are essential for establishing a baseline of internal reliability. Calibrating sensors, checking communication links, and verifying flight plan parameters ensure that all systems start in an optimal and known state. Post-processing validation further reinforces internal reliability by checking the consistency of the collected data. This can involve comparing overlapping datasets, performing statistical analyses on data consistency, or using ground control points (GCPs) to verify spatial accuracy. Discrepancies identified during validation can highlight areas where internal systems may have exhibited inconsistencies, prompting recalibration or algorithm refinement.
Real-time Monitoring and Diagnostics
Advanced autonomous drones integrate sophisticated real-time monitoring and diagnostic systems. These systems continuously assess the health and performance of internal components, including battery status, motor temperatures, sensor outputs, and navigation system integrity. Any deviation from expected operational parameters, inconsistent data streams, or software anomalies trigger alerts or automated corrective actions. For example, if a vision-based obstacle avoidance system detects inconsistent depth measurements from its stereo cameras, it might trigger a hover command or switch to an alternative navigation mode, prioritizing safety and mission integrity over potentially unreliable data. This active internal self-assessment is crucial for maintaining consistent operational reliability throughout an autonomous mission.
The Impact of High Internal Reliability
The pursuit of high internal reliability in drone technology is not merely an academic exercise; it has profound practical implications that extend across various industries and applications.
Enhanced Decision-Making
For applications like precision agriculture, environmental monitoring, or construction site progress tracking, data-driven decisions are paramount. High internal reliability ensures that the data collected by drones is consistent, accurate, and trustworthy. Farmers can confidently apply variable rate treatments based on consistent crop health maps, environmental scientists can track changes in ecosystems with higher certainty, and construction managers can rely on accurate volumetric calculations and progress reports. Inconsistent or unreliable data leads to poor decisions, wasted resources, and potentially dangerous outcomes.
Scientific Accuracy and Reproducibility
In research and scientific applications, such as glaciology, archaeology, or atmospheric science, the reproducibility of results is fundamental. Drones offer unprecedented capabilities for data collection in these fields. High internal reliability means that repeated drone missions over the same area, using the same equipment and methodologies, will yield consistent results within acceptable margins of error. This consistency allows scientists to confidently draw conclusions, validate hypotheses, and contribute reliably to scientific knowledge. Without it, findings could be dismissed as artifacts of measurement inconsistency rather than true observations.
Operational Efficiency and Safety
From a practical operational standpoint, high internal reliability translates directly into increased efficiency and enhanced safety. Drones that consistently perform as expected require less manual intervention, fewer re-flights due to data quality issues, and reduced risk of unexpected system failures. This optimizes flight planning, data processing workflows, and overall project timelines. Moreover, in autonomous or BVLOS (Beyond Visual Line Of Sight) operations, robust internal reliability in navigation, obstacle avoidance, and system health monitoring is non-negotiable for ensuring safe operation in complex environments, protecting assets, and preventing harm.
In conclusion, internal reliability in drone technology signifies the inherent consistency and dependability of an integrated system’s components and processes. It’s the assurance that the intricate web of sensors, algorithms, and control systems within a drone consistently delivers on its promise of accurate data collection, robust performance, and safe autonomous operation, truly unlocking the transformative potential of advanced drone innovation.