
Inertia, a fundamental concept in classical physics, describes an object’s resistance to changes in its state of motion. Coined by Johannes Kepler and later formalized by Sir Isaac Newton, it is the inherent property of matter that dictates how much force is required to alter an object’s velocity, whether that means speeding up, slowing down, or changing direction. In the realm of flight technology, particularly concerning drones and advanced aerial systems, understanding inertia is not merely academic; it is foundational to design, control, navigation, and stabilization, profoundly influencing everything from a drone’s stability in gusty winds to the precision of its autonomous flight path.

The Fundamental Principle of Inertia in Flight
At its core, inertia is a manifestation of mass. The more massive an object, the greater its inertia, and consequently, the greater its resistance to acceleration or deceleration. For an aircraft, whether a manned jet or a miniature drone, this principle governs its every movement and interaction with external forces.
Newton’s First Law and Aviation
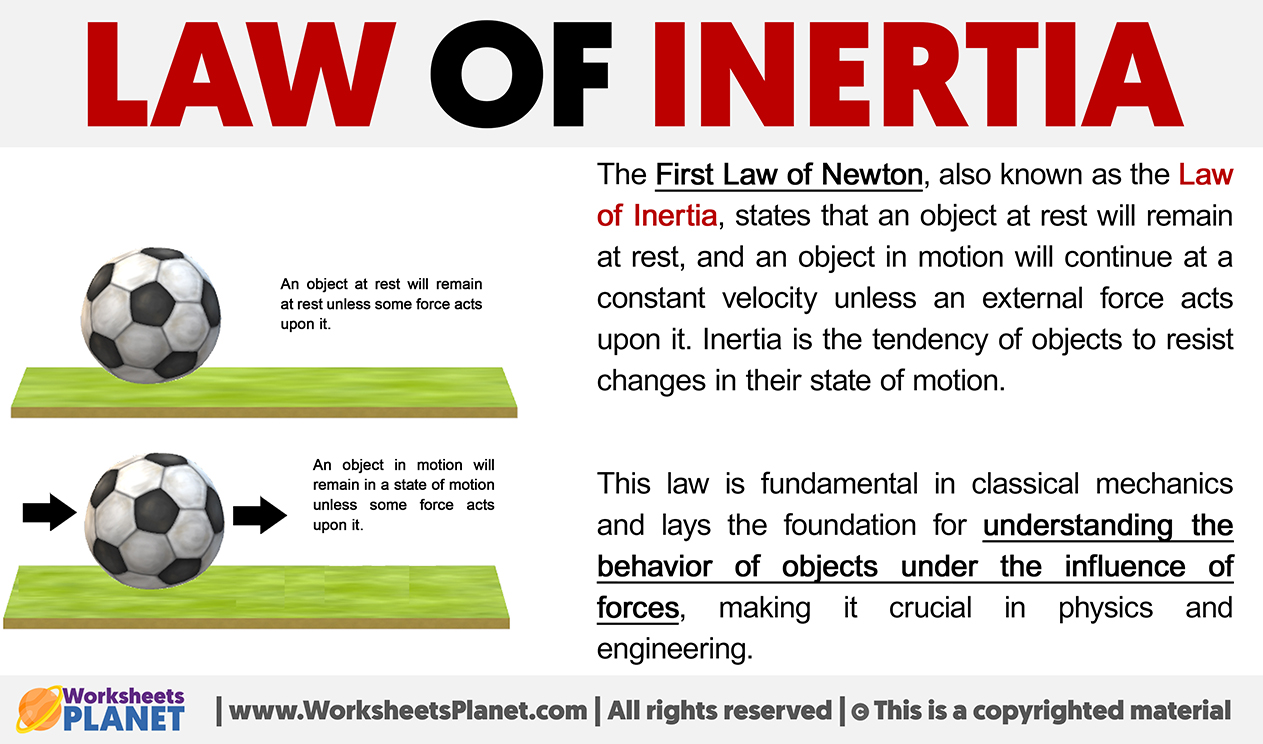
Newton’s First Law of Motion, often called the Law of Inertia, states that an object at rest stays at rest, and an object in motion stays in motion with the same speed and in the same direction unless acted upon by an unbalanced force. In the context of flight, this means a drone will maintain its current velocity vector unless its propellers generate thrust to overcome air resistance, gravity, or to initiate a turn or climb. When hovering, the drone’s inertia keeps it stationary relative to the air until an external force (like a gust of wind) or an internal force (like a change in propeller speed) acts upon it. Similarly, once in motion, it will attempt to continue moving in a straight line at a constant speed, even if the motors momentarily falter, illustrating the intrinsic resistance to any change in its dynamic state.
Mass, Momentum, and Resistance to Change
Inertia is directly proportional to an object’s mass. A heavier drone possesses greater inertia than a lighter one. This has significant implications. A drone with higher inertia will be more resistant to external disturbances like wind gusts, offering a naturally more stable platform, particularly for aerial photography or sensor payload stability. However, this increased inertia also means it requires more force (more powerful motors, larger propellers, greater energy consumption) to accelerate, decelerate, or change direction quickly. This trade-off between stability and maneuverability is a critical design consideration for drone engineers, balancing the mass of the airframe, batteries, and payload to achieve the desired flight characteristics. Momentum, the product of mass and velocity, further illustrates this; a drone with high momentum is harder to stop or redirect, necessitating sophisticated control systems to manage its trajectory safely and efficiently.
Inertia’s Role in Drone Stabilization Systems
Modern flight technology, especially in UAVs, heavily relies on sophisticated stabilization systems to maintain level flight, counteract disturbances, and enable precise maneuvers. Inertial measurement units (IMUs), comprising gyroscopes and accelerometers, are the cornerstone of these systems, directly sensing and interpreting inertial forces.
Gyroscopes: Sensing Angular Inertia
Gyroscopes measure angular velocity, which is the rate of rotation around an axis. When a drone experiences an unwanted roll, pitch, or yaw motion (e.g., due to wind), its internal gyroscopes detect these changes in angular orientation. The drone’s flight controller then processes this data, understanding that the drone’s inertia is being overcome by an external torque, and sends commands to the motors to adjust propeller speeds. By increasing or decreasing the thrust on specific propellers, the flight controller generates counter-torques that counteract the unwanted rotation, bringing the drone back to its desired attitude. Without gyroscopes, the drone’s inertia would simply carry it into an uncontrolled spin or tilt, making stable flight impossible. These sensors effectively provide the instantaneous feedback needed to overcome the drone’s angular inertia when disturbances arise or to precisely control it during intentional maneuvers.
Accelerometers: Detecting Linear Inertia
Accelerometers measure linear acceleration along an axis. They sense the forces acting on the drone, including gravity and any forces causing it to speed up or slow down. When a drone is in level flight, accelerometers mainly sense the constant downward pull of gravity. However, if the drone begins to drift horizontally or vertically due to wind or an uncommanded change in thrust, the accelerometers detect these linear accelerations. By integrating the accelerometer data over time, the flight controller can estimate changes in velocity and, with further integration, changes in position. This information is crucial for maintaining a stable hover, preventing uncontrolled translational drift, and providing data for position estimation, especially in conjunction with other sensors.
Fusing Inertial Data for Stability
The true power of modern drone stabilization lies in the sensor fusion algorithms that combine data from both gyroscopes and accelerometers within the IMU. While gyroscopes provide excellent short-term angular rate data, they are prone to drift over longer periods. Accelerometers, on the other hand, provide reliable long-term orientation information (especially concerning gravity’s direction) but are susceptible to noise from vibrations and linear accelerations. By fusing these two data streams, often using algorithms like Kalman filters, the flight controller can achieve a highly accurate and robust estimation of the drone’s orientation and linear motion. This fused inertial data allows the flight controller to actively overcome or precisely manage the drone’s inertia, ensuring unparalleled stability and responsiveness, even in challenging environmental conditions or during aggressive maneuvers.
Inertial Navigation Systems (INS) for Precision Flight
Beyond stabilization, inertia is critical for Inertial Navigation Systems (INS), which allow drones to track their position, velocity, and orientation without external references like GPS for short periods. This capability is vital for autonomous operations, especially in environments where GPS signals are weak or unavailable.
From Accelerometers to Position
An INS fundamentally operates by continuously measuring the drone’s accelerations and angular velocities using a high-precision IMU. The system then performs complex mathematical integrations. First, the measured accelerations are integrated over time to calculate the drone’s velocity. Then, these velocities are integrated over time to determine the drone’s current position relative to its starting point. Simultaneously, angular rates from the gyroscopes are integrated to track changes in the drone’s orientation. This process leverages the drone’s inertia: the INS knows that if a certain acceleration is applied, the drone’s inertia will cause it to change its velocity and position in a predictable way, allowing the system to keep a running tally of its state.

Drift and the Need for Augmentation (GPS/GNSS)
Despite their sophistication, pure INS systems suffer from an inherent limitation: drift. Because each integration step accumulates small errors from sensor noise, measurement inaccuracies, and computational rounding, these errors grow over time. Even tiny errors in acceleration measurements can lead to significant errors in calculated velocity and position after a few minutes. For instance, a 0.001 m/s² error in acceleration integrated over 10 minutes (600 seconds) would result in a 3.6-meter error in velocity and a 720-meter error in position. To counteract this inertial drift, INS systems in drones are almost always augmented with external navigation aids, predominantly Global Positioning System (GPS) or other Global Navigation Satellite Systems (GNSS). The GPS receiver provides periodic, absolute position fixes, which are used to correct the accumulating errors in the INS. This hybrid approach, often managed by a Kalman filter, combines the INS’s excellent short-term accuracy and high update rate (useful for smooth control and rapid maneuvers) with the GPS’s long-term accuracy, creating a robust and highly precise navigation solution.
Applications in Autonomous Flight and Mapping
The synergistic combination of INS and GPS/GNSS is indispensable for advanced flight technology. In autonomous flight, this integrated system allows drones to follow complex pre-programmed flight paths with extreme precision, perform automated take-offs and landings, and maintain accurate georeferencing for tasks like automated package delivery or surveillance. For mapping and surveying, an accurate INS/GPS solution ensures that each image captured by the drone’s camera is precisely tagged with its geographic coordinates and orientation, critical for generating highly accurate 3D models and orthomosaics. Without this robust inertial-aided navigation, the precision and reliability of modern autonomous drone operations would be severely limited.
Overcoming Inertia: Control Systems and Maneuverability
While inertia provides a baseline for stability, effective flight requires dynamic control to overcome this inherent resistance and achieve desired maneuvers. This is where the interplay of thrust, torque, and sophisticated control algorithms becomes paramount.
Propeller Thrust and Torque Generation
Drones, especially multirotors, manipulate their inertia through the precise control of propeller thrust. Each motor spins a propeller, generating a vertical thrust force. To move forward, a drone tilts its body by increasing thrust from its rear propellers and decreasing thrust from its front propellers, creating a net forward thrust vector that overcomes the drone’s forward inertia. Similarly, to turn (yaw), a drone exploits the reaction torque generated by the spinning propellers. By slightly increasing the speed of two diagonally opposite propellers while decreasing the speed of the other two, a net torque is generated, allowing the drone to overcome its angular inertia and rotate around its vertical axis. The magnitude and direction of these forces must be precisely controlled to overcome the drone’s inertia in a predictable and stable manner.
PID Controllers and Inertial Response
The brain of the drone’s control system is often a Proportional-Integral-Derivative (PID) controller. This algorithm continuously calculates the difference between the drone’s desired state (e.g., hover level) and its actual state (as reported by the IMU’s inertial data).
- Proportional (P) component: Reacts to the current error, providing immediate corrective thrust to counter inertia. A larger error leads to a stronger corrective action.
- Integral (I) component: Accounts for past errors, eliminating steady-state errors or drift that the proportional term might miss, thus ensuring the drone eventually settles exactly at the desired state by slowly overcoming persistent inertial biases or environmental forces.
- Derivative (D) component: Predicts future errors based on the rate of change of the current error, dampening oscillations and preventing overshoots. This is crucial for managing the drone’s momentum and preventing it from overreacting to corrective inputs, which could lead to instability due to its own inertia.
Together, the PID controller constantly works to manage the drone’s inertia, applying forces to bring it to its desired position and orientation, absorbing external disturbances, and ensuring smooth, stable flight.
The Trade-off: Stability vs. Agility
The mass and distribution of mass within a drone directly dictate its inertia, leading to a fundamental trade-off: stability versus agility. A heavier drone with higher inertia will be inherently more stable against external forces like wind, making it ideal for tasks requiring a steady platform, such as aerial mapping or cinematic videography. However, this same high inertia means it will be less agile, requiring more powerful motors and greater energy to change direction or accelerate quickly. Conversely, a lightweight racing drone with low inertia can achieve extreme agility and rapid maneuvers but might struggle to maintain stability in gusty conditions. Designing a drone involves carefully balancing these factors, optimizing its mass, size, and motor power to achieve the desired flight characteristics for its intended application, all while understanding and exploiting the principles of inertia.
Inertia in Advanced Flight Technology and Future Implications
The principles of inertia continue to drive innovation in flight technology, pushing the boundaries of what UAVs can achieve in complex and dynamic environments.
Mitigating Environmental Disturbances
Advanced flight control algorithms are constantly being developed to better leverage and counteract inertia in the face of environmental challenges. For instance, in windy conditions, inertial sensors allow the flight controller to quickly detect unwanted accelerations and rotations caused by gusts. The system can then predict the drone’s inertial response and apply precise, calculated counter-forces to maintain stability and trajectory. Research into adaptive control systems, which learn and adjust their PID gains in real-time based on the drone’s inertial response to varying conditions, aims to create UAVs that are even more resilient and reliable in unpredictable weather.
Crash Resistance and Payload Stability
Inertia plays a critical role in the design of crash-resistant drones. Materials chosen for their strength-to-weight ratio aim to minimize overall mass (and thus inertia) while maximizing structural integrity to absorb impacts. For payloads, especially sensitive cameras or sensors, the drone’s inertia provides a stable platform. However, during maneuvers or impacts, the payload’s own inertia can create stresses on its mounting points. Gimbal systems, which counteract angular inertia to keep cameras steady, are prime examples of technology specifically designed to isolate sensitive payloads from the drone’s inherent motion and vibration. Advanced active vibration dampening systems are also being developed to further mitigate inertial effects on critical components.
Towards More Dynamic and Resilient UAVs
Looking ahead, a deeper understanding and more sophisticated manipulation of inertia will lead to even more dynamic and resilient UAVs. This includes drones capable of extreme acrobatic maneuvers with precise recovery, autonomous vehicles that can navigate through highly cluttered and dynamic environments with greater speed and safety, and systems that can perform complex tasks requiring fine motor control even under significant external disturbances. Future innovations might involve variable inertia systems, where a drone can adjust its mass distribution in flight to optimize for different flight phases (e.g., low inertia for agile travel, high inertia for stable payload deployment). Ultimately, inertia, a seemingly simple physical concept, remains at the heart of developing the next generation of intelligent and capable flight technology.