
In the intricate world of drone flight technology, achieving perfect stability and responsiveness is an ongoing quest. While terms like PID tuning, IMU calibration, and GPS accuracy are common parlance, understanding the nuanced states of a drone’s control system can lead to breakthroughs in performance. One such concept, which can be analogously applied from biology to flight dynamics, is “hypertonicity.” Far from its cellular definition, in the realm of drones, hypertonicity describes a state of excessive rigidity, over-responsiveness, or undue internal tension within a flight control system, often leading to undesirable flight characteristics and compromised performance.
Understanding “Hypertonicity” in Drone Flight Systems
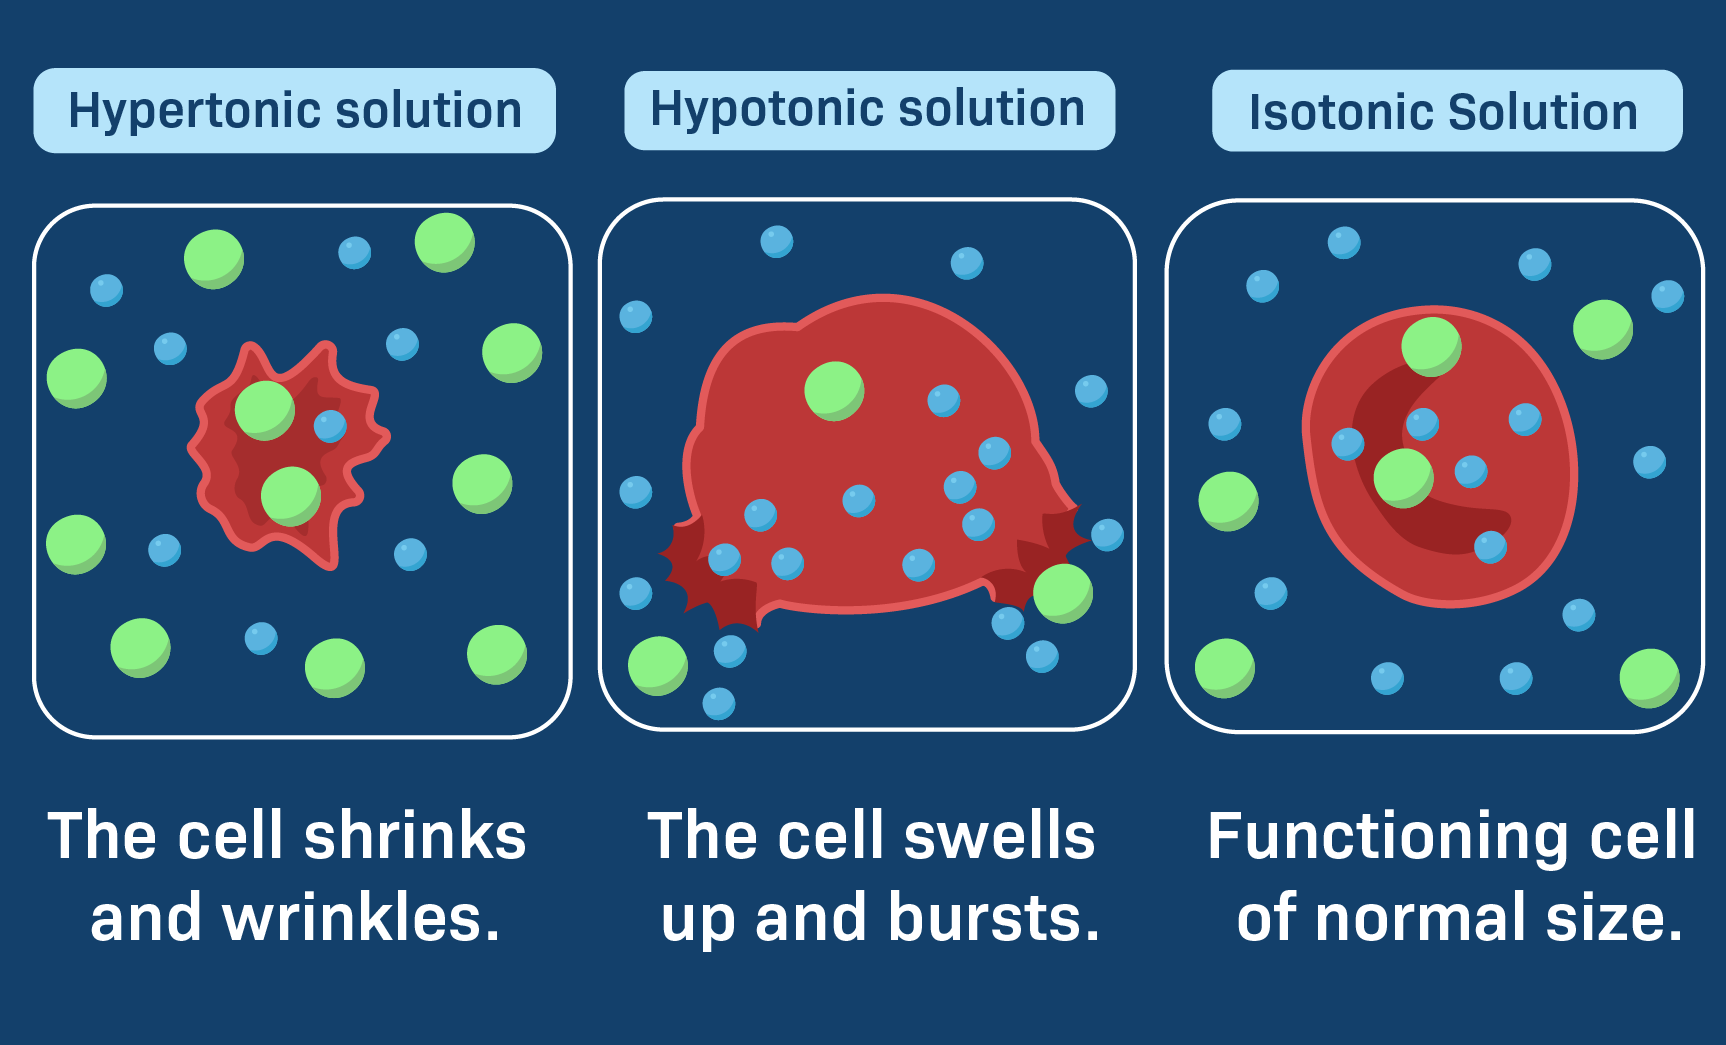
To grasp hypertonicity in a drone context, imagine a system that is overly sensitive or too aggressively tuned. Instead of responding smoothly and proportionally to commands or environmental disturbances, it overcompensates, exhibiting an almost “tense” or “spastic” reaction. This is the opposite of a “hypotonic” state, where the system is sluggish, unresponsive, or under-damped, leading to a loose and unstable flight. The ideal lies in achieving optimal “tonicity”—a balanced state where the drone responds precisely and smoothly, maintaining stability without excessive corrections or rigidity.
This metaphorical application helps us characterize specific issues that arise when flight controllers, sensor inputs, or motor responses are not harmoniously integrated. It’s a crucial concept for advanced drone pilots, engineers, and developers aiming to push the boundaries of flight precision and efficiency.
The Dynamics of Over-Responsiveness
At its core, hypertonicity manifests as an over-correction. A flight controller might interpret a minor disturbance or input as a significant deviation, triggering a powerful, often disproportionate, counter-action. This constant over-correction consumes excessive energy, places undue stress on mechanical components, and can make the drone challenging to control, particularly in delicate maneuvers or in autonomous flight where smooth transitions are paramount. The symptoms can range from subtle jitters to violent oscillations, all stemming from a system that is, in essence, trying too hard to maintain its position or trajectory.
Manifestations of Hypertonicity in Flight Technology
Hypertonicity can surface in various sub-systems of a drone’s flight technology, each with distinct observable effects. Identifying these manifestations is the first step towards resolving them and achieving a more balanced flight profile.
Over-Aggressive Stabilization Systems
One of the most common arenas for hypertonicity is within the drone’s stabilization system, primarily governed by the Proportional-Integral-Derivative (PID) controller. When the P (proportional) or D (derivative) gains are set too high, the system reacts too forcefully to any deviation from the desired attitude.
PID Gain Imbalance
- High P-Gain: An excessively high proportional gain causes the drone to react too quickly and strongly to errors, leading to rapid, jerky movements. It attempts to correct instantly, but this can cause it to overshoot the target and then oscillate back and forth around the setpoint.
- High D-Gain: While the derivative gain helps to dampen oscillations, an overly high D-gain can also introduce hypertonicity by causing the drone to stiffen excessively against angular velocity changes. This can lead to a “locked-in” feeling that resists smooth pilot inputs, or can even amplify high-frequency vibrations from the frame or motors, leading to a “buzzing” sensation or rapid, small oscillations.
The result is a drone that feels “twitchy” or “on edge,” constantly fighting itself rather than gliding effortlessly. This can be particularly problematic for aerial filmmaking, where smooth, cinematic camera movements are critical.
Navigation and Path Planning Rigidity
In autonomous flight and GPS-guided missions, hypertonicity can manifest as a lack of fluidity in path following. Instead of smoothly arcing between waypoints, a hypertonic navigation system might exhibit sharp, angular turns or zigzagging patterns.
Over-Correction in Autonomous Flight
- Waypoint Transition: Autonomous drones with hypertonic navigation may struggle with smooth waypoint transitions. Rather than anticipating the next point and beginning a gentle turn, they might fly directly to a waypoint, stop or sharply decelerate, and then make an abrupt course change, repeating this cycle for each segment.
- Position Hold Aggression: When attempting to hold a precise GPS position, an overly sensitive system might continuously make small, rapid adjustments, even in calm conditions. This consumes more power and can be visually disruptive for tasks requiring a steady platform, such as mapping or surveying. The system is trying too hard to maintain a point, rather than allowing for minor, acceptable drift.

Such rigidity in path planning can reduce the efficiency of flight paths, increase flight times, and compromise the quality of data collected for applications like photogrammetry.
Sensor Data Over-Weighting and Noise Amplification
Flight controllers rely on a multitude of sensors—IMUs (accelerometers, gyroscopes), barometers, magnetometers, GPS—to understand their orientation and position. If the processing of this sensor data is hypertonic, it can lead to problems.
Amplification of Noise
- Unfiltered Sensor Data: When raw sensor data, especially from the gyroscopes or accelerometers, is fed into the control loop with insufficient filtering, high-frequency noise from motor vibrations or air turbulence can be interpreted as actual drone movement. A hypertonic system will then try to “correct” these non-existent movements, leading to micro-oscillations or a buzzing sound from the motors as they constantly adjust.
- Excessive Confidence in Single Sensor: In some cases, a flight controller might be configured to place too much “weight” on the input from a single sensor, even when other sensors or estimation algorithms could provide a more stable or averaged input. If that primary sensor experiences temporary interference or error, the hypertonic system will follow its erroneous input too aggressively, causing erratic behavior.
This over-reliance on or over-processing of noisy data can lead to instability that is difficult to diagnose without analyzing flight logs.
Identifying and Mitigating Hypertonic States
Addressing hypertonicity requires a systematic approach, combining careful observation, data analysis, and iterative tuning. The goal is always to achieve optimal tonicity—a state of agile, stable, and efficient flight.
Diagnosing Hypertonicity
- Visual Observation: The most immediate indicator is erratic flight behavior: rapid jitters, high-frequency oscillations, or a general feeling of instability. The drone might “feel” overly stiff or difficult to make smooth, flowing movements.
- Audio Cues: A hypertonic drone might exhibit a high-pitched “whine” or “buzzing” sound from the motors, indicating rapid, continuous adjustments, even when hovering stationary.
- Flight Log Analysis: This is the most critical diagnostic tool. Analyzing logs for motor output consistency, gyro/accelerometer readings (looking for high-frequency noise or excessive oscillations), and control input vs. actual output discrepancies can pinpoint the source of hypertonicity. Specifically, look for motor saturation or rapid fluctuations in motor commands that don’t correspond to large pilot inputs.
Tuning PID Gains for Optimal Tonicity
The most direct way to mitigate hypertonicity in stabilization is through meticulous PID tuning. This involves finding the sweet spot where the drone responds quickly without overshooting or oscillating.
- P-Gain Reduction: Gradually reducing the proportional gain can alleviate jerky movements and oscillations. This makes the drone less aggressive in its initial response to errors.
- D-Gain Adjustment: While high D-gain can contribute to hypertonicity, a properly balanced D-gain is essential for damping. Too low, and the drone will overshoot; too high, and it will stiffen excessively. Finding the right balance is key to preventing oscillations without introducing new rigidities.
- I-Gain Consideration: The integral gain helps correct long-term errors and maintain stability against constant forces like wind. While less directly related to acute hypertonicity, an incorrectly tuned I-gain can contribute to a “mushy” feeling (hypotonicity) or slow, persistent oscillations if too high.
Implementing Advanced Filtering and Adaptive Control
Modern flight controllers incorporate sophisticated software solutions to combat hypertonicity.
- Noise Filtering: Digital filters (e.g., low-pass filters) are crucial for removing high-frequency noise from sensor data before it reaches the PID controller. This prevents the system from reacting to phantom movements caused by vibrations.
- Adaptive Control Algorithms: Some advanced flight controllers employ adaptive algorithms that can dynamically adjust PID parameters or other control logic based on real-time flight conditions. For instance, a drone might be less aggressive in calm air but increase its responsiveness in windy conditions, maintaining optimal tonicity across varying environments.
- Sensor Fusion: Employing robust sensor fusion algorithms (like Kalman filters or complementary filters) to combine data from multiple sensors can provide a more accurate and stable estimate of the drone’s state, making the overall system less susceptible to hypertonic reactions based on a single, noisy input.
Hardware Considerations
While software tuning is paramount, hardware plays an undeniable role in preventing hypertonicity.
- Vibration Isolation: Good vibration dampening for the flight controller and IMU sensors is fundamental. This minimizes the noise that the control system would otherwise interpret as actual movement.
- Balanced Propellers and Motors: Unbalanced propellers or poorly manufactured motors introduce vibrations that can propagate throughout the frame, inducing sensor noise. High-quality, balanced components are critical for a “clean” signal to the flight controller.
- Frame Rigidity: A stiff, well-designed drone frame minimizes flex and unwanted resonance, ensuring that the drone responds predictably to control inputs rather than oscillating due to structural give.
The Pursuit of Optimal “Tonicity”
The ideal state for any drone’s flight control system is one of optimal “tonicity.” This is where the drone is perfectly responsive to pilot commands and environmental changes, maintains stability effortlessly, and conserves energy through efficient, smooth movements. It’s neither flaccid nor rigid but possesses an agile, controlled, and fluid dynamic.
Achieving this optimal state is an iterative process of tuning, testing, and refining. It demands a deep understanding of flight dynamics, sensor behavior, and control theory. As drone technology continues to advance, the focus will increasingly be on developing more intelligent, self-optimizing systems that can autonomously detect and correct for states of hypertonicity, ensuring that every flight is as smooth, stable, and efficient as possible, regardless of the mission. The continuous evolution of flight technology, from advanced AI to more precise sensors, all contributes to this overarching goal of harmonious, perfectly tuned flight.